

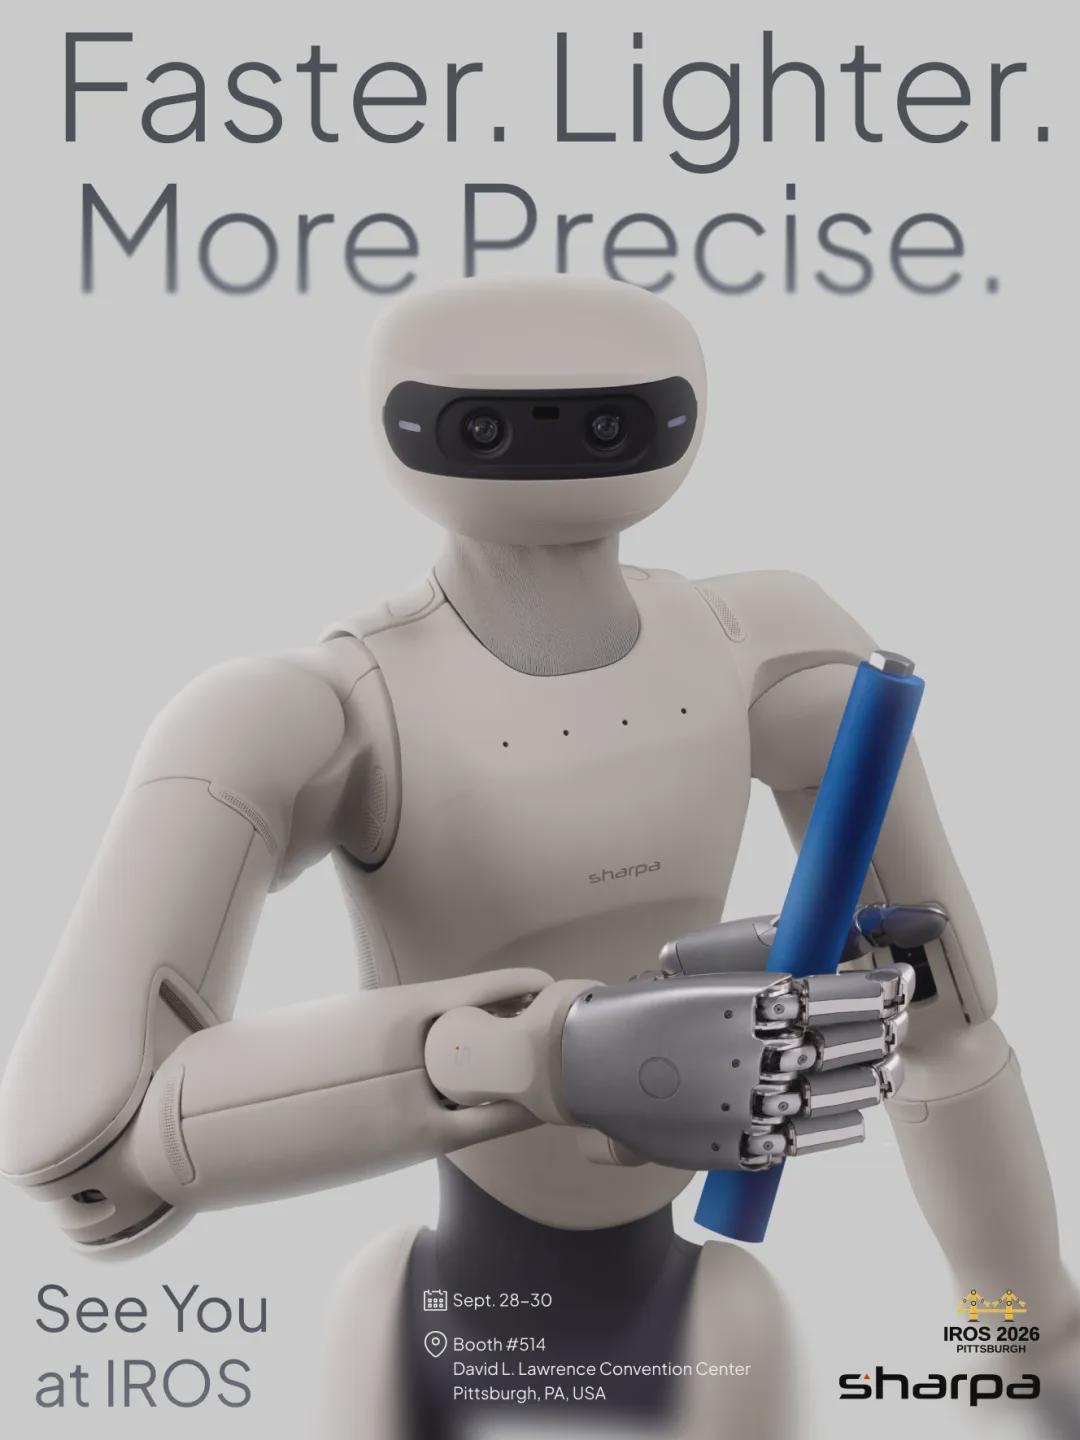
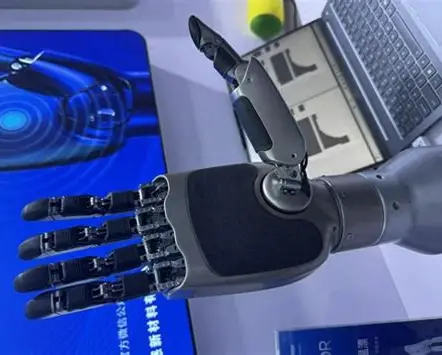
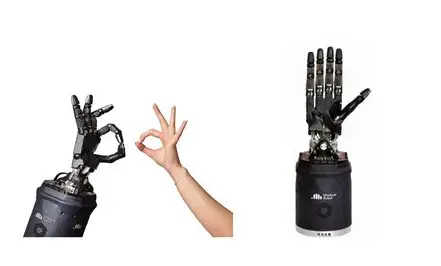
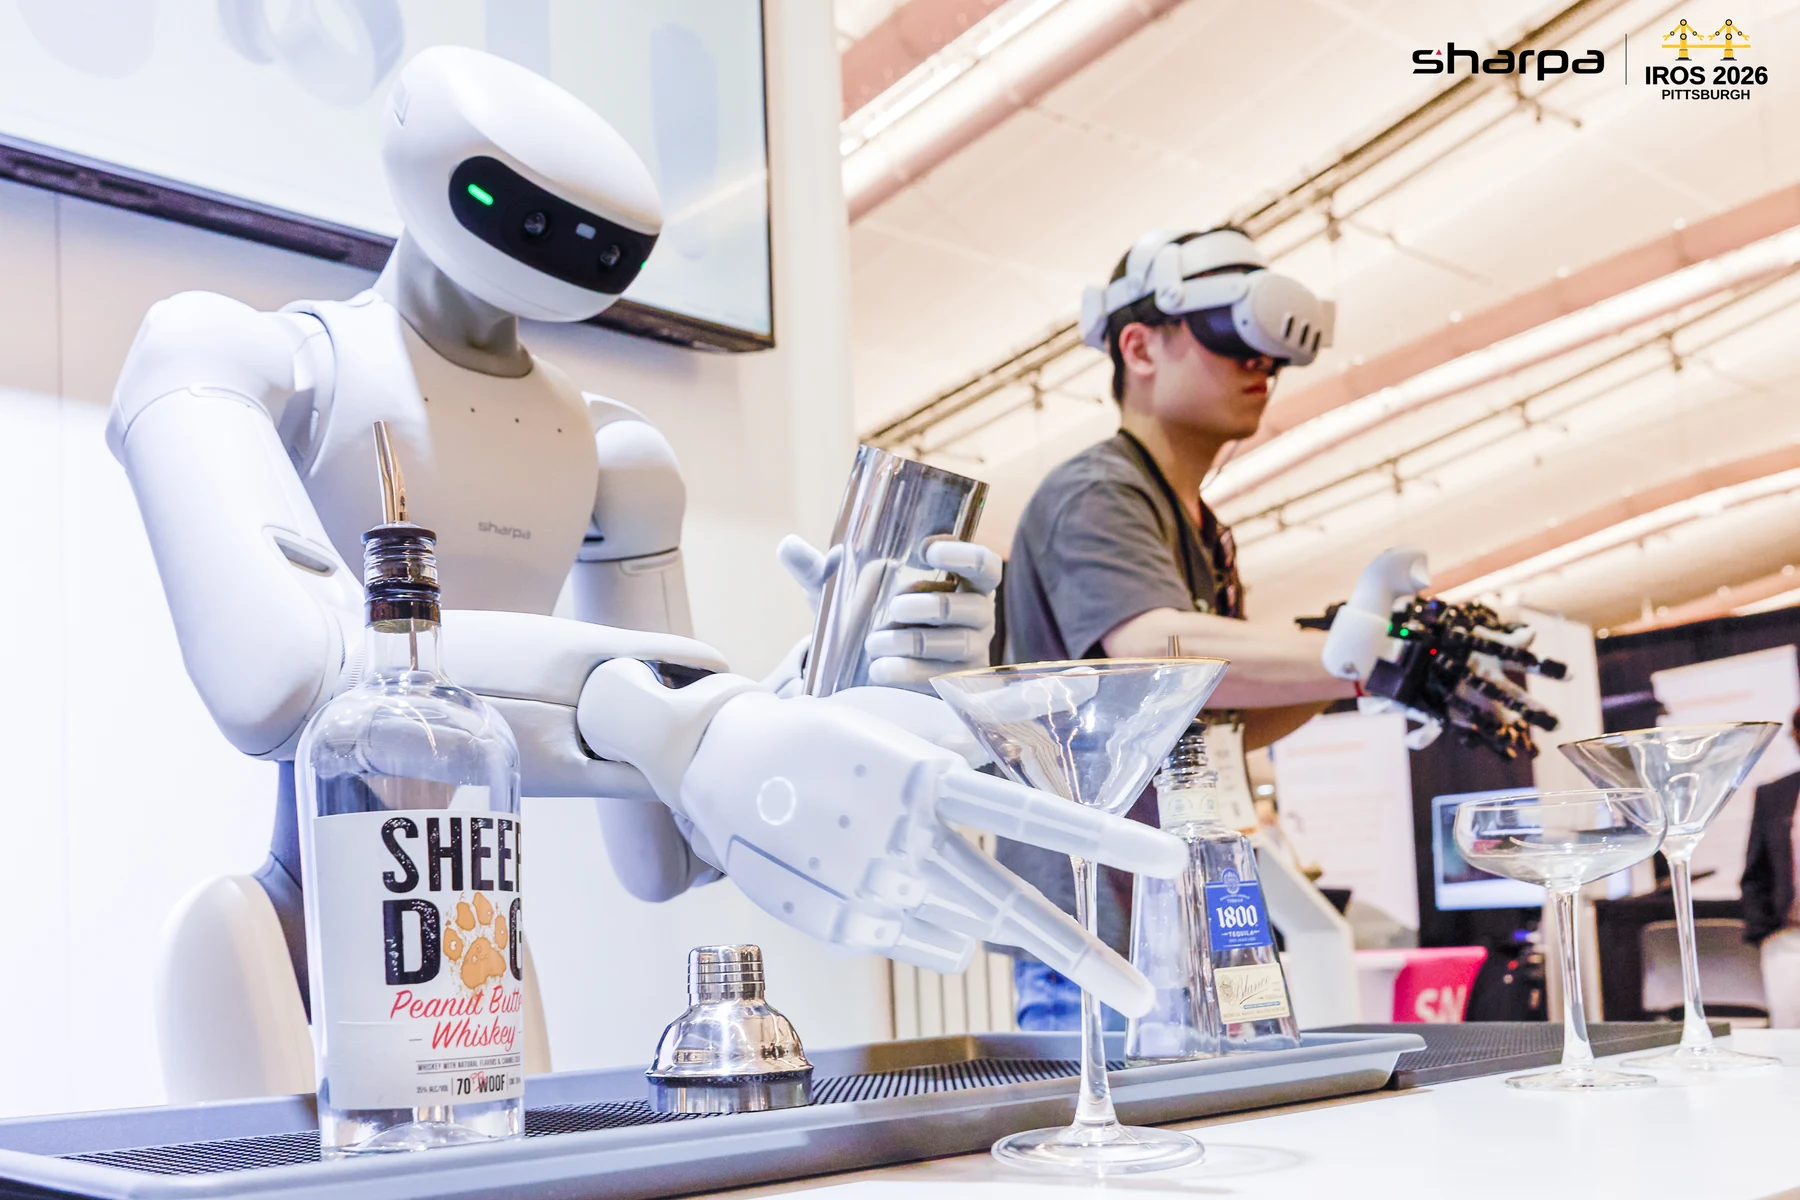
On September 28, at the IROS conference in Pittsburgh, Sharpa showcased a complete robotics system featuring a humanoid robot, a dexterous hand, and an exoskeleton glove. Unlike many exhibitors presenting single modules, Sharpa's offering represents a cohesive system aimed at creating an end-to-end operational loop, enhancing tactile perception, and addressing challenges in real-world applications.
This development is significant as it responds to the industry's need for solutions in real-world environments like retail and dining, where maintaining control precision during high-speed movements and interacting with complex objects are critical. Sharpa's approach integrates the robot body, end effector, and human-machine data input devices, positioning itself as a leader in the dexterous manipulation space.
Looking ahead, the focus will be on the engineering validation of this system, including the performance of its components in real-world scenarios. The D01 humanoid robot, W02 dexterous hand, and AE01 exoskeleton glove are designed to work together seamlessly, with the D01 aiming to achieve high-speed movement and precision control, addressing long-standing challenges in humanoid robotics.
Editor's Note
Sharpa's introduction of a complete dexterous manipulation system highlights a shift in the robotics industry towards integrated solutions that address real-world operational challenges. As robotics technology continues to evolve, the focus on creating systems that can effectively interact with complex environments will be crucial for widespread adoption in sectors like retail and dining.













Leave a comment