

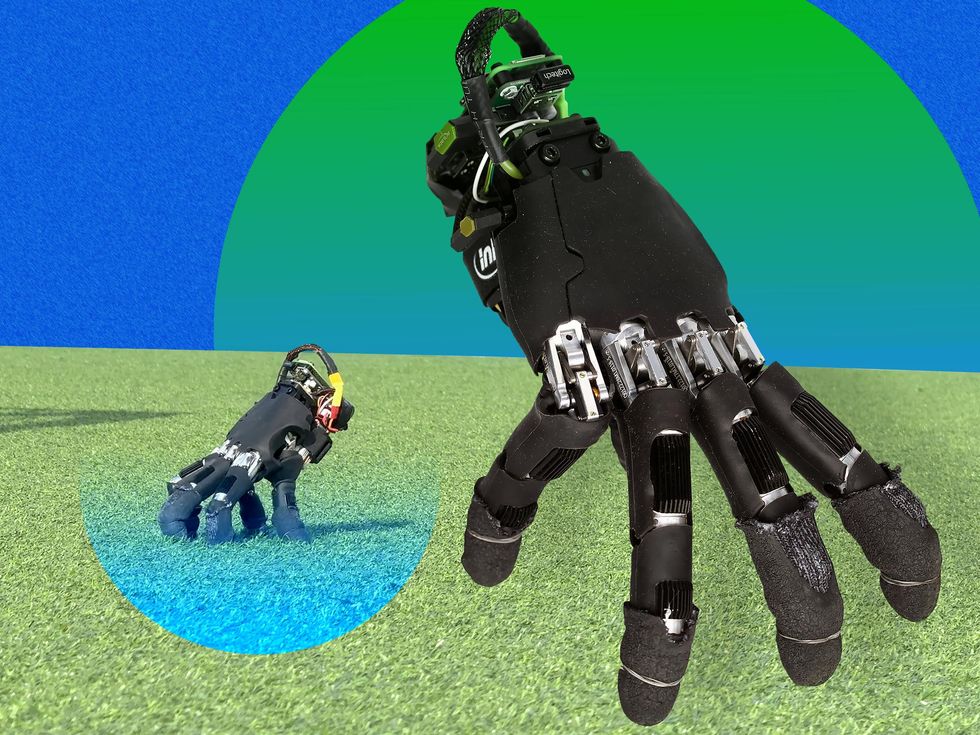
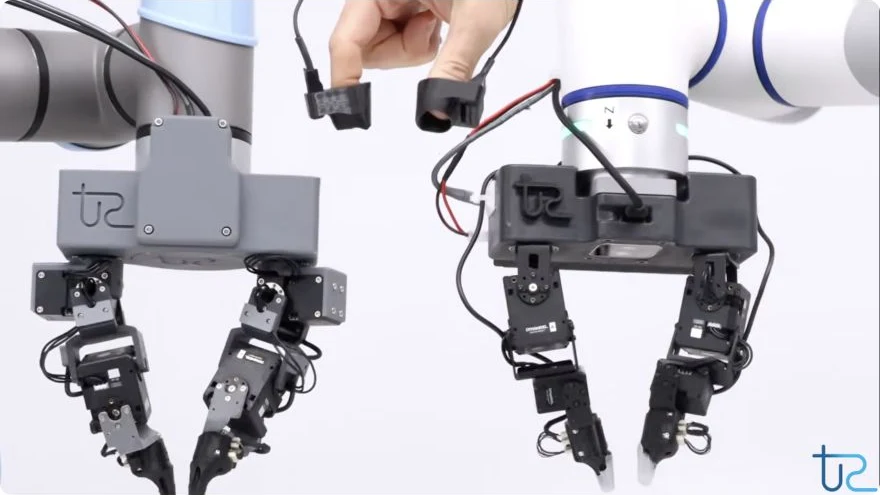
Researchers from ETH Zurich have transformed a standard robotic hand into a self-sufficient robot capable of walking on its fingertips while manipulating objects. This innovation could enhance operations in confined spaces, such as during maintenance tasks or search and rescue missions, where traditional robotic arms may struggle to reach.
The project, led by Ph.D. candidate Amirhossein Kazemipour, utilizes off-the-shelf hardware from Wuji Technology, augmented with a lightweight backpack containing essential components. The hand's unique design allows it to perform tasks beyond traditional robotic capabilities, marking a significant step toward versatile robotics.
Future developments may focus on improving the hand's perception and navigation capabilities for practical applications. Kazemipour envisions a future where robotic parts can dynamically transition between roles, enhancing their utility in various environments and tasks, thus redefining the potential of robotic systems.
Editor's Note
The development of a walking robotic hand by ETH Zurich highlights a shift in robotics towards modular and multifunctional designs. This innovation could significantly impact industries requiring dexterous manipulation in constrained environments, such as maintenance and emergency response. As robotics technology continues to evolve, the integration of versatile components may lead to more adaptable and efficient robotic systems.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.















Leave a comment