

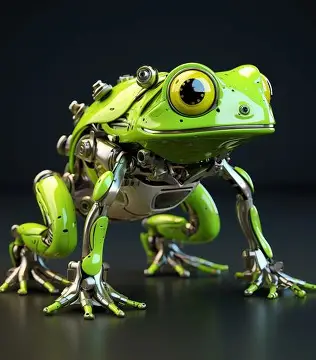
Researchers from UCLA and the University of Michigan have developed a small robot measuring 11 centimeters that utilizes twisted elastic rods to jump. This innovative design allows the robot to store energy through the twisting of the rods and release it suddenly, propelling the robot forward. Weighing 98.2 grams, the robot achieves an average speed of 2.46 body lengths per second across various surfaces, with a peak speed of 3.21 body lengths per second on wood.
The significance of this development lies in its potential applications in challenging terrains. Unlike traditional jumping robots that rely on rigid legs and complex mechanisms, this elastic rod design offers greater adaptability to soft or uneven surfaces. The research indicates that the shape of the elastic rods, rather than their size, determines whether they deform slowly or jump suddenly, suggesting scalability to millimeter-sized robots. This could revolutionize small robot mobility in scenarios such as disaster response and environmental monitoring.
Looking ahead, the research team believes that this design approach could lead to the creation of small robots capable of navigating complex terrains effectively. No further timeline was disclosed at the time of publication.
Editor's Note
The development of this jumping robot highlights a shift in robotics design principles, focusing on adaptability and efficiency. As industries increasingly seek robots that can operate in diverse environments, this research could pave the way for innovative applications in search and rescue operations and environmental assessments. The implications for future robotics technology are significant, particularly in enhancing mobility on challenging surfaces.













Leave a comment