

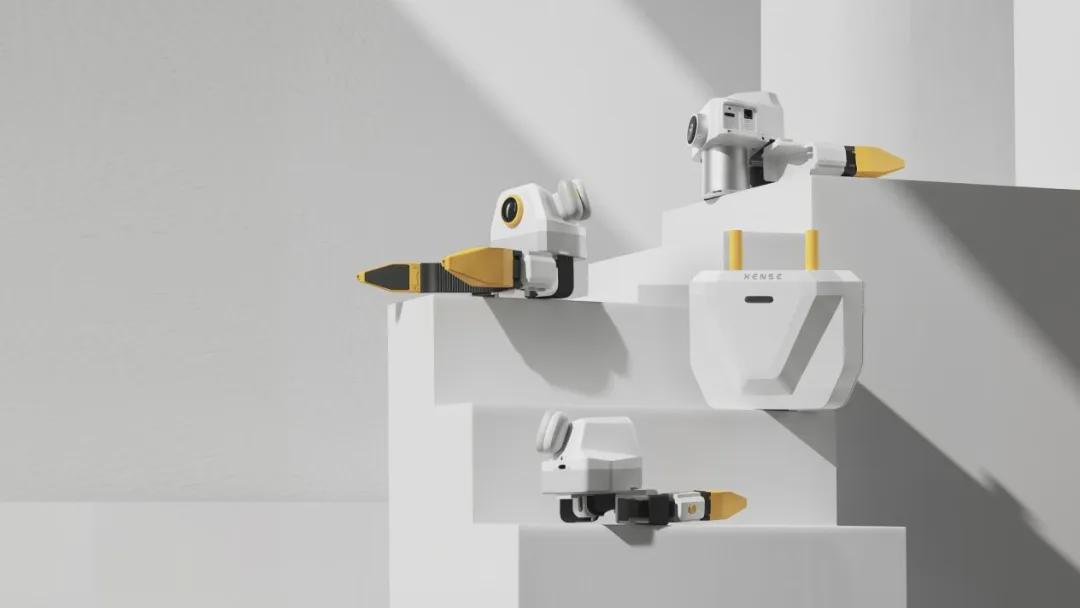
Qianjue Robotics has unveiled the XTac UMI G1, a groundbreaking wearable multi-modal data collection gripper aimed at addressing the challenges of embodied intelligence in robotics. The introduction of this innovative device comes in response to the industry's pressing need for high-quality tactile data, which is essential for training robots to perform complex tasks in real-world environments. By capturing detailed interaction data, the XTac UMI G1 seeks to bridge the existing gap between visual data and physical interaction, thereby enhancing the capabilities of robots. This development marks a significant step forward in improving robotic performance and adaptability in various applications.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.









Leave a comment