


Robot Hand Develops Agile Movements to Minimize Object Drops
- Published
- Source
- TechXplore:Robotics
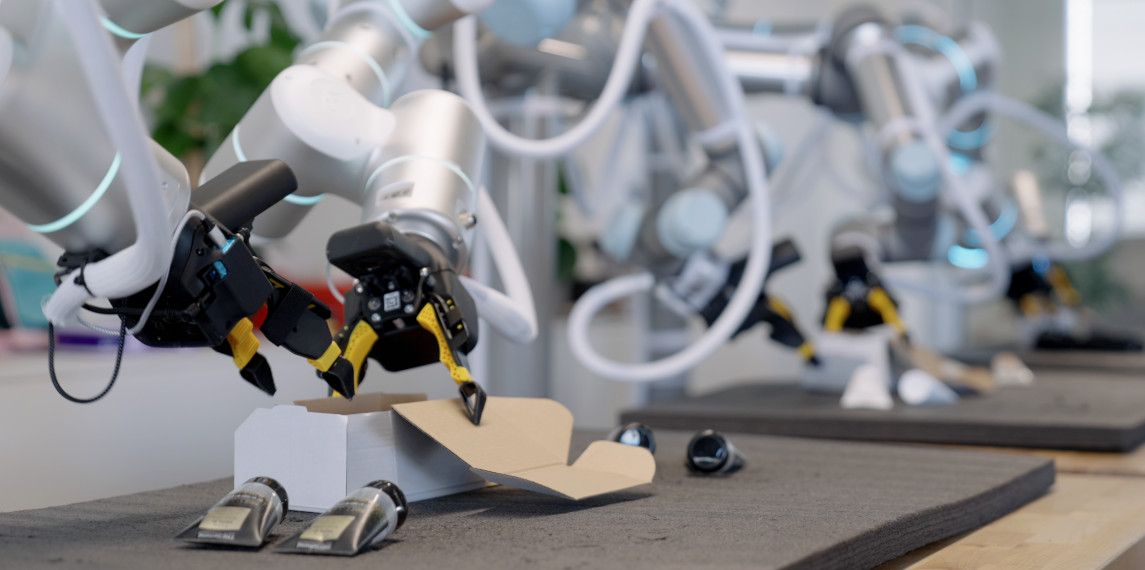
A new robotic hand has been designed to manipulate objects with improved dexterity. This advancement allows the hand to release and re-establish its grip effectively while preventing objects from slipping, even when the palm is oriented downwards.
This innovation is significant as it enhances the capabilities of robotic systems in handling delicate or varying objects, which is crucial for applications in industries such as logistics and manufacturing. Improved dexterity can lead to more efficient operations and reduced loss of items during handling.
The robotic hand's ability to learn and adapt its movements is a key milestone in robotics. Future developments may focus on further refining these skills to handle a broader range of objects and tasks, although no specific timeline was disclosed at the time of publication.
Original report
Robot hand learns nimble moves with fewer dropped objects
TechXplore:RoboticsThis briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? Contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.
More related news
- 1
- 2
- 3
- 4
- 5
-
6
FAIR plus 2027 – Shenzhen, Apr 21–23, 2027 RobotToday · 6 days ago
- 7
-
8
RobotToday Weekly October 26 – 30, 2026 RobotToday · 1 week ago
- 9
- 10
- 11
- 12
Related Suppliers

The Shadow Robot Company
United Kingdom
London, UK maker of dexterous robot hands and teleoperation systems; the Shadow Dexterous Hand offers 20 actuated DOF, 24 joints and over 100 sensors at 1 kHz.
HAND ERC (Human AugmentatioN via Dexterity Engineering Research Center)
United States
NSF Engineering Research Center developing versatile dexterous robot hands with AI-powered manipulation skills and human interfaces.
Generalist AI
United States
Frontier AI research company building embodied foundation models for general-purpose robots, with GEN-1 achieving 99% task success rates.
Beijing Surgerii Robotics 北京术锐机器人股份有限公司
China
Chinese medical robotics company developing the SHURUI single-port surgical robot with flexible snake-like instruments for minimally invasive surgery.

Vathos GmbH
Germany
AI-powered 3D vision software for robot bin picking and depalletizing; TUM spin-out using deep learning for unstructured object handling.
Sber Robotics Center
Russian Federation
Sberbank's robotics unit building the GREEN humanoid (180 cm, 41 DOF) and WORKER semi-humanoid, controlled by its Green-VLA model.
Daewoo E&C 大宇建设
Korea, Republic of (South)
Major South Korean construction conglomerate founded 1973, integrating construction robotics and wearable exoskeletons for worker safety at job sites.
ATS Industrial Automation
Canada
Automation and assembly systems integrator (part of ATS Corporation) building test and assembly platforms for eMobility, energy storage and nuclear markets.
CasiaHand Robotics Co., Ltd. 中科硅纪(南京)机器人有限公司
China
CAS Institute of Automation spin-off in Nanjing building the Casia Hand series of tendon- and direct-drive dexterous robot hands and embodied control models

University of Auckland — Centre for Automation and Robotic Engineering Science (CARES)
New Zealand
Auckland, New Zealand university robotics centre directed by Bruce MacDonald; researches human-robot interaction, sensing, and agricultural robots.
Dexterity Inc.
United States
Redwood City AI robotics company deploying Physical AI-powered robots for warehouse truck loading, palletizing, and logistics.
Applied Dexterity
United States
Open-platform surgical robotics research company developing the Raven telesurgical robot system.
Robotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.


