

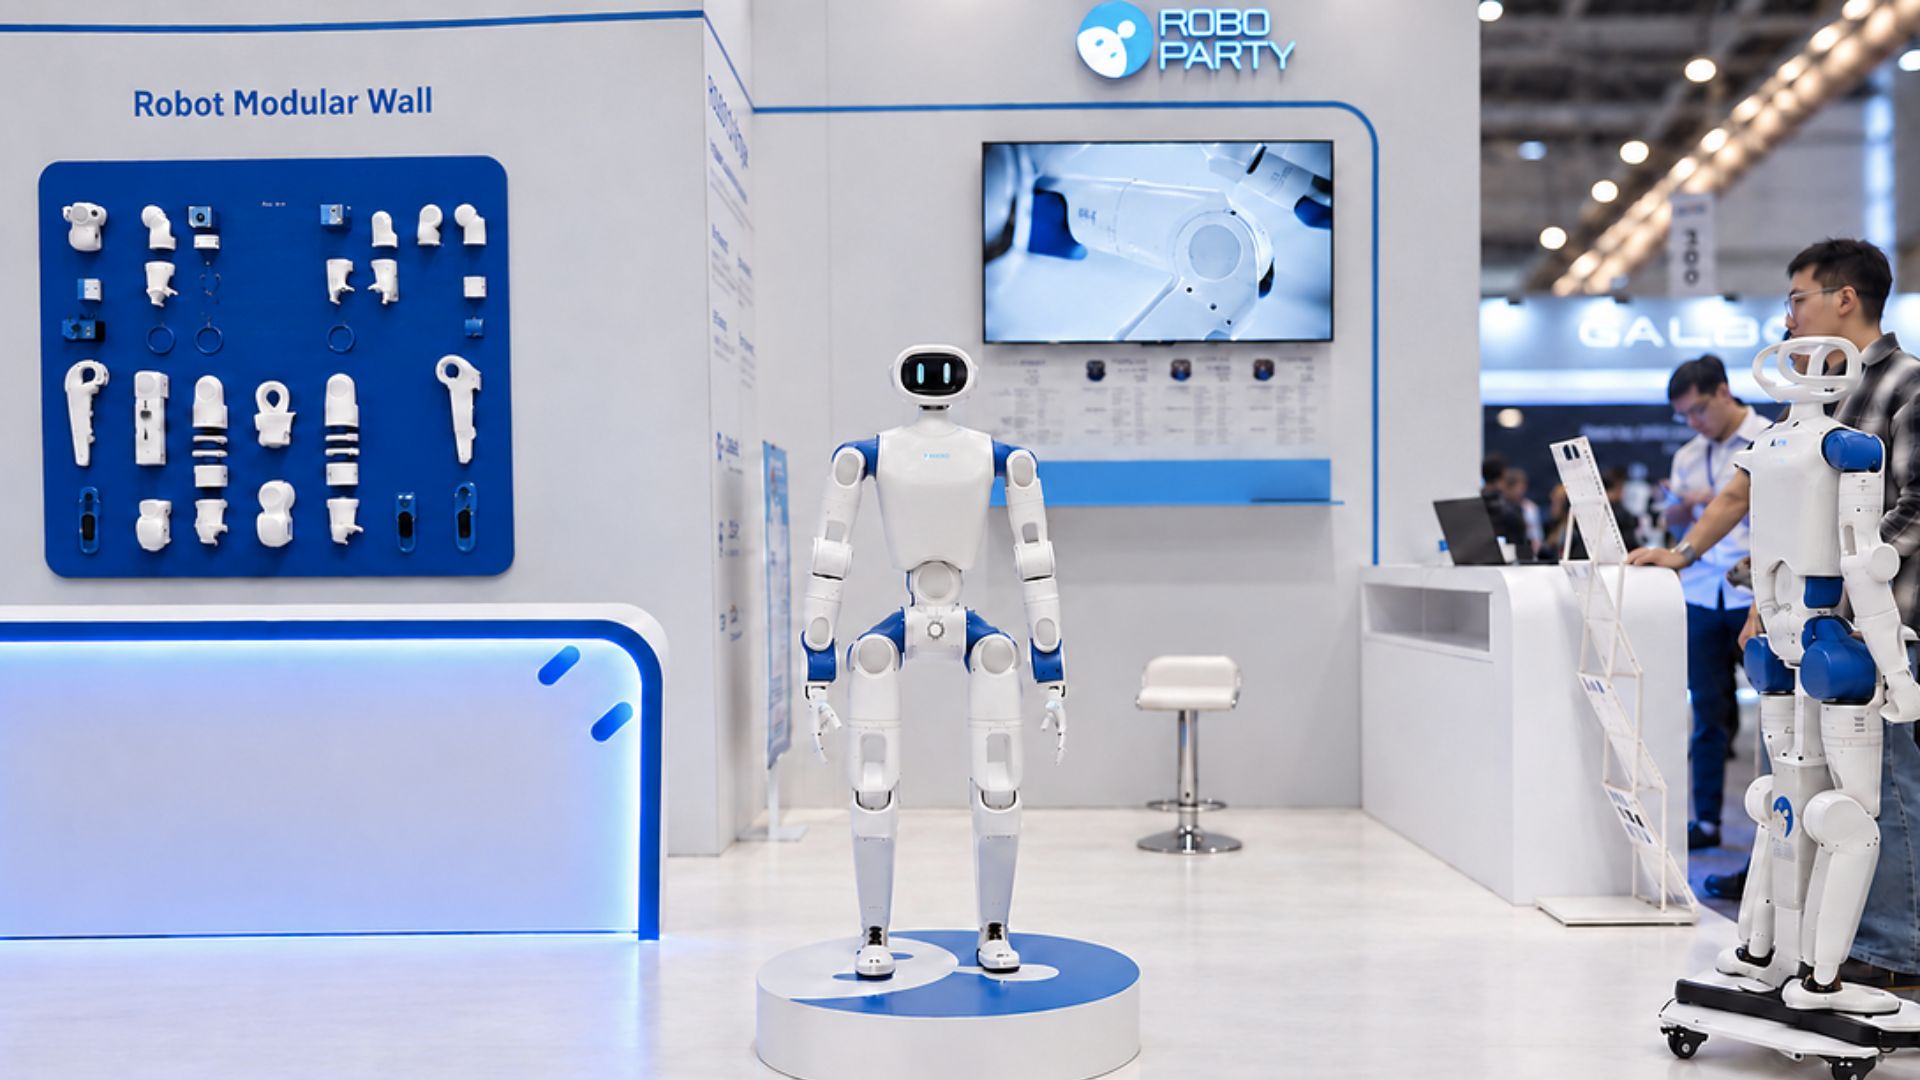
RoboParty, a firm based in Pittsburgh, has introduced RP1 (ROBOTO 01), the world's first high-performance full-stack open-source bipedal humanoid robot, at IROS 2026. This robot aims to serve researchers, educators, and robotics developers by providing a customizable humanoid system that can be modified and trained in real development workflows.
The significance of RP1 lies in its open-source nature, allowing a broader range of developers to engage with humanoid robotics. Founder Yi Huang emphasized the importance of accessibility in robotics, stating that the goal is to create an open foundation for continuous improvement and innovation. The robot's capabilities were showcased through an interactive demonstration, where visitors could test its dynamic stability and control performance by applying external disturbances.
Looking ahead, RoboParty plans to further develop RP1 as part of its full-stack open-source roadmap, which began with the RPO project. The robot features impressive specifications, including a peak joint torque of 160 N•m, and is designed for dynamic motion and embodied AI model training. No further timeline was disclosed at the time of publication.
Editor's Note
The introduction of RP1 marks a significant step in the evolution of humanoid robotics, emphasizing open-source development and community engagement. This approach could reshape the competitive landscape by enabling more developers to contribute to and innovate within the field. As the demand for advanced robotics solutions grows, the accessibility of platforms like RP1 may accelerate adoption and experimentation in various applications.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.










Leave a comment