


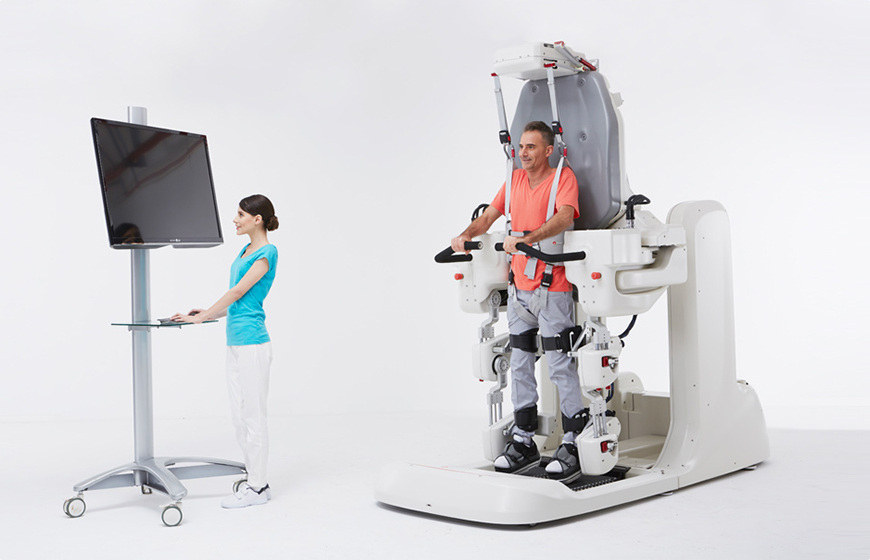
The article discusses the kinematics analysis and performance optimization of a multimode reconfigurable parallel ankle-rehabilitation mechanism. This mechanism is designed to enhance rehabilitation processes for patients recovering from ankle injuries.
Understanding the kinematics and optimizing the performance of such mechanisms is crucial for improving rehabilitation outcomes. The study highlights the importance of reconfigurability, which allows the mechanism to adapt to various rehabilitation needs, thereby increasing its effectiveness.
Future research may focus on further refining the mechanism's design and exploring its application in different rehabilitation scenarios. No further timeline was disclosed at the time of publication.
Editor's Note
The development of advanced rehabilitation mechanisms is pivotal in enhancing patient recovery processes. As the demand for personalized rehabilitation solutions grows, the focus on kinematics and performance optimization becomes increasingly relevant for healthcare providers and technology developers alike.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.















Leave a comment