

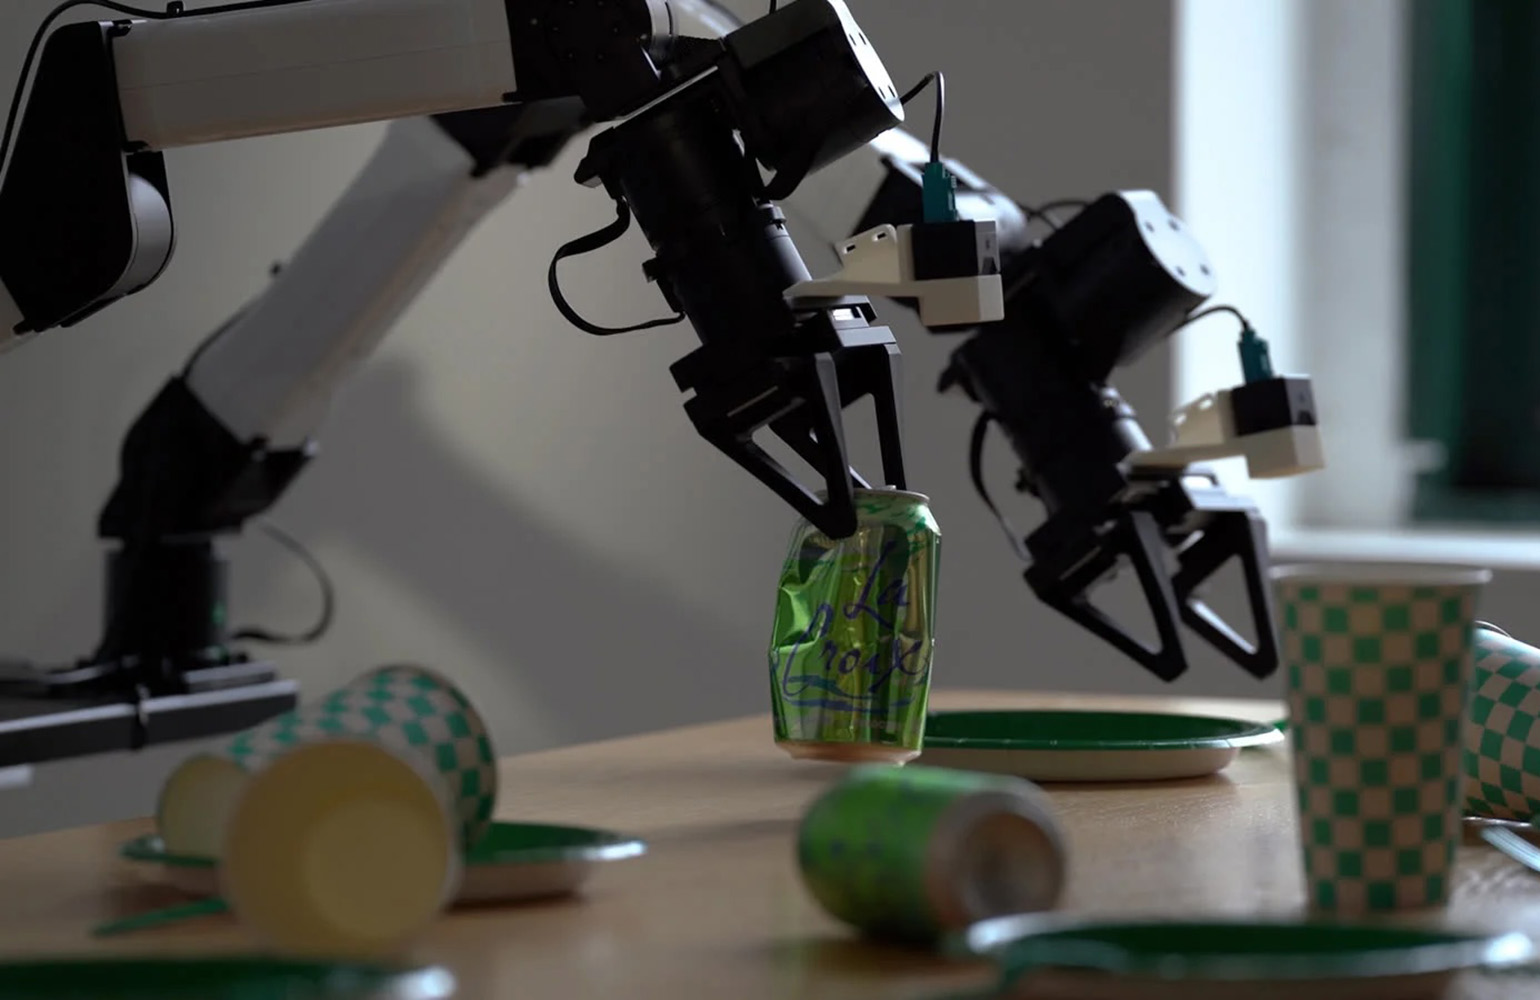
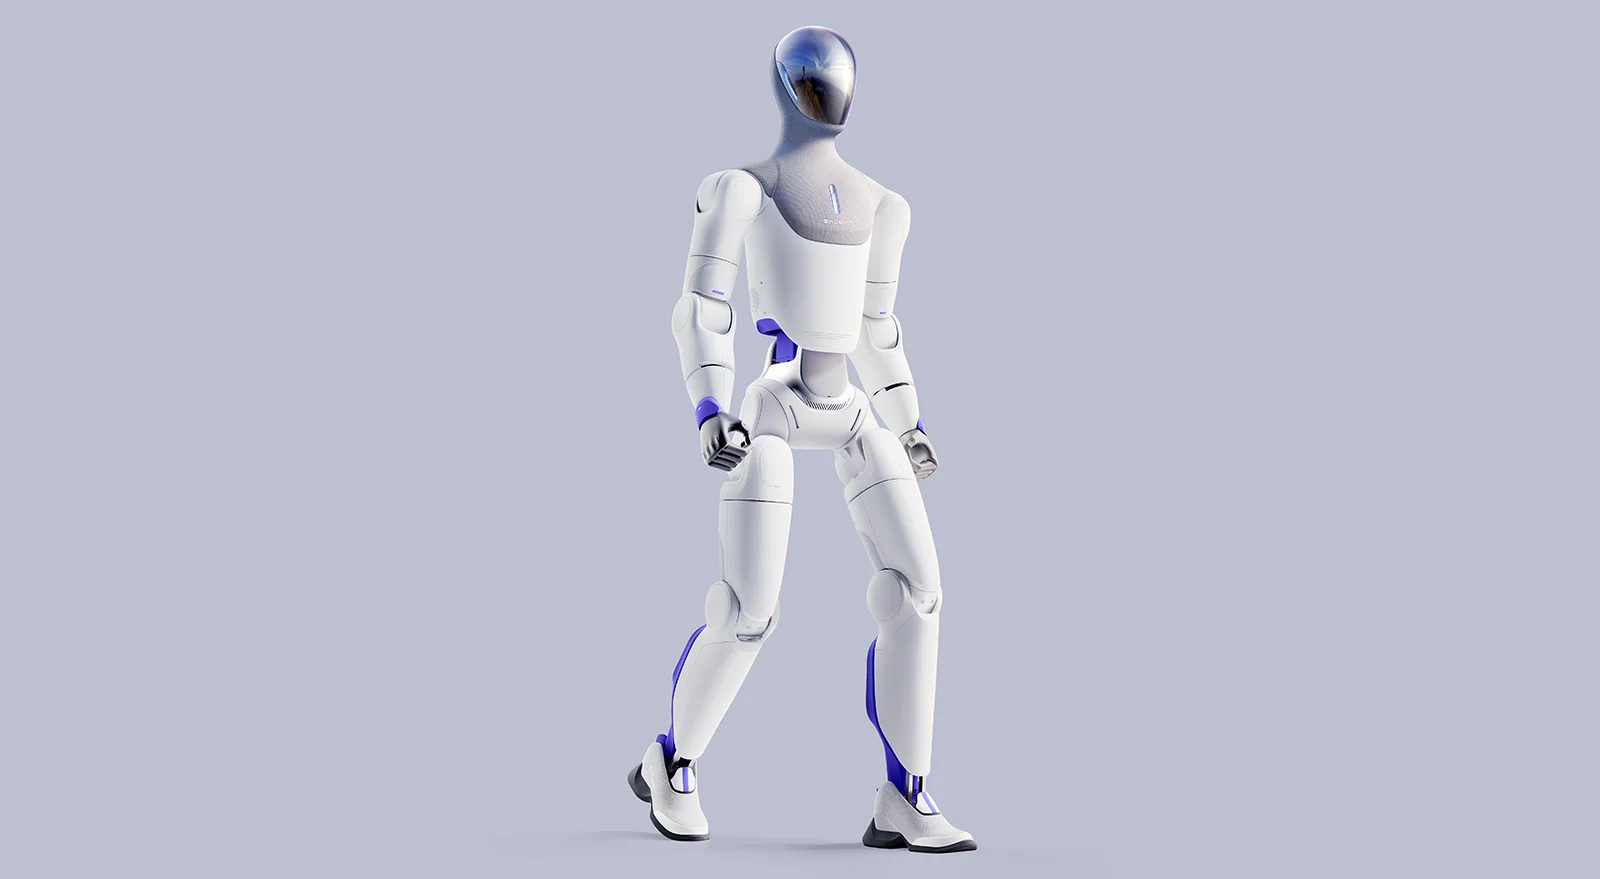
Runway AI Inc. has introduced Praxis-1, an open-weight world action model designed to enhance robotic control through video pretraining. The company is currently testing Praxis-1 across various embodiments and environments to identify and address potential gaps before its general release.
The significance of Praxis-1 lies in its ability to learn primarily from third-person video, which alleviates the challenges associated with the scarcity and cost of robot data collection. According to Kamil Sindi, Runway's CTO, the model's performance improves with increased video input, allowing it to understand object behavior and task execution without relying heavily on robot demonstrations.
Looking ahead, Runway plans to publicly release Praxis-1 in the coming months after thorough testing with early partners. The model aims to provide a versatile policy framework for robotics developers and researchers, capable of functioning across diverse environments and embodiments, thereby addressing the current limitations in robotics training data.
Editor's Note
The introduction of Praxis-1 by Runway AI highlights a significant shift in how robotics can leverage abundant video data for training generalist AI models. This approach could reshape the competitive landscape by reducing reliance on expensive and limited robot demonstration data, making advanced robotics more accessible to developers and researchers.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.










Leave a comment