

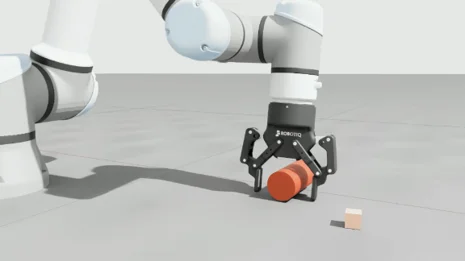
Robotiq has launched three open-source software packages aimed at enhancing its adaptive grippers. These releases include a C++ SDK, an official ROS 2 package, and updated NVIDIA Isaac Sim assets, all designed to facilitate the training of manipulation models on Robotiq components and their deployment on real robots.
This initiative is significant as it represents the first components of Robotiq's physical AI software layer, which is intended to streamline the integration of AI in robotic manipulation tasks. By providing these tools, Robotiq aims to empower developers and engineers to create more effective and efficient robotic solutions.
Looking ahead, Robotiq's commitment to maintaining and optimizing these software packages suggests ongoing support for the developer community. No further timeline was disclosed at the time of publication.
Editor's Note
The release of open-source software by Robotiq highlights a growing trend in the robotics industry towards collaborative development and accessibility. This move not only enhances the capabilities of their products but also fosters innovation within the robotics community, potentially leading to more advanced applications in automation and AI integration.




















Leave a comment