

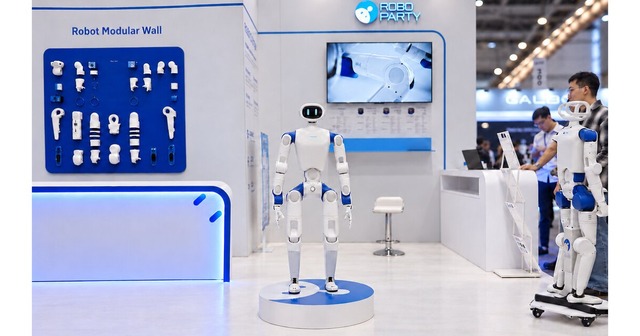
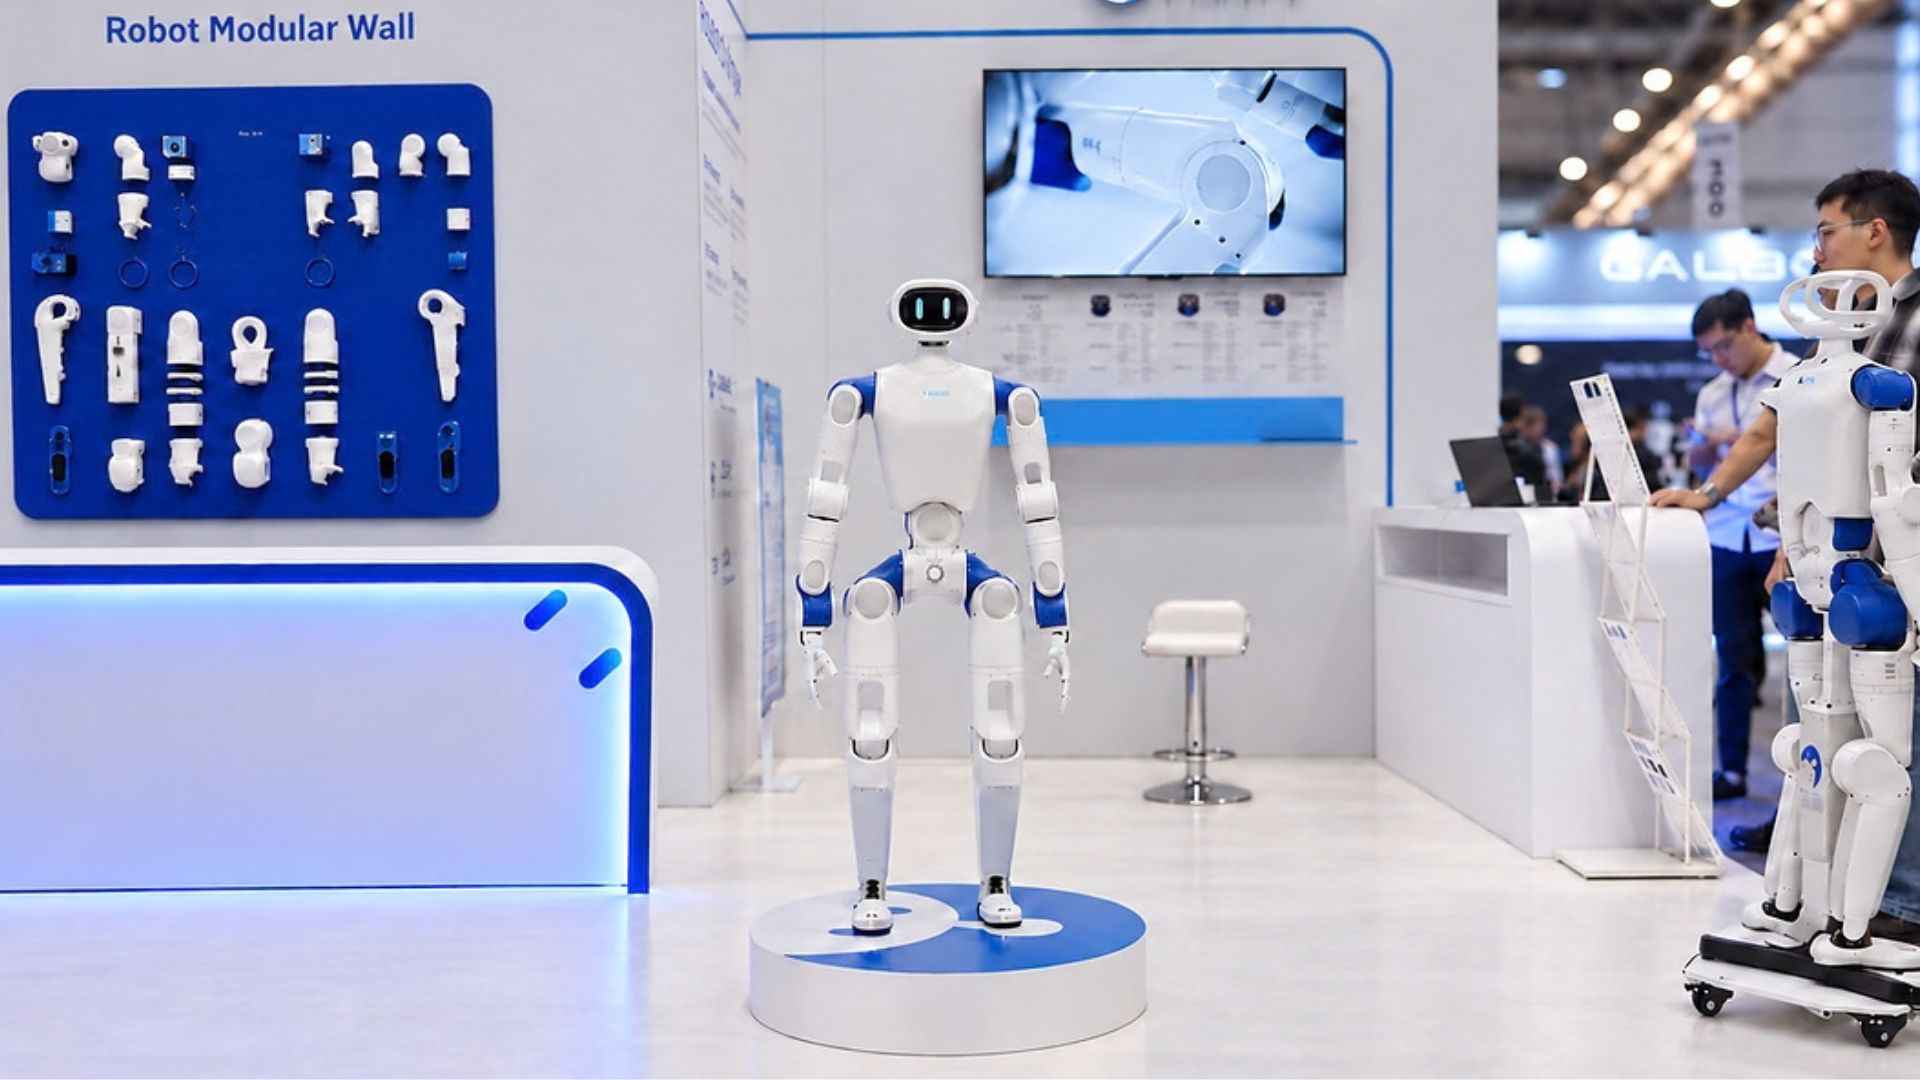
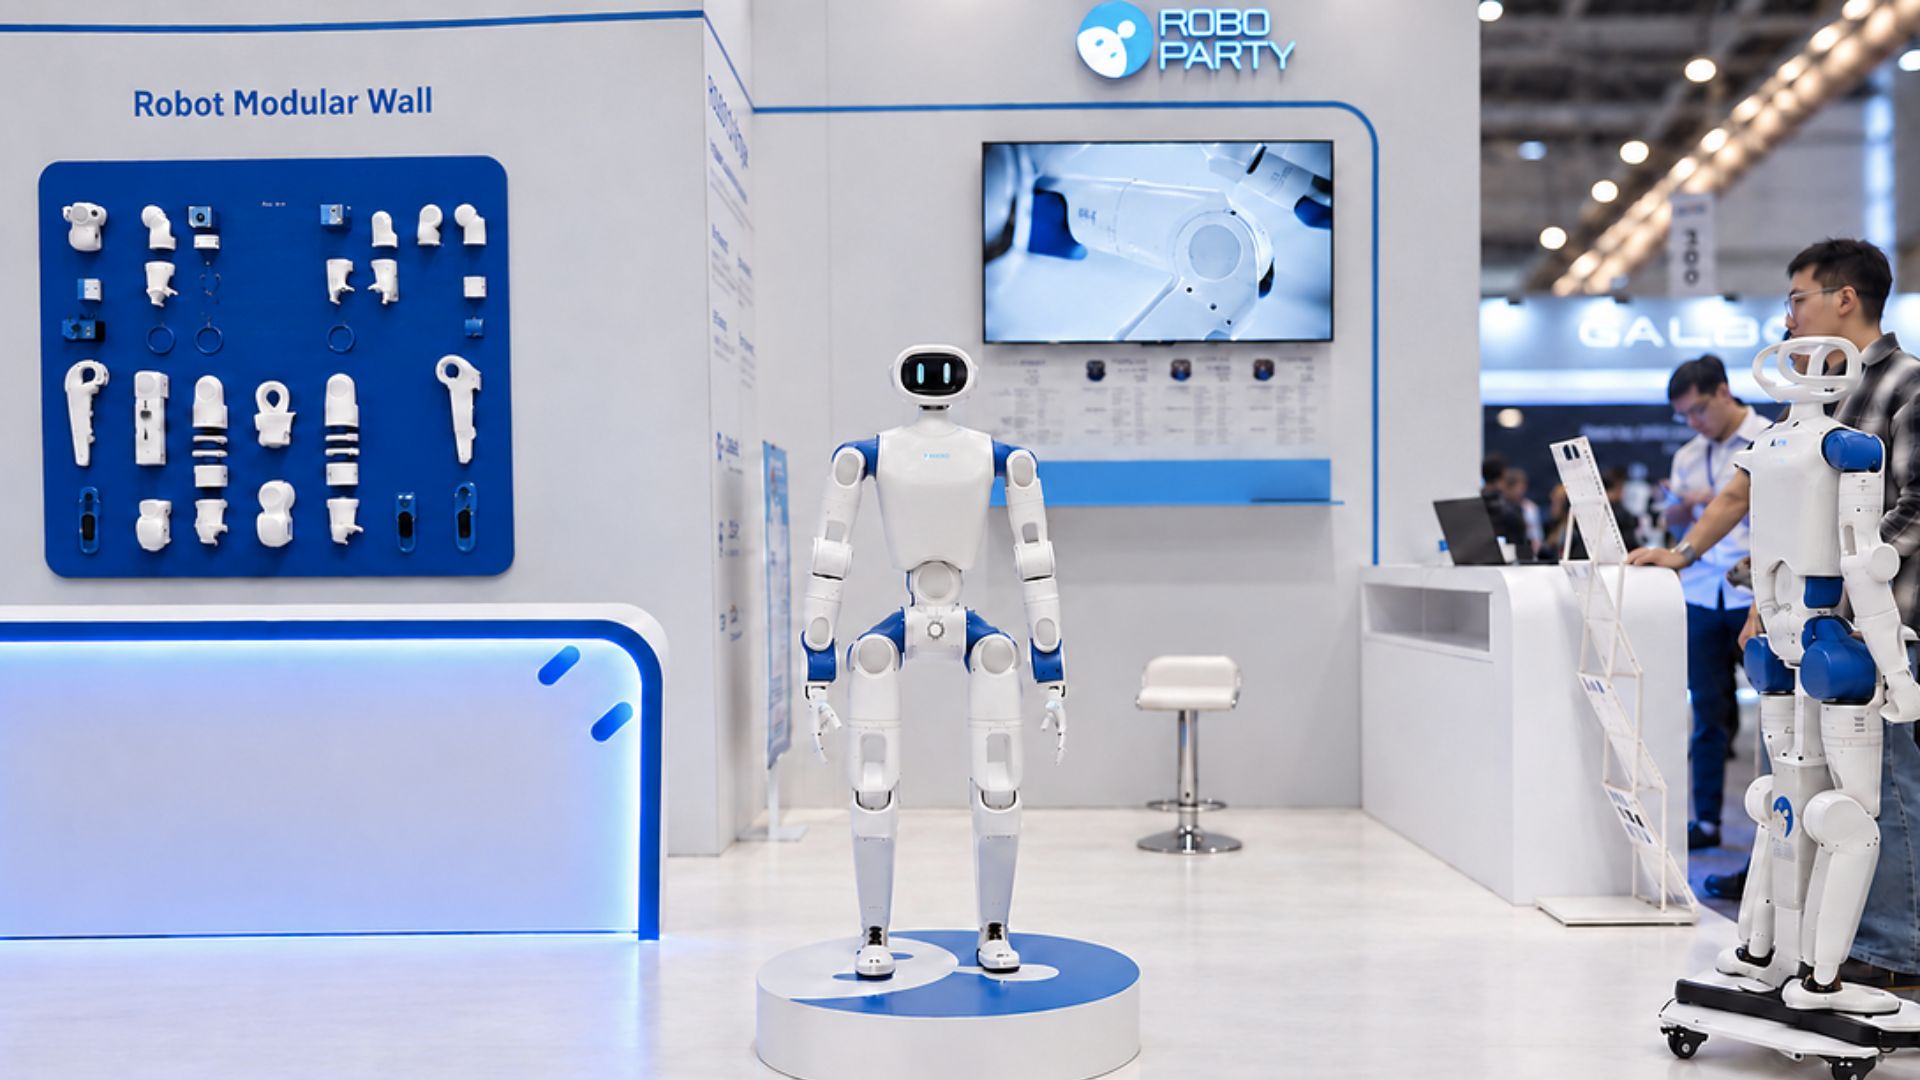
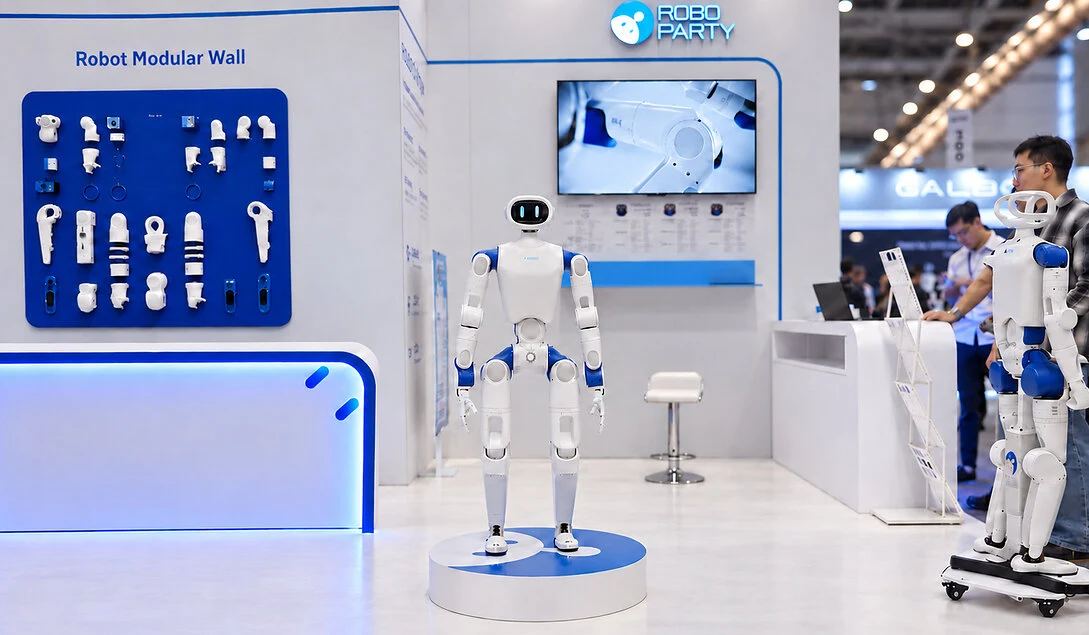
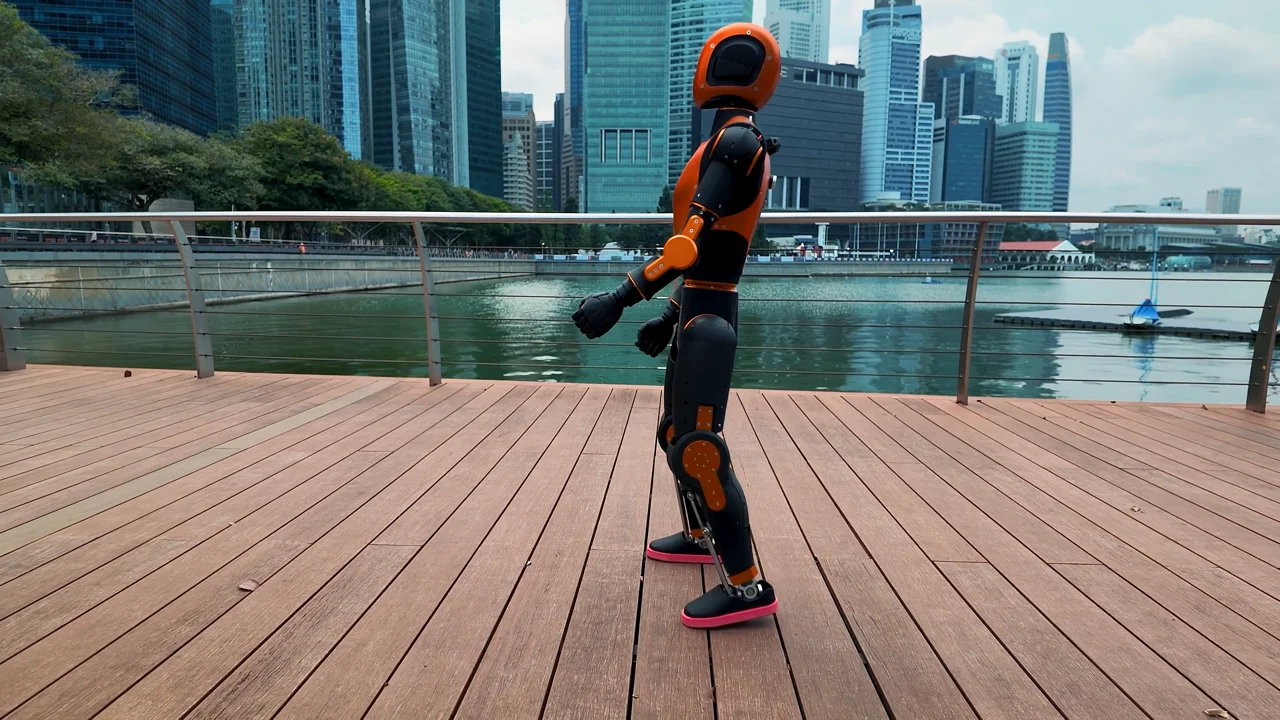
On September 28, 2026, RoboParty introduced the humanoid robot RP1 (ROBOTO 01) at IROS 2026. The company positions RP1 as a high-performance, full-stack open-source bipedal humanoid robot aimed at researchers, educators, and developers, allowing them to use, modify, and expand the system in real-world applications.
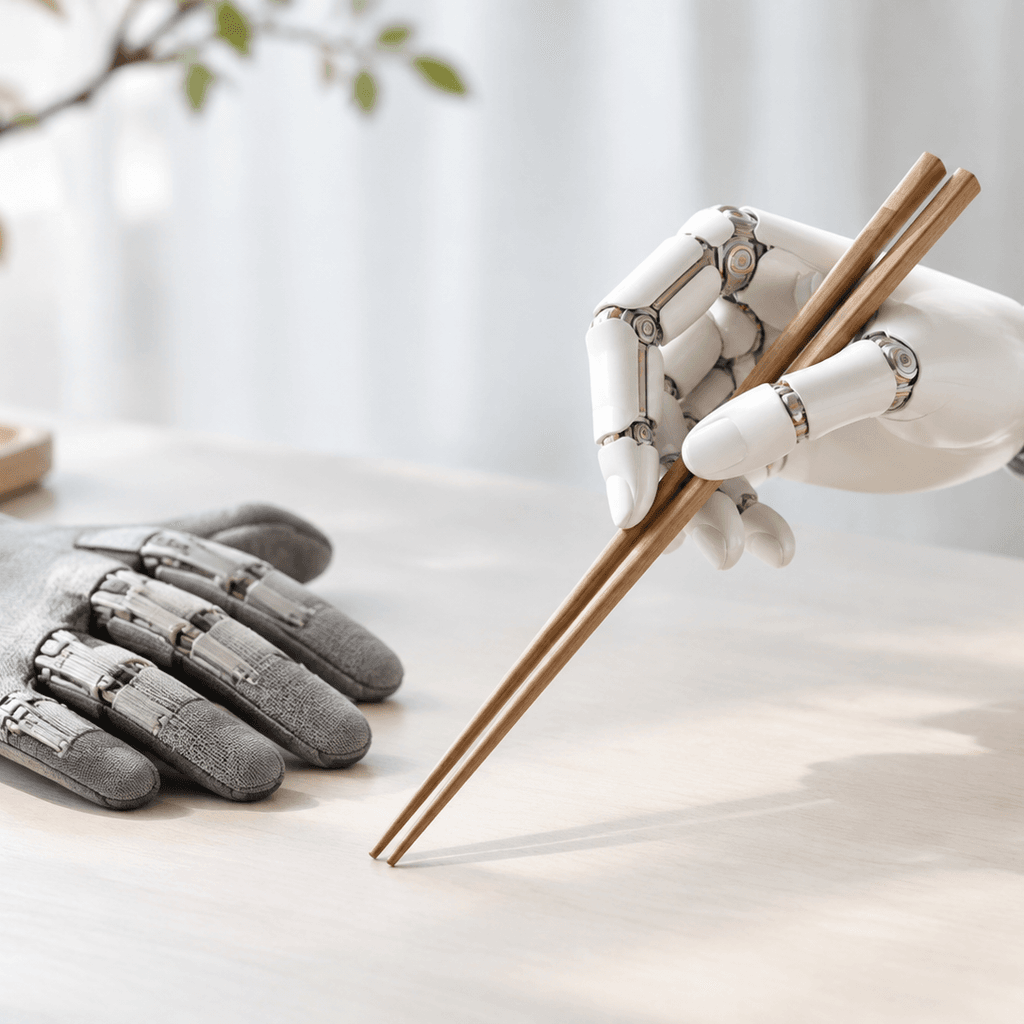
This initiative builds on the foundation laid by RoboParty's earlier project, RPO (ROBOTO ORIGIN), which garnered significant interest and over 2,500 stars on GitHub. RP1 integrates the company's proprietary actuator module, Romomo, and a dexterous robot hand, RP Hand, alongside the development platform PartyOS, enhancing the robot's capabilities for dynamic stability and interaction.
During the event, attendees experienced an interactive demo called "Kick Me," showcasing RP1's ability to quickly regain balance after being pushed or kicked. This demonstration highlighted the robot's robust performance and the collaborative functionality of its actuator module and control systems, supported by the PartyOS framework, which incorporates unsupervised reinforcement learning for humanoid control. No further timeline was disclosed at the time of publication.
Editor's Note
The introduction of RP1 represents a significant advancement in open-source robotics, enabling deeper engagement from developers and researchers. By providing a comprehensive platform that includes hardware and software components, RoboParty is fostering innovation in humanoid robot development. This approach may shift the competitive landscape by encouraging collaboration and knowledge sharing in the robotics community.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.











Leave a comment