

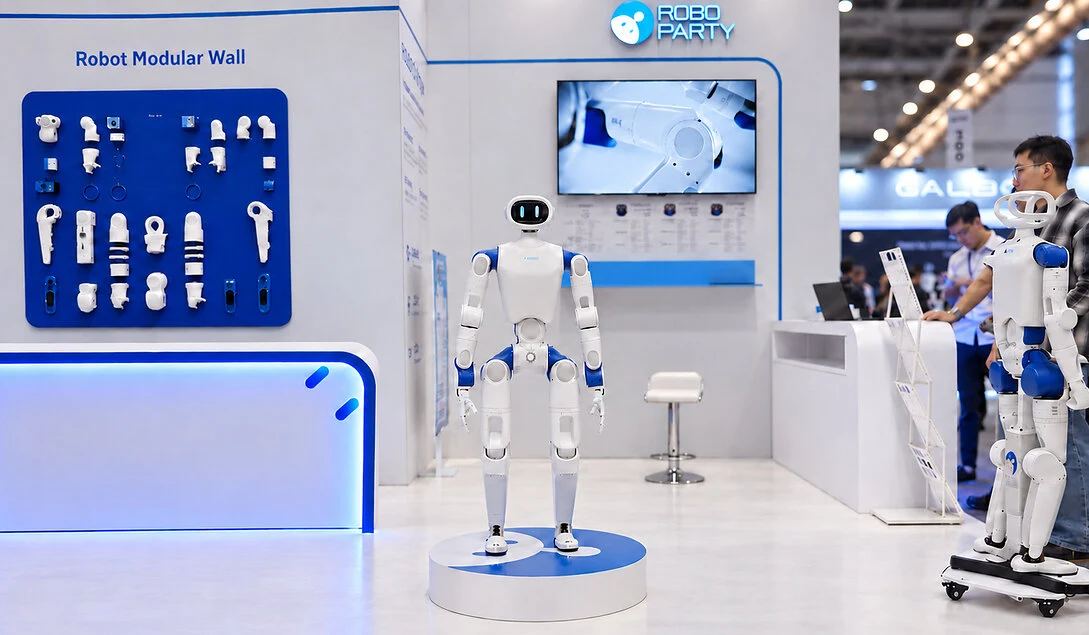
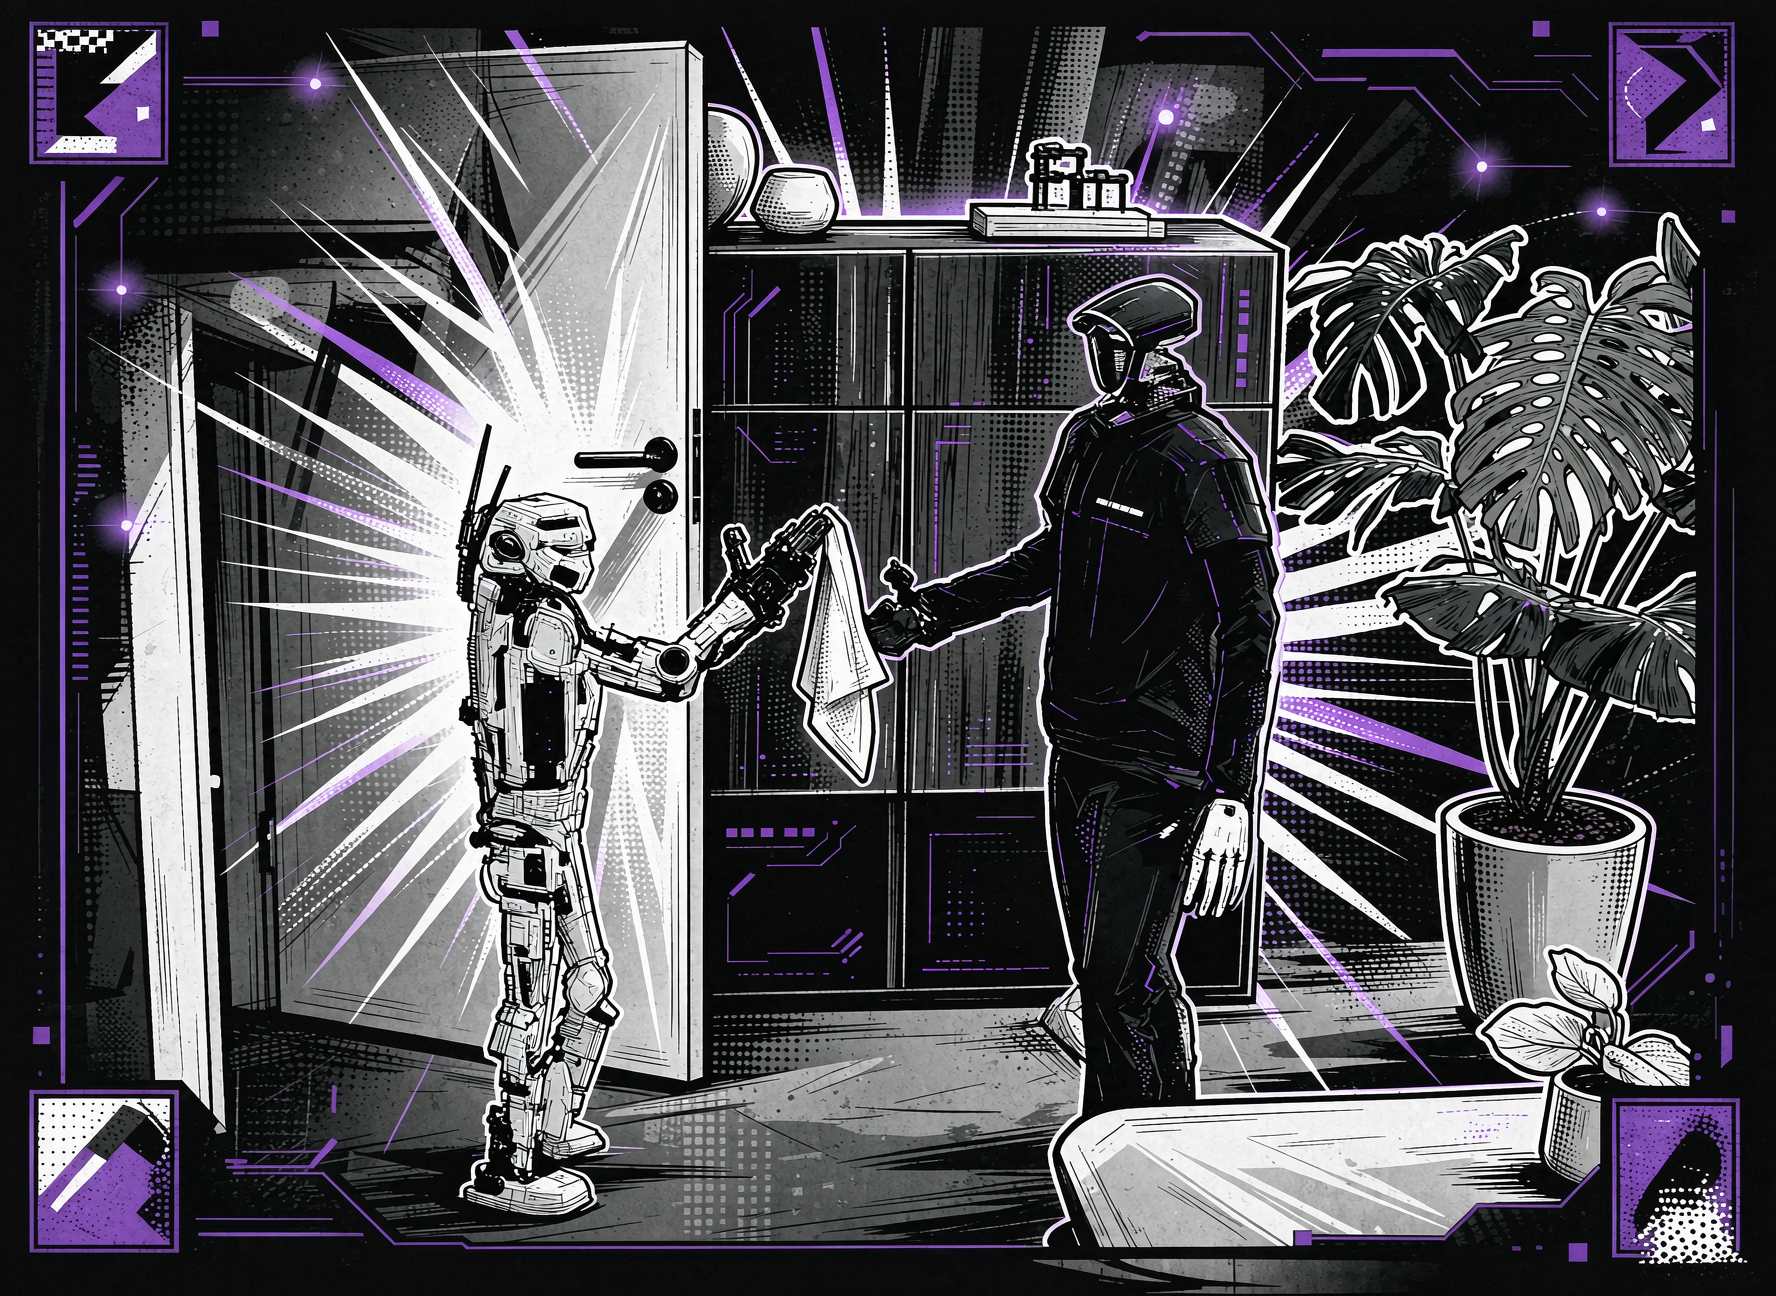
RoboParty has introduced the RP1 (ROBOTO 01), a bipedal humanoid robot designed for robotics researchers and developers, during its debut at IROS in Pittsburgh on September 28. The company announced on October 3 that the RP1 showcased its balance capabilities through an interactive demonstration where it adjusted its posture after being pushed and kicked by visitors.
The significance of the RP1 lies in its advanced motion capabilities, attributed to PartyOS, which utilizes the UFO unsupervised reinforcement-learning framework and Romomo actuators. RoboParty plans to release a range of hardware and software resources, including motion control, simulation environments, and SDKs, with more details expected in October. A mass-production program is also anticipated later in Q4, although pricing details remain undisclosed.
Looking ahead, the success of the RP1 will depend on whether external teams can replicate its capabilities using the provided designs and training resources. This would enhance the platform's utility for researchers, allowing them to inspect and modify a shared system beyond the exhibition context. No further timeline was disclosed at the time of publication.
Editor's Note
The introduction of the RP1 by RoboParty highlights a growing trend in the robotics industry towards open-source development. By providing access to hardware and software resources, RoboParty aims to foster collaboration among researchers and developers, potentially accelerating innovation in humanoid robotics. The emphasis on reproducibility will be crucial for establishing the RP1 as a valuable tool in academic and industrial settings.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.










Leave a comment