

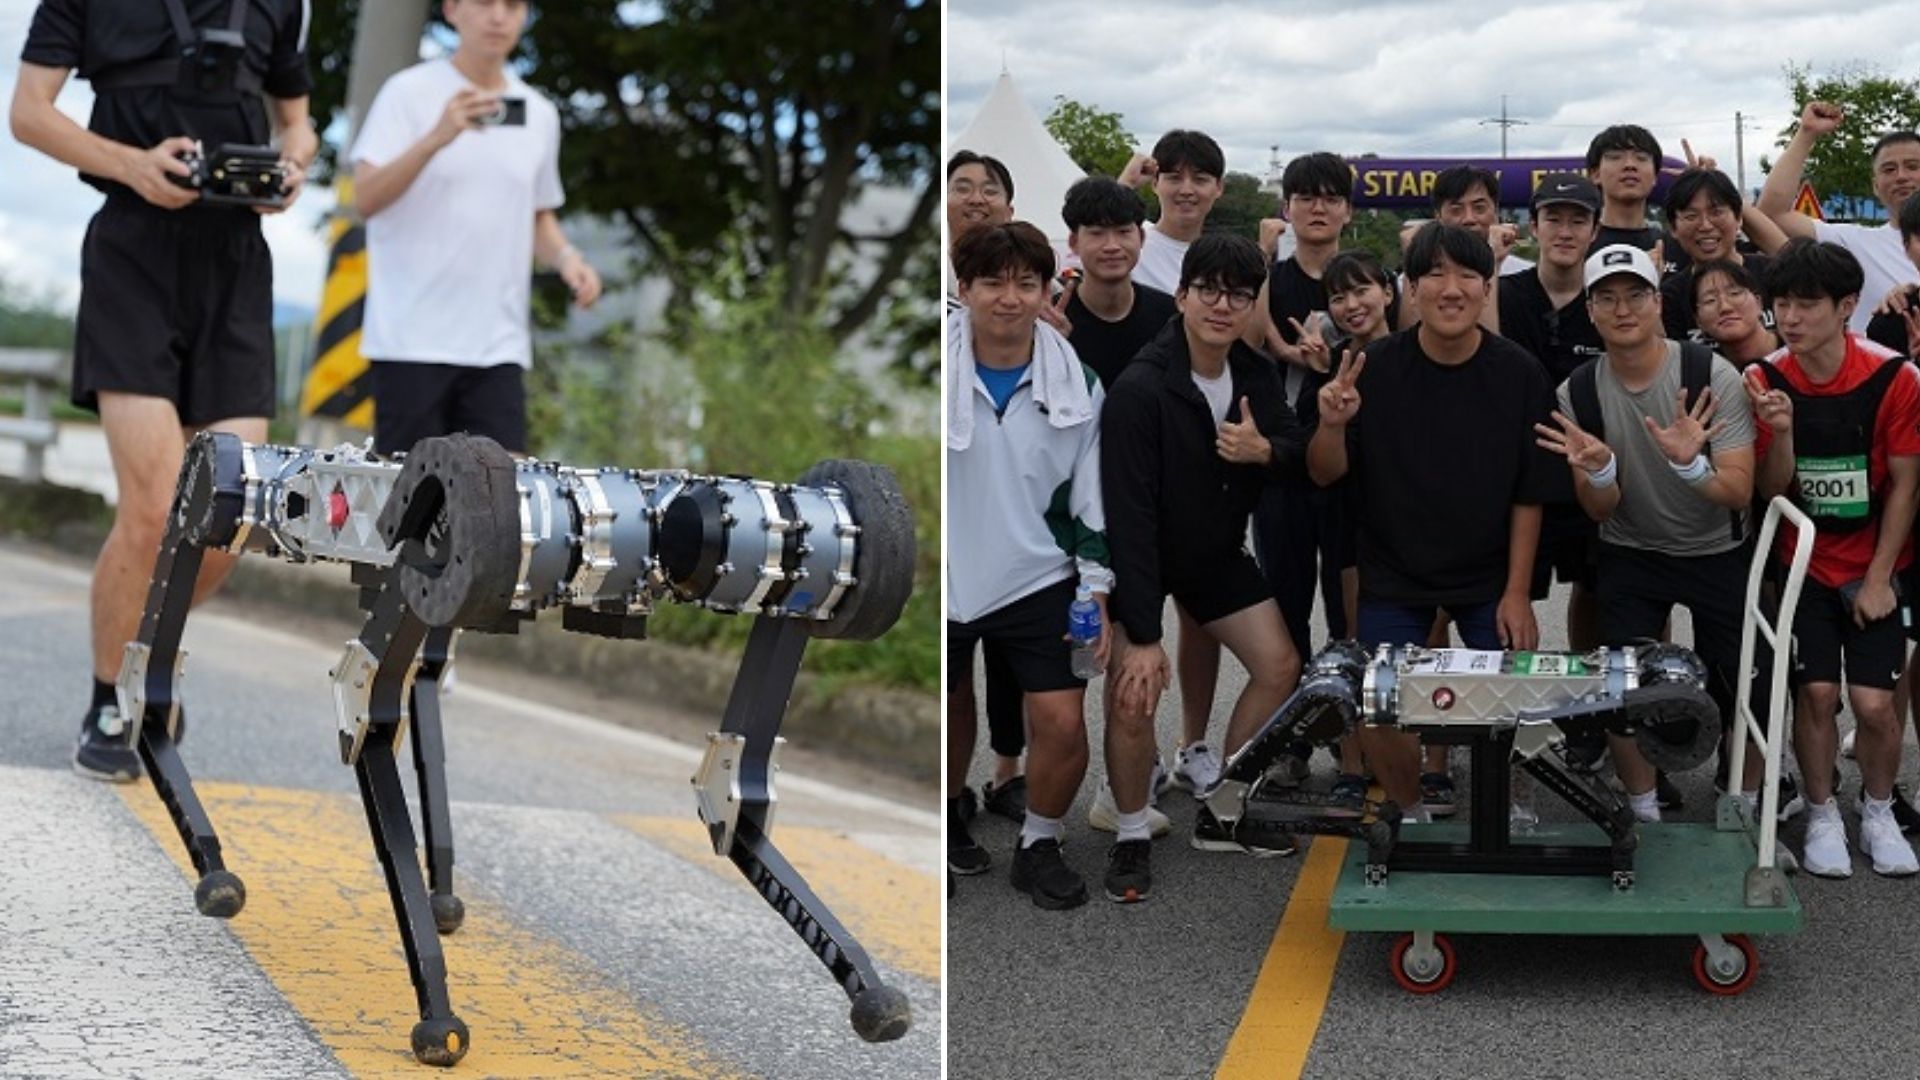
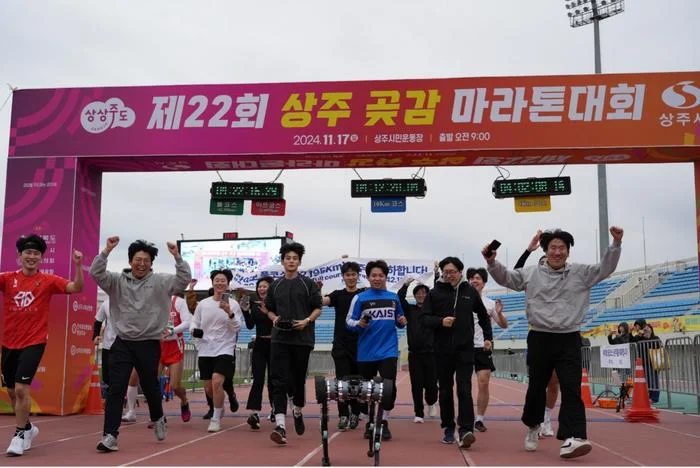
KAIST's quadruped robot, RAIBO2, successfully completed a marathon distance of 42.195 kilometers in 4 hours, 19 minutes, and 52 seconds on a single battery charge. This achievement occurred during the 2024 Sangju Dried-Persimmon Marathon, showcasing significant advancements in robotic endurance and energy efficiency.
The completion of the marathon is a pivotal milestone in addressing the endurance limitations of legged robots, which traditionally struggle with energy consumption due to their need to support their weight and manage impacts. RAIBO2 maintained an average speed of 2.64 meters per second while consuming less energy than a human, achieving a cost of transport (COT) of 0.25 compared to the human benchmark of 0.37.
Looking ahead, the research team at KAIST, which previously faced challenges with battery life in earlier versions of the robot, has refined RAIBO2's design and locomotion strategies. Future developments may focus on further enhancing energy efficiency and exploring additional applications for quadruped robots in various environments. No further timeline was disclosed at the time of publication.
Editor's Note
The successful marathon completion by KAIST's RAIBO2 highlights the growing capabilities of quadruped robots in endurance and energy efficiency. This advancement could influence future designs in robotics, particularly in applications requiring sustained mobility and efficiency, such as search and rescue operations or outdoor exploration.















Leave a comment