

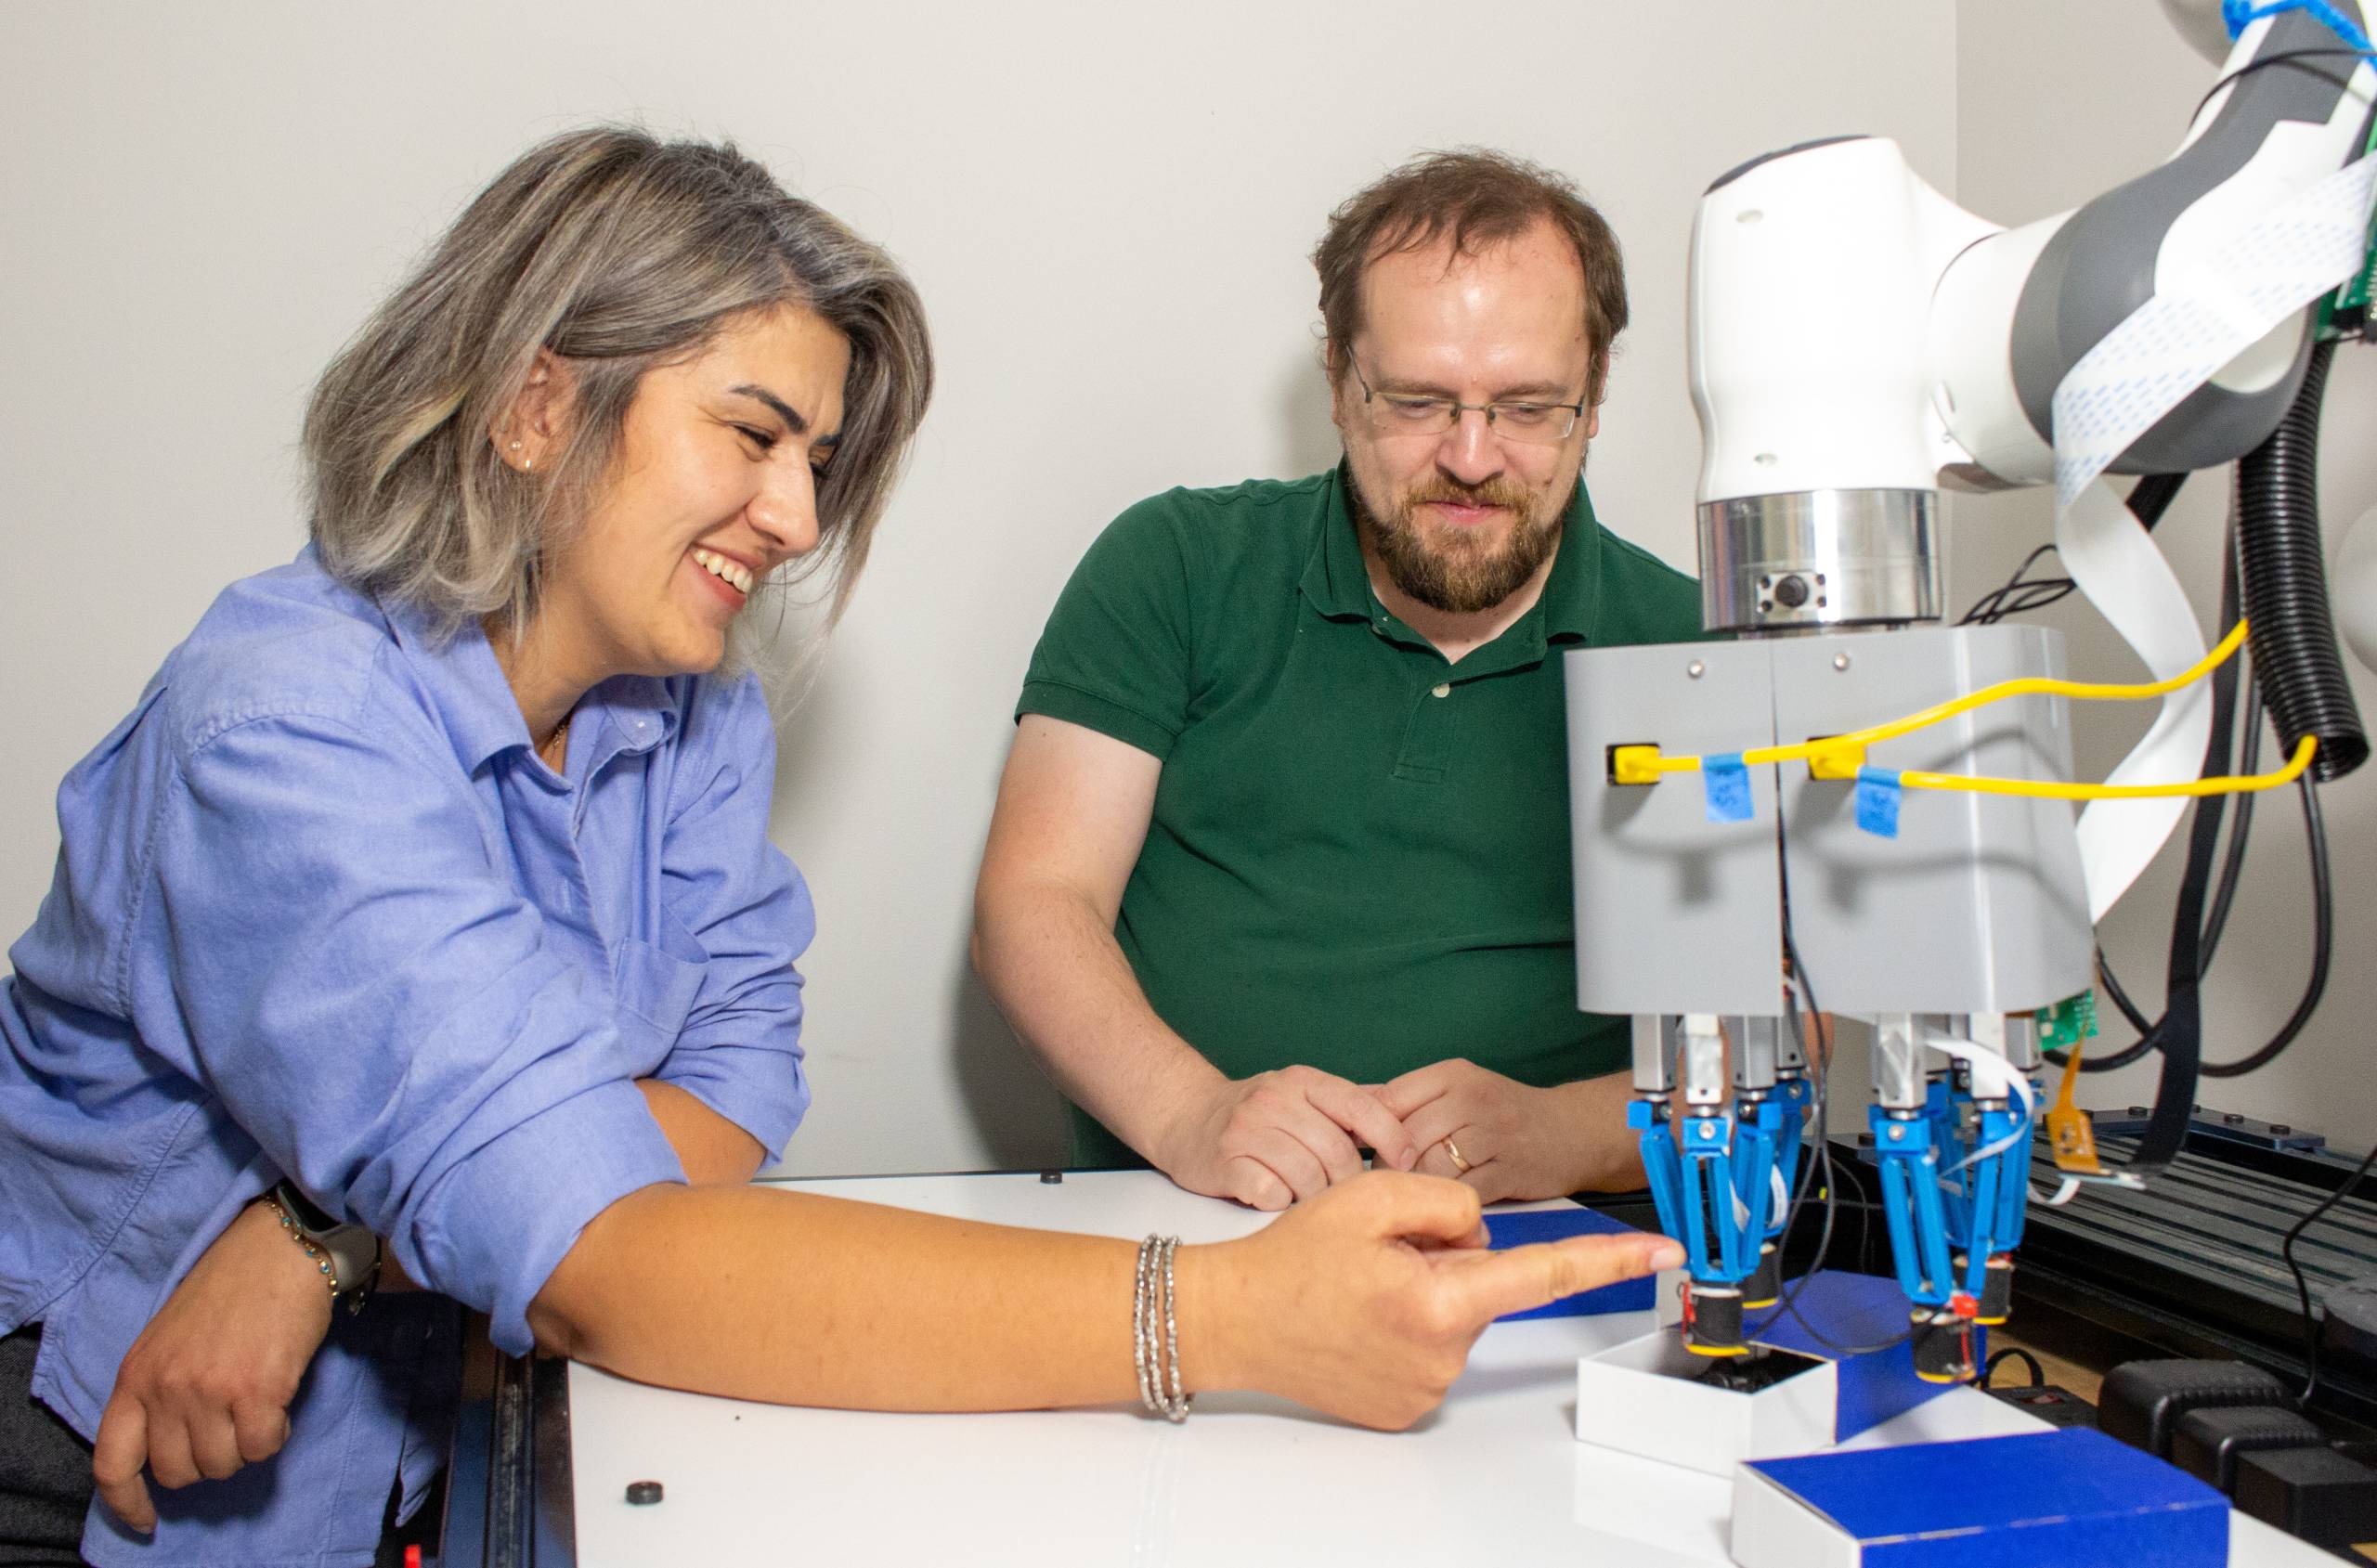
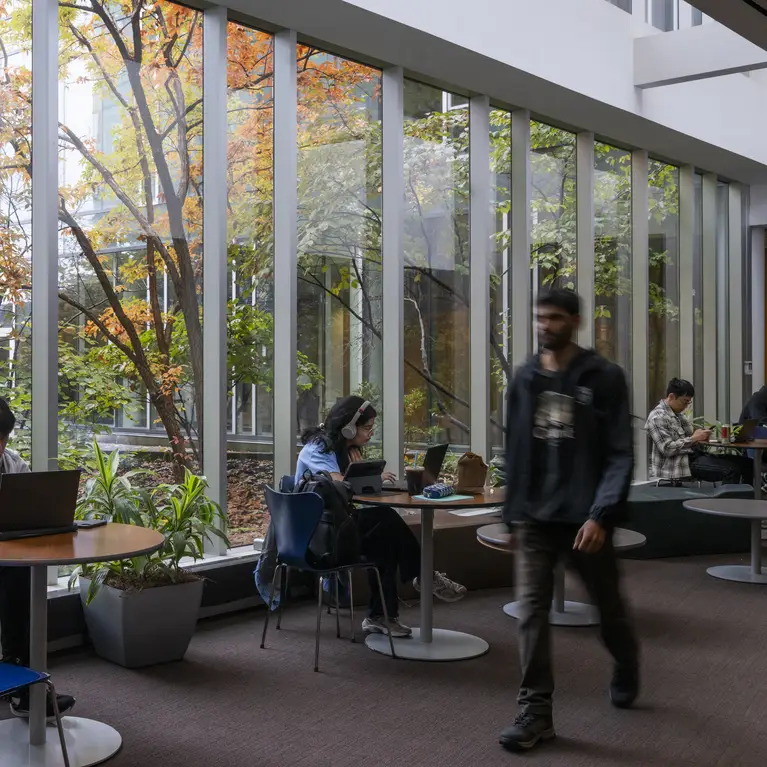
Researchers at Carnegie Mellon University's Kenneth C. Griffin School of Computer Science have designed a new type of robotic fingertip that integrates multiple senses to handle delicate objects. This innovation aims to enhance the capabilities of robotic home assistants, enabling them to perform tasks like picking up small items such as pills, which are challenging to grasp without damage.
The significance of this development lies in its potential to improve dexterity in robotics, a critical area of research. According to Oliver Kroemer, an associate professor at the Robotics Institute, fine manipulation remains a significant challenge in the field. The new fingertips, inspired by human anatomy, are cost-effective and versatile, costing less than $100 each, compared to $800 for similar devices made from commercial products.
Looking ahead, the research team plans to further enhance the robotic hand's capabilities by expanding the sensing technology beyond the fingertips. Their work was recently presented at the 2026 Intelligent Robots and Systems Conference in Pittsburgh, highlighting the ongoing advancements in robotic manipulation and the potential for future applications in home assistance.
Editor's Note
The development of advanced robotic manipulation technologies is crucial for enhancing automation in various sectors, including home assistance and industrial applications. As researchers continue to innovate in dexterity and sensing, the competitive landscape in robotics will evolve, potentially leading to more sophisticated and capable robotic systems that can perform complex tasks with precision.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.









Leave a comment