

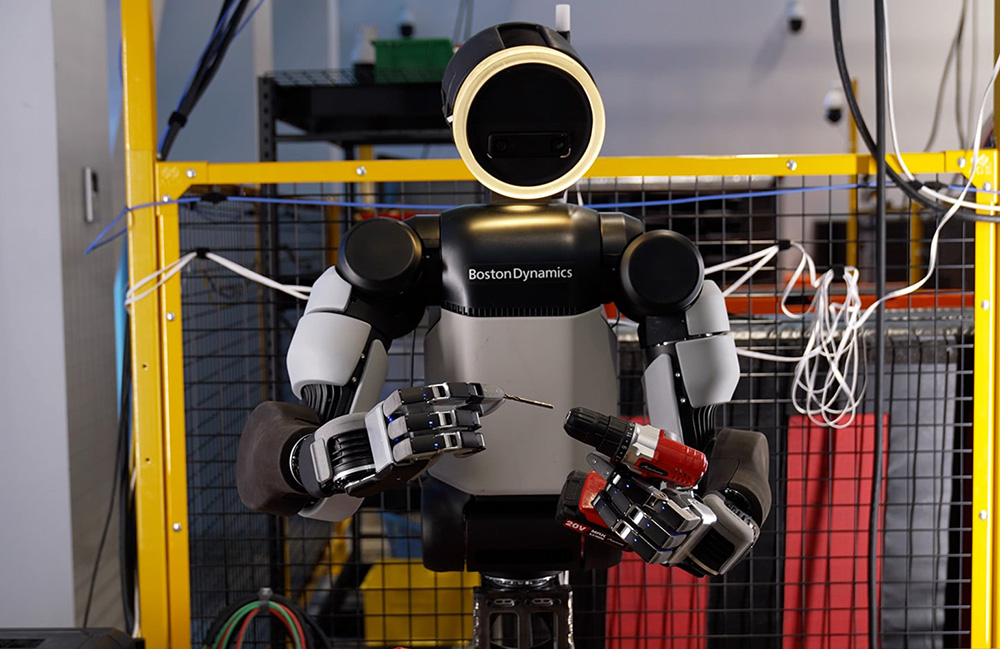
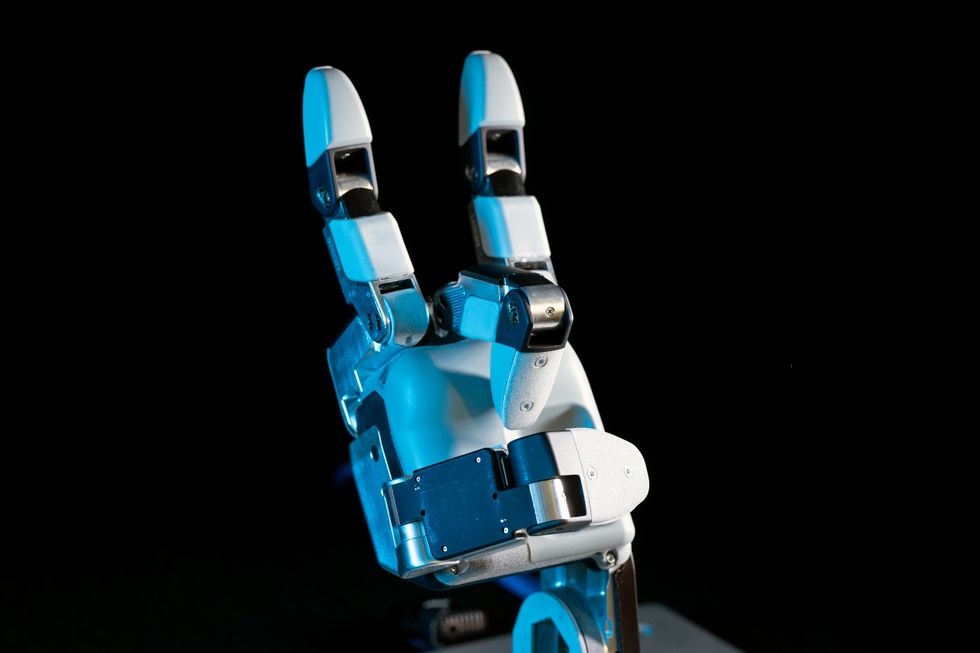
Boston Dynamics has introduced a new four-fingered hand for its Atlas humanoid robot, featuring 13 degrees of freedom and designed for tool manipulation. The hand, which lacks a pinky, emphasizes reliability and mass manufacturing over complexity, allowing for high fidelity simulation and sim-to-real reinforcement learning.
This development is significant as it marks a shift in focus from merely grasping objects to manipulating them effectively. The design process involved extensive experimentation, leading the team to conclude that the absence of a pinky finger would not hinder the robot's capabilities, balancing dexterity with complexity and power consumption.
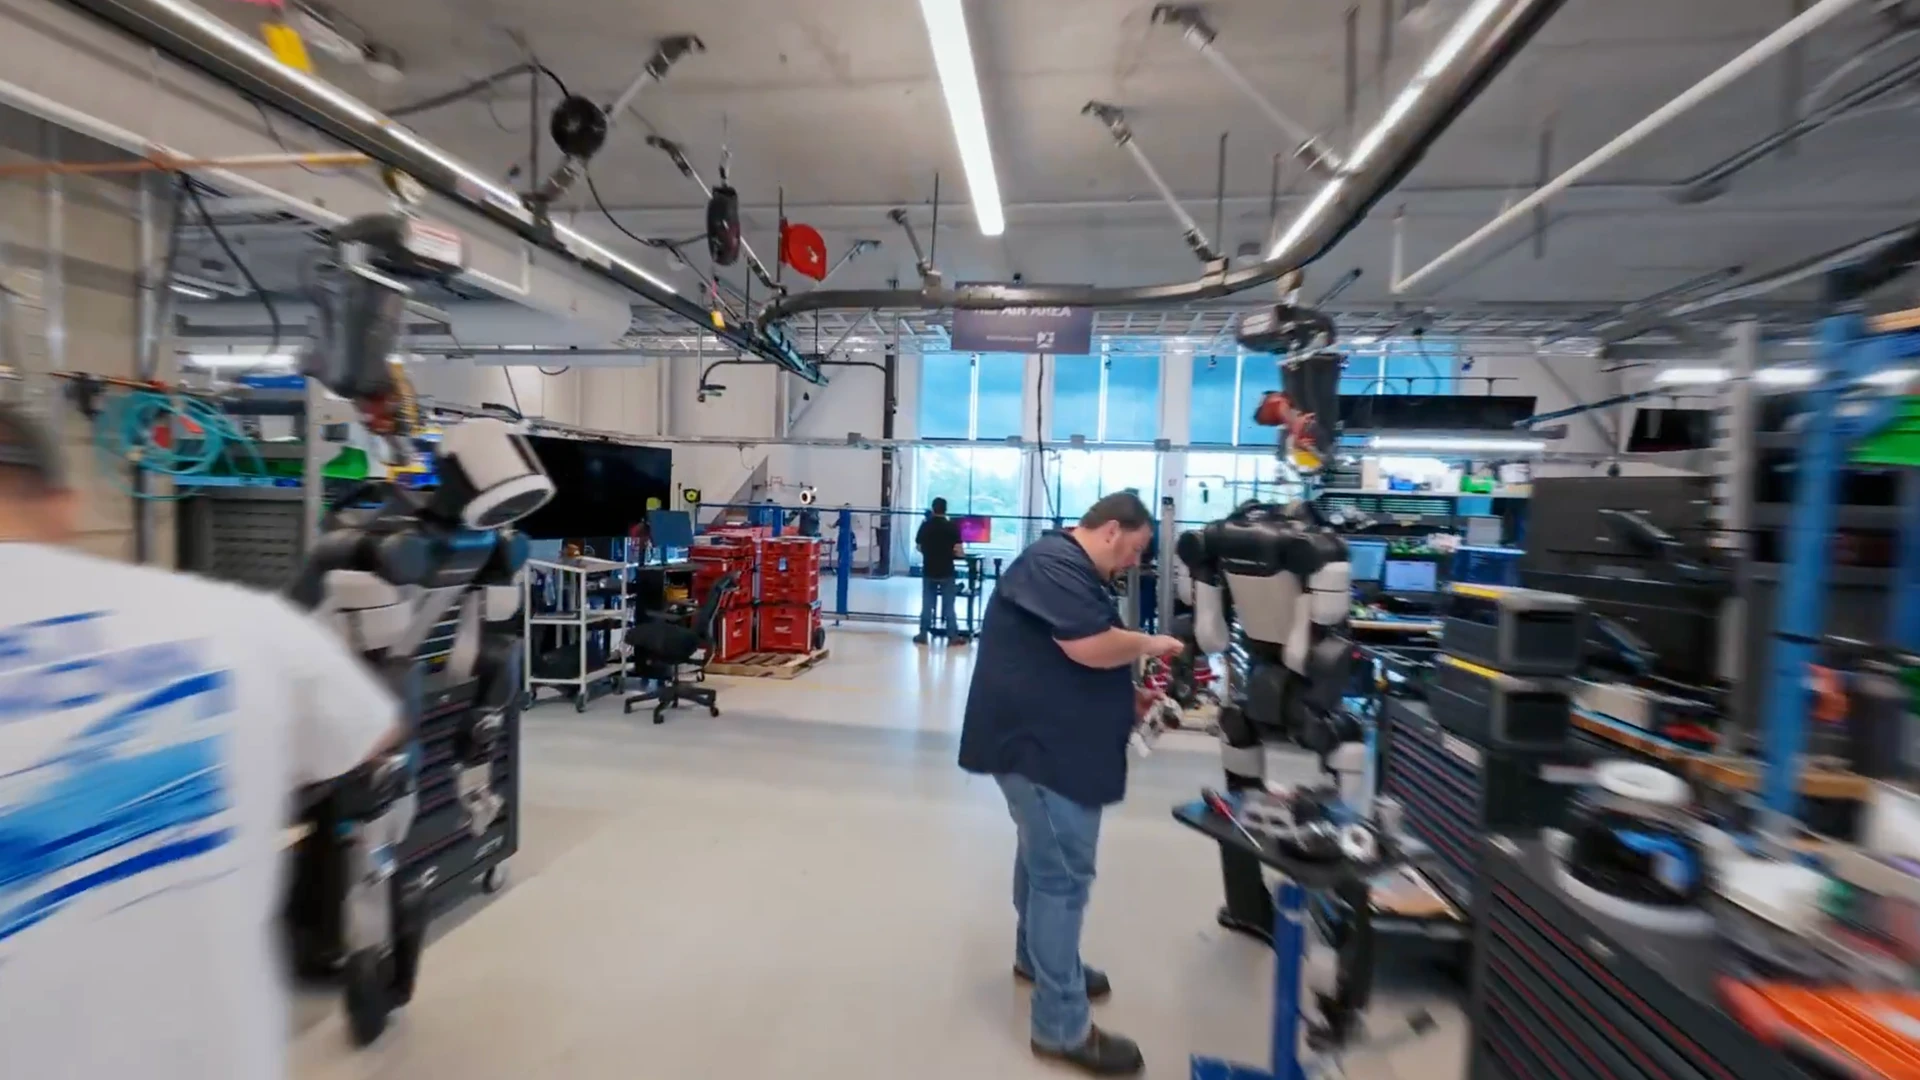
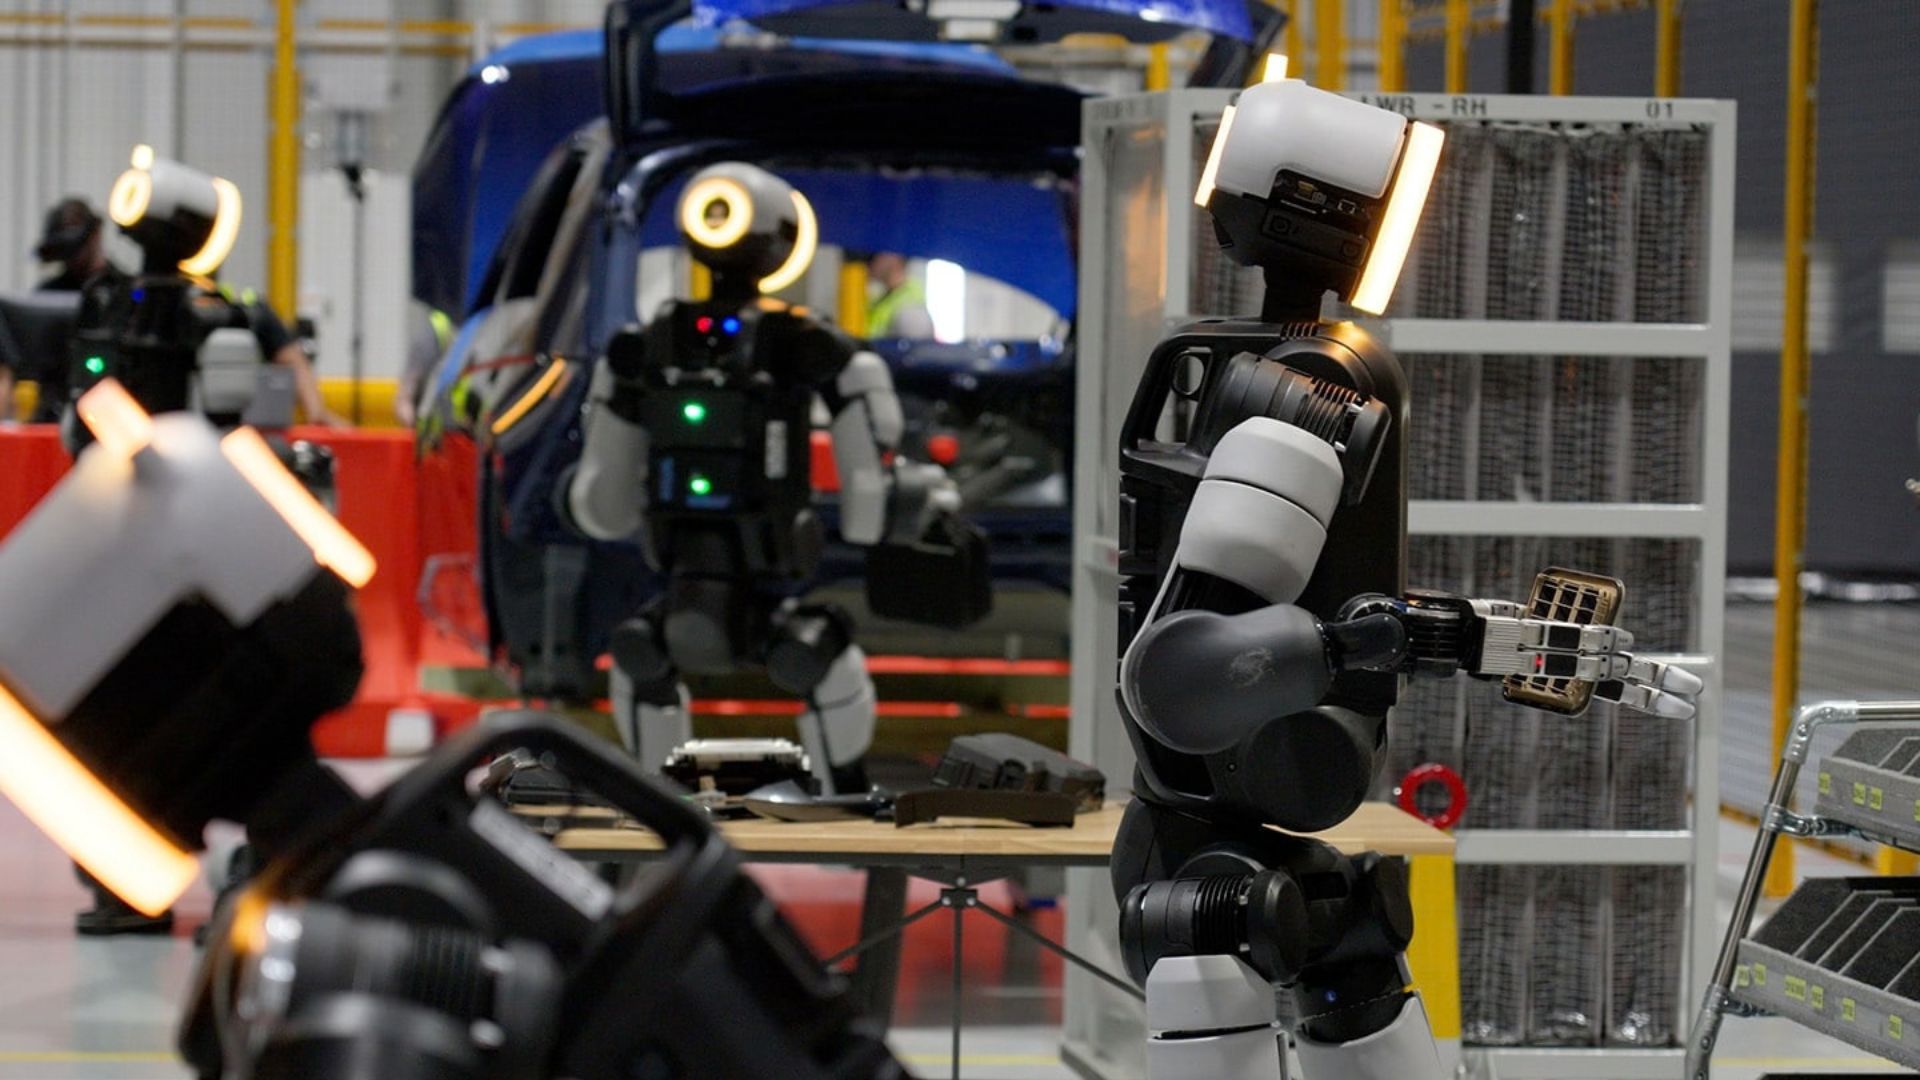
Looking ahead, Boston Dynamics is integrating Atlas into Hyundai's automotive manufacturing operations through its new Robotics Metaplant Application Center in Georgia. The company aims to enhance the functionality of its robots in real-world applications, with no further timeline disclosed at the time of publication.
Editor's Note
The introduction of Boston Dynamics' new hand for the Atlas robot reflects a broader trend in robotics towards practical functionality over human-like design. As companies strive to integrate advanced robotics into manufacturing processes, the focus on reliable and efficient tool manipulation will likely shape future developments in robotic hand technology.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.










Leave a comment