

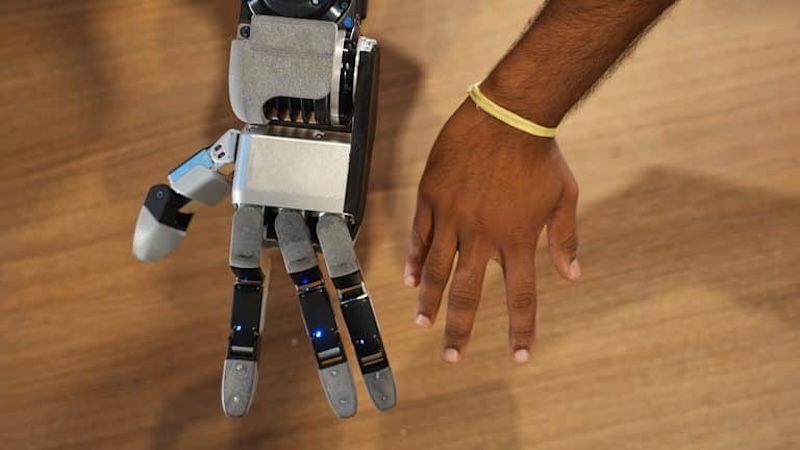
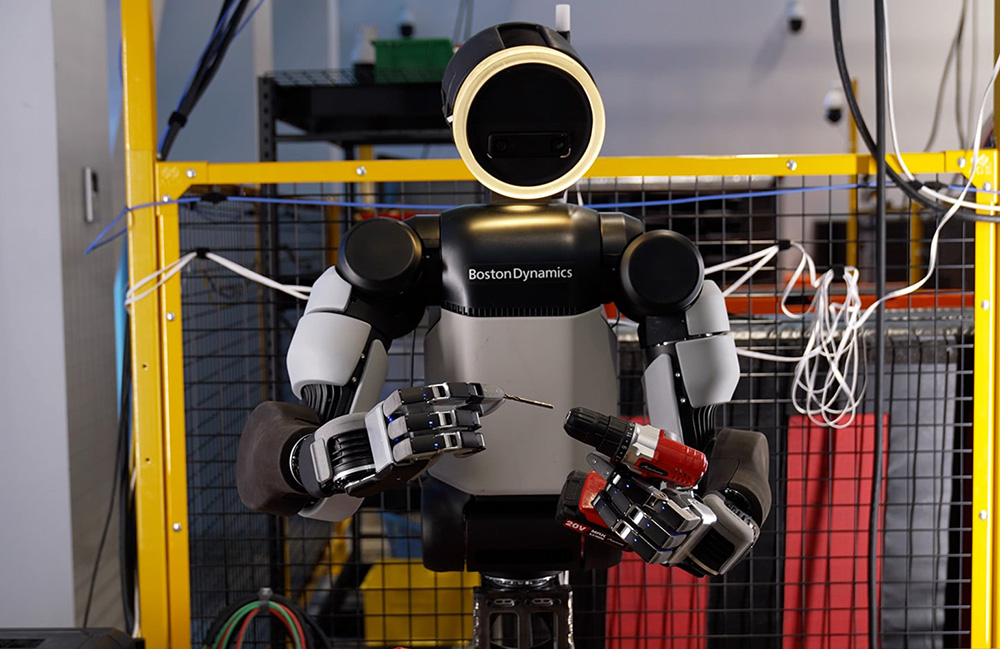
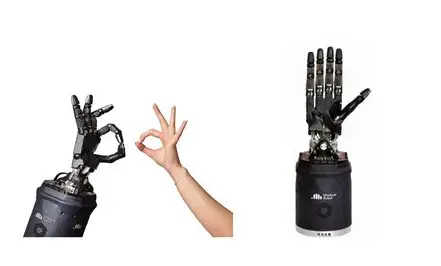
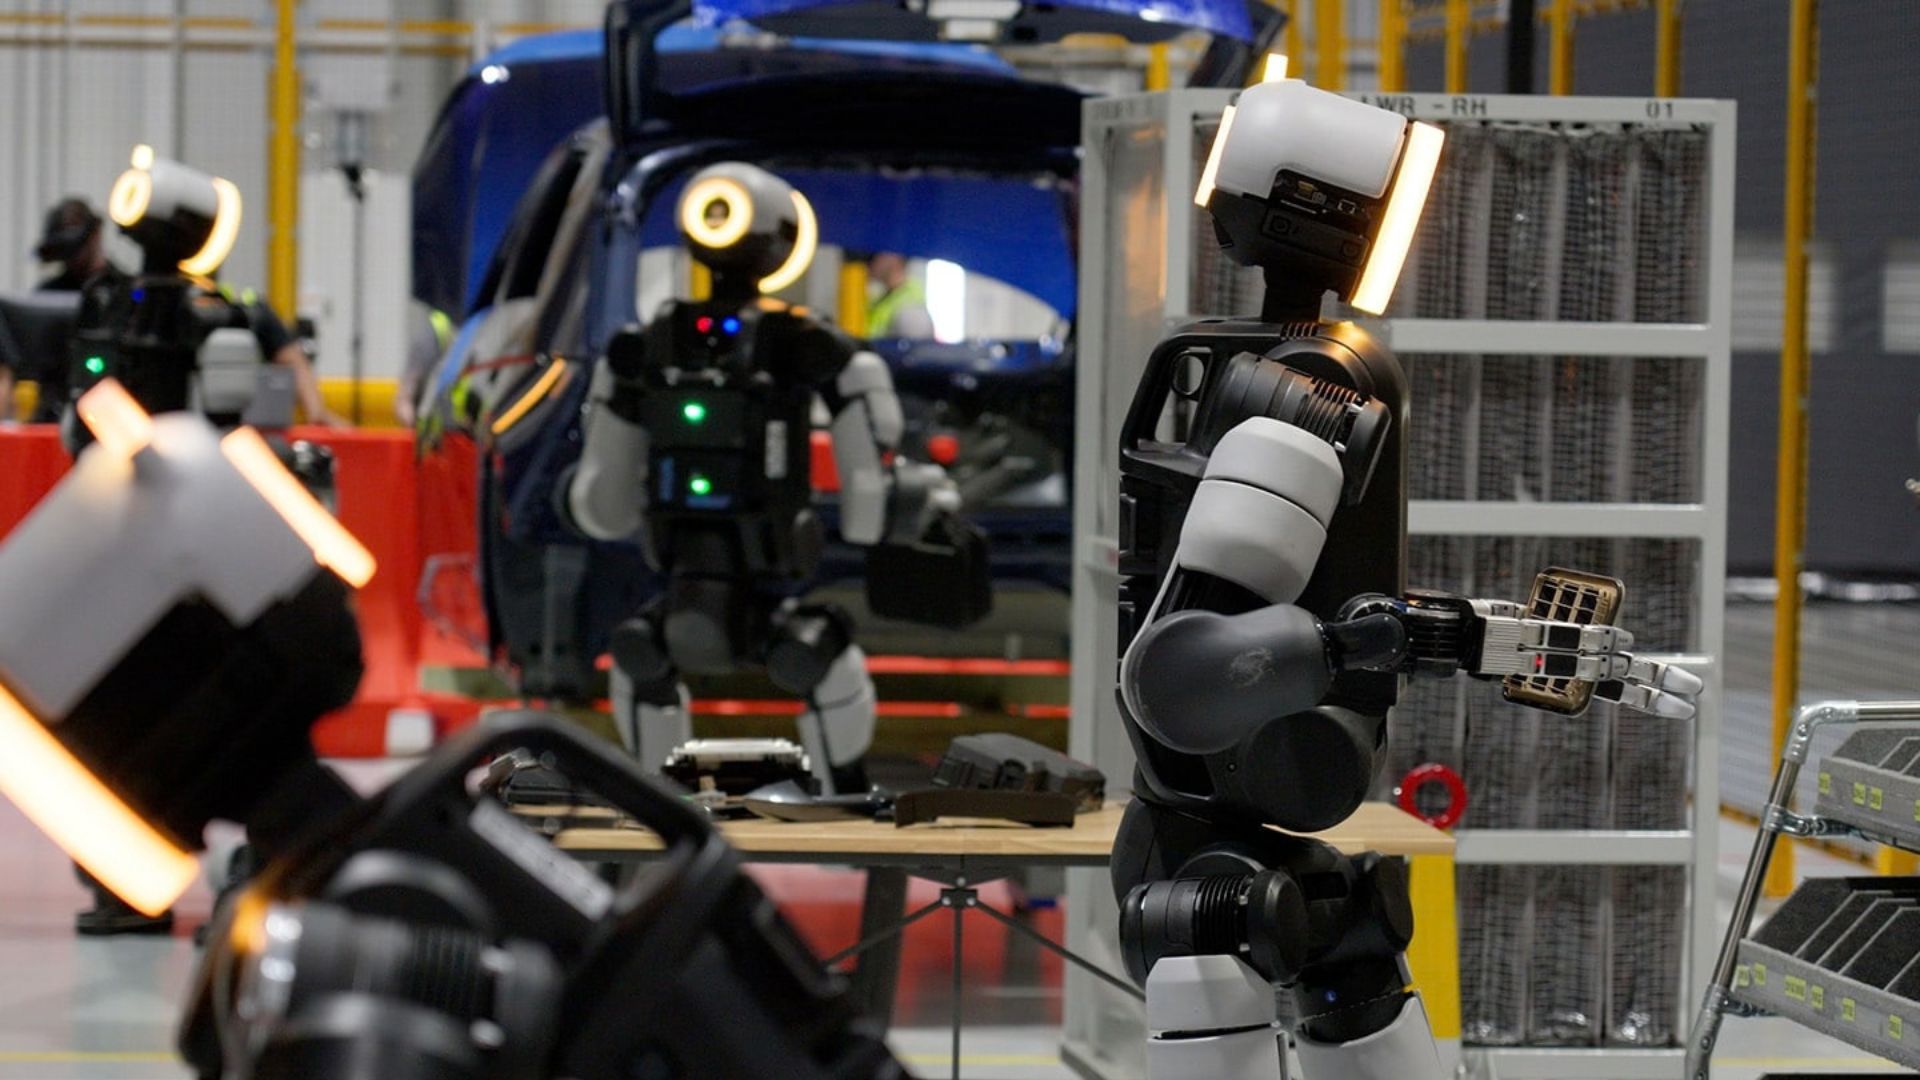
Boston Dynamics has launched a new four-finger hand for its Atlas humanoid robot, enhancing its capabilities for complex manipulation and industrial tasks. This innovative hand features 13 degrees of freedom, including a four-DOF opposable thumb, and incorporates tactile pressure sensors for improved dexterity and strength.
The new design allows Atlas to perform intricate tasks such as in-hand object reorientation and tool operation, while the decision to use four fingers instead of five aims to reduce costs and complexity without sacrificing functionality. The hand's size is comparable to that of a large human hand, enabling Atlas to work in environments designed for human operators.
Looking ahead, Boston Dynamics is focused on improving the ruggedness and manufacturability of humanoid robots as they prepare for larger-scale production. No further timeline was disclosed at the time of publication.
Editor's Note
The introduction of the four-finger hand for the Atlas robot marks a significant advancement in humanoid robotics, particularly in terms of dexterity and industrial application. As companies increasingly adopt automation technologies, innovations like this could reshape workforce dynamics and operational efficiency in various sectors.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.










Leave a comment