

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.
Coast Guard Seeks Effective Technology to Counter Unmanned Underwater Vehicles
The Coast Guard has announced its search for technology capable of defeating unmanned underwater vehicles (UUVs). According to a recent notice, there are currently limited solutions that have been tested and fielded to address this challenge. This initiative is significant as the rise of UUVs poses potential threats to maritime security and safety. The Coast Guard's efforts to find effective countermeasures highlight the urgency of addressing vulnerabilities in underwater operations and protecting critical assets. Looking ahead, the Coast Guard's ongoing search for viable technology solutions will be crucial in enhancing maritime defense capabilities. No further timeline was disclosed at the time of publication.
Naval Warfare coast guard Drones Navy Unmanned unmanned underwater vehicle
A Multilevel Path Planning Framework for Unmanned Surface Vehicles in Environmental Monitoring
A new multilevel path planning framework has been developed for unmanned surface vehicles (USVs) aimed at enhancing environmental monitoring of uninhabited islands and reefs. This framework utilizes information-driven techniques to optimize navigation and data collection processes in challenging marine environments. The significance of this development lies in its potential to improve the efficiency and effectiveness of environmental monitoring efforts. By employing advanced path planning strategies, USVs can navigate complex terrains and gather critical data, which is essential for conservation and research initiatives in remote areas. Looking ahead, the implementation of this framework could lead to more widespread use of USVs in environmental studies. As researchers and organizations seek innovative solutions for monitoring ecosystems, the advancements in path planning technology will be crucial in facilitating these efforts. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
Study on Cooperative Navigation Methods for Autonomous Underwater Vehicles in Terrain Mapping
A recent study published in the Journal of Field Robotics explores cooperative navigation methods for autonomous underwater vehicles (AUVs) in terrain mapping. The research focuses on enhancing the accuracy and efficiency of AUVs when mapping underwater environments through collaborative navigation techniques. This research is significant as it addresses the challenges faced by AUVs in accurately mapping complex underwater terrains. By improving navigation methods, the study aims to facilitate better data collection for various applications, including environmental monitoring, underwater exploration, and resource management. Looking ahead, the implications of this research could lead to advancements in AUV technology and its applications in marine research. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
Current Disturbances Impacting Online Localization for Autonomous Underwater Vehicles
The Journal of Field Robotics has published an early view article discussing the challenges of online localization for autonomous underwater vehicles (AUVs) in the presence of current disturbances. This research highlights the difficulties faced by AUVs when global references are not available, which is crucial for their navigation and operational efficiency. Understanding how current disturbances affect AUV localization is significant as it directly impacts the effectiveness of underwater missions. Accurate localization is essential for various applications, including environmental monitoring, underwater exploration, and military operations. The findings from this study could lead to improved algorithms and technologies that enhance the reliability of AUVs in challenging underwater environments. Future research should focus on developing advanced localization techniques that can mitigate the effects of current disturbances on AUVs. As underwater exploration continues to grow, the demand for reliable AUV navigation systems will increase. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
Army Replaces Infantry Squad Vehicles with Polaris MRZR for Unmanned Systems Testing
The U.S. Army has officially transitioned from using Infantry Squad Vehicles (ISVs) to Polaris MRZR platforms for its Unmanned Systems (UxS) autonomy program. This change, confirmed by Michael Rose, chief technology officer for CPE Mission Autonomy, aims to enhance off-road autonomy testing. The MRZR platforms will allow multiple companies to test their autonomy software in a standardized environment, facilitating direct comparisons of technological capabilities. This shift is significant as it marks a departure from the Army's previous plans to enhance ISVs with autonomy software from Forterra, Overland AI, and Scout AI. The decision to adopt MRZR platforms is based on evolving technological needs and aims to address challenges identified in the initial UxS program, including safety risks and financial constraints. The Army has received 12 MRZR Alphas from Polaris for this initiative, indicating a commitment to advancing unmanned ground vehicle capabilities. Looking ahead, the Army is evaluating various autonomy software providers for the MRZR platforms, although specific companies involved have not been disclosed. The ongoing participation of Forterra, Overland AI, and Scout AI in the UxS program suggests a competitive landscape as the Army seeks to refine its approach to unmanned systems. No further timeline was disclosed at the time of publication.
Land Warfare Army autonomy Drones ground autonomy GVSETS 2026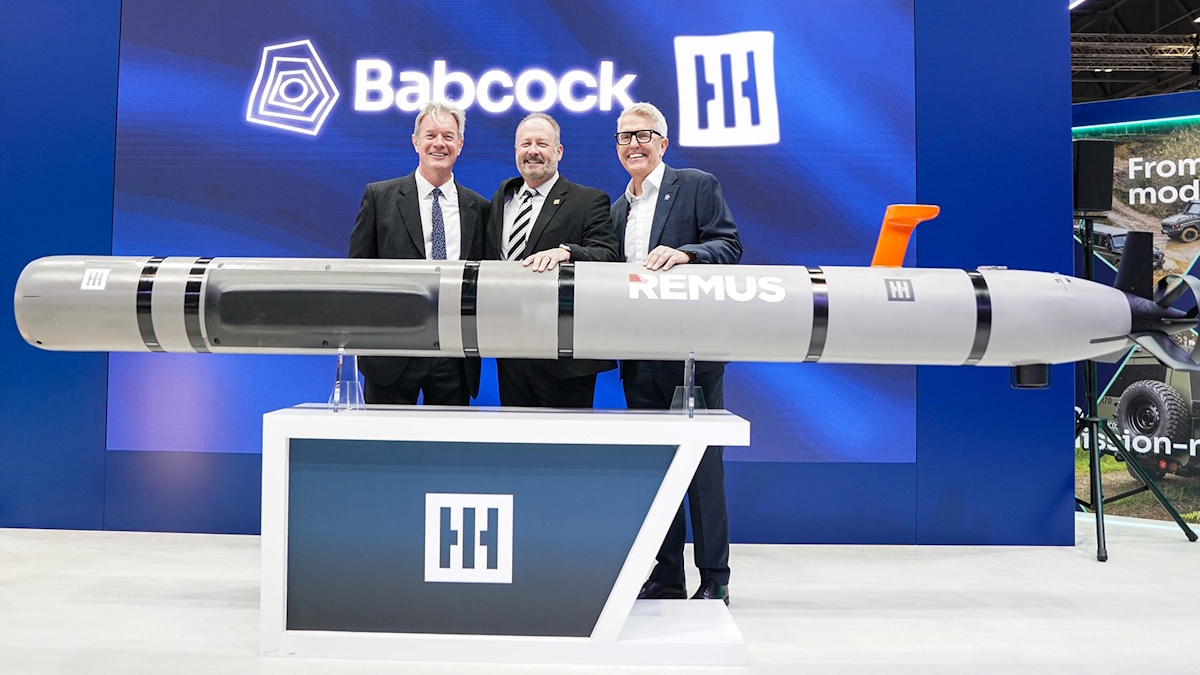
HII and Babcock Join Forces to Integrate Unmanned Underwater Vehicles with Submarine Weapon Handling and Launch Systems
Babcock International Group and HII have entered into a memorandum of understanding to integrate HII’s REMUS unmanned underwater vehicles with Babcock’s advanced submarine Weapon Handling and Launch Systems. This collaboration aims to enhance the autonomous launch and recovery capabilities of UUVs through submarine torpedo tubes, thereby bolstering the undersea operational advantages of allied navies. This initiative marks the inaugural program of its kind within Babcock's Mission Systems division, reflecting a significant step forward in military maritime technology.
hii babcock unmanned underwater vehicles submarine weapon handling and launch systems dsei 2025
Open‐Set Fault Diagnosis for Autonomous Underwater Vehicles Via Prototype Learning and Adaptive Mahalanobis Gating
The Journal of Field Robotics has recently published an early view article highlighting advancements in robotic technology. Researchers from various institutions collaborated to explore innovative applications of robotics in field environments. This study, released in October 2023, emphasizes the growing importance of robotics in enhancing efficiency and safety in agricultural and industrial settings. The motivation behind this research stems from the increasing demand for automation to address labor shortages and improve productivity. The team employed a combination of field tests and simulations to demonstrate the effectiveness of their robotic solutions, showcasing how these technologies can adapt to diverse tasks and terrains. The findings aim to inform future developments in robotic systems, ultimately contributing to more sustainable practices in various sectors.
RESEARCH ARTICLE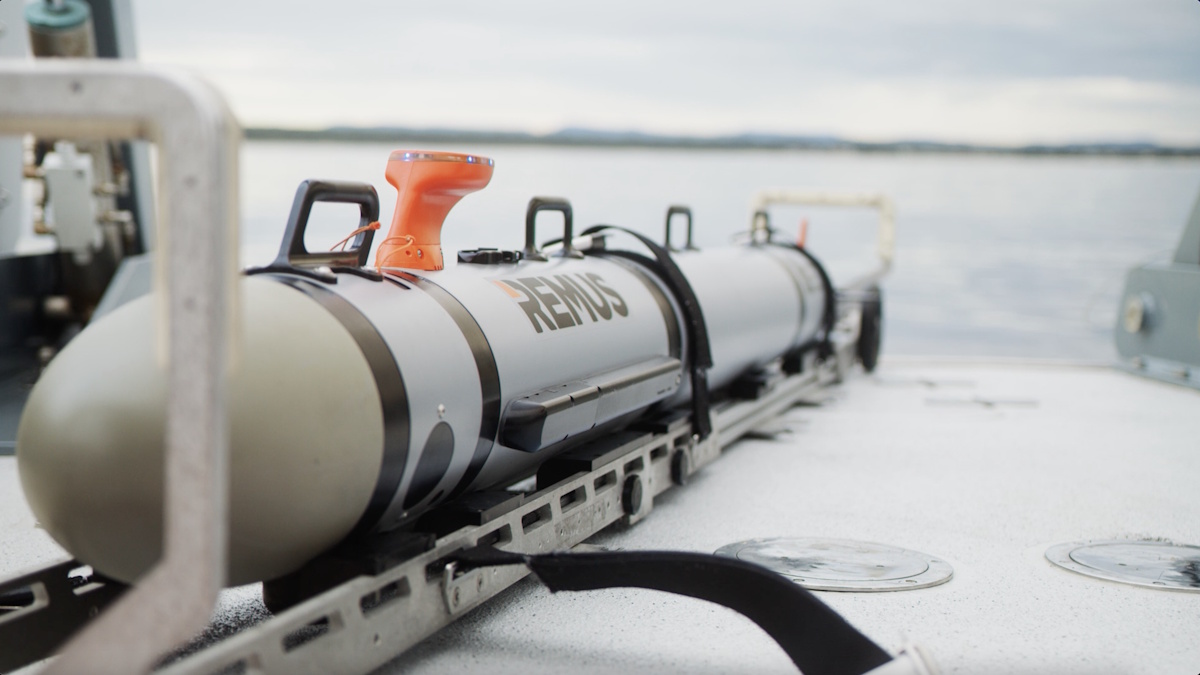
HII Secures Option Year Contract for 200 U.S. Navy Lionfish Undersea Vehicles
HII has been awarded an option year production contract for the U.S. Navy's Lionfish small unmanned undersea vehicle (SUUV), which is based on the REMUS 300 platform. This contract, announced on June 7, 2026, continues the momentum of the Lionfish program, which achieved a significant milestone with the completion of its 42nd vehicle at HII’s Pocasset facility by the end of 2025. The five-year program could scale to a total of 200 vehicles, with a contract value exceeding $347 million. The Lionfish SUUV is designed for various undersea warfare missions, including mine countermeasures, intelligence, surveillance and reconnaissance (ISR), anti-submarine warfare, and electronic warfare operations. The U.S. Navy's decision to exercise this option year contract reflects confidence in the platform's operational performance and adaptability, as stated by Duane Fotheringham, president of HII’s Unmanned Systems group. Looking ahead, HII aims to enhance the capabilities of the Lionfish program to meet evolving mission requirements for sailors and marines. No further timeline was disclosed at the time of publication, but the continued investment in this program indicates a strong commitment to advancing autonomous systems in naval operations.
hii contract award u.s. navy lionfish unmanned undersea vehicle uuv
RGPB‐Planner: A Real‐Time Gaussian Potential B‐Spline Trajectory Planner for Unmanned Aerial Vehicles in Complex Environments
A recent study published in the Journal of Field Robotics explores advancements in autonomous robotic systems designed for agricultural applications. Researchers from various institutions conducted the study to address the growing need for efficient farming solutions amid increasing global food demands. The findings, released in early October 2023, highlight innovative technologies that enhance the capabilities of robots in tasks such as planting, harvesting, and monitoring crops. The research was conducted in diverse agricultural settings, showcasing how these robotic systems can adapt to different environments and crop types. By integrating artificial intelligence and machine learning, the robots are able to optimize their performance, reducing labor costs and increasing productivity for farmers. This initiative stems from the urgent necessity to improve agricultural efficiency and sustainability in response to climate change and population growth. The study emphasizes that the implementation of these robotic systems could significantly transform traditional farming practices, making them more resilient and resource-efficient. The research team utilized a combination of field tests and simulations to demonstrate the effectiveness of the robotic technologies, providing a comprehensive analysis of their potential impact on the agricultural sector. As the industry continues to evolve, the insights from this study may pave the way for broader adoption of robotics in farming, ultimately contributing to food security and environmental sustainability.
RESEARCH ARTICLE
Performance Evaluation of Different Laser SLAM Algorithms for Unmanned Mining Vehicles
A recent study published in the Journal of Field Robotics highlights advancements in robotic technology aimed at improving agricultural efficiency. Researchers from a leading university conducted experiments to develop autonomous robots capable of performing tasks such as planting, weeding, and harvesting crops. The study, which took place over the summer of 2023, was conducted on various farms in California, showcasing the robots' adaptability to different agricultural environments. The motivation behind this research stems from the increasing demand for sustainable farming practices and the need to address labor shortages in the agricultural sector. By integrating advanced sensors and artificial intelligence, the robots are designed to optimize crop yields while minimizing resource use. The research team employed a series of field trials to test the robots' performance, collecting data on their effectiveness and efficiency compared to traditional farming methods. Preliminary results indicate that these autonomous systems can significantly reduce labor costs and increase productivity, offering a promising solution for modern agriculture. As the agricultural industry faces challenges such as climate change and population growth, this innovative approach could play a crucial role in ensuring food security and sustainability in the coming years. The findings from this study are expected to pave the way for further developments in agricultural robotics, potentially transforming the way food is produced globally.
SURVEY ARTICLE
Kalman Filter–Based Sensor Fusion for Navigation of Holonomic Unmanned Ground Vehicles
In a recent study published in the Journal of Field Robotics, researchers explored advancements in robotic navigation systems, focusing on their application in complex environments. The study, which appeared in the June 2026 issue, highlights innovations that enhance the ability of robots to navigate through challenging terrains, such as urban landscapes and disaster-stricken areas. Conducted by a team of engineers and roboticists, the research aims to address the growing demand for autonomous systems capable of performing tasks in unpredictable settings. By integrating advanced algorithms and machine learning techniques, the team demonstrated significant improvements in navigation efficiency and accuracy. The findings are particularly relevant as industries increasingly rely on robotics for tasks ranging from search and rescue operations to urban planning. The researchers conducted extensive field tests to validate their models, showcasing the robots' ability to adapt to dynamic obstacles and varying environmental conditions. This work not only contributes to the field of robotics but also underscores the potential for these technologies to enhance safety and effectiveness in critical situations. As the demand for intelligent robotic systems continues to rise, this research marks a significant step forward in the evolution of autonomous navigation.
RESEARCH ARTICLE
Adaptive DWA Guides Underwater Vehicles Past Obstacles
Researchers have developed an enhanced dynamic window approach for unmanned underwater vehicles (UUVs), aimed at improving their navigation capabilities in challenging environments. This innovative method focuses on optimizing obstacle avoidance, which significantly increases the success rates of UUV operations while simultaneously reducing energy consumption. The advancements in this technology are particularly relevant for missions that require precise maneuvering in complex underwater landscapes, such as search and rescue operations, environmental monitoring, and underwater exploration. By integrating this new approach, UUVs can better adapt to dynamic conditions, ensuring safer and more efficient missions. The findings were presented in October 2023, highlighting the potential for this technology to revolutionize underwater vehicle navigation.
Six‐Dimensional Digital Twin System for Autonomous Underwater Vehicles: Conceptualization and Twin Experiments
The Journal of Field Robotics has published a new early view article highlighting advancements in robotic technology. The research, conducted by a team of engineers and scientists, focuses on enhancing the capabilities of autonomous robots in complex environments. This study, released in October 2023, aims to address the growing demand for improved robotic systems in various applications, including agriculture, search and rescue, and industrial automation. The researchers employed innovative algorithms and machine learning techniques to enable robots to navigate and operate more effectively in unpredictable settings. By simulating real-world scenarios, the team was able to test the robots' performance and adaptability, showcasing significant improvements over previous models. This development comes at a crucial time as industries increasingly rely on automation to boost efficiency and safety. The findings are expected to influence future designs and applications of robotic systems, ultimately contributing to the evolution of the field. The research underscores the importance of interdisciplinary collaboration in advancing technology and meeting the challenges posed by complex operational environments.
RESEARCH ARTICLE
Collaborative Sampling and Imaging of Phytoplankton Communities by Two Long‐Range Autonomous Underwater Vehicles Using Acoustic Tracking and Messaging
In May 2026, researchers published a study in the Journal of Field Robotics, detailing advancements in robotic technology aimed at enhancing agricultural efficiency. This research, conducted by a team of engineers and agricultural scientists, focuses on the development of autonomous robots capable of performing various farming tasks, such as planting, monitoring crop health, and harvesting. The study highlights the pressing need for innovative solutions in agriculture, driven by the increasing global population and the corresponding demand for food production. By integrating advanced sensors and artificial intelligence, these robots can operate independently, reducing the reliance on manual labor and improving productivity. The research was conducted in various agricultural settings, showcasing the robots' adaptability to different environments and crop types. The findings suggest that implementing such robotic systems could lead to significant cost savings and increased yield for farmers, ultimately contributing to food security. The team employed a combination of field trials and simulations to validate the robots' effectiveness, demonstrating their ability to navigate complex terrains and perform tasks with precision. This breakthrough could revolutionize the agricultural sector, offering a sustainable approach to meet future food demands while minimizing environmental impact.
RESEARCH ARTICLE
Dynamic State Feedback Control of Autonomous Underwater Vehicles Based on Switching Between Multiple Heading Movement Models
In May 2026, researchers published a significant study in the Journal of Field Robotics, detailing advancements in robotic technology. The study, appearing in Volume 43, Issue 3, pages 1679-1692, highlights innovative methodologies for enhancing robotic navigation and autonomy in complex environments. Conducted by a team of experts in robotics and artificial intelligence, the research aims to address the growing demand for efficient and reliable robotic systems in various industries, including agriculture, manufacturing, and disaster response. The motivation behind this research stems from the increasing reliance on robotics in everyday applications and the need for these systems to operate effectively in unpredictable settings. By employing advanced algorithms and machine learning techniques, the researchers demonstrated how robots can improve their decision-making processes and adapt to changing conditions in real-time. The findings are expected to have a profound impact on the future development of autonomous robots, paving the way for more sophisticated applications that can enhance productivity and safety across multiple sectors. As the field of robotics continues to evolve, this study represents a crucial step toward achieving greater autonomy and efficiency in robotic systems.
RESEARCH ARTICLE
Transition Strategy for Unmanned Aerial‐Aquatic Vehicles (UAAVS): A Survey
In the May 2026 issue of the Journal of Field Robotics, researchers present groundbreaking advancements in robotic technology, focusing on the development of autonomous systems designed for complex field operations. This comprehensive study highlights innovations that enhance the efficiency and safety of robots deployed in various environments, including agriculture, disaster response, and exploration. The research team, comprised of leading experts in robotics and artificial intelligence, conducted extensive field tests to evaluate the performance and adaptability of these autonomous systems. Their findings reveal significant improvements in navigation, obstacle avoidance, and decision-making capabilities, which are crucial for real-world applications. The motivation behind this research stems from the increasing demand for reliable robotic solutions that can operate in unpredictable and hazardous conditions. By addressing these challenges, the team aims to pave the way for more widespread adoption of robotics in critical sectors, ultimately improving operational outcomes and reducing human risk. The study's implications are far-reaching, suggesting that these advanced robotic systems could revolutionize industries by providing enhanced support in tasks that are currently labor-intensive or dangerous. As the field of robotics continues to evolve, this research marks a significant step forward in harnessing technology to meet the needs of society.
SURVEY ARTICLE
A Review on Path Planning for Autonomous Underwater Vehicles: From Models, Classical Methods, and Learning‐Based Intelligence Perspectives
In a recent study published in the Journal of Field Robotics, researchers explored advancements in robotic technologies aimed at enhancing agricultural efficiency. The findings, released in May 2026, highlight innovative methods for deploying autonomous robots in farming environments to improve crop management and yield. Conducted by a team of experts in robotics and agriculture, the research took place in various agricultural settings, focusing on the integration of artificial intelligence and machine learning to optimize planting, monitoring, and harvesting processes. The motivation behind this initiative stems from the growing need for sustainable farming practices and the increasing global demand for food production. By utilizing advanced robotics, the study aims to address labor shortages and reduce environmental impacts associated with traditional farming methods. The researchers conducted extensive field trials to assess the effectiveness of these robotic systems, demonstrating significant improvements in efficiency and productivity. This work not only contributes to the field of robotics but also offers practical solutions for the agricultural sector facing modern challenges.
SURVEY ARTICLE
UK Royal Navy Awards Teledyne Contract for Autonomous Underwater Vehicles and Floats
Teledyne Marine, a division of Technologies Incorporated, has secured a contract with the UK Ministry of Defence to enhance the Royal Navy's oceanographic and environmental data collection capabilities. This partnership supports the Royal Navy's Future Maritime Data Gathering initiative, aimed at improving persistent oceanographic data collection. The contract underscores the UK's commitment to advancing its maritime research and operational effectiveness.
uk royal navy contract award teledyne autonomous underwater vehicles (auv) floats
Enhanced Unscented Kalman Filter With Time‐Varying Attenuation Factor for Cross‐Domain Unmanned Surface Vehicle/Autonomous Underwater Vehicle Tracking Using Time‐Direction of Arrival Measurements
The Journal of Field Robotics has recently published an early view article highlighting advancements in robotic technology. This publication, which became available in October 2023, focuses on innovative applications of robotics in various fields, including agriculture, search and rescue, and environmental monitoring. Researchers and engineers are increasingly motivated to enhance robotic capabilities to address complex challenges and improve efficiency in these sectors. The article outlines the methodologies employed in developing these advanced robotic systems, emphasizing the integration of artificial intelligence and machine learning. By showcasing successful case studies and ongoing projects, the journal aims to inform and inspire further research and collaboration within the robotics community.
RESEARCH ARTICLE
Analysis of Unilateral Track Movement for Tracked Unmanned Combat Vehicles
A recent study published in the Journal of Field Robotics highlights advancements in autonomous robotic systems designed for agricultural applications. Researchers from a leading university conducted experiments to assess the effectiveness of these robots in optimizing crop management. The study took place over the summer of 2023 on various farms across the Midwest, where the robots were deployed to monitor crop health and automate tasks such as planting and harvesting. The motivation behind this research stems from the increasing need for sustainable farming practices and the challenges posed by labor shortages in the agricultural sector. By integrating advanced sensors and artificial intelligence, the robots demonstrated significant improvements in efficiency and accuracy compared to traditional farming methods. The researchers utilized a combination of field tests and data analysis to evaluate the robots' performance, focusing on their ability to adapt to different environmental conditions and crop types. The findings suggest that these autonomous systems could play a crucial role in enhancing productivity while reducing the environmental impact of farming. As the agricultural industry continues to evolve, this study underscores the potential of robotics to transform farming practices, addressing both economic and ecological challenges. The ongoing research aims to further refine these technologies, paving the way for broader adoption in the field.
RESEARCH ARTICLE
Improved Target Detection in Unmanned Aerial Vehicles Search and Rescue via V‐Circular Trajectory Optimization
The Journal of Field Robotics has recently published an early view article highlighting significant advancements in robotic technology. Researchers from various institutions collaborated to explore innovative applications of robotics in field environments, aiming to enhance efficiency and safety in agricultural practices. This study, released in October 2023, emphasizes the growing importance of automation in addressing labor shortages and improving productivity in the agricultural sector. By integrating advanced sensors and artificial intelligence, the team demonstrated how robots can autonomously navigate complex terrains and perform tasks such as planting, harvesting, and monitoring crop health. The findings suggest that these technological advancements could revolutionize traditional farming methods, ultimately leading to more sustainable agricultural practices.
RESEARCH ARTICLE
Autonomous Underwater Vehicles Key Components Fault Diagnosis Method Based on Multisource Information Multilevel Fusion With Fault Feature Exchange
The Journal of Field Robotics has published new research highlighting advancements in robotic technology aimed at enhancing field operations. This study, released in early October 2023, focuses on the integration of artificial intelligence and machine learning to improve the efficiency and accuracy of robotic systems in agricultural settings. Conducted by a team of researchers from various institutions, the work demonstrates how these innovations can lead to better crop management and resource allocation. The research was carried out in various agricultural environments, showcasing the robots' ability to adapt to different terrains and conditions. By employing sophisticated algorithms, the robots can analyze data in real-time, allowing for timely interventions that can significantly boost yields and reduce waste. The motivation behind this study stems from the growing need for sustainable farming practices amid increasing global food demand. By leveraging advanced robotics, the researchers aim to address challenges such as labor shortages and environmental impacts associated with traditional farming methods. The findings suggest that the application of these technologies could revolutionize the agricultural industry, making it more efficient and environmentally friendly. As the field of robotics continues to evolve, this research underscores the potential for robotic systems to play a crucial role in modern agriculture, paving the way for future innovations that could further transform how food is produced and managed.
RESEARCH ARTICLE
Mission Specialist Wraith Signals AeroVironment’s Next Step in Compact Unmanned Underwater Systems Capability
A new expeditionary unmanned underwater vehicle (UUV) has been unveiled, showcasing advanced capabilities that include six-degree-of-freedom maneuverability, increased thrust, and modular mission flexibility. This compact platform is designed to enhance operational efficiency for various underwater missions. The development comes amid growing demands for innovative maritime technology, as military and research organizations seek to improve their underwater exploration and operational capabilities. The UUV's design allows for easy adaptation to different mission requirements, making it a versatile tool for a range of applications. The introduction of this advanced vehicle marks a significant step forward in underwater technology, promising to support both military operations and scientific research in challenging aquatic environments.
videoray rov wraith aerovironment
Liquid Robotics and Hydronet Sign MOU to Advance Undersea Mesh Networking for Maritime and Underwater Autonomous Vehicles
Liquid Robotics, a subsidiary of Boeing, has partnered with Massachusetts-based deep tech start-up Hydronet to enhance and commercialize underwater mesh networking technologies. This collaboration aims to improve connectivity for maritime and underwater autonomous vehicles. The two companies have formalized their commitment through a Memorandum of Understanding (MOU), signaling a strategic move to leverage their respective expertise in advancing this innovative technology. The partnership is expected to facilitate more efficient communication and data sharing among autonomous systems operating in underwater environments, ultimately enhancing operational capabilities in various maritime applications.
liquid robotics hydronet mou undersea mesh networking underwater autonomous vehicles auv
Kongsberg Discovery Starts Production of Autonomous Underwater Vehicles in the U.S.
Kongsberg Discovery has announced the commencement of production for its HUGIN autonomous underwater vehicle in the United States. This strategic move, made in response to the increasing demand for advanced subsea technology in the U.S. market, underscores the company's commitment to enhancing its presence in the region. By establishing local production, Kongsberg aims to better serve its clients and capitalize on the growing opportunities within the subsea sector. The decision reflects a broader trend of companies investing in domestic manufacturing to meet specific market needs and improve operational efficiency.
kongsberg discovery hugin auv
HII Tops 700 REMUS Uncrewed Underwater Vehicles Sold
HII, the largest shipbuilder in the United States and a prominent provider of all-domain technologies and solutions, has achieved a significant milestone by selling over 700 REMUS uncrewed underwater vehicles (UUVs) to customers worldwide. This accomplishment not only underscores HII's dominance in the market but also enhances its reputation as the leading producer of these advanced underwater systems. The sales reflect a growing demand for innovative undersea technology, positioning HII at the forefront of the industry as it continues to expand its global footprint.
hii remus uncrewed underwater vehicles (uuv)Robotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.







