

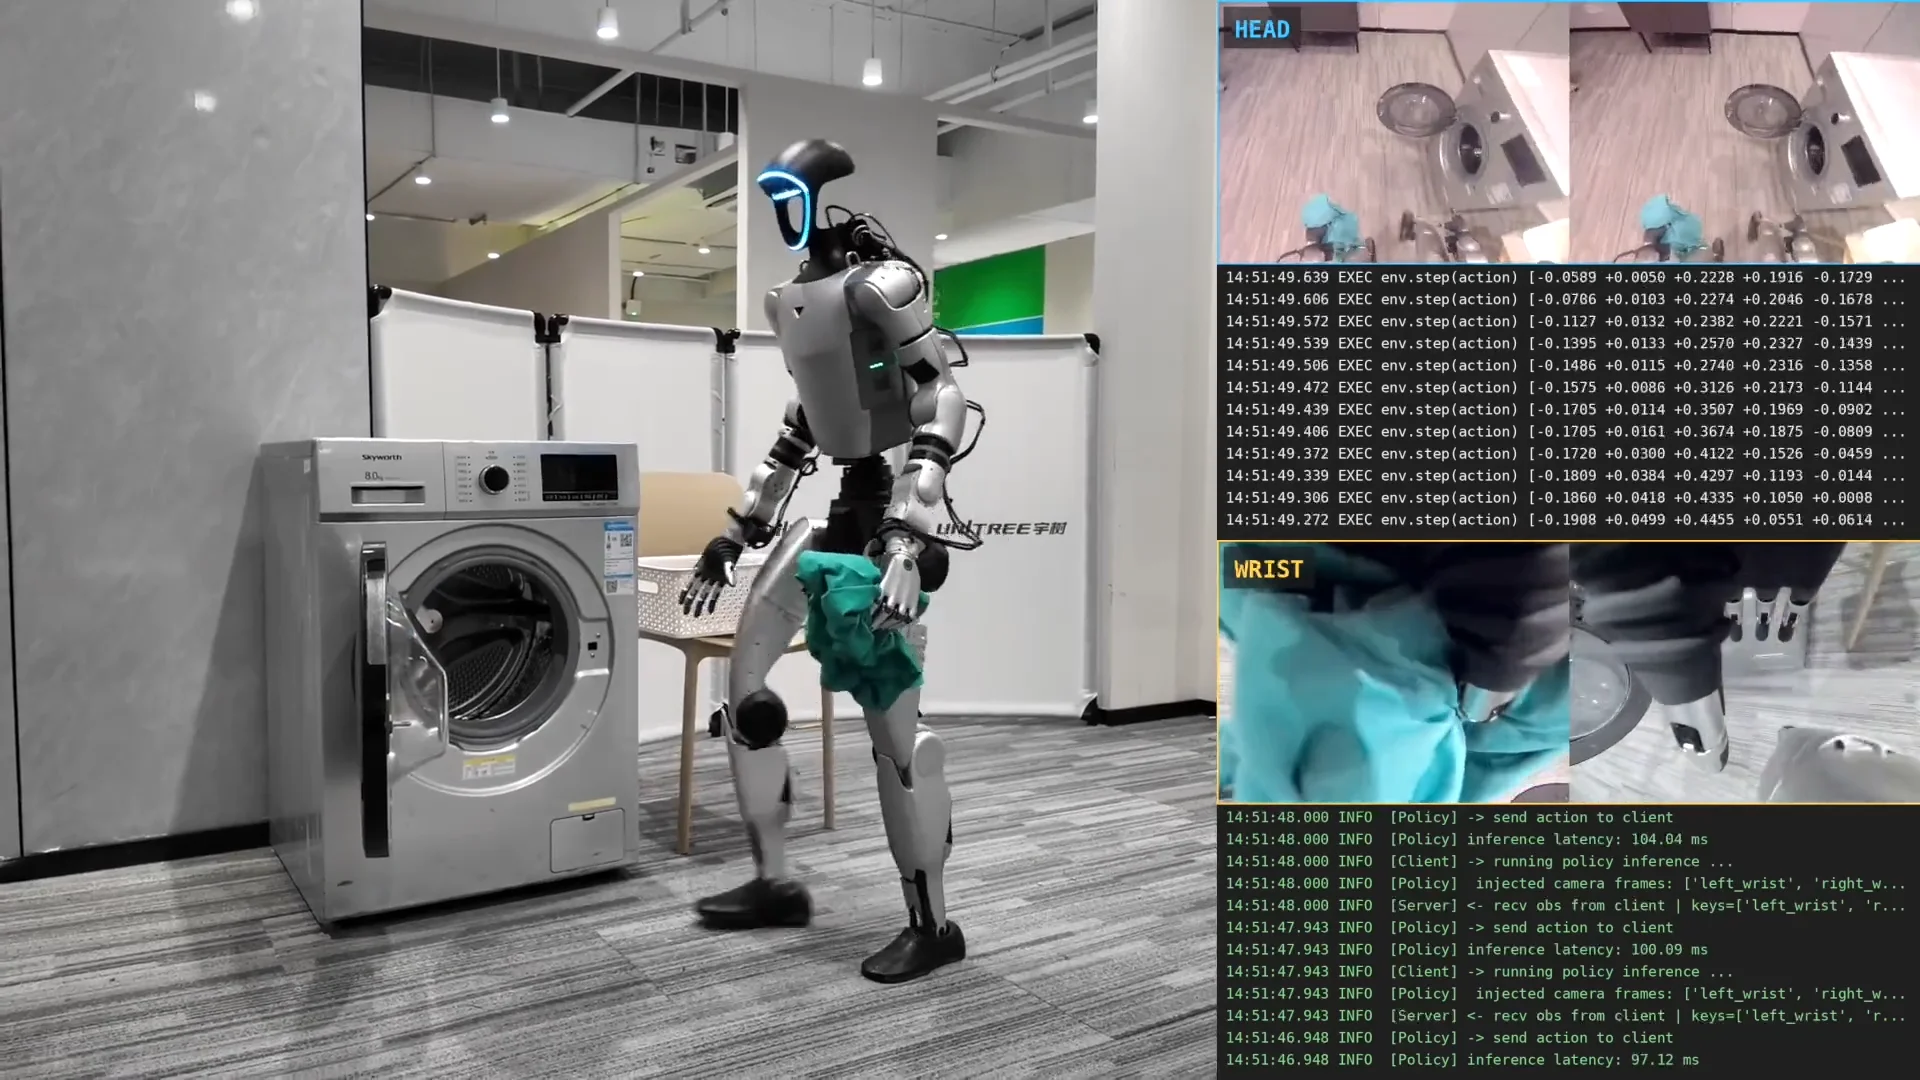
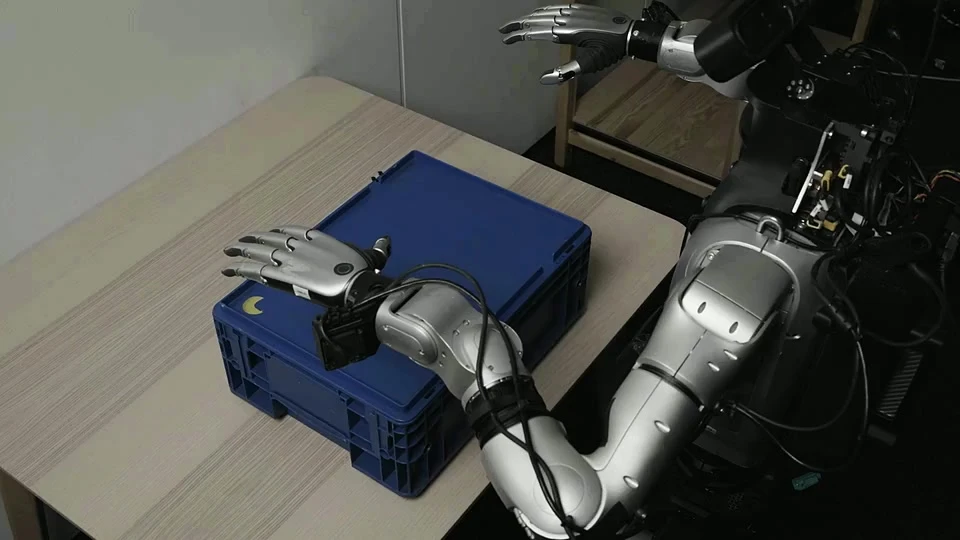
Unitree Robotics has initiated the open release of its UnifoLM-WLA-1.0 model, designed to improve humanoid robots' ability to perform complex tasks such as laundry handling. This model integrates visual understanding, task instructions, and predictive capabilities to enable coordinated movements of the robot's arms and lower body.
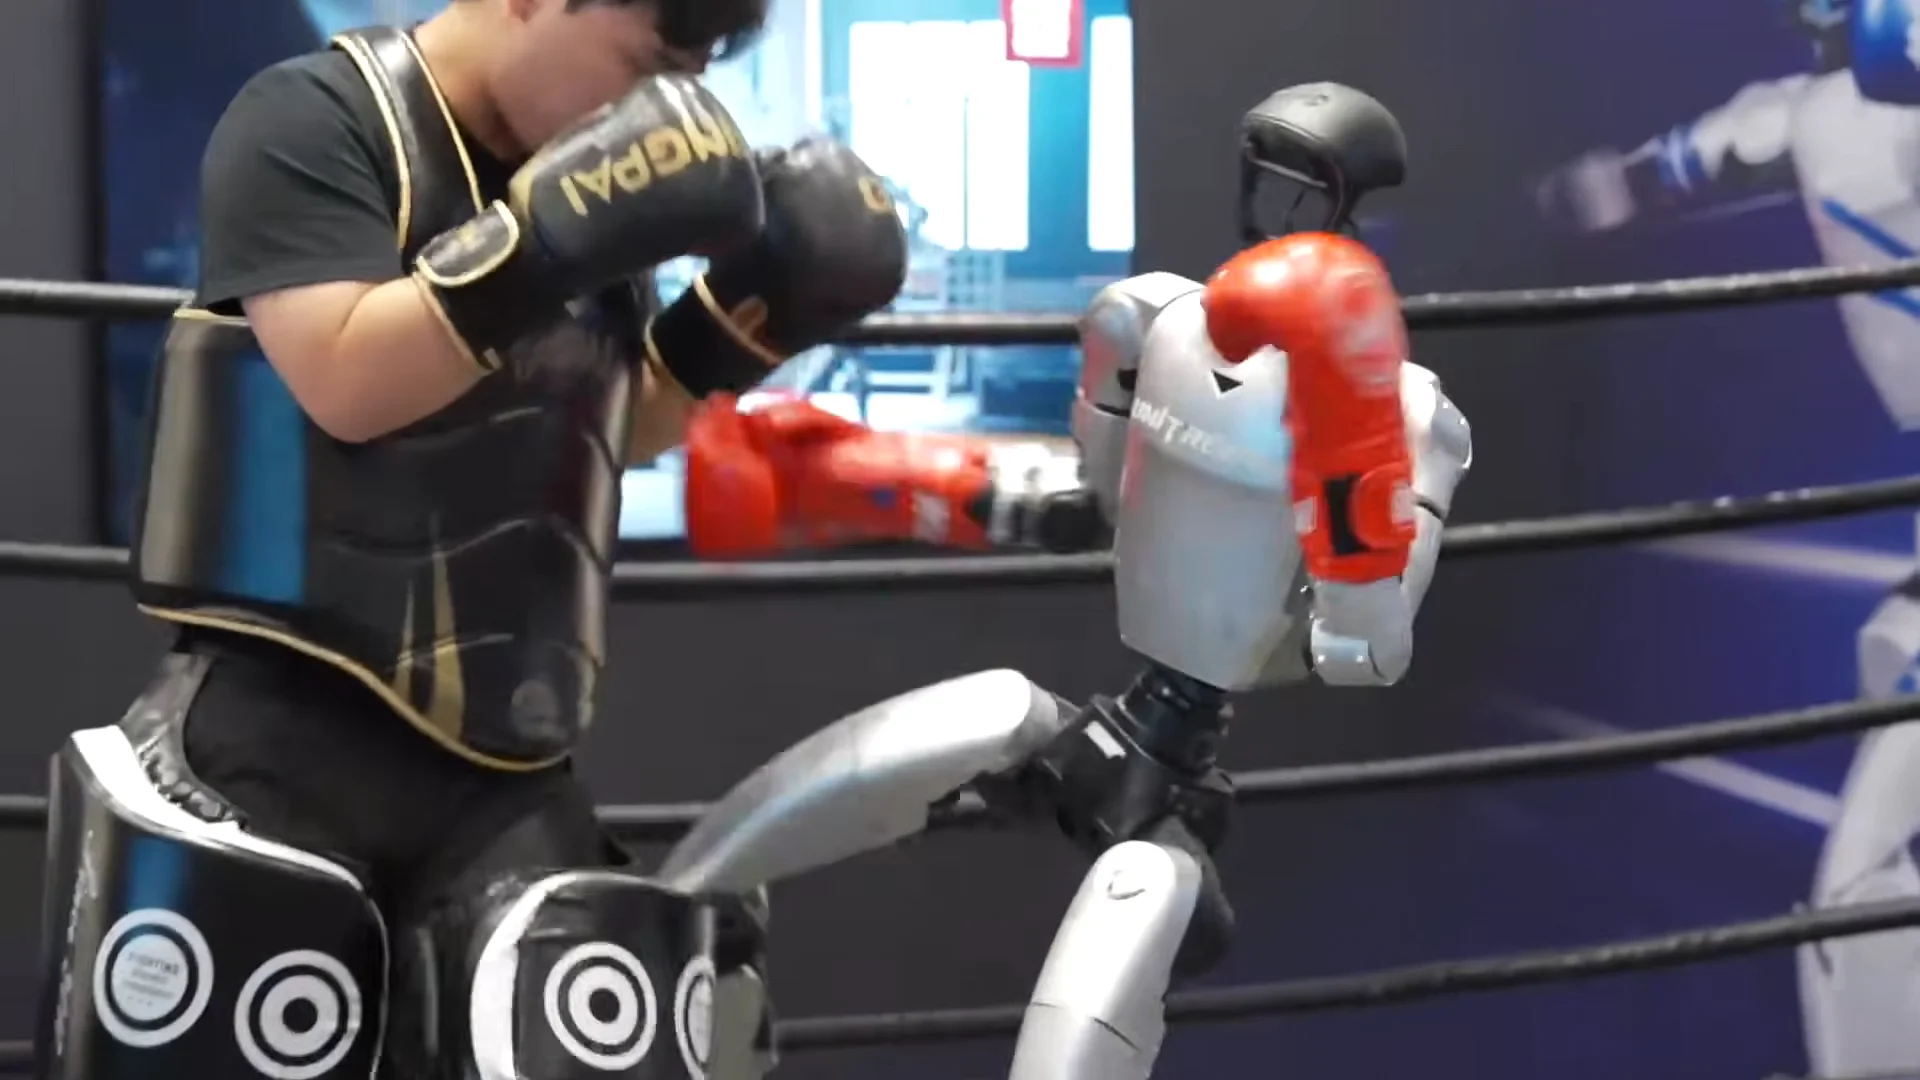
The significance of UnifoLM-WLA-1.0 lies in its potential to overcome the software limitations that currently restrict many humanoid robots to laboratory settings. With over 18,000 bipedal units manufactured, Unitree aims to enhance the practical applications of its robots in everyday environments, moving beyond mere demonstrations.
Looking ahead, Unitree's GitHub repository will serve as a key resource for researchers interested in the model's components, although the complete action model is still pending release. The architecture's focus on scene understanding, interaction prediction, and movement generation will be crucial for future developments in humanoid robotics.
Editor's Note
The launch of UnifoLM-WLA-1.0 by Unitree Robotics highlights a significant step towards practical humanoid applications in various environments. As the robotics industry continues to evolve, addressing software bottlenecks will be essential for broader deployment and acceptance of humanoid robots in everyday tasks. Stakeholders should monitor the progress of Unitree's releases and the implications for humanoid capabilities.












Leave a comment