

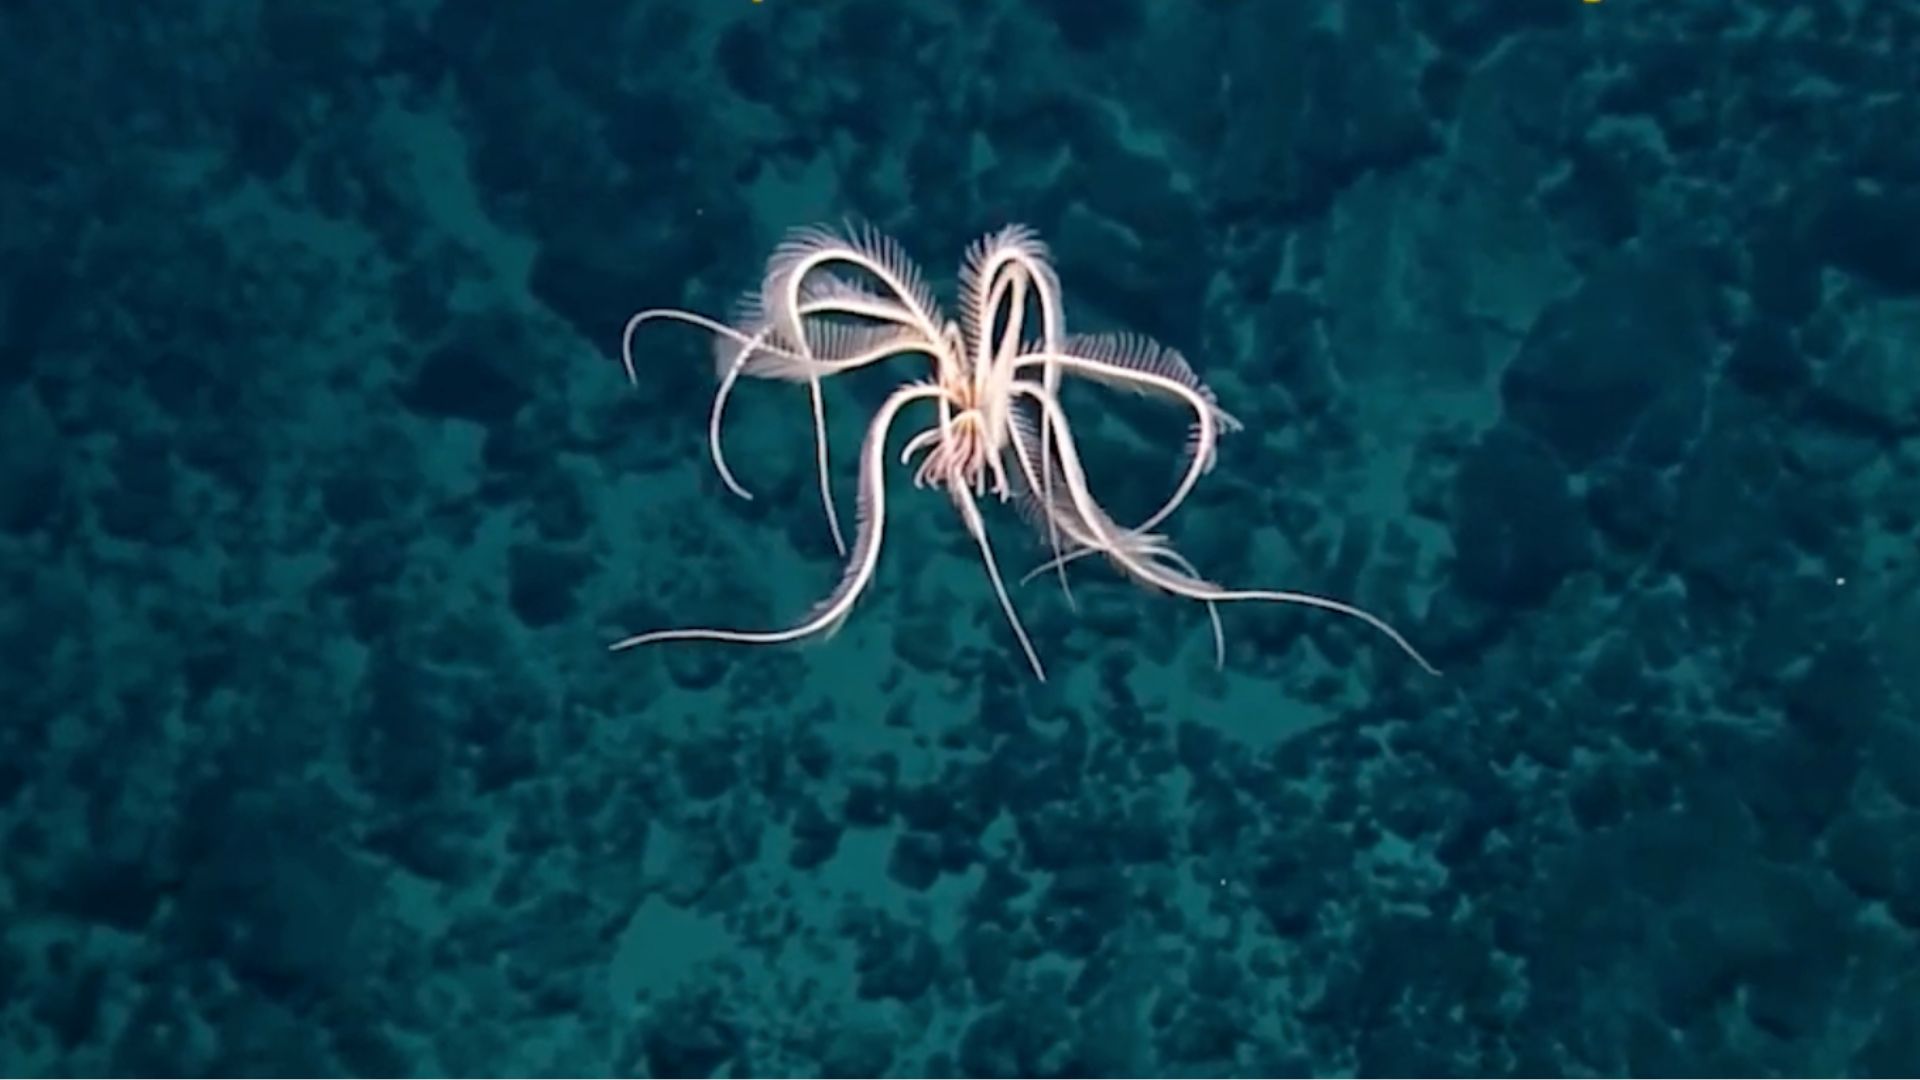
Researchers at North Carolina State University have created a soft underwater robot inspired by feather stars, capable of three-dimensional movement using only two actuators. This innovative design significantly reduces mechanical complexity, as traditional systems typically require six actuators for similar maneuverability.
The robot employs a principle known as 'mechanical intelligence,' allowing its structure and water interactions to minimize control input from operators. With four elastic wings arranged around a central disk, the robot can achieve various motions, including upward movement, hovering, and rotation, all while maintaining a streamlined design.
Future developments to watch include the robot's application in underwater exploration and object manipulation, as demonstrated by its ability to lift items and navigate environments using a camera. No further timeline was disclosed at the time of publication.
Editor's Note
The development of this feather star-inspired robot highlights a significant advancement in soft robotics and underwater maneuverability. By reducing the number of actuators needed for complex movements, this innovation could lead to more efficient designs in marine exploration and environmental monitoring, potentially transforming how underwater tasks are approached.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.











Leave a comment