DAAAM has made significant advancements in enhancing the spatiotemporal capabilities of autonomous systems by integrating real-time 4D scene graphs with detailed language descriptions derived from video input. This innovative approach aims to improve how autonomous systems perceive and interact with their environments, allowing for more sophisticated decision-making processes. The integration of 4D scene graphs enables these systems to understand complex spatial and temporal relationships, while the incorporation of rich language descriptions provides context and clarity to the visual data. This development is expected to have wide-ranging applications in various fields, including robotics, autonomous vehicles, and smart surveillance systems, ultimately leading to more efficient and effective autonomous operations.


New AI Framework Helps Robots Answer Spatiotemporal Questions
Robotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Uvision and Lendurai Collaborate to Integrate Systems for NATO Military Applications
Uvision, an Israeli company, and Lendurai from Estonia have announced a collaboration to integrate their systems for NATO military applications. The specifics of the military branch involved in this partnership remain undisclosed. This collaboration is significant as it highlights the increasing cooperation between technology firms and military organizati...
Air Warfare Global AI & Autonomy
Chen Pu of Yuan Ke Vision Discusses Transitioning Robot Training Data from 2D to 4D with High Precision
On September 23, Chen Pu, Vice President of Product Development at Yuan Ke Vision, highlighted the importance of high-quality real data for robot training during a seminar in Beijing. He emphasized the need to elevate data from 2D to 4D and improve precision from centimeter to sub-millimeter levels to build a robust 4D data foundation for robotics. This t...
Robot Training Data 4D Data Collection Industrial Robotics
RobotToday Weekly September 21 – 25, 2026
Cognex buys RealSense, Qualcomm acquires PickNik, the IFR counts 5 million factory robots, AGIBOT deploys 300 robots at Chimelong, and Tekever raises $580 million.
RobotToday Weekly
Arm Introduces Robotics Capability Framework for Intelligent Robot Descriptions
Arm, a semiconductor and software design company, has launched a Robotics Capability Framework aimed at providing a standardized language for the robotics industry. This initiative seeks to clarify ambiguous terms like 'autonomous' and 'intelligent' as AI becomes more integrated into robotic systems. The framework is designed to address the challenges pos...
Computing Design Engineering
Cognex Announces Acquisition of RealSense to Enhance Machine Vision in Robotic Perception
Cognex Corporation has entered into a definitive agreement to acquire RealSense, a leader in depth-sensing cameras and vision technology for robotic perception. This acquisition is poised to enhance Cognex's capabilities in the rapidly growing market of robotic perception, aligning with its strategy to diversify growth avenues. The addition of RealSense's...
York University Develops CBS Algorithm to Enhance Humanoid Robot Depth Perception
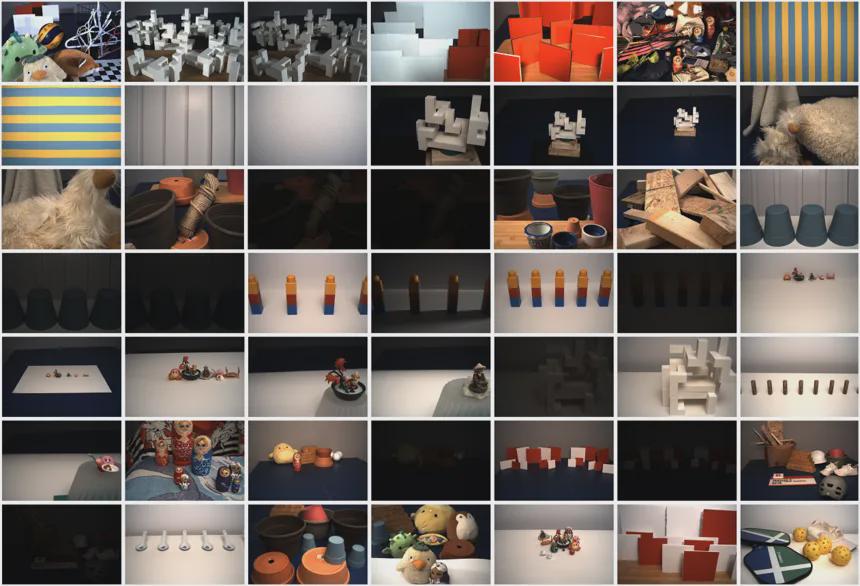
Researchers from York University have introduced the Convergent Binocular Stereo (CBS) algorithm to improve depth perception in humanoid robots. This innovative approach utilizes the movement of the robot's eyes, allowing them to converge on a target while calculating depth based on camera orientation and disparities in the images. This method significant...
Humanoid Robots Vision Systems Depth Perception
Jiushi Expands Its 30,000 Autonomous Vehicles into Urban Governance Applications
Jiushi has announced a strategic upgrade to its urban-level physical AI, aiming to extend its 'Jiushi Brain' capabilities beyond autonomous logistics vehicles. CEO Kong Qi emphasized that the company will leverage its extensive operational experience and data from over 30,000 vehicles, which have collectively traveled more than 250 million kilometers acro...
Autonomous Vehicles Urban Governance AI Technology
Ant International, Visa, and Mastercard Collaborate on Know-Your-Agent Framework for AI Payments
Ant International, Visa, and Mastercard have initiated the development of a Know-Your-Agent (KYA) interoperability framework aimed at enhancing AI-driven payments. This framework will assist card networks, digital wallets, agent platforms, and online marketplaces in identifying and onboarding reliable AI agents while maintaining existing verification and ...
News Feed
Kamiwaza AI Introduces Signal65 PINNACLE Framework for Enterprise AI Evaluations
Kamiwaza AI has launched Signal65 PINNACLE, an independent benchmarking framework designed for enterprise evaluations. This new framework is co-developed with and powered by Kamiwaza technology, enabling organizations to effectively assess their AI capabilities. The introduction of Signal65 PINNACLE is significant as it provides enterprises with a structu...

A Multilevel Path Planning Framework for Unmanned Surface Vehicles in Environmental Monitoring
A new multilevel path planning framework has been developed for unmanned surface vehicles (USVs) aimed at enhancing environmental monitoring of uninhabited islands and reefs. This framework utilizes information-driven techniques to optimize navigation and data collection processes in challenging marine environments. The significance of this development li...
RESEARCH ARTICLE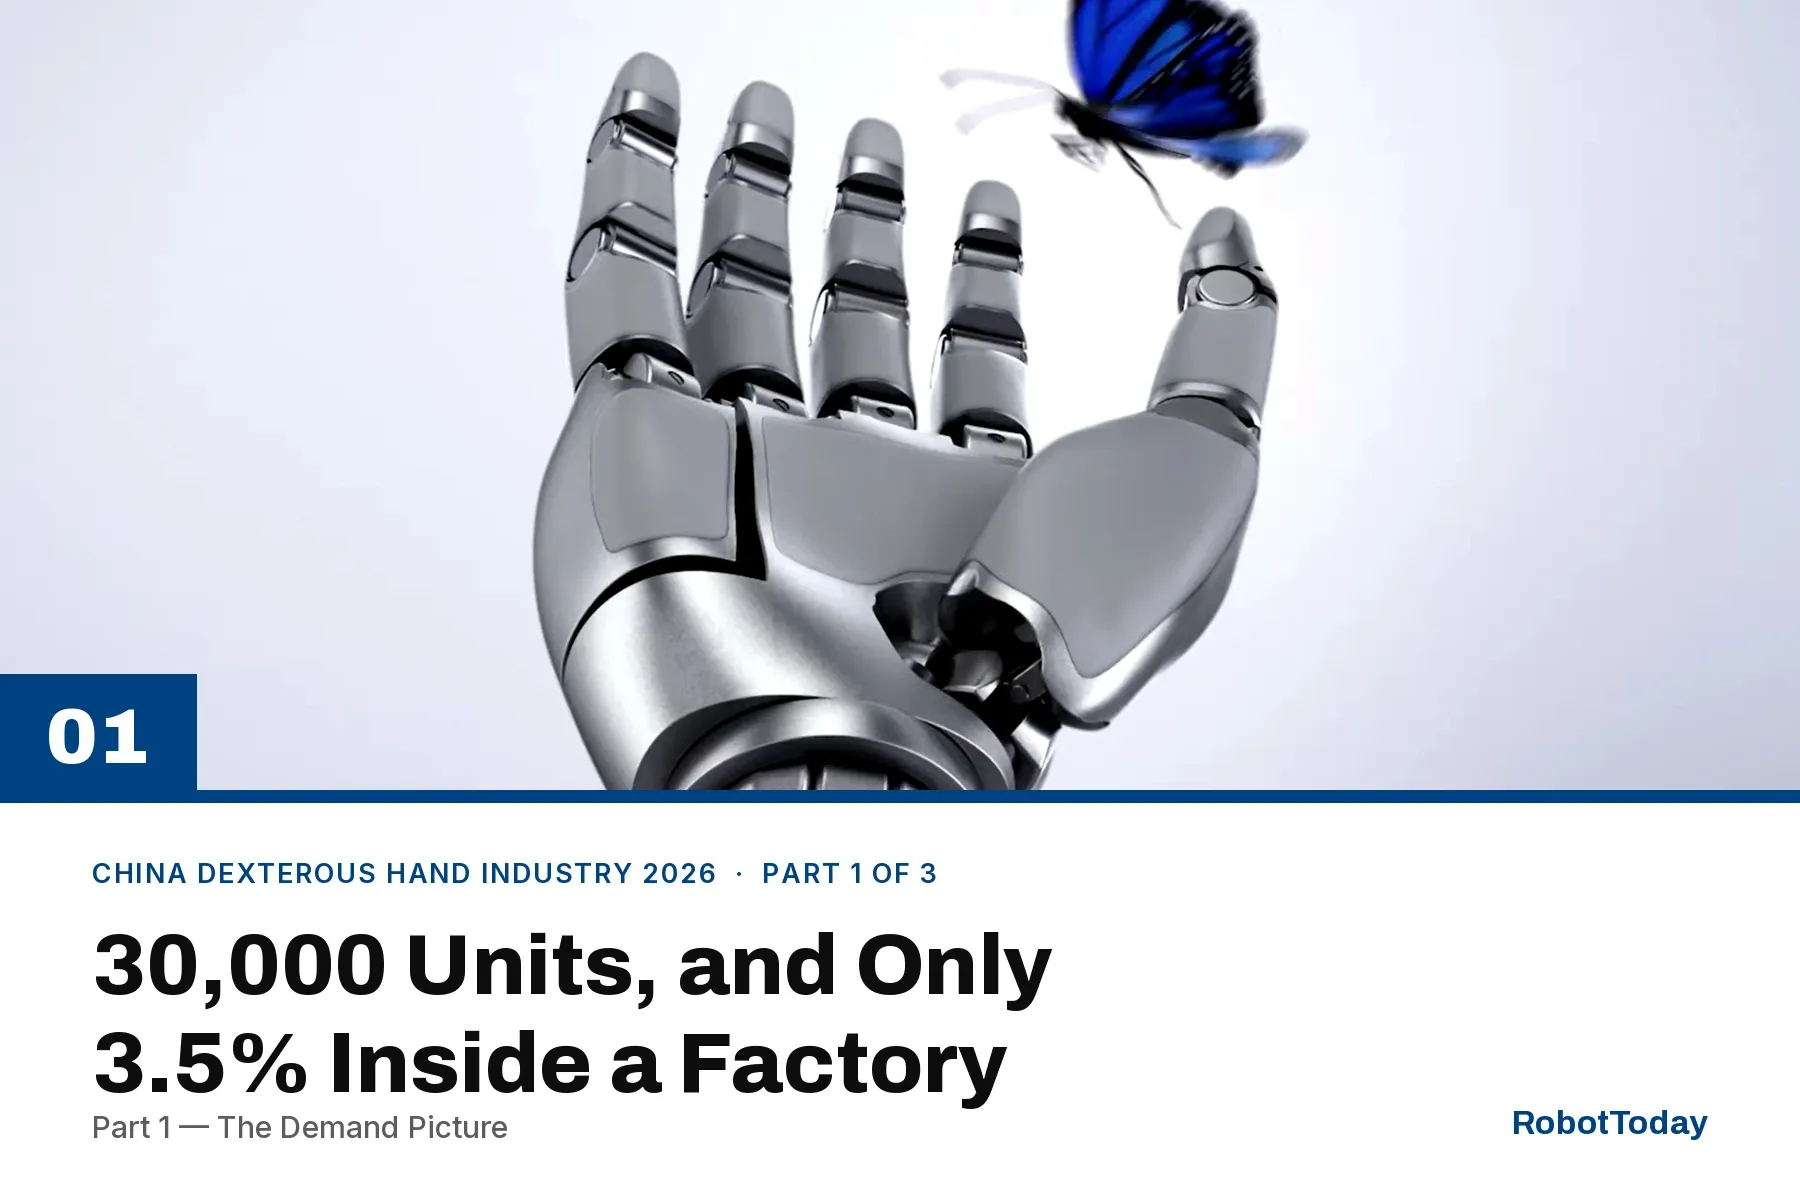
China’s Dexterous Hand Industry, 2026 Part 1 — The Demand Picture
MIR Databank puts China dexterous hand shipments above 30,000 units in 2026, yet only 3.5% of 2025 demand came from factory production. Part 1 of 3.
Components and Hardware Humanoids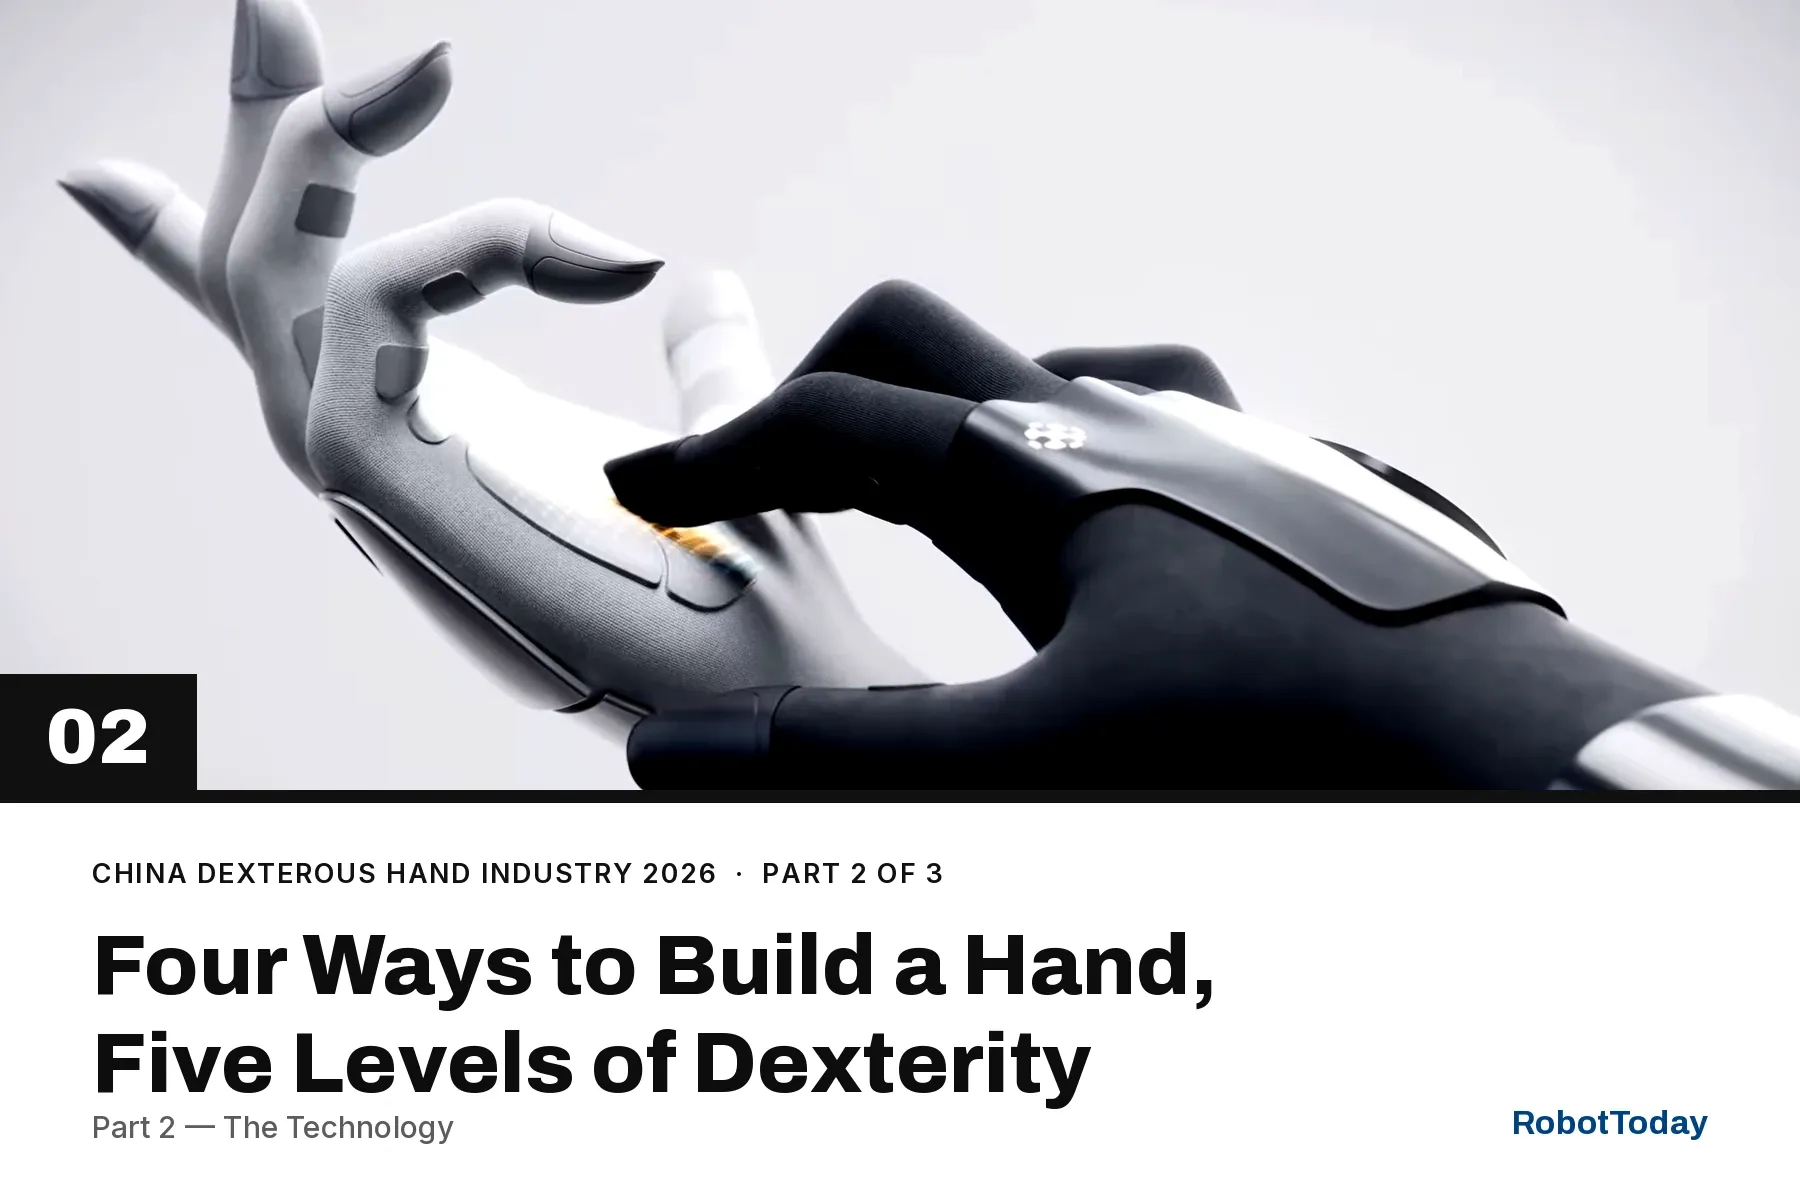
China’s Dexterous Hand Industry, 2026 Part 2 — The Technology
Linkage, tendon, direct drive or hybrid — and why hardware is converging while the DL1–DL5 manipulation scale decides who wins. Part 2 of 3.
Components and Hardware
Drone Delivery Canada
Canada
Vaughan, Ontario drone logistics developer merged with Volatus Aerospace in August 2024; the combined company trades as FLT in Toronto.
Duckietown Robotics
United States
Educational robotics platform provider offering autonomous vehicle kits and AI curricula used by 250+ universities worldwide.
EasyMile
France
Toulouse, France autonomous-vehicle software company founded 2014; EZTow and EZDolly systems automate industrial tow tractors and cargo movers at airports.
Machine Vision Lighting Inc.
Japan
Tokyo firm whose patented VISA-Method lighting delivers uniform illumination and one-step 3-D imaging for machine-vision inspection.
Tangram Vision
United States
Perception infrastructure software and hardware company enabling reliable sensor calibration and integration for robotics and autonomous systems.
CHINGMU VISION 上海青瞳视觉科技有限公司
China
Shanghai-based developer of optical motion capture systems for robotics, film, biomechanics, and rehabilitation applications.
Human in Motion Robotics
Canada
Vancouver, Canada medical-robotics company founded 2016 builds the XoMotion self-balancing exoskeleton for people with spinal cord injury or stroke.
LG Display
Korea, Republic of (South)
Seoul display maker (KRX:034220, NYSE:LPL), formed 1999, that launched plastic OLED humanoid-robot face panels for industrial settings in 2026.
Roboblock System Co., Ltd.
Korea, Republic of (South)
South Korean robotics distribution and development company founded in 1997; supplies AI robots, drones, humanoid kits, and VR/AR systems internationally.
Ortelio Ltd
United Kingdom
Ortelio Ltd is a UK cloud robotics research company founded in 2011 that develops AI platforms giving robots intelligence for service and healthcare tasks.
Parata Systems
United States
Durham, North Carolina pharmacy automation maker acquired by BD in 2022; builds robotic vial-filling and packaging systems.
Pensa Systems
United States
Austin-based AI retail shelf platform using autonomous drones and CV to detect stockouts; customers include J&J, AB InBev, and Circle K.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.








Leave a comment