

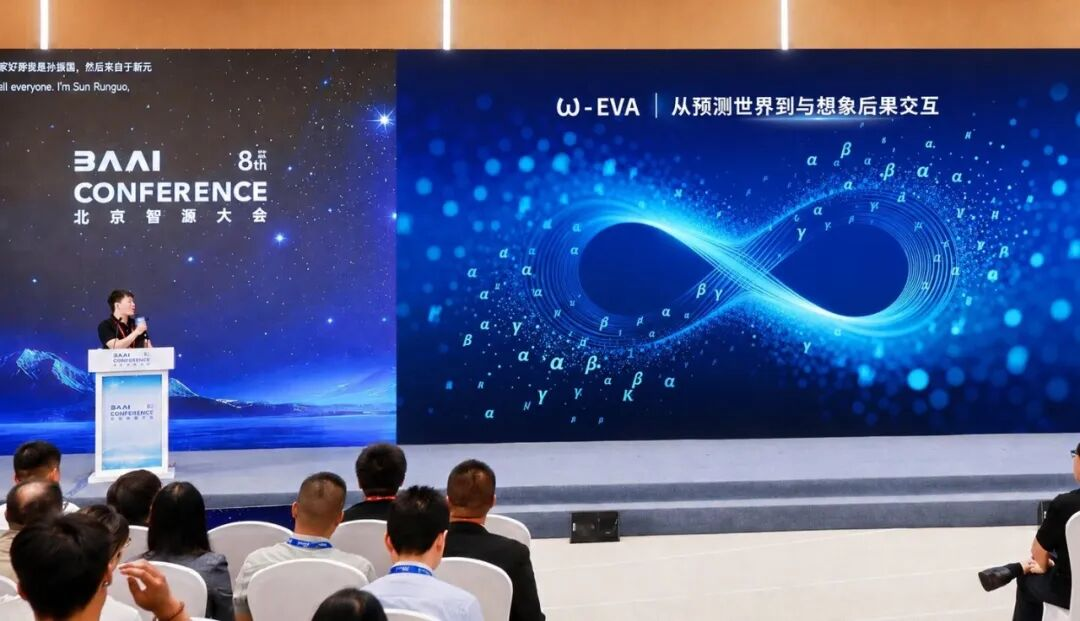
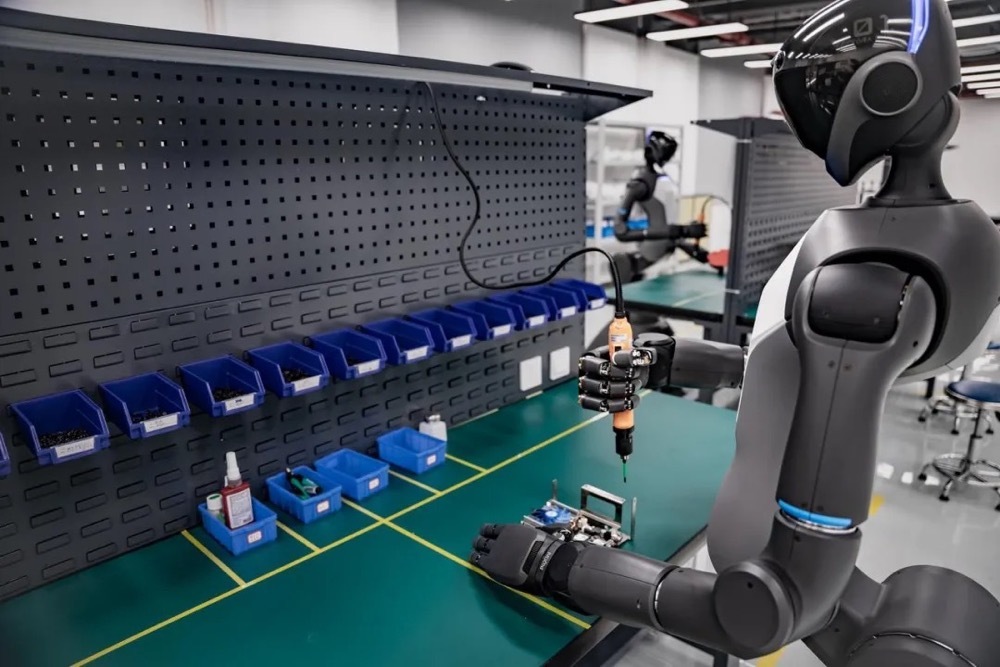
At the 8th Beijing Zhiyuan Conference, Xingyuan unveiled its innovative ω-EVA model, marking a significant advancement in the field of embodied intelligence. This model represents a shift from traditional world models, which have typically acted as passive observers, to a more dynamic role in robotic decision-making. By integrating real-time feedback into action generation, the ω-EVA model emphasizes the necessity of predicting outcomes prior to executing movements. This development highlights a broader industry trend towards the practical application of artificial intelligence capabilities, showcasing how robotics can evolve to become more responsive and effective in various tasks.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.















Leave a comment