

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.

Direct Drive Proposes Wheel-Legged Robots to Overcome Physical Access Challenges in Embodied AI
Chinese startup Direct Drive claims that the primary challenge for embodied robots is not the intelligence of their systems but rather their ability to physically access various environments. By integrating direct-drive actuators with innovative wheel-legged designs, these robots are engineered to navigate obstacles such as curbs, slopes, and mixed indoor-outdoor spaces. This approach is significant as it addresses a critical limitation in the deployment of embodied AI technologies. The ability to traverse diverse terrains enhances the functionality and applicability of robots in real-world scenarios, potentially expanding their use in sectors such as logistics, healthcare, and home assistance. Looking ahead, the focus will be on the practical implementation of these wheel-legged robots in various environments. No further timeline was disclosed at the time of publication.

Researchers Develop Six-Legged Robot Mimicking Stick Insect for Uneven Terrain Navigation
Researchers from Tohoku University and VISTEC have created a six-legged robot that learns to walk by imitating stick insect movements. This AI-powered system adapts its walking strategies to navigate various surfaces, potentially enhancing robotic operations in challenging environments such as disaster zones. The significance of this development lies in its ability to overcome limitations of traditional robotic gait systems, which often rely on fixed patterns. By employing adversarial inverse reinforcement learning (AIRL), the robot learns coordination principles from biological data, enabling it to maintain stability even on uneven terrain. Looking ahead, the ability of the robot to adapt to changes, such as losing a leg, demonstrates its potential for real-world applications. The researchers also noted that the learned reward structure could be transferred to different robot models, improving efficiency in training and adaptability across various robotic platforms. No further timeline was disclosed at the time of publication.
AI and Robotics
Six-Legged Robot Mimics Stick Insect to Enhance Walking Abilities
A six-legged robot has been developed to learn walking techniques inspired by stick insects. This innovation showcases how robotic systems can adopt biological strategies to navigate complex environments effectively. The significance of this advancement lies in its potential applications in robotics, where enhanced mobility can lead to improved performance in various tasks. By mimicking the dexterity of insects, robots may be able to tackle challenges in environments that are difficult for traditional machines. Looking ahead, further developments in this area could lead to robots that are not only more agile but also capable of performing complex tasks in diverse settings. No further timeline was disclosed at the time of publication.
Robotics
Robot.com Introduces R-dog: A Versatile Four-Legged Delivery and Engagement Robot
Robot.com has unveiled R-dog, a four-legged robotic platform intended for delivery, advertising, and engagement tasks. This innovative robot is designed to operate on REMI, Robot.com's fleet management and physical API layer, showcasing the company's commitment to advancing robotic solutions. The significance of R-dog lies in its potential to enhance operational efficiency in various sectors by integrating advanced autonomy features. The collaboration with FieldAI is crucial, as their general-purpose Field Foundation Models will provide the necessary autonomy capabilities, positioning R-dog as a versatile tool for businesses. Looking ahead, the evolution of R-dog into a production version will be closely monitored. The partnership with FieldAI is expected to yield significant advancements in robotic autonomy, making R-dog a noteworthy development in the robotics landscape. No further timeline was disclosed at the time of publication.

Seoul Tech Develops 3D-Printed Footpad for Energy-Efficient Four-Legged Robots
A research team from Seoul Tech has created a flexible, 3D-printed footpad for four-legged robots that can absorb and release energy, enhancing efficiency. This design enables robots to save between 1.4% to 6.2% of energy during movement, presenting a viable alternative to conventional energy recovery techniques. The significance of this development lies in its potential to improve the operational efficiency of robotic systems, particularly in applications such as inspection and logistics. The integration of an AI controller further optimizes the robot's gait, expanding its operational range and effectiveness in various tasks. Looking ahead, the focus will be on the practical applications of this technology in real-world scenarios. No further timeline was disclosed at the time of publication.
Robotics Energy Efficiency 3D Printing AI Control Automation
Recent Developments and Challenges in Legged Robotics: A Detailed Overview
Legged robots, once a concept of science fiction, are now capable of delivering packages directly to homes and navigating challenging rescue scenarios. A comprehensive review published in the journal Science Robotics, authored by researchers from leading institutions including ETH Zurich, Stanford University, and NVIDIA, examines advancements in legged robotics across hardware, motion control, autonomy, data, and applications, while also addressing ethical, economic, and policy considerations. This review highlights the evolution of legged robotics, tracing its origins from the 1960s with projects like the hydraulic-powered Walking Truck to the dynamic stability breakthroughs led by Marc Raibert. The transition from static to dynamic stability has enabled quadrupedal robots to carry loads exceeding 180 kilograms, while bipedal robots face challenges due to their reliance on dynamic stability. Looking ahead, the review emphasizes the need for high-torque actuators with low mechanical impedance to enhance performance. Innovations in electric drive systems and sensor miniaturization are paving the way for more capable legged robots. However, challenges remain in manufacturing, durability, and control, particularly for bio-inspired technologies. No further timeline was disclosed at the time of publication.
Legged Robotics Motion Control Autonomy Robotics Research Ethics in Robotics
Legged Robots Spark Concerns Over Surveillance, Employment, and Military Accountability
Legged robots have evolved from science fiction to practical engineering, now performing tasks such as package delivery and military operations. This shift highlights significant advancements in technology, driven by increased financial investment in the sector. The emergence of these humanoid and quadrupedal machines raises important ethical questions and economic opportunities, as they become more integrated into everyday life. The implications of their use in surveillance and military contexts are particularly pressing, prompting discussions on accountability and regulation. As the technology continues to develop, stakeholders should monitor the evolving landscape of legged robots, particularly regarding their deployment in sensitive areas. No further timeline was disclosed at the time of publication.
Robotics
Exploring the Advances, Challenges, and Opportunities in Legged Robots
The article discusses the latest advancements in legged robots as detailed in Science Robotics, Volume 11, Issue 116, published in July 2026. It highlights the technological innovations that have improved the mobility and functionality of these robots, making them more applicable in various environments. Understanding the challenges faced by legged robots is crucial for their future development. The article emphasizes issues such as stability, energy efficiency, and adaptability, which must be addressed to enhance their performance in real-world applications. These challenges present both hurdles and opportunities for researchers and developers in the field. Looking ahead, the article suggests that ongoing research and development will focus on overcoming these challenges while exploring new applications for legged robots. No further timeline was disclosed at the time of publication.
Review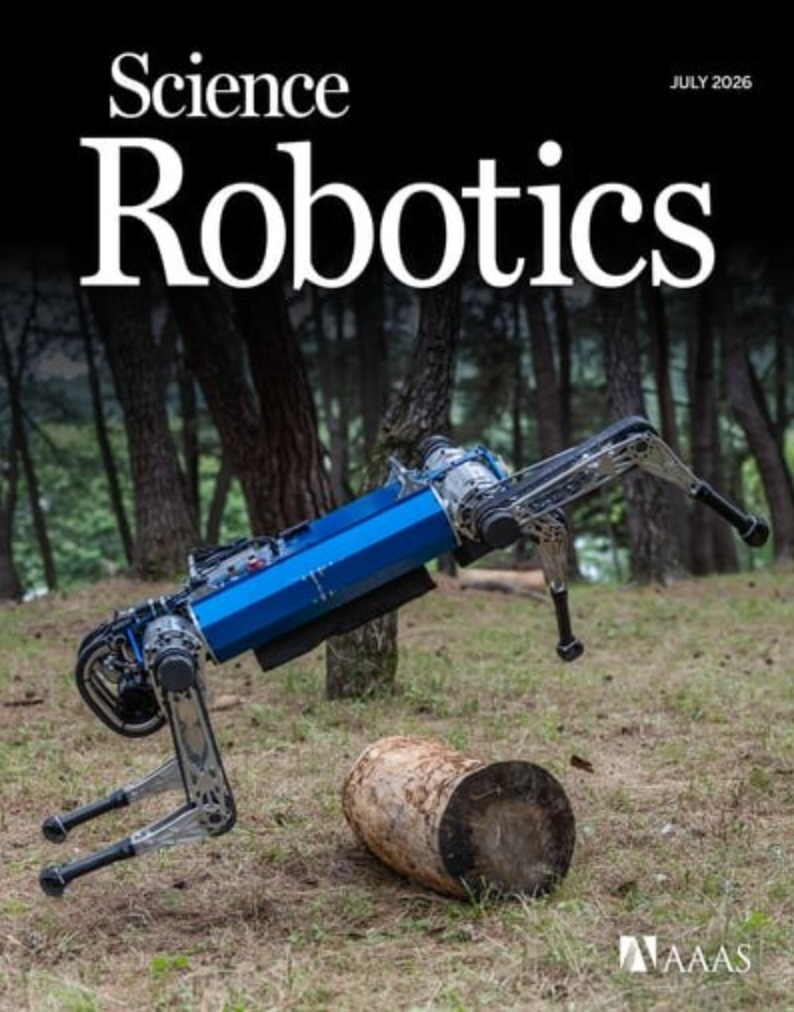
KAIST Unveils Advanced Four-Legged Robot with Autonomous Navigation Technology
KAIST's mechanical engineering team, led by Professor Park Hai-won, announced a breakthrough in robotic technology on July 16. They developed a four-legged robot capable of autonomously selecting and switching between various gaits in real-time, enabling it to navigate complex outdoor environments with speed and stability. This innovation is significant as it integrates a new control architecture called APT-RL (Action Pre-training Reinforcement Learning based on Transformers), which allows the robot to learn movement through computer simulations rather than traditional motion capture. The robot, named KAIST HOUND, demonstrated its capabilities by traversing diverse terrains, achieving peak speeds of 6 meters per second, faster than an average cyclist. Future developments to watch include the potential applications of this technology in disaster response, defense tasks, and industrial inspections. The research was published in the July issue of the journal Science Robotics, highlighting its importance in advancing the field of robotic control and physical AI.
Four-Legged Robots Robotics Technology AI Autonomous Navigation
China Unveils Xiaoyuan, the First Wheeled and Legged Robot Guide Dog for the Visually Impaired
The Zhiyuan Research Institute in China has introduced Xiaoyuan, the world's first wheeled and legged robot guide dog designed for visually impaired individuals. Launched at the China Care and Rehabilitation Expo in Beijing, this innovative robot features a combination of wheels for smooth movement on flat surfaces and four legs for navigating stairs, enhancing independence for its users. This development is significant as it highlights the growing integration of AI and robotics into civilian applications, particularly in aiding those with disabilities. The robot's quiet operation is crucial for users who depend on auditory cues, and its ability to detect overhead obstacles offers advantages over traditional mobility aids like canes. Xiaoyuan boasts impressive technical specifications, including centimetre-level outdoor positioning accuracy and high obstacle-avoidance success rates. The robot is also connected to various support services, enabling users to access remote assistance when necessary. No further timeline was disclosed at the time of publication.

Galileo Unveils Galileo X: A Unified Ground Mobility Platform for Diverse Environments
Chinese robotics company Galileo has introduced Galileo X, a groundbreaking ground mobility platform that integrates wheeled, off-road, and legged robot capabilities. Unveiled at the 2026 World Robot Conference in Beijing, this innovative system aims to provide a versatile solution for various operational environments by bridging the gaps between different robotic architectures. The significance of Galileo X lies in its ability to combine the precise transport capabilities of wheeled automated guided vehicles (AGVs) with the long-range mobility of off-road vehicles and the adaptability of legged robots. This unified approach allows for a single platform to handle diverse tasks, reducing the complexity and need for multiple specialized machines in challenging terrains. Looking ahead, the potential applications of Galileo X are vast, ranging from heavy-duty off-road handling to warehouse logistics and mobile inspection tasks. No further timeline was disclosed at the time of publication, but the platform's development reflects Galileo's commitment to embodied intelligence and in-house technological advancements in robotics.
AI and Robotics
Quadrupedal Robot Learns Agile Jumping Through Narrow Openings Using AI
Researchers at the University of Hong Kong and the Oxford Robotics Institute have developed a learning-based system that enables four-legged robots to navigate through narrow gaps autonomously. This innovative approach allows quadrupedal robots to perform agile movements, inspired by the natural jumping abilities of dogs, without relying on pre-programmed sequences. The technology, demonstrated on the 48-pound Unitree Aliengo robot, utilizes a hierarchical reinforcement learning framework called ConsJump. This system allows the robot to assess obstacles and dynamically decide when to jump, enhancing its ability to traverse confined spaces quickly and efficiently. The robot's onboard Intel D435i RGB-D camera plays a crucial role in identifying obstacles and adjusting its movements accordingly. Future developments may focus on refining the robot's adaptability to various environments and conditions. The researchers believe that the same architecture could be applied to other complex robotic tasks, potentially leading to advancements in robotic agility and autonomy in challenging terrains. No further timeline was disclosed at the time of publication.
AI and Robotics
Quadrupedal Robot Develops Dog-like Agility for Navigating Tight Spaces
Recent advancements in robotics have led to the development of a quadrupedal robot that mimics the agile movements of dogs and other four-legged animals. This robot is designed to leap and maneuver through tight spaces, showcasing improved agility compared to previous models. The ability to replicate such movements is significant as it opens up new possibilities for robotic applications in environments where space is limited. This advancement could enhance the functionality of robots in various sectors, including search and rescue operations, where navigating through confined areas is crucial. Looking ahead, the focus will be on refining these movements further and integrating advanced sensors to improve the robot's adaptability in dynamic environments. No further timeline was disclosed at the time of publication.
Robotics
Legged Robots Learn Dynamic Movements Through Motion-Imitation Framework
Legged robots, which mimic the movements of animals or humans, are being enhanced through a motion-imitation framework that teaches them dynamic movements such as cartwheels and backflips. This advancement addresses the challenge of reliably replicating complex whole-body movements in a short time frame. The ability to perform intricate movements is crucial for legged robots, especially in home environments or populated areas where dynamic tasks are common. By improving their motion capabilities, these robots can become more effective in navigating and interacting within these spaces, potentially increasing their utility in everyday applications. Looking ahead, the continued development of motion-imitation frameworks could lead to even more sophisticated movement capabilities for legged robots. No further timeline was disclosed at the time of publication.
Robotics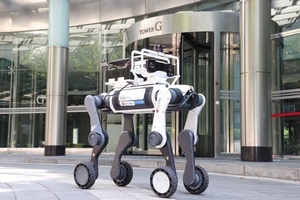
LG CNS Introduces Four-Legged Security Robot at Tower Palace in Seoul
LG CNS has deployed a four-legged security robot at Tower Palace, a luxury complex in southern Seoul. This marks the company's first venture of its physical AI platform into a residential environment, previously utilized in factories and warehouses. The significance of this deployment lies in LG CNS's ability to enhance security through advanced robotics. The robot will autonomously patrol common areas and underground parking, identifying suspicious activities and alerting management, thereby improving safety for residents. Looking ahead, LG CNS plans to conduct approximately two months of technical validation before full operations commence in the fourth quarter. The integration of the PhysicalWorks platform is expected to streamline the deployment of robots in various settings, with future expansions of AI robot services anticipated.
All News
QuadBoat: A Spider-Inspired Robotic Boat for Water Rescue Operations
Researchers at the Shenzhen Institute of Artificial Intelligence and Robotics for Society and Stevens Institute of Technology have developed QuadBoat, a four-legged robotic boat designed to track and retrieve individuals from water. Unlike traditional unmanned surface vehicles, QuadBoat can physically extract victims, addressing a critical gap in maritime rescue operations. The significance of QuadBoat lies in its innovative design, inspired by fishing spiders, which allows it to maneuver effectively on water. The robot employs a unique combination of buoyancy and leg propulsion, enabling it to adapt its posture for optimal movement. This capability is crucial for rescue missions, where swift extraction from water can be life-saving. Future developments to watch include the potential deployment of QuadBoat in emergency scenarios such as boat crashes. The robot's advanced tracking and retrieval capabilities could enhance the efficiency of rescue teams, particularly in challenging conditions where traditional vehicles may falter. No further timeline was disclosed at the time of publication.
AI and Robotics
Engineers Create Autonomous Four-Legged Robot That Adapts Gait to Environment
Engineers have developed a groundbreaking four-legged robot capable of autonomously determining its walking strategy based on its environment. This innovative robot can adjust its gait when navigating stairs, leap over gaps, and maintain balance on uneven forest trails. The significance of this development lies in its potential applications across various fields, including search and rescue operations, outdoor exploration, and even entertainment. By mimicking the adaptive movement of animals and humans, this robot represents a significant advancement in robotics, enhancing mobility and versatility in challenging terrains. Looking ahead, the focus will be on further refining the robot's capabilities and exploring its deployment in real-world scenarios. No further timeline was disclosed at the time of publication.
Robotics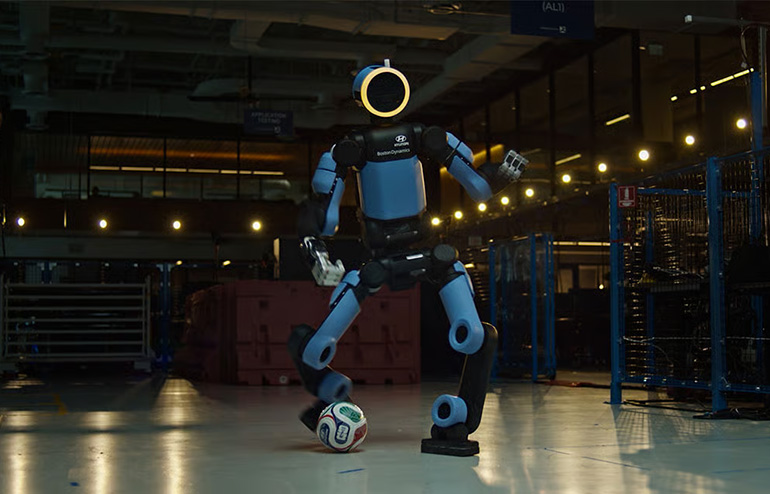
Boston Dynamics brings its legged robots to the FIFA World Cup
Around the 2026 FIFA World Cup, Hyundai and Boston Dynamics have taught footwork to the Atlas humanoid, while the Spot robot is on patrol. The post Boston Dynamics brings its legged robots to the FIFA World Cup appeared first on The Robot Report.
Artificial Intelligence Autonomous Mobile Robots (AMRs) Controllers Defense / Security Humanoids Mobility / Navigation
Four-legged detection robots for safe firefighting operations
Researchers at TU Graz have developed an advanced detection robot capable of identifying hazardous substances, designed to assist fire services during high-risk operations. This innovative technology serves as a remote-controlled advance guard, enhancing safety and efficiency in emergency situations. A recent study highlights the potential integration of this high-tech tool into fire service teams, demonstrating its effectiveness in supporting personnel on the ground. By employing the robot, fire services can better manage dangerous environments, ultimately aiming to protect both responders and the public.
Robotics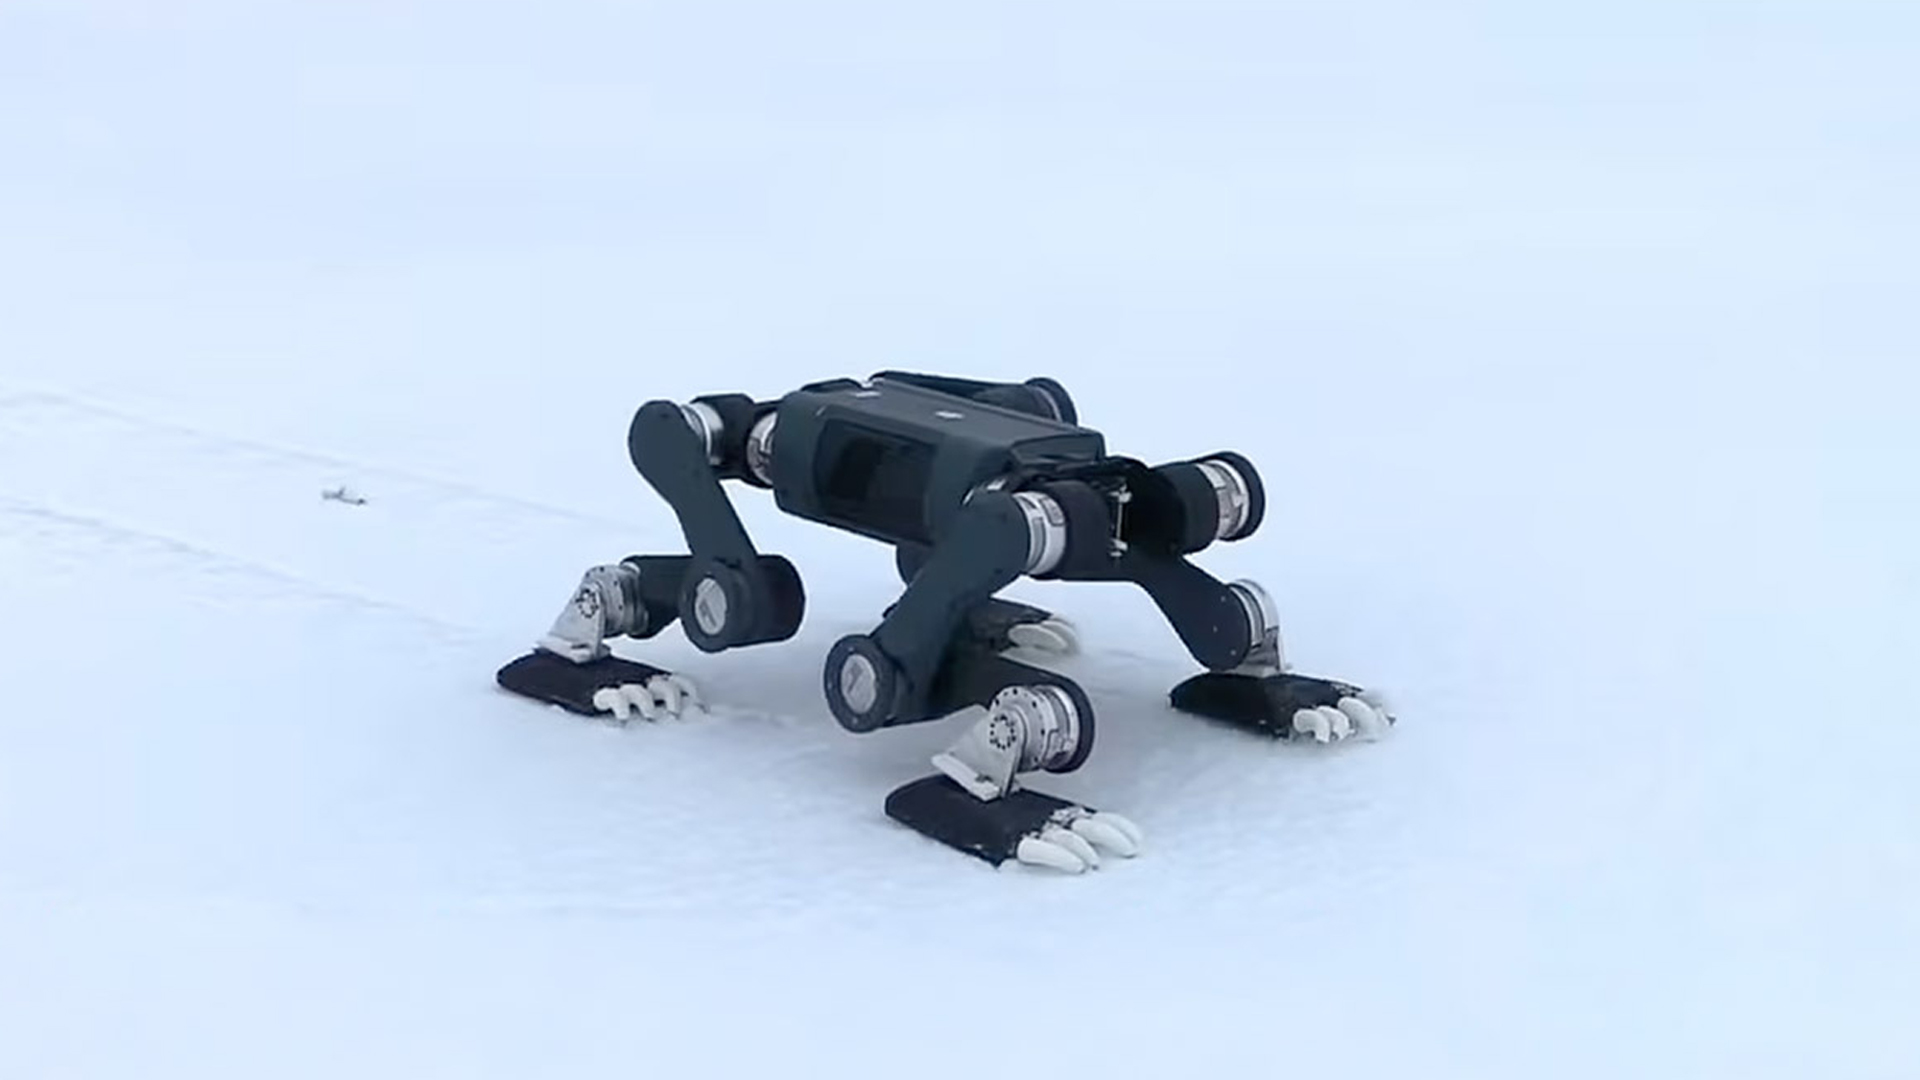
First-ever: Four-legged robot dog successfully walks across treacherous Arctic ice floes
The Arctic, long regarded as one of the most perilous regions on the planet, is facing unprecedented challenges due to climate change and increased human activity. Recent studies reveal that rising temperatures are accelerating ice melt, leading to more accessible shipping routes and resource extraction opportunities. This shift, occurring over the past few years, has prompted nations to stake claims in the region, intensifying geopolitical tensions. In response to these developments, various governments and environmental organizations are advocating for stronger regulations to protect the fragile Arctic ecosystem. The urgency of the situation has led to international discussions aimed at establishing guidelines for sustainable practices in the area. As countries scramble to assert their interests, the potential for conflict looms, raising concerns about the environmental impact and the rights of Indigenous communities. The situation is further complicated by the ongoing effects of global warming, which are expected to exacerbate the challenges faced by the Arctic. Scientists warn that without immediate action, the consequences could be dire, not only for the region but for the entire planet. As the world watches, the Arctic stands at a crossroads, where the balance between economic opportunity and environmental preservation hangs in the balance.
Culture Innovation
Four-legged robot dog spots hazardous toxins before firefighters enter danger zones
A groundbreaking four-legged robot dog, engineered to identify toxic substances, is poised to serve as a first responder in hazardous situations. Developed by a team of researchers and engineers, this innovative technology aims to enhance safety protocols in environments where chemical exposure poses significant risks. The robot's deployment is anticipated to occur in the coming months, with trials set to take place in various industrial settings and disaster response scenarios. The motivation behind this advancement stems from the increasing need for effective monitoring and rapid response to chemical spills and leaks, which can have dire consequences for both human health and the environment. By utilizing advanced sensors and artificial intelligence, the robot dog can navigate challenging terrains and provide real-time data on toxic substance levels, allowing human responders to make informed decisions. As the project progresses, the team is focused on refining the robot's capabilities and ensuring its reliability in real-world applications. This initiative represents a significant step forward in the integration of robotics into emergency response, potentially revolutionizing how hazardous situations are managed and mitigating risks associated with toxic exposures.
AI and Robotics
A Low‐Drift Legged Robot State‐Estimation System Through Combined Physics‐Informed Contact Estimation Network and Full Joint State
A recent study published in the Journal of Field Robotics highlights advancements in autonomous robotic systems designed for agricultural applications. Researchers from various institutions collaborated to develop innovative algorithms that enhance the efficiency and precision of farming robots. The findings, released in early October 2023, demonstrate how these technologies can significantly improve crop monitoring and management. The study was conducted across multiple farms in the Midwest, where the team tested the robots' capabilities in real-world conditions. By utilizing advanced sensors and machine learning techniques, the robots were able to identify crop health issues and optimize resource usage, such as water and fertilizers. This approach not only aims to increase agricultural productivity but also addresses sustainability concerns in farming practices. The motivation behind this research stems from the growing need for efficient food production methods to meet the demands of a rising global population. As traditional farming faces challenges such as labor shortages and environmental impacts, the integration of autonomous systems presents a viable solution. The researchers emphasized that the successful implementation of these technologies could lead to a transformative shift in how agriculture is practiced, ultimately benefiting both farmers and consumers alike.
RESEARCH ARTICLE
Revolutionizing Robotics: Breakthrough 20-Legged Robot Approaches Theoretical Limits
A research team at Duke University has unveiled Argus, an innovative 20-legged robot engineered for superior movement in multiple directions. This advanced robot utilizes a unique design principle known as 'dynamic isotropy,' which enhances its stability, energy efficiency, and adaptability across various terrains. The development of Argus marks a significant advancement in robotic technology, highlighting the potential for future innovations in the field of discovery robotics.
Robotics Dynamic Isotropy Modular Robots Terrain Navigation Discovery Robotics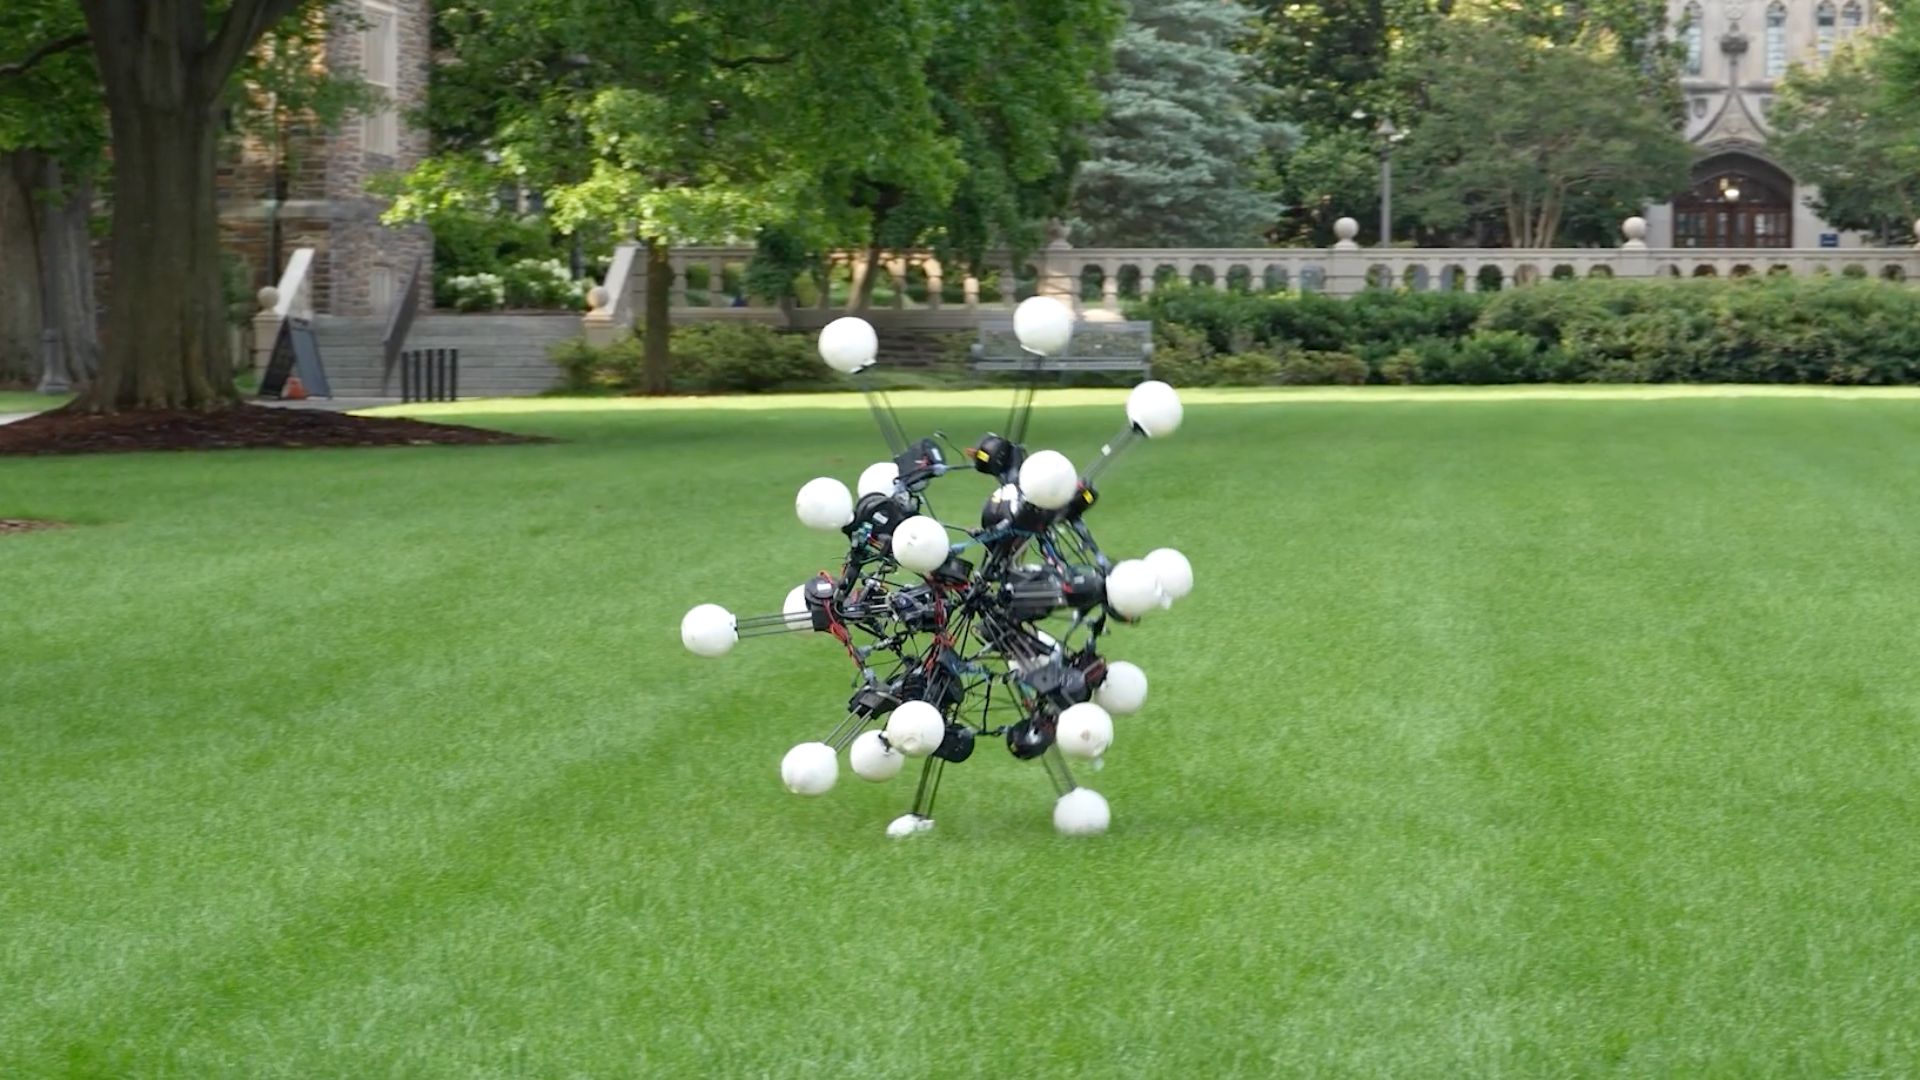
New 20-legged Argus robot redefines robotics with directionless movement design
Researchers at Duke University have unveiled an innovative robotic system that redefines conventional design principles in robotics. This groundbreaking development, announced on October 15, 2023, aims to enhance the adaptability and functionality of robots in various environments. Located in Durham, North Carolina, the team’s work is driven by the need for more versatile robots capable of performing complex tasks in unpredictable settings. The new system employs advanced algorithms and flexible materials, allowing robots to adjust their shapes and movements in real-time based on their surroundings. This adaptability is crucial for applications ranging from search and rescue missions to automated manufacturing processes, where conditions can change rapidly and unpredictably. By integrating insights from biology and engineering, the researchers have created a platform that not only improves the robots' operational efficiency but also reduces the need for extensive reprogramming when faced with new challenges. The implications of this technology extend beyond robotics, potentially influencing fields such as artificial intelligence and materials science. This innovative approach represents a significant step forward in robotic design, promising to enhance the capabilities of machines in both industrial and everyday applications. As the research progresses, the team at Duke University aims to collaborate with industry partners to bring these advancements to practical use, ultimately transforming how robots interact with the world around them.

It looks like a sea urchin, but this strange 20-legged machine is rewriting what robots can do
Roboticists have long sought to replicate the diverse forms and functionalities found in nature, drawing inspiration from the symmetry observed in various organisms, such as the bilateral structure of vertebrates and the radial patterns of starfish. This endeavor has spanned decades, with researchers developing robots that mimic the appearances and movements of humans, dogs, and insects. The ongoing exploration into biomimicry aims to enhance robotic design and performance by integrating the efficient and adaptive traits seen in living creatures. As technology advances, these efforts continue to push the boundaries of robotics, potentially leading to more versatile and capable machines in the future.
Robotics
Look back on 10 years of legged robots with Ghost Robotics at the Robotics Summit
At the upcoming Robotics Summit, Gavin Kenneally, the CEO and co-founder of Ghost Robotics, will reflect on a decade of experience in deploying quadruped robots. This presentation aims to share valuable insights and lessons learned from the company's journey in the field of legged robotics. The event will take place in the near future, providing an opportunity for industry professionals and enthusiasts to engage with advancements in robotic technology and explore the impact of these innovations. Kenneally's talk will highlight the evolution of quadruped robots and their applications, emphasizing the significance of this technology in various sectors.
Autonomous Mobile Robots (AMRs) Events News Robots / Platforms Ghost Robotics
Unitree Robotics demonstrates wheeled-legged humanoid robot capable of skating and advanced flips
Unitree Robotics has unveiled an innovative wheeled-legged humanoid robot that showcases remarkable capabilities, including skating, spinning, and executing front flips. This demonstration, which took place recently, underscores significant advancements in dynamic motion control technology. The robot's design integrates both wheels and legs, allowing for enhanced mobility and agility, which could have various applications in industries ranging from entertainment to logistics. By pushing the boundaries of robotic movement, Unitree Robotics aims to revolutionize how machines interact with their environments, potentially paving the way for more versatile and efficient robotic solutions in the future.
News
4SWLR: A Switched System and Skid Steer Integrated Whole‐Body Control Framework for Wheeled‐Legged Robots
A recent study published in the Journal of Field Robotics highlights advancements in autonomous robotic navigation. Researchers from a leading university conducted experiments to improve the efficiency and accuracy of robots in complex environments. The study, released in early October 2023, focuses on the integration of artificial intelligence and machine learning algorithms to enhance decision-making processes in real-time. The research team aimed to address challenges faced by robots in dynamic settings, such as unpredictable obstacles and varying terrain. By employing advanced sensing technologies and adaptive algorithms, the robots demonstrated significant improvements in their ability to navigate and perform tasks autonomously. The experiments were conducted in various locations, including urban settings and natural landscapes, to test the robots' adaptability and performance under different conditions. The findings suggest that these innovations could lead to more effective applications in fields such as search and rescue, agriculture, and environmental monitoring. This study underscores the growing importance of robotics in addressing real-world challenges and the potential for continued advancements in the field. The researchers believe that their work could pave the way for more sophisticated robotic systems capable of operating independently in increasingly complex environments.
RESEARCH ARTICLE
Real‐Time Behavior Recognition Using a Legged Robot for Animal–Robot Interaction
A recent study published in the Journal of Field Robotics highlights advancements in robotic technologies aimed at enhancing agricultural practices. Researchers from various institutions collaborated to explore innovative solutions for improving crop management and efficiency. The findings, released in May 2026, underscore the growing need for automation in agriculture due to increasing labor shortages and the demand for higher productivity. The study focuses on the development of autonomous robots capable of performing tasks such as planting, monitoring, and harvesting crops. By integrating artificial intelligence and machine learning, these robots can analyze soil conditions and optimize resource use, ultimately aiming to reduce waste and increase yield. The research was conducted in various agricultural settings, demonstrating the versatility and adaptability of these robotic systems. This initiative is driven by the urgent need to address food security challenges posed by a rising global population and climate change. The researchers emphasize that implementing such technologies could significantly transform traditional farming methods, making them more sustainable and efficient. As the agricultural sector continues to evolve, the successful deployment of these robotic solutions could pave the way for a new era in farming, ensuring that food production meets future demands while minimizing environmental impact.
RESEARCH ARTICLE
CES 2026: world’s first wheel-legged robot vacuum designed to tackle stairs and multi-level homes
At CES 2026, Roborock introduced the G-Rover, a groundbreaking concept device that is being hailed as the world's first wheel-legged robot vacuum capable of navigating stairs and multi-level homes. This innovative prototype features a unique dual wheel-leg architecture, allowing each leg to lift independently and adjust its height for optimal maneuverability. Enhanced by advanced AI algorithms and 3D spatial perception technology, the G-Rover is designed to efficiently clean various surfaces and adapt to complex environments. The unveiling of this device highlights Roborock's commitment to pushing the boundaries of home automation and robotics, aiming to provide consumers with a versatile cleaning solution for modern living spaces.
News Feed CES 2026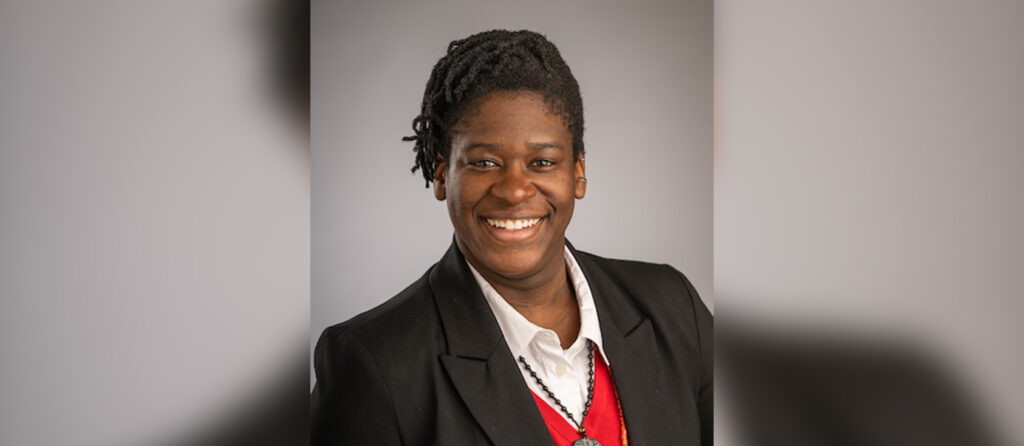
Robot Talk Episode 137 – Getting two-legged robots moving, with Oluwami Dosunmu-Ogunbi
Claire recently engaged in a conversation with Oluwami Dosunmu-Ogunbi, an Assistant Professor in the Mechanical Engineering Department at Ohio Northern University, regarding advancements in bipedal robotics. Dosunmu-Ogunbi, who is recognized as the first Black woman to hold this position, specializes in control systems that enhance bipedal locomotion, including the ability of robots to walk and navigate stairs. Her research not only contributes to the field of robotics but also aims to inspire future generations in engineering education. This dialogue highlights the innovative strides being made in robotics and the importance of diversity in STEM fields.
Robotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.







