


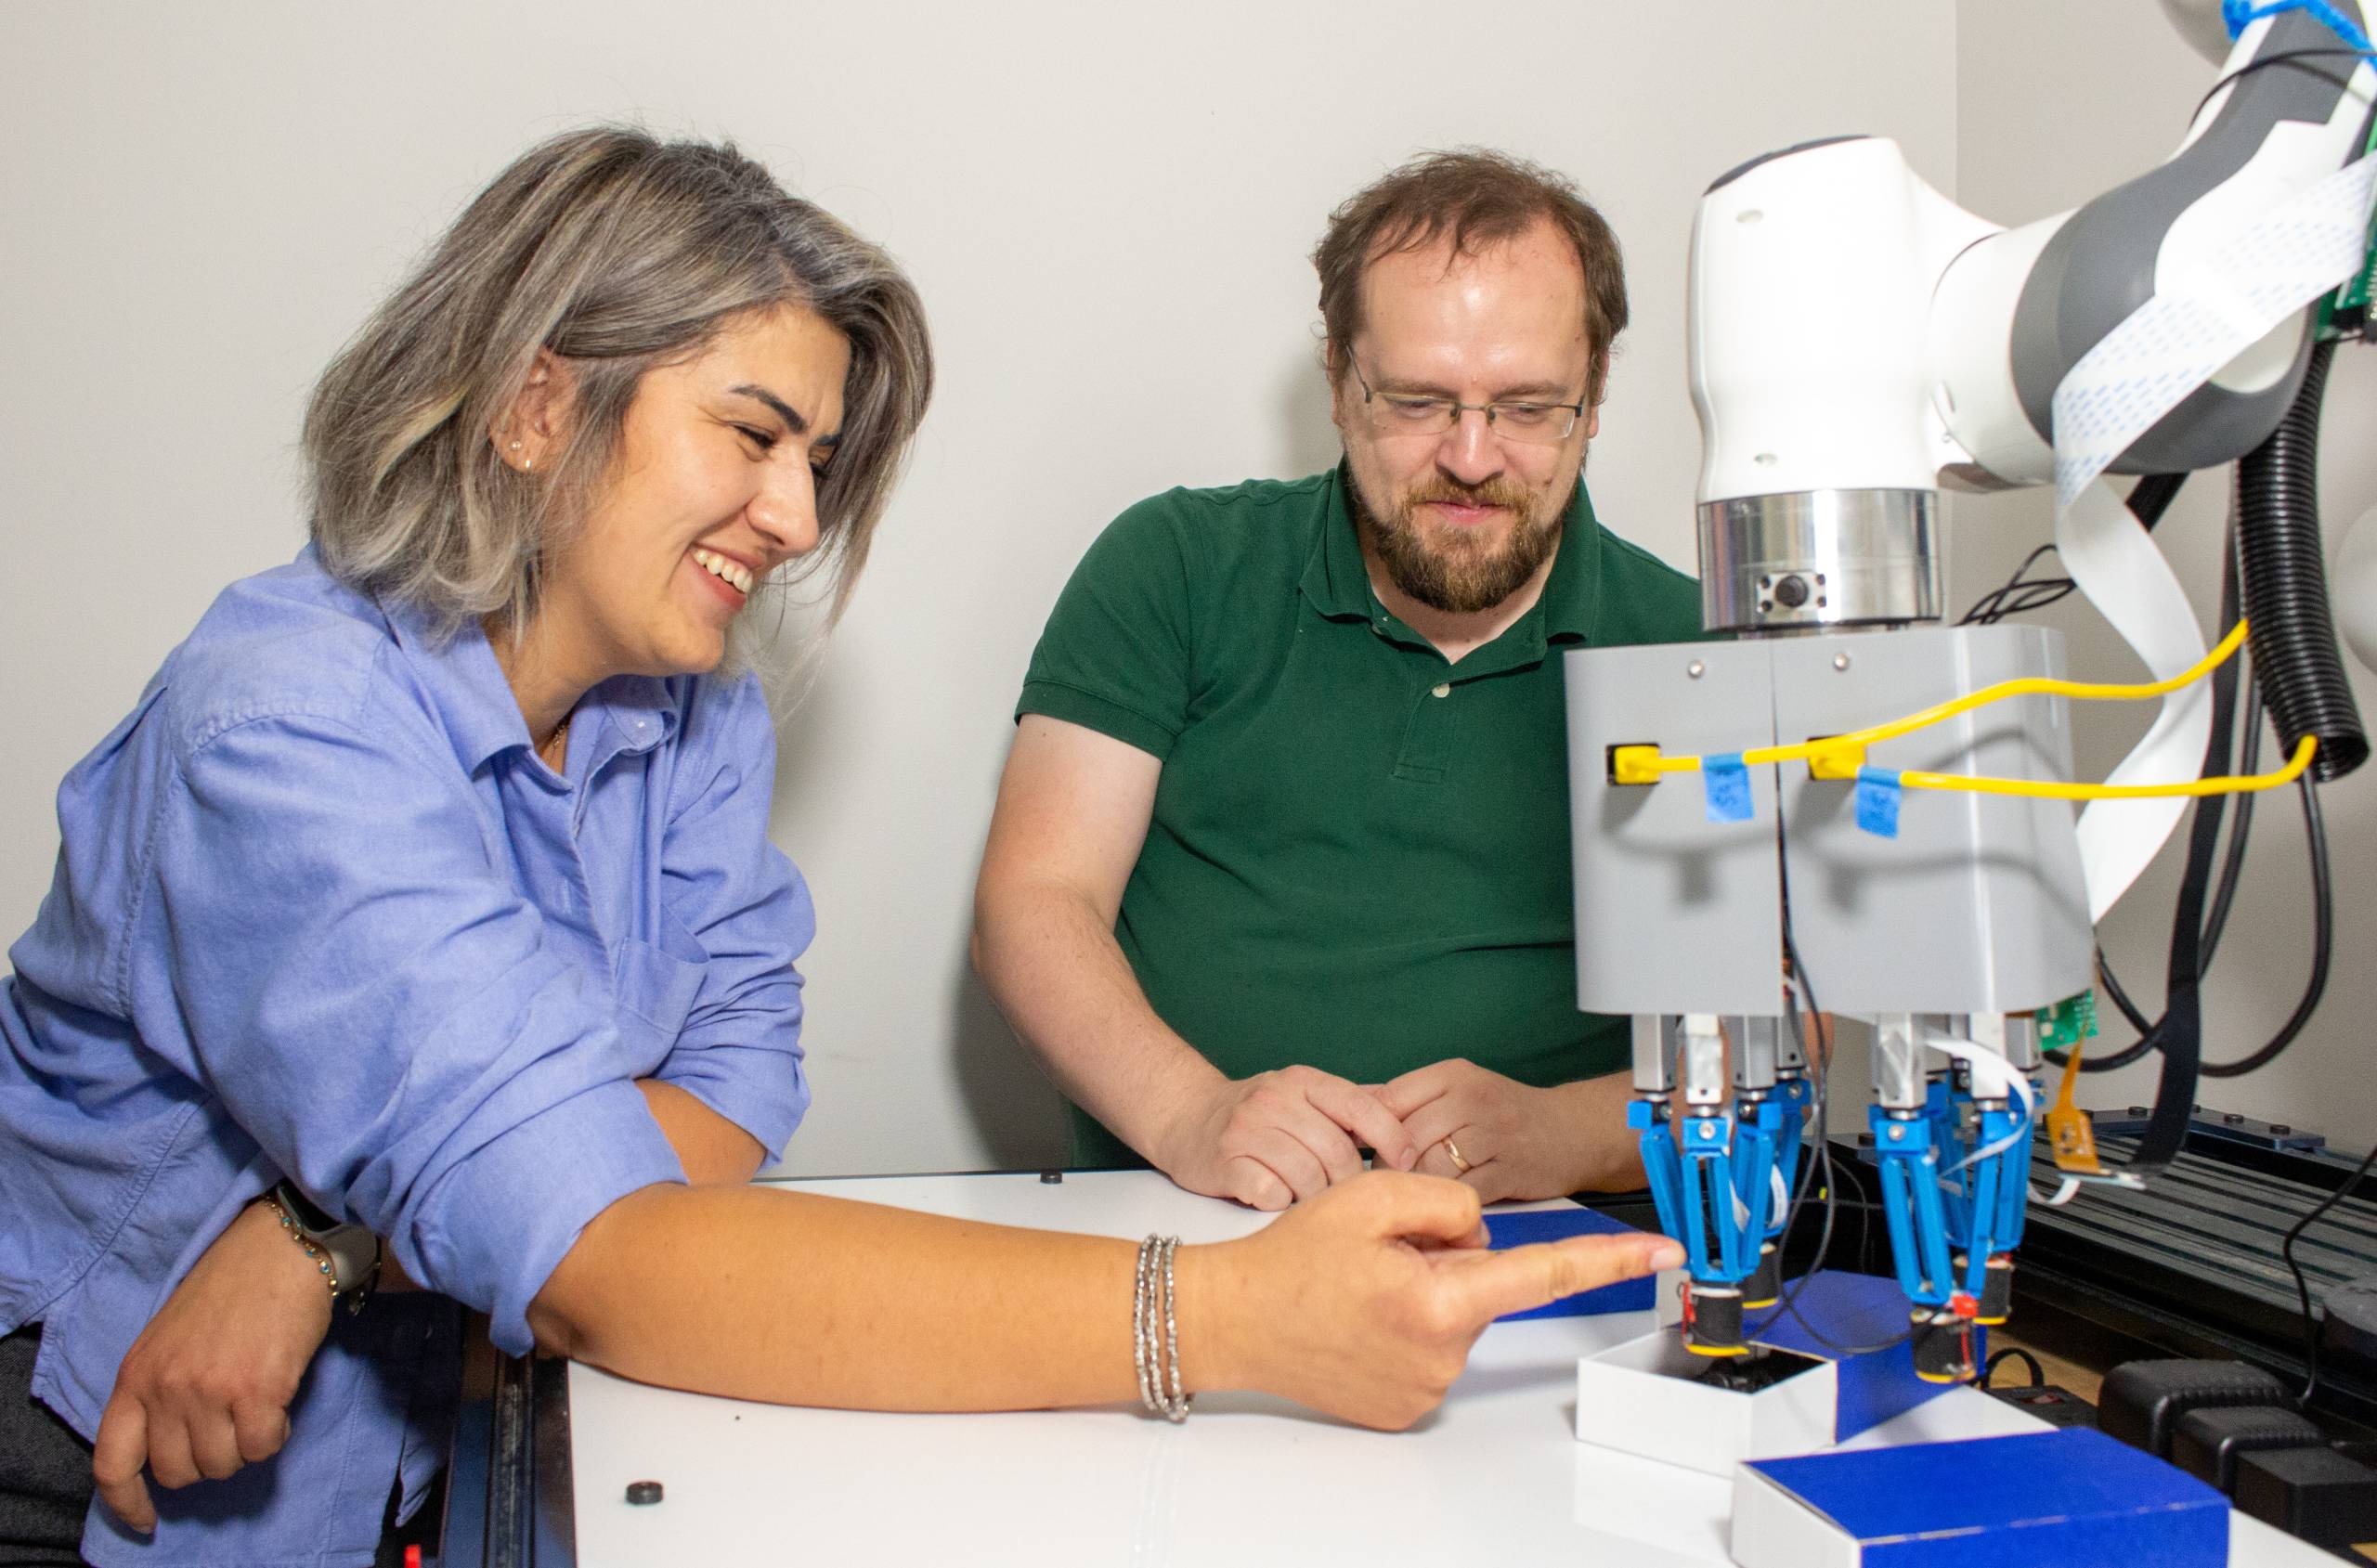
Professors at Universidad Carlos III de Madrid (UC3M) and Universidad Pública de Navarra (UPNA) have created a soft robotic gripper that can pick up, hold, and manipulate objects. This innovative gripper is designed to reposition items securely between its fingers without losing grip.
The development of this soft robotic gripper is significant as it enhances the dexterity and functionality of robotic systems, making them more versatile in handling various objects. This advancement could lead to improved applications in fields such as logistics, manufacturing, and healthcare, where precise manipulation is essential.
Looking ahead, the implications of this technology could reshape how robots interact with their environment. No further timeline was disclosed at the time of publication.
Editor's Note
The development of soft robotic grippers represents a crucial advancement in robotics, particularly in enhancing dexterity and adaptability. As industries increasingly adopt automation, the ability to manipulate objects with precision will be vital for improving efficiency and effectiveness in various applications.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.
















Leave a comment