

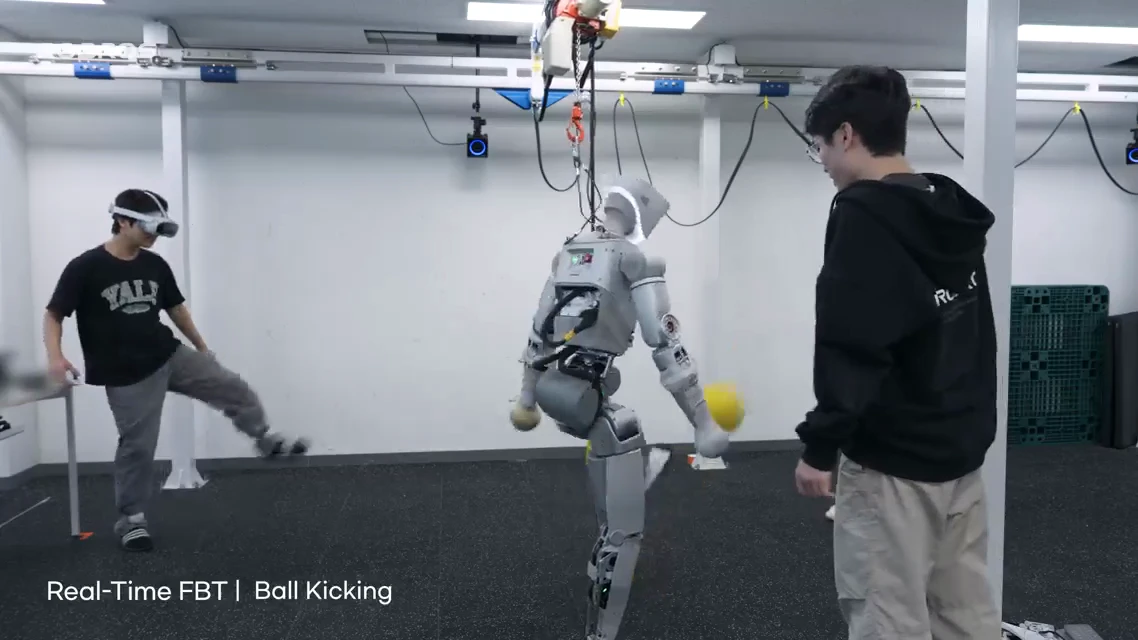
South Korean startup Robros has introduced full-body teleoperation for its IGRIS-C humanoid, allowing real-time control of the robot's entire body. This advancement, reported by Seoul Economic Daily on September 22, expands previous capabilities focused on upper-body movements to include coordinated posture and lower-body actions such as squatting and turning.
The significance of this development lies in its practical applications for industrial tasks, where coordinated movements can enhance the robot's ability to handle complex situations that require the use of multiple body parts. While the system promises richer demonstrations for training purposes, the announcement did not provide specific metrics on improvements in autonomy or task efficiency.
Looking ahead, Robros, founded in 2020 and based in Seoul, has reported a total of 18 IGRIS-C units sold, with customers in sectors like semiconductor and automotive. However, the reliability of the teleoperation system during extended industrial use remains to be seen, as no further timeline was disclosed at the time of publication.
Editor's Note
The introduction of full-body teleoperation by Robros marks a significant step in humanoid robotics, particularly for industrial applications. This technology could enhance operational flexibility and efficiency, allowing robots to perform tasks that require intricate movements. As companies increasingly seek automation solutions, the ability to control robots in real-time across their entire body may influence procurement decisions and technology adoption in various sectors.
















Leave a comment