Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.

Innovative Puppet Master Approach Enables Control of Multiple Robots Simultaneously
A team from the Technical University of Munich demonstrated a novel method for controlling three distinct robots to collaboratively transport a whiteboard through a doorway. This approach, published in Science Robotics, utilizes an allocentric perspective, allowing operators to oversee multiple robots from a 'God's eye' view, akin to puppeteering. The results showed an 84% increase in speed for parallel tasks compared to traditional first-person control. This new paradigm is significant as it addresses the cognitive load associated with egocentric control, where operators switch perspectives between robots, hindering efficiency. The allocentric method allows for simultaneous control, enhancing usability scores when operators can switch between modes. Cognitive science supports this approach, indicating that the brain processes spatial information more effectively in an allocentric manner, particularly in complex scenarios. Looking ahead, the research indicates potential for further exploration in robot control systems. While the allocentric mode excels in speed, it shows limitations in precision tasks, suggesting a need for hybrid approaches that leverage the strengths of both allocentric and egocentric perspectives. No further timeline was disclosed at the time of publication.
Multi-Robot Control Remote Operation Robotics Research Human-Robot Interaction
Cooperative Climbing Control for Bridge Pier Defect Detection Using Multi-Wheel Robots
A new multi-wheel cooperative climbing control system has been developed for detecting defects in bridge piers. This innovative circular frame robot system enhances the efficiency and accuracy of inspections, addressing a critical need in infrastructure maintenance. The significance of this technology lies in its potential to improve safety and reduce costs associated with bridge maintenance. By utilizing a cooperative approach, the system can navigate complex structures more effectively, ensuring that defects are identified promptly and accurately. Looking ahead, the adoption of this multi-wheel cooperative climbing control system could revolutionize the way infrastructure inspections are conducted. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
ACE Robotics and NTU S-Lab Release Open-Source Puffin-World Multimodal Model
ACE Robotics and NTU S-Lab have announced the open-source release of Puffin-World, a multimodal world model that integrates physics, geometry, and appearance. This model utilizes the Puffin-16M dataset and achieves state-of-the-art camera absolute pose errors, reporting sub-degree accuracy across four public benchmarks. The significance of this release lies in its potential to enhance various applications in robotics and computer vision by providing a unified framework for understanding complex environments. By achieving such high accuracy in pose estimation, Puffin-World could facilitate advancements in autonomous navigation and scene understanding. Looking ahead, the impact of Puffin-World on the robotics community will be closely monitored, particularly in how it influences future research and development in multimodal models. No further timeline was disclosed at the time of publication.

Humanoid Robots Enhanced by AI Controller for Translating Commands into Actions
Humanoid robots, designed to mimic human limbs and body structures, are being enhanced by an AI controller that translates virtual reality, video, and language commands into actionable movements. This advancement aims to simplify the teaching process for these robots, which often struggle with executing humanlike movements reliably. The significance of this development lies in its potential to streamline the deployment of humanoid robots across various environments, including homes and workplaces. By improving the efficiency of command translation, the AI controller could reduce the time and effort required to train these robots, making them more accessible for practical applications. Looking ahead, the focus will be on the effectiveness of the AI controller in real-world scenarios and its ability to adapt to diverse tasks. No further timeline was disclosed at the time of publication.
Robotics
Scalabot Unveils HERON-World Model with Enhanced Multiplayer Mode for Robotics
Scalabot has introduced the HERON-World Model, a new action-conditioned world model aimed at enhancing robotic understanding and future prediction capabilities. This model utilizes a three-tier data pyramid, incorporating real robot teleoperation data, simulation data, and first-person human operation videos to improve the robot's interaction with the environment. The significance of this development lies in its ability to extend the boundaries of world models from physical to social reasoning. By employing a diverse range of data sources, HERON-World Model aims to create a robust learning loop that allows robots to adapt and respond to dynamic environments, thereby advancing embodied intelligence from single-task capabilities to more general, transferable skills. Looking ahead, Scalabot's focus on integrating real-world data with simulation and human interaction videos will be crucial for the ongoing evolution of robotics. The HERON-World Model's current evaluation score stands at 75.80, indicating its potential impact on the industry. No further timeline was disclosed at the time of publication.
World Models Robotics AI Machine Learning Data Strategy
Hebbian Robotics Releases HFlow 0.2.4 for Robotic Data Quality Control
Hebbian Robotics has launched HFlow 0.2.4, a preliminary version of its open-source tool aimed at robotic data quality control. The software organizes videos, joint states, actions, and timestamps used for training models, while tracking transformations applied to each episode. Robotic teams often accumulate recordings from cameras, sensors, and commands that do not share the same clock, which can degrade learning without visible errors. HFlow aims to replace scattered scripts with a reproducible, observable, and queryable pipeline. It uses MCAP as the primary input and output format, which is natively utilized by ROS 2, and can integrate images, states, actions, and other time series. The latest version also adds support for importing datasets in LeRobot v3 format. Each processing step can execute transformations, checks, annotations, or enrichments written in Python, allowing teams to trace the code that produced an episode and compare versions of checks. The project’s success will depend on its adoption by teams already using ROS 2, MCAP, or LeRobot. HFlow addresses a significant issue: a robotic model cannot sustainably compensate for desynchronized, incomplete, or irreproducible data. By making these defects measurable and auditable, HFlow seeks to shift quality control earlier in the learning pipeline.
Robots
Multiway Robotics Enhances Malaysian Manufacturer's Smart Warehouse with Over 5,000 Storage Locations
Multiway Robotics has implemented a solution for a Malaysian manufacturer that features over 5,000 storage locations and multi-model autonomous forklift collaboration. This transformation has led to a more efficient and scalable warehouse operation, achieving a storage density improvement of over 30%. The significance of this development lies in its support for the customer's ongoing supply chain transformation, showcasing how advanced robotics can optimize warehouse logistics. By enhancing storage capabilities and operational efficiency, Multiway Robotics is setting a new standard in smart warehouse solutions. Looking ahead, it will be important to monitor how this implementation impacts the manufacturer's overall supply chain performance and whether similar solutions will be adopted by other manufacturers in the region. No further timeline was disclosed at the time of publication.

Variable Impedance and QP-CBF Control for Damage-Free Grasping Using Multimodal Oxidation Prior
The article discusses a novel approach to damage-free grasping through the implementation of variable impedance and Quadratic Programming-Collision Barrier Function (QP-CBF) control. This method leverages multimodal oxidation prior to enhance the grasping capabilities of robotic systems. This advancement is significant as it addresses the challenges of ensuring safe and effective interactions between robots and delicate objects. By utilizing variable impedance control, robots can adapt their grip strength based on the object's properties, minimizing the risk of damage during handling. Looking ahead, the research highlights the potential for further developments in robotic grasping techniques that incorporate advanced control strategies. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE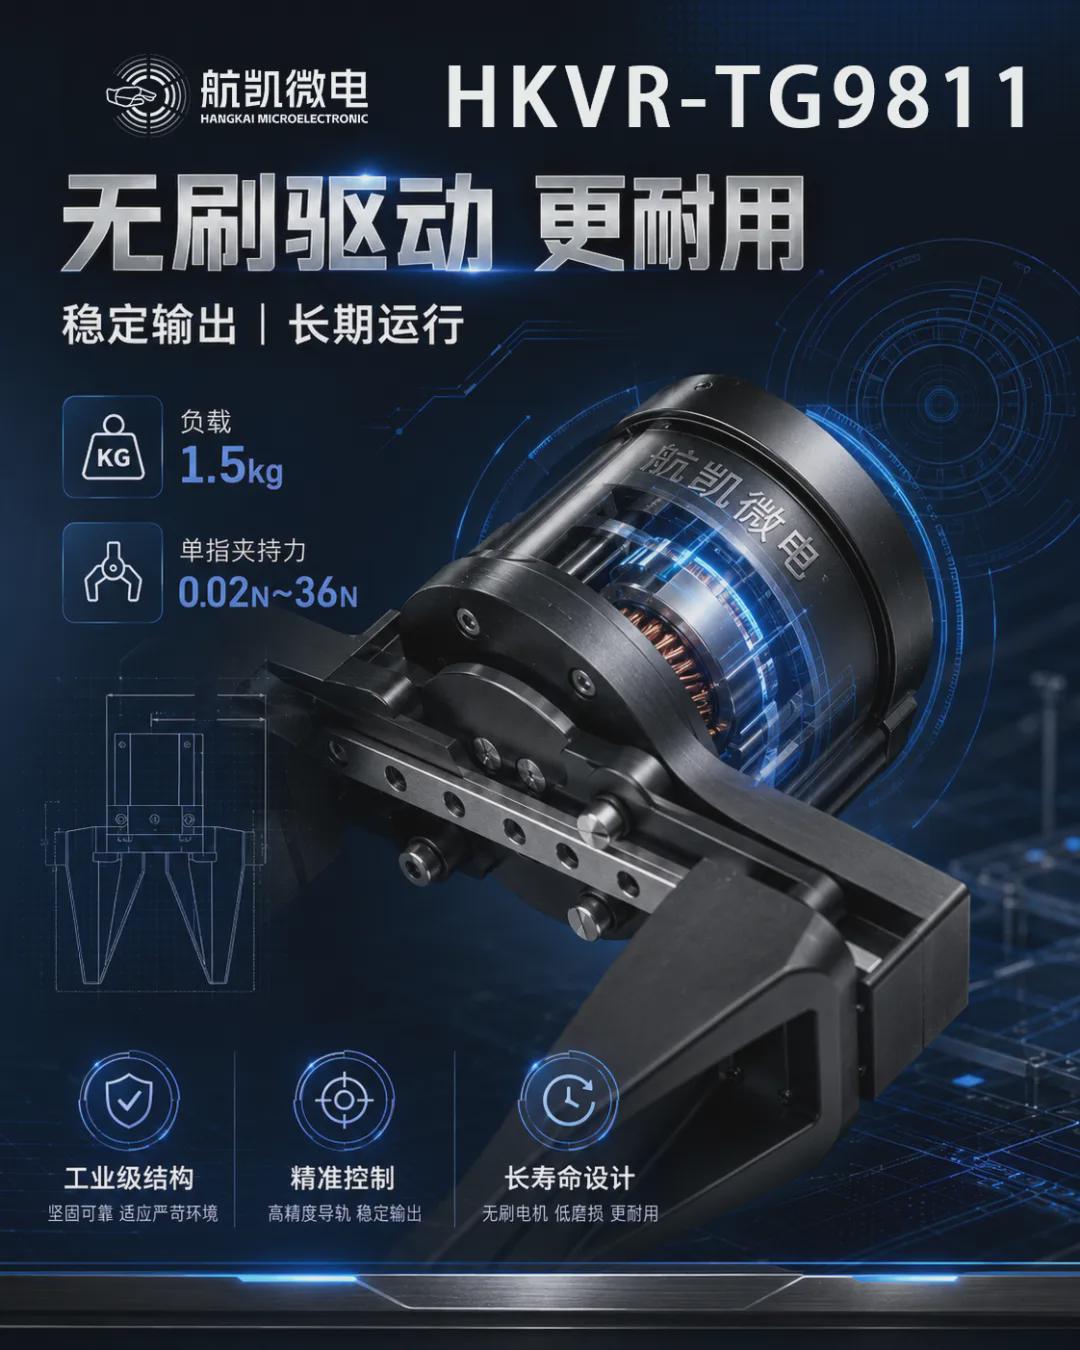
Suzhou Hangkai Microelectronics Launches TG9811 for Enhanced Robot Tactile Control
Suzhou Hangkai Microelectronics has introduced the TG9811, a three-dimensional tactile electric gripper designed to address common challenges in flexible automation. This innovative product features a maximum gripping force of 36N, making it suitable for various industrial applications such as component handling, precision assembly, and flexible sorting. The TG9811 stands out by integrating high-performance brushless motors and an intelligent adaptive grasping algorithm, which allows for automatic adjustments based on material properties without the need for manual recalibration. This capability significantly reduces issues like slippage and misgrasping, thereby enhancing operational efficiency in flexible production environments. With its built-in high-precision tactile sensors, the TG9811 can detect material conditions in real-time, enabling timely adjustments to gripping strategies. This feature is particularly beneficial for high-value component handling and continuous automated operations, ensuring reliable performance under varying conditions. No further timeline was disclosed at the time of publication.
Robotic Grippers Force Sensors Automation Solutions Industrial Robotics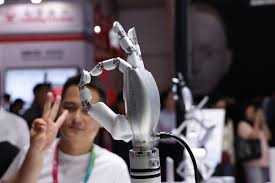
Multi-Stage Dynamic Positioning Control for Overactuated AUVs Using Active Disturbance-Rejection
The Journal of Field Robotics has published an early view article detailing a novel multi-stage dynamic positioning control method for overactuated Autonomous Underwater Vehicles (AUVs). This method employs active disturbance-rejection techniques to enhance control performance in challenging underwater environments. This advancement is significant as it addresses the complexities faced by AUVs in dynamic conditions, improving their operational reliability and efficiency. The proposed control strategy is expected to facilitate better navigation and stability, which are critical for underwater exploration and various marine applications. Future developments in this area will likely focus on refining the control algorithms and testing them in real-world scenarios. Researchers and practitioners should monitor upcoming publications for further insights into the practical applications and performance metrics of this innovative control approach.
RESEARCH ARTICLE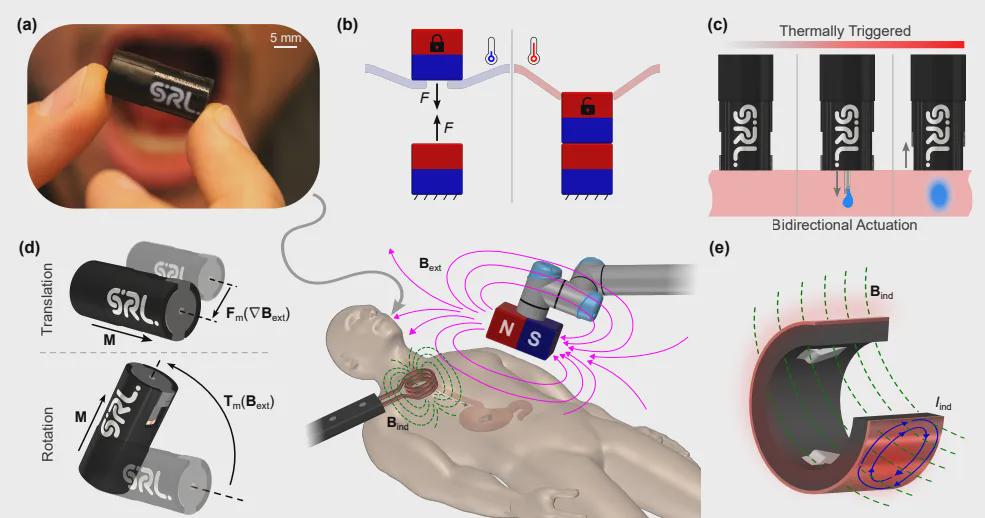
University of Twente Develops Magnetic-Controlled Capsule Robot for Medication Injection
Researchers at the University of Twente have developed a 10mm capsule robot capable of injecting medication into tissue using magnetic control. This innovative device operates without wires or battery-powered motors, relying instead on an external magnet and a thermally triggered mechanism. The technology, known as Thermally Triggered Magnetic Springs (TTMS), allows for precise delivery of medication, overcoming the limitations of traditional oral drug delivery methods. The significance of this advancement lies in its potential to enhance drug delivery efficiency. Current oral medication capsules often face barriers in the gastrointestinal tract, resulting in low delivery efficiency. The TTMS technology enables targeted drug delivery by utilizing a magnetic spring mechanism that can exert Newton-level forces at the millimeter scale, addressing the challenges of penetrating physiological barriers. Looking ahead, the researchers emphasize the importance of further development and testing of this capsule robot. The TTMS mechanism's ability to control the release of stored energy through temperature changes presents a promising avenue for improving therapeutic applications. No further timeline was disclosed at the time of publication.
Capsule Robots Drug Delivery Medical Robotics Magnetic Navigation
Kunwei Technology to Support 2nd World Humanoid Robot Games with Force Control Technology
The 2nd World Humanoid Robot Games will take place on August 22, 2026, at the National Speed Skating Stadium in Beijing. This event, themed 'Intelligent Competition Towards the Future,' will feature 666 teams and 2056 robots from 16 countries, marking a 138% increase in teams and a fourfold increase in robots compared to the first event. The competition will expand from 26 to 51 events, introducing high-intensity challenges such as long jump, weightlifting, tug-of-war, and table tennis, while also extending scenarios to nine real-world environments including industrial and domestic settings. This event is significant as it showcases the advancements in humanoid robot technology and aims to promote industry standards through competition. Analysts predict that 2026 will be a pivotal year for the commercialization of humanoid robots. The core components, such as six-dimensional force and joint torque sensors, are crucial for ensuring safe human-robot interaction and effective performance. Domestic manufacturers, led by Kunwei Technology, are gaining market share, achieving 58.8% in 2025, marking a shift away from reliance on foreign brands. Looking ahead, the focus will be on the development of a self-sufficient supply chain for force sensors in humanoid robots. Leading manufacturers are prioritizing domestic sensors for their stability, lightweight integration, and rapid customization. Kunwei Technology, with over 20 years of experience in multi-dimensional force sensor research, is positioned to meet these demands with its innovative technologies and products, including specialized sensors for humanoid robots that have already been adopted by major companies in the field. No further timeline was disclosed at the time of publication.
Humanoid Robots Force Sensors Robotics Technology Industrial Automation
Multi-Robot Collaboration Demonstrated by Daheng Technology at 2026 World Robot Conference
At the 2026 World Robot Conference, Daheng Technology showcased a multi-robot collaboration platform, where a quadruped robot autonomously inspected an area and alerted a cleaning robot to respond to an unidentified object. This demonstration highlighted Daheng's transition from single capabilities to a systematic approach in robotic solutions over the past year. The significance of this advancement lies in the industry's shift from merely activating robots to integrating them into diverse sectors for scalable applications. Daheng's multi-robot collaboration not only identifies issues but also facilitates coordinated responses, emphasizing the need for robots to possess enhanced sensory capabilities to navigate complex environments. Daheng Technology introduced its BlackEye Vision intelligent fusion terminal, which supports multi-modal perception and integrates various sensors for real-time data processing. This innovation allows robots to detect anomalies such as temperature fluctuations and gas leaks, providing critical information for AI-driven decision-making. No further timeline was disclosed at the time of publication.
Multi-Robot Collaboration AI Integration Industrial Robotics Automation Technology
Two-Stage Planning Method Enhances Continuous Multi-Robot Inspection in Mines
A two-stage robot planning method has been developed to enhance continuous underground mine inspections. This method integrates predictive charging, obstacle avoidance, and road condition assessments to optimize the performance of multiple robots in simulated environments. The significance of this advancement lies in its potential to improve safety and efficiency in mine inspections. By effectively managing the robots' charging needs and navigating obstacles, the method ensures that inspections can be conducted without interruptions, thereby increasing operational productivity. Looking ahead, the implications of this technology could lead to broader applications in various sectors requiring autonomous inspections. No further timeline was disclosed at the time of publication.
Sami Robotics Advances Broccoli Harvesting with Multi-Crop Platform Development
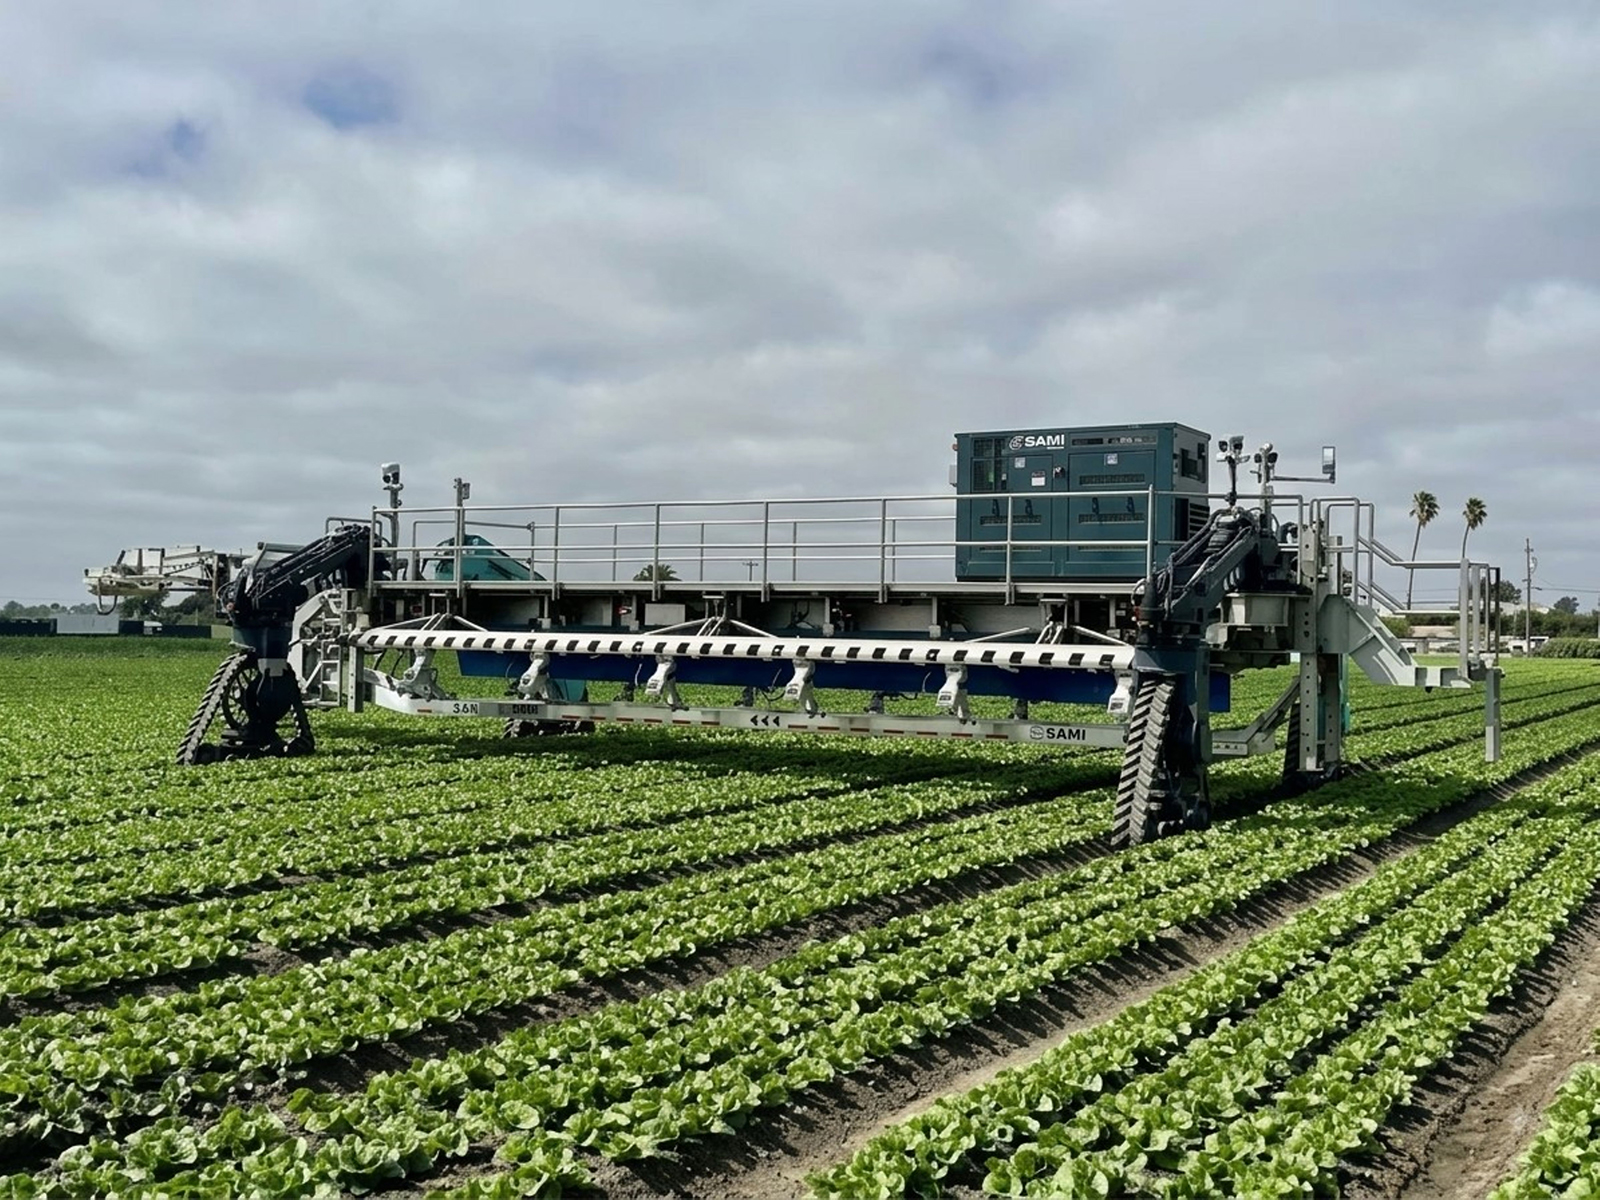
Sami Robotics, located in Varennes, Québec, has successfully transitioned its broccoli harvesting application from prototype to operational status, utilizing a scalable, multi-arm design. The platform employs 12 to 18 robotic arms that work in parallel to identify and harvest mature vegetables, although specific throughput figures are not disclosed due to varying field conditions. The significance of this advancement lies in Sami Robotics' commitment to automating labor-intensive agricultural tasks through advanced robotics, AI, and data analytics. CEO Pascal Labrecque emphasizes the platform's adaptability for multiple crops and agricultural operations, aiming to enhance efficiency and reduce labor dependency for growers. Looking ahead, Sami Robotics plans to scale commercial deployments while refining its technology. Romaine lettuce is next in line for development, with iceberg lettuce and cauliflower also generating interest. The company envisions a multifunctional platform that could eventually support various agricultural tasks beyond harvesting, although no additional capabilities are currently in development.
Crop solutions Harvest & storage harvest Harvest robot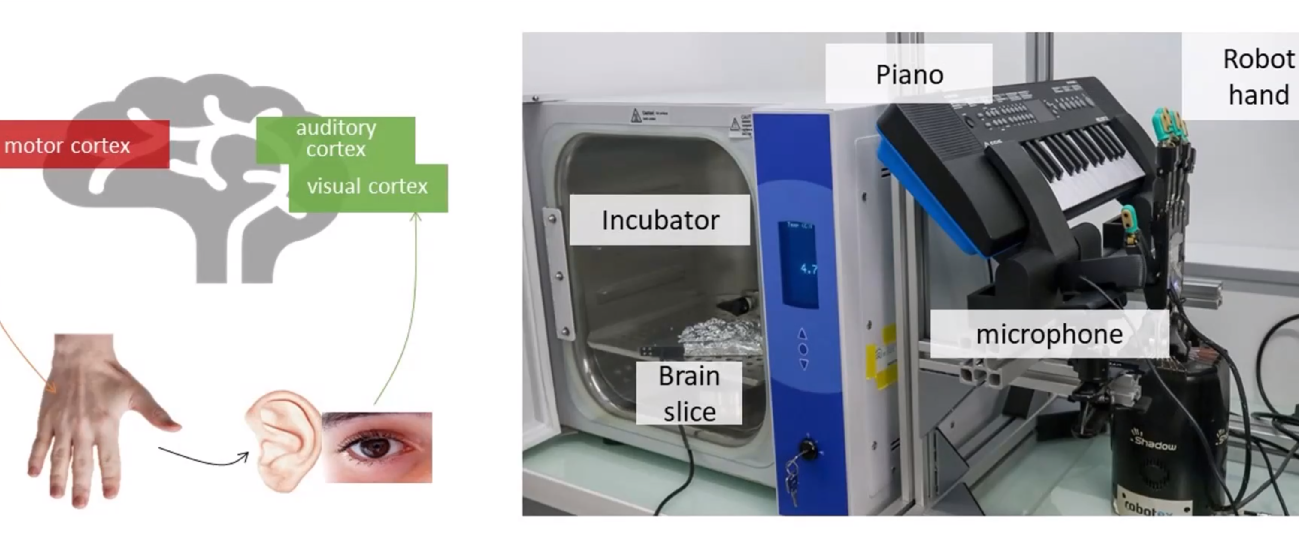
French Research Team Uses Dead Brain Cells to Control Robot Hand for Piano Playing
A French research team has achieved a remarkable feat by connecting adult brain slices from deceased donors to a robotic hand, enabling it to play the piano. Their study, titled 'Unsupervised Sensory-Motor Associative Learning in Human Brain Explants Enables Robot Action Imitation,' reveals that the brain slices retained memory for at least 17 days, although performance declined with drug treatment or viral infection. This breakthrough raises significant ethical and technological questions about the use of hybrid AI, which integrates living neurons into computational systems. The research highlights the stark differences in energy consumption and learning efficiency between biological systems and traditional AI, with the human brain consuming 20 watts compared to the minimal energy used by simpler organisms. Looking ahead, the team proposes a novel approach using organotypic culture of post-mortem adult brain explants (OPAB) as a viable alternative to existing methods. The study was ethically approved and involved brain tissue from three donors, emphasizing the need for careful consideration of ethical implications in future research.
Hybrid AI Neural Networks Robotic Control Brain-Computer Interface
RoboScience Unveils REX G1: A Multifunctional Wheeled Humanoid Robot for Diverse Applications
On August 17, RoboScience officially launched the REX G1, a versatile wheeled humanoid robot designed for various operational scenarios. This robot, equipped with RoboScience's proprietary VLOA architecture and Visics model, aims to enhance productivity in logistics, factories, retail, and home environments by executing complete tasks in dynamic, unstructured settings. The significance of REX G1 lies in its ability to integrate mobility and operational capabilities, addressing the limitations of traditional robots that often operate in isolation. With 22 degrees of freedom, REX G1 can perform tasks with high precision, including object handling and positioning, while adapting to existing spatial layouts without requiring modifications. Looking ahead, REX G1's advanced perception and control systems allow it to function effectively in complex environments, reducing reliance on external infrastructure. No further timeline was disclosed at the time of publication.
Humanoid Robots Logistics Automation AI Robotics Warehouse Automation
NVIDIA and Boston Dynamics: Divergent Strategies in Robotic Motion Control
On August 12, two papers on robotic motion control were published in Science Robotics, showcasing contrasting approaches by NVIDIA and Boston Dynamics. The RAI Institute and Boston Dynamics introduced the ZEST framework, which enables zero-shot embodied skill transfer and motion imitation, allowing the Atlas robot to learn various skills in approximately 10 hours using a single NVIDIA L4 GPU. In contrast, the SONIC framework consumed around 700 hours of motion capture data and 21,000 GPU hours for training, focusing on a unified control strategy that encompasses a wide range of human movements. This approach allowed the Yushu G1 robot to successfully execute 123 different motion sequences with a 99.2% success rate, demonstrating real-time adaptability to human actions. These differing methodologies highlight the ongoing debate in robotics regarding efficiency versus data-driven approaches. Future developments will need to address complex movement challenges, such as how robots can adapt to various physical interactions and whether new control logic is required for different actions. No further timeline was disclosed at the time of publication.
Robotic Motion Control AI Machine Learning Robot Training Boston Dynamics
Motion Controls Robotics, Inc. Expands Automation Portfolio with New Technologies and Expertise
Motion Controls Robotics, Inc. (MCRI) has announced an expansion of its automation portfolio by integrating new specialized automation technologies and intellectual property. This enhancement includes capabilities in tire manufacturing automation, robotic painting, precision fluid application, surface treatment, and other specialized manufacturing processes. This development is significant as it broadens MCRI's ability to support a wider range of operations within manufacturing plants. By adding experienced personnel with industry expertise, MCRI aims to improve efficiency and effectiveness in various manufacturing applications, thereby strengthening its market position. Looking ahead, MCRI's focus on enhancing its automation capabilities may lead to further innovations and partnerships in the automation sector. No further timeline was disclosed at the time of publication.

ZEST Enables Zero-Shot Skill Transfer for Enhanced Athletic Robot Control
The research published in Science Robotics introduces ZEST, a novel approach for zero-shot embodied skill transfer in athletic robots. This method allows robots to learn and execute complex athletic skills without prior specific training on those tasks. ZEST is significant as it enhances the adaptability and performance of athletic robots, potentially transforming their application in sports and physical activities. By enabling robots to generalize skills across different contexts, this technology could lead to more versatile and efficient robotic athletes. Looking ahead, the implications of ZEST could extend beyond athletics, influencing various fields where robotic adaptability is crucial. No further timeline was disclosed at the time of publication.
Research Article
Multiway Robotics Completes Intelligent Warehouse Automation for Malaysian Manufacturer
Multiway Robotics has successfully deployed an intelligent warehouse automation system for a manufacturing company in Malaysia, integrating autonomous forklifts with warehouse management software to enhance storage capacity and material handling. This project supports over 5,000 storage locations, including raw material warehouses and finished goods storage, and has reportedly increased storage density by more than 30 percent. The significance of this deployment lies in its contribution to the ongoing trend of warehouse automation and digital transformation among manufacturers in Southeast Asia. By addressing the customer's growing storage needs and complex material flows, Multiway Robotics has implemented a fleet of autonomous forklifts alongside its proprietary Warehouse Management System (WMS) and Robot Control System (RCS), facilitating end-to-end automation of warehouse operations. Looking ahead, the system's capabilities include managing raw material receiving, finished goods storage, and internal material transportation. The deployment features three autonomous forklift models, each designed for specific tasks, and operates 24/7 with automatic charging. No further timeline was disclosed at the time of publication.
News Warehouse robots amrs automated warehouse autonomous forklifts autonomous mobile robots
DPVR Integrates VR Technology for Real-Time Robot Control at Qingdao's 6S Store
DPVR has officially launched its VR technology at Qingdao's 6S experience store, allowing users to control robotic arms in real-time using the E4 VR headset. This innovative approach eliminates the need for complex programming, creating a direct action mapping channel between the operator and the robot. The integration of DPVR's RoboPilot platform with the E4 headset enables precise tracking of head and controller movements, facilitating efficient robotic operations such as movement and grasping. Additionally, RoboPilot collects data throughout the operation, contributing to AI model training and task validation, enhancing the learning process for the robots. As DPVR continues to expand its RoboPilot ecosystem, partnerships with various robotics companies are being established to create adaptable robotic systems. The 6S experience store exemplifies a new era of human-robot collaboration, where users can operate machines intuitively without extensive training or programming knowledge.
Virtual Reality Robotic Control AI Training Human-Robot Interaction
Mind-Controlled Rehabilitation Robots to Emerge from China's Internet Valley by 2026
Wuhan-based Xi Yuan Intelligent Technology Co., Ltd. is pioneering mind-controlled rehabilitation robots aimed at stroke recovery. Founded on May 13, 2026, the company leverages technology from Huazhong University of Science and Technology and Tongji Hospital, focusing on integrating multimodal brain-computer interfaces with advanced robotic systems. The significance of this initiative lies in its potential to redefine stroke rehabilitation. By creating a direct communication pathway between the patient's brain and the robot, Xi Yuan aims to facilitate active recovery, allowing patients to regain movement through real-time interpretation of their intentions. This approach contrasts with traditional passive therapies, offering a more engaging and effective rehabilitation experience. Looking ahead, Xi Yuan's strategic plan includes clinical trials and regulatory submissions to the National Medical Products Administration. The company is positioned to address critical quality-of-life challenges for stroke patients, with a vision to be a leader in the integration of brain-computer interfaces and embodied intelligence in rehabilitation robotics. No further timeline was disclosed at the time of publication.
Robotics Healthcare Technology Brain-Computer Interfaces Stroke Rehabilitation
PaXini Unveils PX-FOOTRIX, the First Multi-Dimensional Tactile Sensor for Bipedal Robots
PaXini has officially launched the PX-FOOTRIX, the world's first multi-dimensional tactile sensor designed for bipedal robots. This innovative product utilizes a pioneering 6D Hall array tactile sensing technology to provide comprehensive three-dimensional force perception and six-dimensional force/moment sensing, enabling robots to accurately understand ground features and adapt their gait in real-time. The introduction of PX-FOOTRIX is significant as it enhances the ability of bipedal robots to navigate complex real-world terrains, moving beyond simple walking capabilities to a deeper understanding of how to walk. This advancement is crucial for applications in industrial manufacturing, logistics, and public services, where robots must adjust their movements based on varying ground conditions. Looking ahead, the PX-FOOTRIX is set to redefine robotic gait perception and control. With its ability to deliver rich tactile feedback and support dynamic gait optimization, it promises to improve the stability and safety of robotic movements in diverse environments. No further timeline was disclosed at the time of publication.
Bipedal Robots Tactile Sensors Robotics Technology AI Sensor Technology
Diguwa Robotics and GigaDevice Introduce Comprehensive Control System for Six-Axis Collaborative Robot
On August 5, 2026, Diguwa Robotics and GigaDevice jointly launched a full-stack control system for six-axis collaborative robots, built on the Sunrise S600 and GD32H77R technologies. This initiative marks a significant milestone in their strategic partnership, providing a standardized solution for various applications including precision industrial assembly and flexible automation. The collaboration addresses critical challenges in the robotics industry, such as hardware-software fragmentation and reliance on imported core components. By integrating high-performance computing with real-time motion control, the system enhances operational efficiency and precision, making it suitable for high-dynamic industrial tasks. Looking ahead, the partnership aims to streamline the development process by offering a unified hardware interface and software architecture, significantly reducing the time from prototype validation to mass production. No further timeline was disclosed at the time of publication.
Collaborative Robots Industrial Automation AI Robotics Motion Control
Chiba University Researchers Enhance Control System for Flapping-Wing Robots in Windy Conditions
Researchers from Chiba University in Japan have developed a new control method for flapping-wing micro aerial vehicles (FW-MAVs) that significantly improves stability in windy conditions. This method addresses the limitations of existing control systems, reducing X-axis position error by 53.1 percent, which is crucial for applications like inspection and search-and-rescue operations. The importance of this advancement lies in the unique flight capabilities of FW-MAVs, which are inspired by birds and insects. Their ability to hover and maneuver in confined spaces makes them ideal for various applications, but their susceptibility to disturbances such as wind gusts has posed challenges. The new control method enhances their performance, enabling more stable and accurate flight. Looking ahead, the research paper detailing these findings will be published in the October issue of Control Engineering Practice, following its online release on June 4, 2026. The study's insights into non-minimum-phase behavior and its impact on disturbance correction will be critical for future developments in the field of aerial robotics.
Features Science aerial robotics autonomous flight Autonomous robots bio-inspired robotics
U.S. Army Demonstrates H-60M Black Hawk Helicopter's Capability to Control Multiple Combat Drones
The U.S. Army successfully completed a significant flight demonstration of the H-60M Black Hawk helicopter, showcasing its ability to launch and control multiple air-launched effects (ALEs) during Project Convergence Capstone 6 in California's Mojave Desert. This three-day test is a crucial advancement in enhancing the operational reach of Army helicopters in contested environments while maintaining safer distances from enemy defenses. This demonstration is vital as it marks a step towards improving the Army's capabilities in modern warfare. The Increment 1 capability, developed by the U.S. government in collaboration with the Utility Helicopters Project Office and the DEVCOM Aviation and Missile Center, allows the upgraded H-60M to operate effectively even in extreme conditions, thereby increasing its tactical advantages on the battlefield. Looking ahead, the Army plans further testing and evaluation of the Black Hawk's air-launched effects capabilities. This initiative aims to enhance the aircraft's survivability and effectiveness in combat, as well as to improve communication between aviation units and ground forces, thereby transforming battlefield dynamics and providing a decisive advantage to soldiers in future operations.
Military
Key Innovations in Robot Perception and Control Ahead of the 2026 World Robot Conference
The upcoming 2026 World Robot Conference will showcase significant advancements in robot perception and control technologies. Key innovations include a bipedal robot brain platform based on AMD Embedded Ryzen™ 8840U, which utilizes heterogeneous computing capabilities for autonomous navigation and interaction. Additionally, the JT series mini 3D LiDAR by Hesai offers a 360° x 189° field of view, setting a new benchmark in performance for robotic applications. These developments are crucial as they enhance robots' ability to perceive and interact with their environments, thereby improving their functionality in various applications. The integration of advanced sensors and computing platforms allows for real-time processing and decision-making, which is essential for the future of robotics. The innovations presented at the conference are expected to drive further advancements in automation and intelligent systems. Looking ahead, attendees should pay attention to the practical applications of these technologies in sectors such as logistics, manufacturing, and service industries. The conference will provide insights into how these innovations can be implemented to improve operational efficiency and user interaction. No further timeline was disclosed at the time of publication.
Robot Perception Autonomous Navigation Sensor Technology AI Robotics
Google DeepMind Introduces Gemini Robotics 2 for Enhanced Humanoid Control
Google DeepMind recently launched Gemini Robotics 2, an advanced version of its vision-language-action model. This iteration features intelligent whole-body control, enabling robots to perform complex tasks such as walking, crouching, and object manipulation. The model can adapt to new robotic bodies quickly, enhancing its versatility. The significance of Gemini Robotics 2 lies in its ability to expand physical AI capabilities, allowing robots to execute intricate movements and collaborate with other robots. This development is crucial for achieving the finesse required for real-world applications, such as household chores and workplace tasks. Looking ahead, the focus will be on further improving movement speed and dexterity. Gemini Robotics 2 represents a pivotal advancement in robotics, as it can control sophisticated end effectors like the SharpaWave hand, enabling delicate actions. No further timeline was disclosed at the time of publication.
Artificial Intelligence Artificial Intelligence / Cognition Design / Development End Effectors / Grippers Humanoids News
Google Unveils Gemini Robotics 2 for Advanced Humanoid Robot Control and Reasoning
Google has launched Gemini Robotics 2, a sophisticated robotics model that enables humanoid robots to perform full-body movements and complex tasks. This system allows for coordination among multiple robots and adapts to various robot designs with minimal training. The new capabilities extend beyond simple manipulation to include walking, bending, and balancing. The significance of Gemini Robotics 2 lies in its ability to facilitate multi-step reasoning and adaptability in unfamiliar environments, setting it apart from traditional robots. This model can control both humanoid robots and dual-arm systems, enhancing their functionality for household and industrial applications. Demonstrations showcased its ability to manage tasks such as picking up objects and performing intricate actions with dexterous robotic hands. Looking ahead, Google is also releasing Gemini Robotics ER 2 for high-level reasoning and Gemini Robotics On-Device 2 for local operation without cloud reliance. The introduction of multi-robot collaboration capabilities allows different robots to work together efficiently, marking a notable advancement in robotic technology. No further timeline was disclosed at the time of publication.
AI and Robotics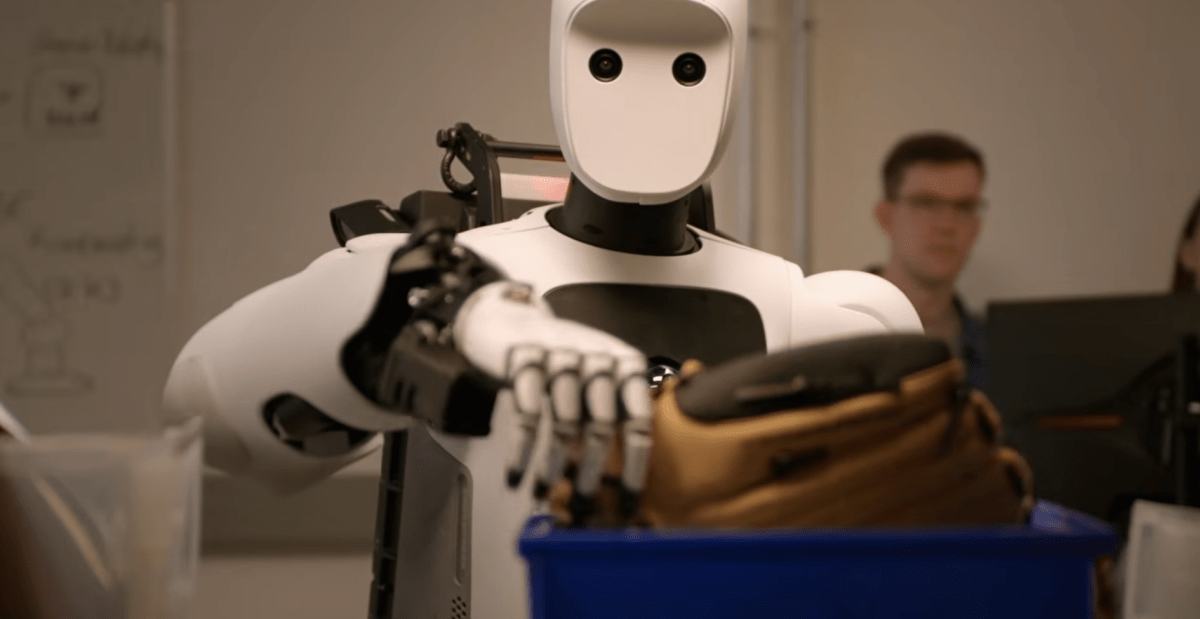
Google DeepMind Unveils Gemini Robotics 2 for Full-Body Control of Humanoid Robots
Google DeepMind has announced the launch of Gemini Robotics 2, an advanced AI model capable of controlling humanoid robots from 'feet to fingertips.' This new version enhances the robot's ability to perform a variety of actions, including walking, crouching, and manipulating objects, significantly expanding its functional capabilities. The importance of this development lies in its potential to enable humanoid robots to undertake more complex, real-world tasks that require whole-body coordination. With improved dexterity, Gemini Robotics 2 allows robots to perform intricate tasks such as sealing bags and unscrewing lightbulbs, marking a significant advancement in robotic manipulation. Looking ahead, Google DeepMind is also enhancing its Gemini Robotics ER model, which aids robots in analyzing their environment and executing multi-step tasks. This update aims to improve collaboration among different types of robots, enhancing safety features and operational efficiency. No further timeline was disclosed at the time of publication.
AI Google News Robot Tech
Exploring Multilevel Dynamics of Brain, Hormones, Mind, and Behavior in Human-Robot Interaction
A recent study published in Science Robotics investigates the complex interactions between the brain, hormones, mind, and behavior in social human-robot interactions. This research highlights how these multilevel dynamics influence the way humans engage with robots, potentially reshaping our understanding of robotics in social contexts. Understanding these interactions is crucial as it can lead to improved design and functionality of robots, enhancing their effectiveness in various applications. The findings may also inform the development of robots that can better respond to human emotional and psychological states, thereby fostering more natural interactions. As the field of robotics continues to evolve, it will be important to monitor advancements in understanding human-robot dynamics. Future research may explore specific applications of these findings in sectors such as healthcare, education, and entertainment, where social interaction with robots is increasingly prevalent. No further timeline was disclosed at the time of publication.
Research Article
NASA's Katalyst Space Robot for Telescope Lift Faces Control Issues in Orbit
NASA's Katalyst Space robot, designed to elevate the Neil Gehrels Swift Observatory to a higher orbit, is currently tumbling out of control. This mission marks NASA's first collaboration with a private company for such an operation, aimed at extending the observatory's operational lifespan beyond its initial expectations. The Swift Observatory, launched in 2004, is crucial for observing transient cosmic events. However, the LINK spacecraft, which was launched on July 3 aboard a Northrop Grumman Pegasus rocket, has encountered significant control issues, including the failure of two of its three reaction wheels. This has complicated communication efforts as the spacecraft spins away from Earth. Flight controllers are actively working to stabilize the LINK spacecraft using alternative thrusters, and initial efforts have shown positive results. As Katalyst's mission progresses, the focus will be on recovering the spacecraft to ensure the Swift Observatory can continue its vital work in astrophysics. No further timeline was disclosed at the time of publication.
Space NASA
An In-Depth Analysis of Wall-Climbing Robots: Adaptation, Adhesion, and Motion Control
The Journal of Field Robotics has published a comprehensive review focusing on wall-climbing robots, detailing their environmental adaptation, adhesion mechanisms, and motion control strategies. This review highlights the various technologies employed in these robots to navigate vertical surfaces effectively. Understanding the capabilities of wall-climbing robots is crucial as they have significant applications in inspection, maintenance, and exploration tasks across various industries. The review emphasizes the importance of adhesion mechanisms, which are vital for the robots' ability to operate in diverse environments without falling. Looking ahead, advancements in motion control and adhesion technologies will be essential for enhancing the performance of wall-climbing robots. No further timeline was disclosed at the time of publication.
SURVEY ARTICLE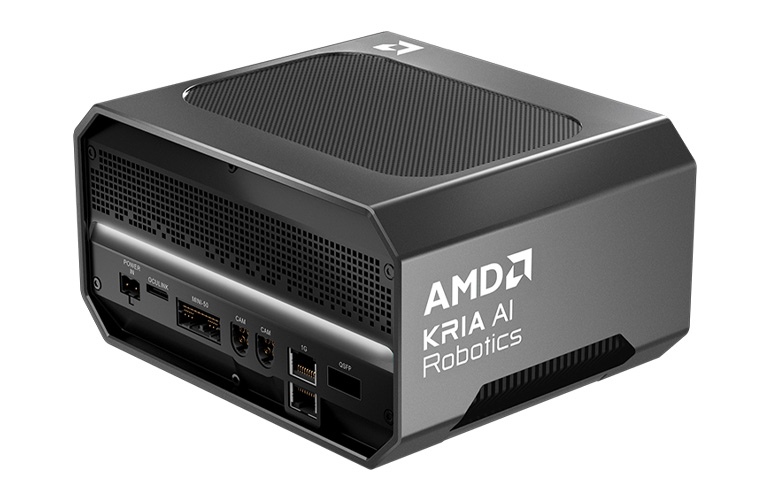
AMD Launches Kria Module and Ryzen AI Embedded X100 for Robotics Control
AMD has introduced the Kria module and Ryzen AI Embedded X100 series, aimed at enhancing real-time control and processing for robotics applications. The new platform promises deterministic performance with unified memory architecture, targeting both firm and hard real-time control through advanced optimizations. This development is significant as it positions AMD as a competitive alternative to NVIDIA in the robotics sector, particularly for physical AI applications. The unified CPU-GPU-NPU memory architecture is designed to reduce latency and improve efficiency in tasks such as perception and sensor fusion, which are critical for robotic operations. Looking ahead, AMD's offerings, including the open-source AMD Robotics Sophie Suite and a curated Robotics Partner Network, will be crucial for developers seeking scalable solutions for various robotic applications. No further timeline was disclosed at the time of publication.
Artificial Intelligence Controllers Microprocessors / SoC Microprocessors / SoCs Motion Control News
FloatForm Develops Hybrid Control for Reconfigurable Aquatic Swarms of Miniature Robot Boats
FloatForm has introduced a novel approach that combines distributed onboard control with lightweight centralized planning to manage self-assembling robotic boats. This innovative hybrid control system allows for effective coordination of miniature robot boats during controlled aquatic experiments. The significance of this development lies in its potential applications in various fields, including environmental monitoring, search and rescue operations, and marine research. By enabling the formation of reconfigurable swarms, FloatForm's technology could enhance the efficiency and adaptability of robotic systems in aquatic environments. Looking ahead, it will be important to monitor further advancements in FloatForm's technology and its deployment in real-world scenarios. No further timeline was disclosed at the time of publication.
Multimodal Robotics Inspired by Biological Systems Explored in Science Robotics
The latest issue of Science Robotics, Volume 11, Issue 116, published in July 2026, delves into the advancements in bioinspired multimodal robotics. This research highlights how biological systems can inform the design and functionality of robotic systems, leading to more versatile and adaptive technologies. The significance of this research lies in its potential to enhance robotic capabilities by mimicking the diverse modalities found in nature. By studying biological organisms, engineers can develop robots that are not only more efficient but also capable of performing complex tasks across various environments, which is crucial for applications in fields such as search and rescue, agriculture, and environmental monitoring. Looking ahead, the ongoing exploration of bioinspired designs in robotics will likely lead to innovative solutions that address current limitations in robotic performance. No further timeline was disclosed at the time of publication.
Review
Multiple Exhibitors Showcase the Same Robot at WAIC, Highlighting Industry Trends
At the WAIC, the focus shifted from individual robot models to practical applications, with over 60 out of 200 exhibiting companies emphasizing 'scenarios' for deployment. A notable example was the AI robot S1 from Astribot, showcased at various booths, performing tasks from sorting medications to assisting in retail environments. The significance of this trend lies in the growing recognition that operational capabilities and versatile applications are crucial for commercial success in robotics. Companies like Ant Group, JD.com, and Xian Gong Intelligent are leveraging the same humanoid robot for diverse tasks, indicating a shift in the industry towards physical operational intelligence. Looking ahead, the emphasis on the S1 robot's adaptability and safety features suggests a promising future for humanoid robots in various sectors. However, challenges remain in transitioning from product development to commercial deployment, as many manufacturers still face uncertainties in scaling production and fulfilling orders.
Humanoid Robots Robotics Applications AI Technology Physical Intelligence
BrainCo Showcases Brain-Controlled Robot Platform at WAIC 2026 Event
BrainCo, a developer of brain-computer interfaces based in Hangzhou, showcased its innovative brain-controlled robot platform during WAIC 2026. This advanced system utilizes an EEG headset to convert neural signals from users into actionable commands for various machines, including humanoid robots, robotic arms, and robot dogs. The significance of this demonstration lies in its potential to revolutionize human-robot interaction by enabling users to control robots through thought alone. By translating imagined actions into physical operations, BrainCo's platform aims to enhance the efficiency and intuitiveness of robotic systems, paving the way for more seamless integration into everyday tasks. Looking ahead, the focus will be on how BrainCo continues to develop this technology and its applications across different sectors. No further timeline was disclosed at the time of publication.
News Feed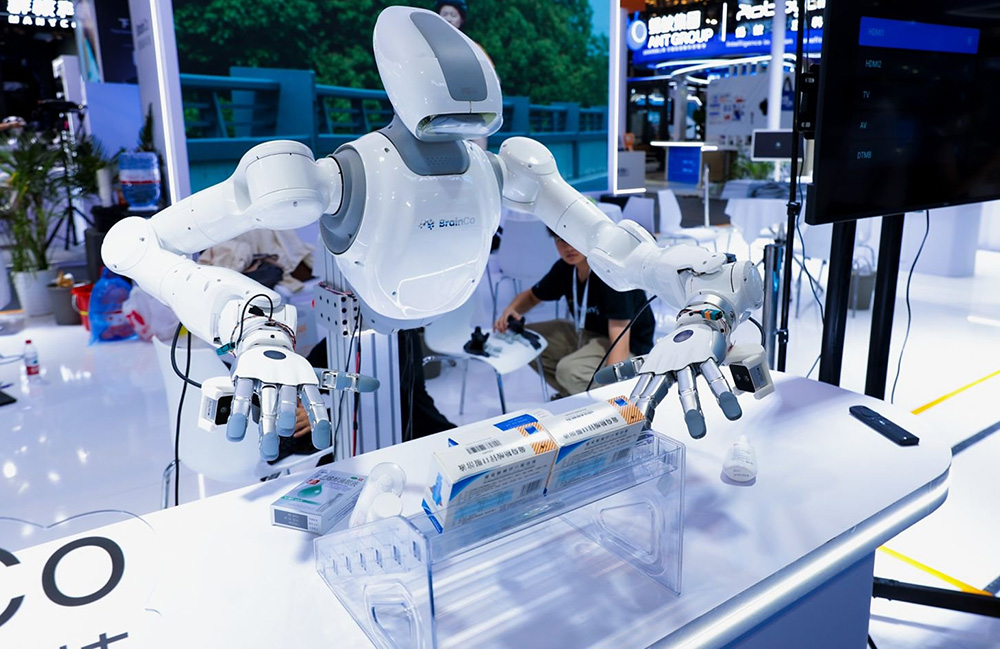
BrainCo Unveils Brain-Controlled Robot AI Platform at 2026 WAIC
BrainCo showcased its innovative brain-controlled robot AI platform at the 2026 World Artificial Intelligence Conference. Users can direct a robotic arm using neural signals captured by a lightweight EEG headset, enabling actions like grasping objects with precision. This technology, developed over a decade, integrates brain-computer interfaces and AI to enhance human-machine collaboration. The significance of this platform lies in its ability to decode user intent and translate it into machine actions in under 200 milliseconds. BrainCo's approach, termed 'neuro-embodied-AI,' allows for compatibility with various commercially available robots, facilitating integration into existing research and development frameworks without the need for proprietary hardware. Looking ahead, BrainCo also introduced its Embodied AI Data Collection Solution, addressing the challenge of obtaining high-quality training data for complex robotic tasks. This system captures both human actions and EEG data, providing a comprehensive dataset for training robots in dexterous tasks. No further timeline was disclosed at the time of publication.
Arms / Manipulators Artificial Intelligence Artificial Intelligence / Cognition Design / Development Healthcare Robotics Human Robot Interaction / Haptics
BrainCo Unveils First Brain-Machine Interface for Controlling Robots at WAIC 2026
At the 2026 World Artificial Intelligence Conference (WAIC), BrainCo launched the world's first brain-controlled robot AI platform. This innovative system utilizes a non-invasive electroencephalogram (EEG) headset to convert human neural activity into executable commands for robots in real-time. The significance of this technology lies in its potential to revolutionize human-robot interaction. By simply thinking about an action, users can control robots to perform tasks such as grabbing or moving objects without verbal commands or button presses. BrainCo's platform is designed to create a 'human-machine co-training' data loop, which will gather extensive data from users to enhance AI's physical world interactions. Looking ahead, BrainCo's brain-machine interface could mark the beginning of a new era in human-robot collaboration. As users engage with the system, the feedback and data collected will be invaluable for refining AI algorithms and improving the overall user experience. No further timeline was disclosed at the time of publication.
Brain-Machine Interface Robotics Artificial Intelligence EEG Technology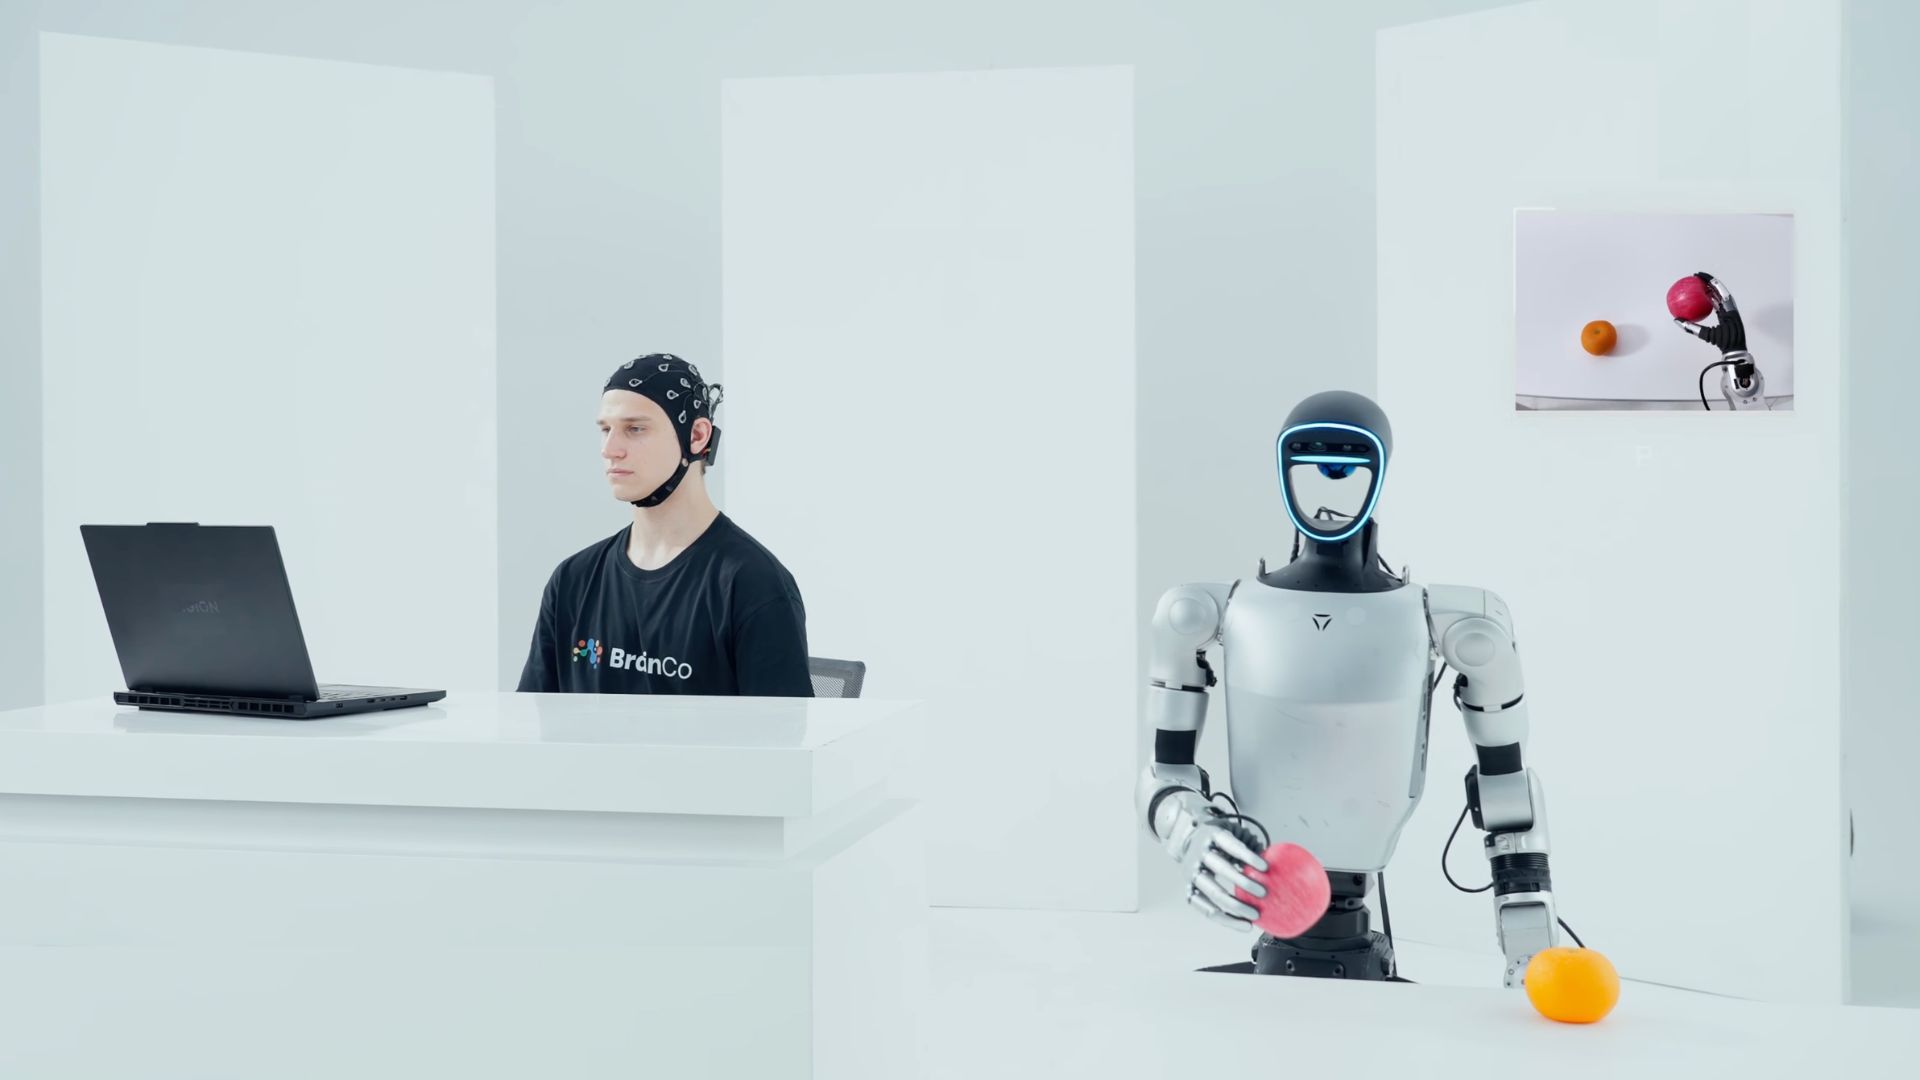
BrainCo Launches Innovative Brain-to-Robot Platform for Thought-Controlled Machines
BrainCo has introduced a groundbreaking 'brain-to-robot' platform at the World Artificial Intelligence Conference in Shanghai. This system enables users to control robots solely through brain signals, utilizing a non-invasive brain-computer interface (BCI) that interprets electrical signals from the brain via an EEG headset. This development is significant as it addresses a major challenge in robotics: understanding human intentions. Nyx He, senior vice-president of BrainCo, emphasized that while robots have advanced in autonomous actions, the next frontier is enhancing their ability to comprehend human commands. The platform also aims to generate high-quality training data essential for training intelligent machines. Looking ahead, BrainCo's platform is compatible with various third-party hardware, including humanoid robots and robotic arms. The potential for this technology extends beyond mere control, as it could significantly improve the training processes for future robots, addressing the critical need for real-world interaction data in embodied AI applications. No further timeline was disclosed at the time of publication.
AI and Robotics Innovation
Noetra Initiates Development of Japan's Multimodal AI Foundation Model for Robotics
Noetra, in collaboration with key partners including Sony, SoftBank, NEC, and Honda Motor, has launched extensive R&D for a multimodal foundation model aimed at enhancing AI-enabled robotics in Japan. This initiative is part of a broader effort to develop sovereign AI technologies within the country, supported by investments from 44 companies across various sectors, primarily manufacturing. The significance of this development lies in its potential to position Japan as a leader in physical AI. By creating a robust multimodal foundation model, Noetra aims to improve industrial competitiveness and address societal challenges through advanced AI capabilities, including natural language processing and multimodal data understanding. Looking ahead, Noetra plans to construct AI computing infrastructure with Nvidia's advanced GPUs, with operations expected to commence in June 2028. The phased development will culminate in a comprehensive omni-modal foundation model by fiscal 2028, ultimately striving for a “Real-world Native AI” by fiscal 2030, which will be capable of understanding physical properties in real-world applications.
Artificial Intelligence News Robot simulation ai agents AI infrastructure artificial intelligence
AI Agent Autonomy's Impact on Robotics Safety and Control Mechanisms
Robotic systems are increasingly capable of perceiving, choosing, and altering their behavior autonomously, without human intervention. This shift towards autonomy enhances adaptability in various environments such as warehouses and labs, but it also raises significant concerns regarding safety and control. Traditional safety measures, including physical barriers and emergency buttons, may no longer suffice as robots undertake more complex tasks. The implications of this autonomy are profound, as organizations must now assess the quality of decisions made by autonomous systems, the reliability of their software, and the protocols for monitoring their actions. Unlike conventional robots that follow fixed commands, autonomous robots can evaluate multiple scenarios and make decisions based on real-time conditions, which complicates safety protocols. Ensuring that these systems operate safely requires a reevaluation of existing safety standards that focus on speed and force. Looking ahead, it is crucial for operators to have adequate information to respond effectively to unexpected robot behavior. Autonomous robots utilize various sensors to interpret their environment, but factors like dust and poor lighting can affect input quality. Organizations should prioritize the definition and testing of triggers for human intervention to maintain a balance between autonomy and safety. No further timeline was disclosed at the time of publication.
AI agents Infrastructure AI agent autonomy ai agents ai safety automation
Pudu Robotics Showcases 'One Brain, Multiple Embodiments' Technology and PUDU D7 at WAIC 2026
Pudu Robotics presented its advancements in the 'One Brain, Multiple Embodiments' technology architecture at WAIC 2026. The event featured an in-depth exploration of its Physical Agent architecture, highlighting the innovative capabilities of this system. The company also unveiled the PUDU D7, an industrial-grade semi-humanoid robot, during its first offline public showcase. This demonstration marks a significant step in Pudu Robotics' efforts to enhance automation solutions across various sectors. Looking ahead, industry observers will be keen to see how Pudu Robotics continues to develop its technology and the potential applications of the PUDU D7 in real-world scenarios. No further timeline was disclosed at the time of publication.
BrainCo Launches Innovative Brain-Controlled Robot Platform at World AI Conference in China
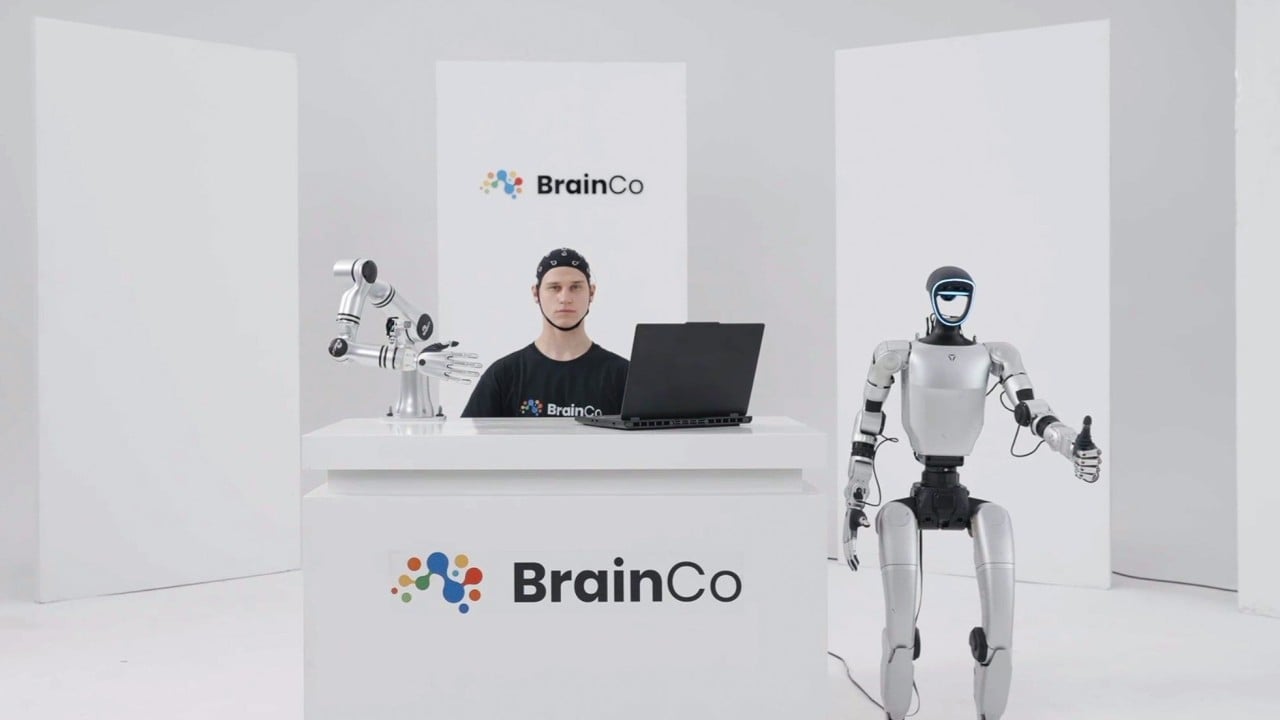
BrainCo, based in Hangzhou, has introduced a groundbreaking robot platform that allows users to control robots using only their thoughts through EEG headsets. This advancement signifies a major step forward in embodied AI technology, where artificial intelligence is integrated into physical machines, enabling them to interact with the real world. The significance of this development lies in its potential to revolutionize human-robot interaction. By utilizing electroencephalogram (EEG) headsets, BrainCo's platform captures brain signals and employs AI algorithms to decode these signals, translating user intentions into robotic actions. This capability could enhance various applications across industries, making robots more intuitive and responsive to human commands. Looking ahead, the platform's compatibility with diverse third-party hardware, including humanoid robots and robotic arms, suggests a wide range of potential use cases. As the competition among global technology firms intensifies in the realm of embodied AI, BrainCo's innovation will be crucial to monitor for its impact on the future of robotics and AI integration. No further timeline was disclosed at the time of publication.
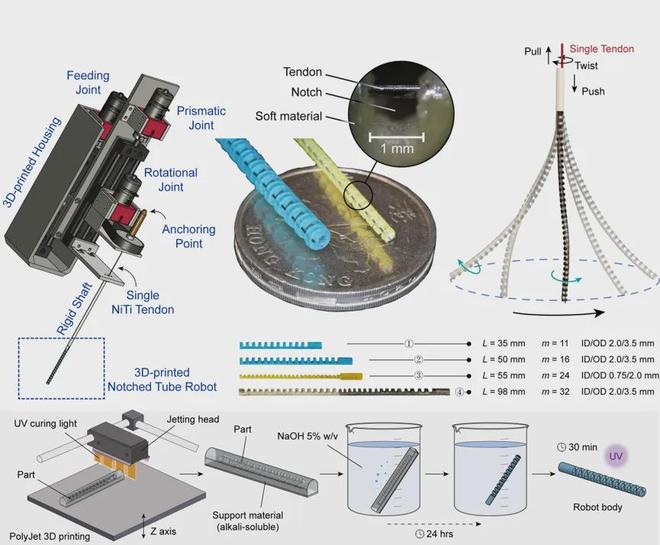
CUHK Introduces Innovative Single-Tendon Continuum Robots for Enhanced Motion Control
The Chinese University of Hong Kong (CUHK) has developed a groundbreaking single-tendon-driven continuum robot, addressing the longstanding challenges in minimally invasive medical applications. This innovative design utilizes a single eccentrically arranged tendon to achieve near omnidirectional motion control, significantly simplifying the actuator and transmission system while maintaining a compact size. This advancement is crucial as traditional tendon-driven continuum robots (TDCRs) rely on multiple tendons for three-dimensional motion, leading to increased complexity and limitations in miniaturization. The new paradigm proposed by CUHK's research team not only enhances spatial manipulation capabilities but also improves force transmission efficiency, paving the way for next-generation minimally invasive surgical robots. Looking ahead, the research, published in Nature Communications, offers a new design and technological pathway for continuum robots, inspired by the flexible movement observed in biological systems. No further timeline was disclosed at the time of publication.
Continuum Robots Medical Robotics Robotic Motion Control Tendon-Driven Robotics
Control Method Developed for Heavy-Duty Hexapod Robot Navigating Border Terrains Using Simplified Model
A new control method has been developed for a heavy-duty hexapod robot designed to walk on border terrains, as reported in the Journal of Field Robotics. This method utilizes a simplified model to enhance the robot's navigation capabilities in challenging environments. The significance of this development lies in its potential applications in various sectors, including military and disaster response, where navigating difficult terrains is crucial. The heavy-duty hexapod robot's ability to traverse border terrains effectively could improve operational efficiency and safety in these scenarios. Looking ahead, the implications of this control method could lead to further advancements in robotic mobility and control systems. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
Allocentric Teleoperation Enhances Multirobot Coordination from Variable Perspectives
In the July 2026 issue of Science Robotics, researchers introduced allocentric teleoperation as a novel approach to enhance multirobot coordination. This method allows operators to control multiple robots from various perspectives, improving situational awareness and operational efficiency. The significance of this development lies in its potential to transform how operators interact with robotic systems. By enabling a variable perspective, allocentric teleoperation can facilitate more intuitive control and better decision-making in complex environments, which is crucial for applications in fields such as search and rescue, exploration, and industrial automation. Looking ahead, the implications of allocentric teleoperation could lead to advancements in robotic teamwork and autonomy. Future research may focus on refining this technology and exploring its integration into existing robotic systems. No further timeline was disclosed at the time of publication.
Research Article
Agile Multiskill Locomotion Techniques for Quadrupedal Robots in Natural Environments
A recent study published in Science Robotics explores advanced locomotion techniques for quadrupedal robots designed for outdoor environments. The research focuses on developing agile and perceptive multiskill locomotion capabilities that enable these robots to navigate complex terrains effectively. This advancement is significant as it enhances the operational versatility of quadrupedal robots, making them more suitable for various applications in challenging environments. By improving their ability to adapt to different terrains, these robots can be utilized in fields such as search and rescue, environmental monitoring, and exploration. Looking ahead, the implications of this research could lead to further innovations in robotic mobility and autonomy. No further timeline was disclosed at the time of publication.
Research ArticleRobotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.