

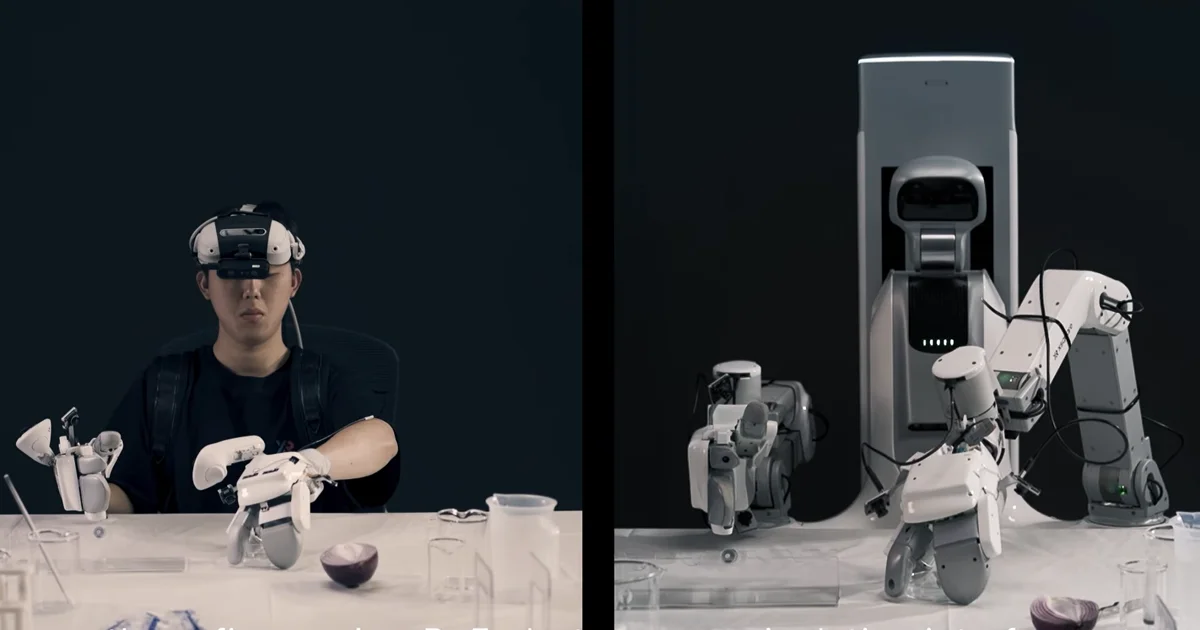
X Square Robot, based in Shenzhen, has unveiled TwinDEX, a new manipulation platform designed to bridge the data gap in embodied artificial intelligence. This innovative system connects a wearable exoskeleton to a robotic end effector, ensuring identical geometry and functionality, which enhances data fidelity and collection efficiency.
The introduction of TwinDEX is significant as it addresses the limitations of traditional data collection methods, which often struggle with the embodiment gap. By utilizing a three-finger, nine-degree-of-freedom architecture, TwinDEX allows for versatile manipulation capabilities while maintaining mechanical reliability and cost-effectiveness.
Looking ahead, X Square's approach could redefine how data is gathered for robotic applications, particularly in complex tasks requiring precision. The company has demonstrated TwinDEX's capabilities through a continuous chemistry experiment, showcasing its potential to operate effectively without relying on conventional teleoperation data. No further timeline was disclosed at the time of publication.
Editor's Note
The launch of TwinDEX by X Square highlights a pivotal moment in the robotics sector, particularly in the context of data collection for embodied AI. As companies strive to enhance the efficiency and reliability of robotic systems, innovations like TwinDEX could significantly influence the competitive landscape, driving advancements in automation and intelligent manufacturing.










Leave a comment