

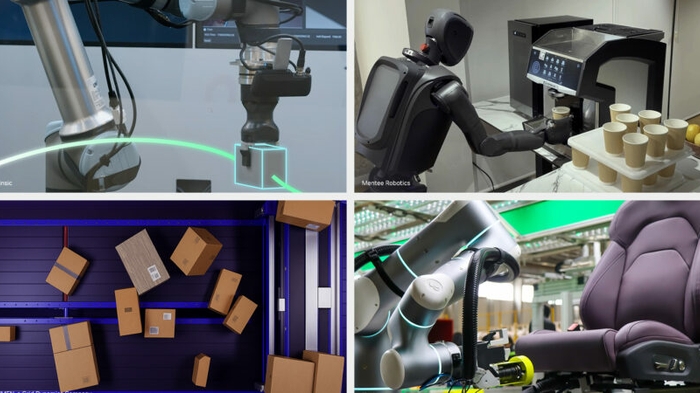
NVIDIA has unveiled Isaac ROS 5.0 at the ROSCon conference in Toronto, Canada, aimed at advancing robotics applications. This release introduces new agentic workflows and platform support, enabling developers to build and deploy robotics applications more efficiently. With nearly 1.3 million ROS users, NVIDIA Isaac ROS integrates accelerated computing and physical AI models to enhance the development process.
The significance of this release lies in its ability to streamline robotics development through the introduction of reusable workflows and agent-ready documentation. These features allow developers and AI agents to collaborate effectively, automating repetitive tasks and accelerating the transition from concepts to functional applications. The integration with ROS Lyrical and Ubuntu 24.04 further supports the adoption of the latest ROS platform while leveraging NVIDIA's computing capabilities.
Looking ahead, the robotics community is expected to embrace the agentic approach introduced by Isaac ROS 5.0, which includes new skills for setup and manipulation. The introduction of advanced features, such as the FoundationStereo fine-tuning skill and FoundationPose model, will likely enhance perception and tracking capabilities in robotics applications. No further timeline was disclosed at the time of publication.
Editor's Note
The launch of NVIDIA Isaac ROS 5.0 marks a significant advancement in the robotics sector, particularly in the context of open-source development. As AI agents increasingly influence software development, the integration of these capabilities into robotics could reshape workflows and enhance productivity. Stakeholders should monitor how these innovations impact the competitive landscape and the adoption of robotics technologies across various industries.













Leave a comment