


Feagine Robotics has launched Fi0, a cross-embodiment foundation model that retains task knowledge across various robot structures. This innovation addresses the challenge of adapting AI systems to different physical forms, enhancing their ability to generalize across unfamiliar machines.
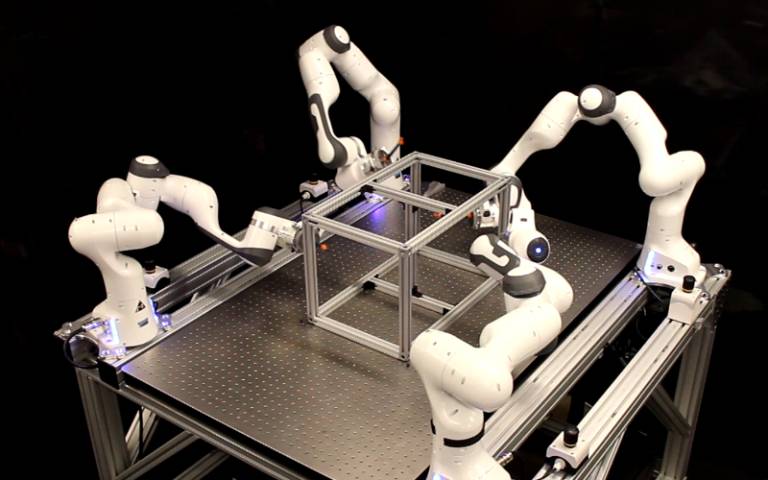
The introduction of three tendon-driven soft manipulators—A01, A02, and A03—supports this concept by providing varying lengths and degrees of freedom. This approach is crucial as robotics evolves beyond standardized industrial arms, allowing for improved adaptability and efficiency in diverse operational environments.
Looking ahead, Feagine aims for Fi0 to minimize retraining when robots face new tasks, enabling them to learn from single human demonstrations. This could revolutionize how robots interact with their environments, suggesting a future where multiple robot embodiments can share intelligence seamlessly, catering to specific applications without being limited by their physical designs. No further timeline was disclosed at the time of publication.
Editor's Note
Feagine Robotics' introduction of the Fi0 model represents a significant advancement in the robotics sector, particularly in the context of soft robotics and cross-embodiment learning. This innovation could reshape how robots are deployed across various industries, enhancing their versatility and reducing the need for extensive retraining. As the demand for adaptable robotic solutions grows, this approach may lead to more efficient manufacturing and automation processes.

















Leave a comment