


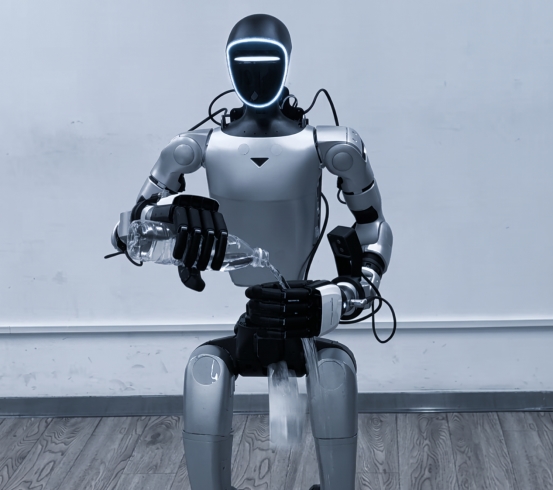
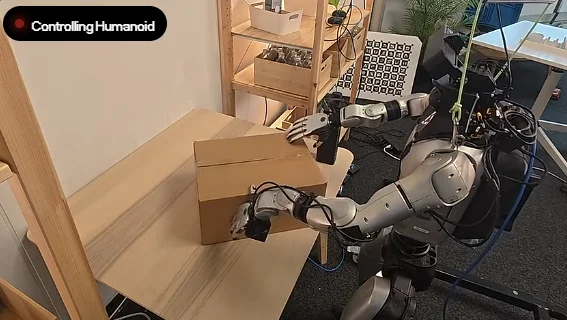
On August 10, 2026, Daimon Robotics unveiled the world's first Tactile-grounded World Model (Daimon-TWM), showcasing a robot's ability to adapt to unexpected disturbances without stopping or colliding. This demonstration challenges the conventional belief that robots can only execute standardized processes and fail when disrupted.
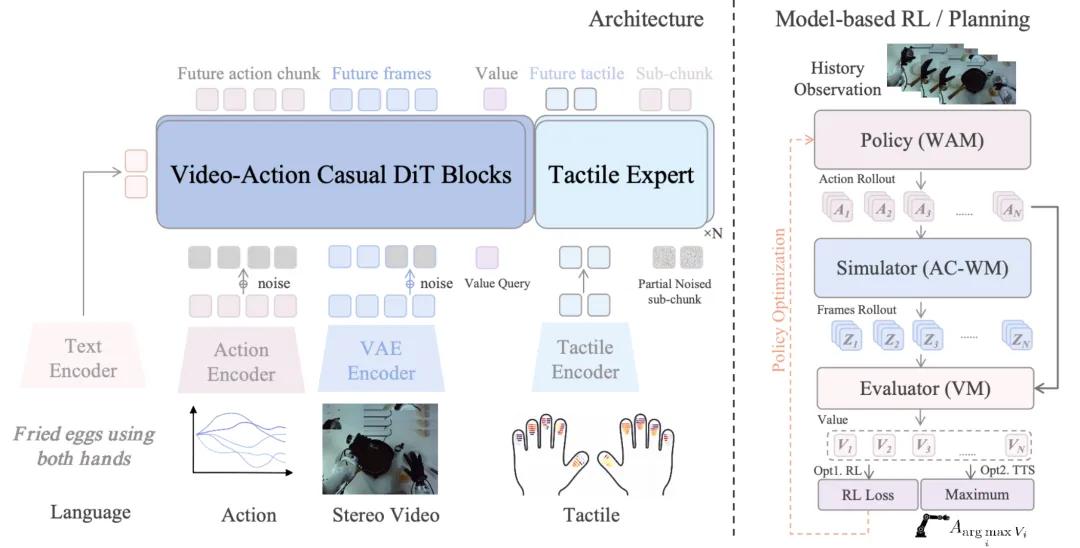
The significance of Daimon-TWM lies in its innovative integration of physical cognition, predictive decision-making, and instantaneous control within a unified framework. This model allows robots to understand physical states through tactile feedback, anticipate risks before they occur, and make real-time adjustments, enhancing their operational capabilities in dynamic environments.
In testing, Daimon-TWM achieved an average success rate of 64.0% under undisturbed conditions and 53.5% under disturbances, outperforming traditional models significantly. This breakthrough emphasizes the importance of tactile input as a core element throughout the operational process, marking a pivotal advancement in embodied intelligence technology.
Editor's Note
Daimon's introduction of the Tactile-grounded World Model represents a significant leap in the field of embodied intelligence, emphasizing the role of tactile feedback in robotic operations. This innovation could reshape how robots interact with their environments, potentially leading to broader applications in various industries, including manufacturing and logistics. The competitive landscape may shift as companies strive to enhance robotic dexterity and adaptability.












Leave a comment