

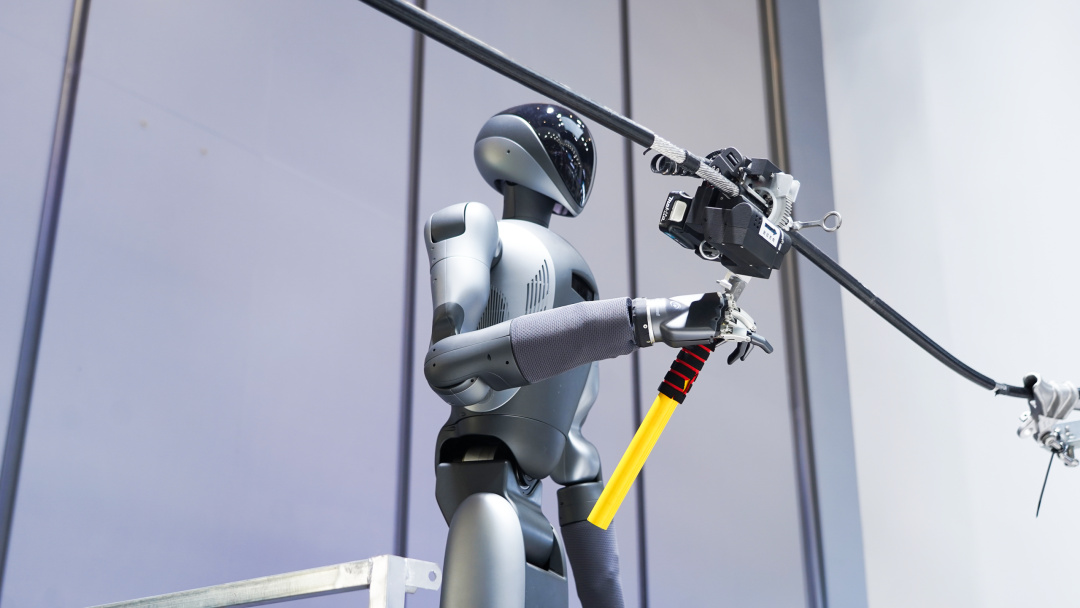
Zinova, a spinoff from RIC Robotics, has introduced a new approach to construction robotics by focusing on tool-handling capabilities. Co-founder Xu Ziyou emphasized that their goal is to equip robots with the ability to use tools effectively, rather than replicating human dexterity. This approach involves a non-dextrous gripper and a force feedback sensor called TEISI, which captures the interactions between tools, robots, and materials.
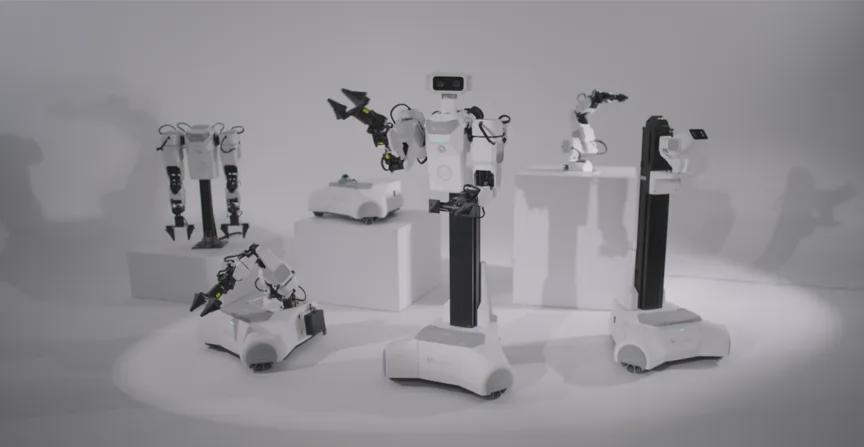
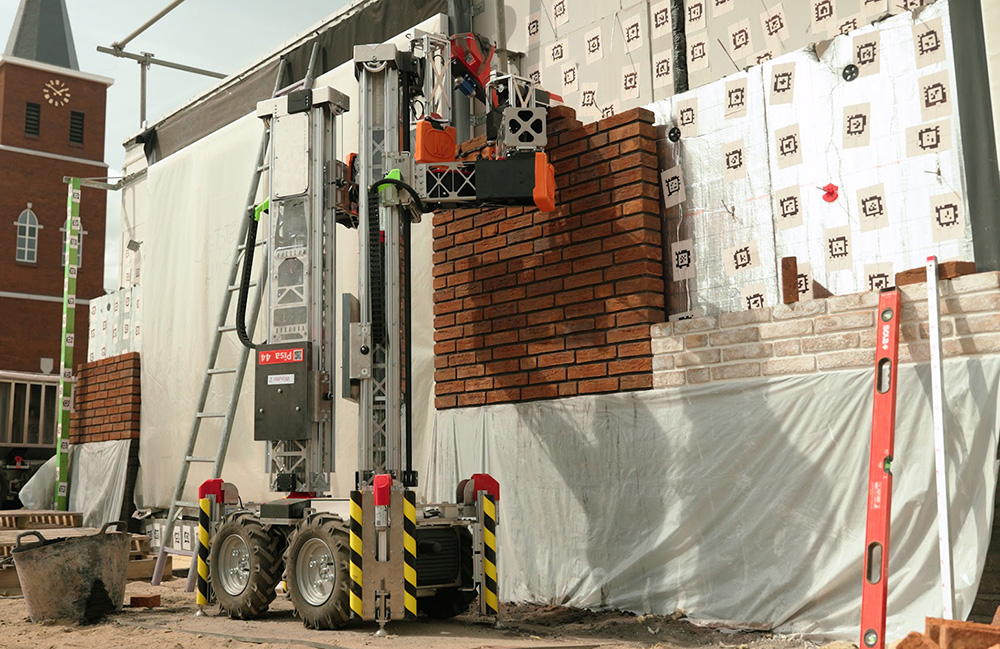
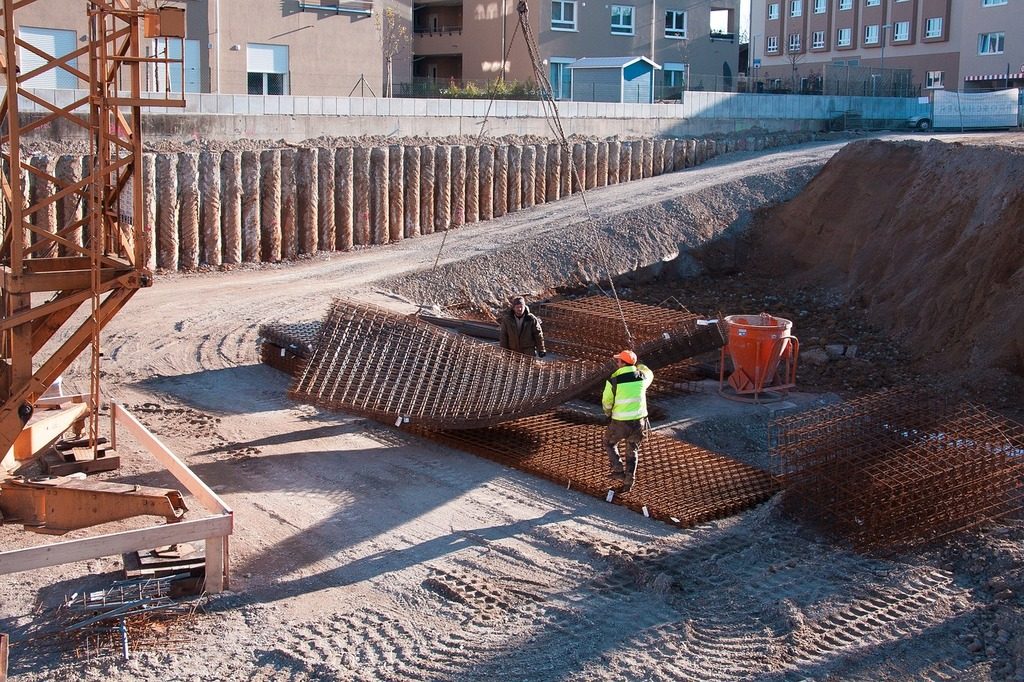
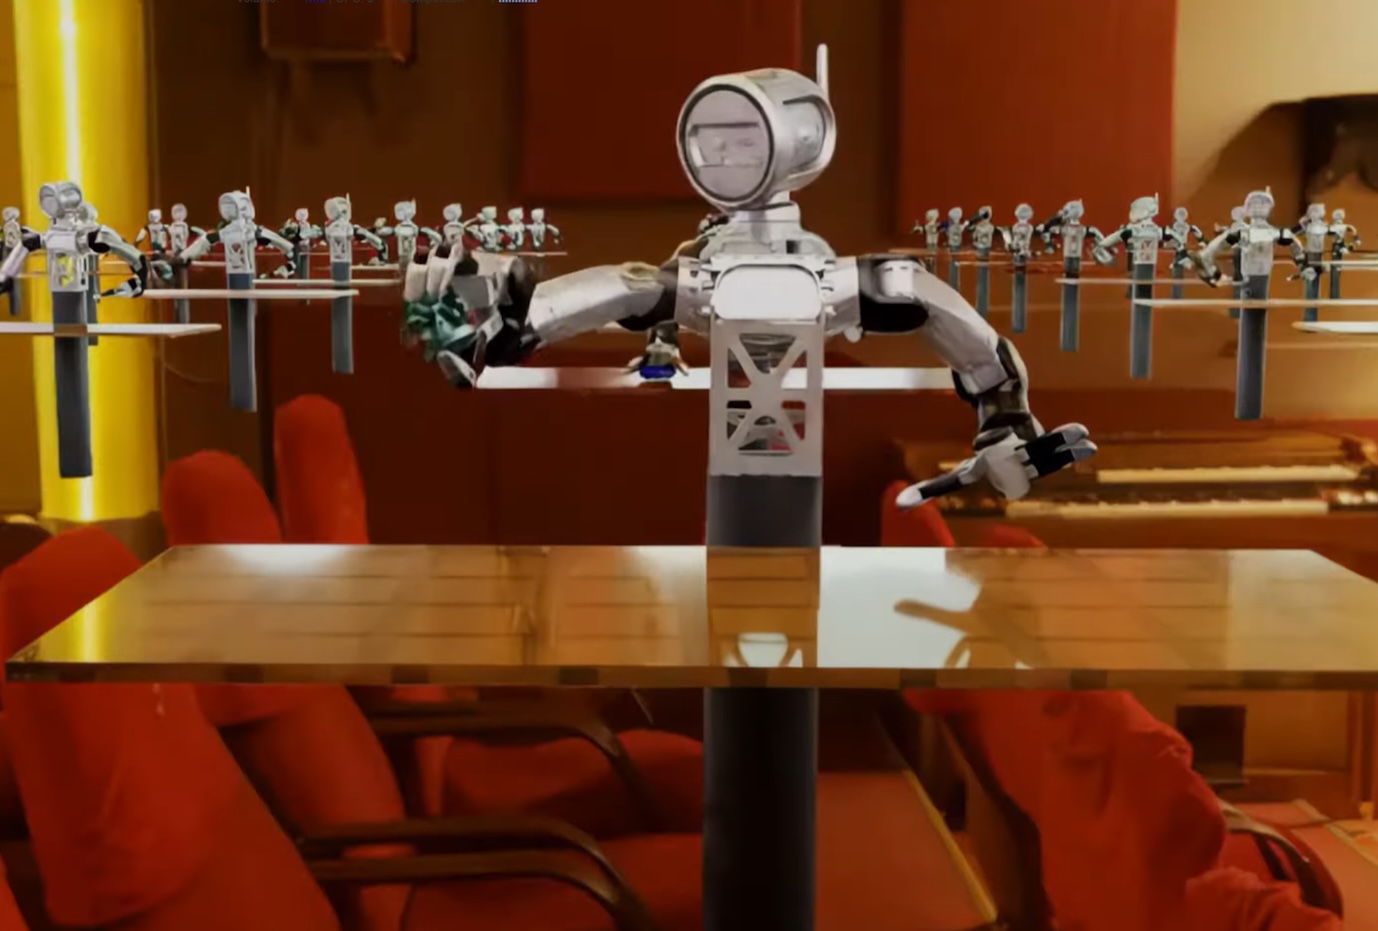
The construction industry faces significant challenges, including an aging workforce and high project overruns. Zinova aims to adapt robots to existing tools rather than redesigning construction sites. Their demonstration utilized the TRON 2 dual-arm robot to perform a series of tasks, showcasing the potential for robots to handle various tools and processes in a coherent workflow.
As Zinova prepares for real-world applications, the focus will be on how their technology performs on actual construction sites. The implications of their approach could lead to greater adaptability in construction robotics, addressing labor shortages and safety concerns in the industry. No further timeline was disclosed at the time of publication.
Editor's Note
Zinova's innovative approach to construction robotics highlights a shift in focus from dexterity to effective tool usage. This could significantly impact the industry's ability to address labor shortages and improve safety on construction sites. As the sector grapples with an aging workforce and project inefficiencies, solutions like Zinova's may pave the way for more adaptable and efficient robotic systems in construction.














Leave a comment