

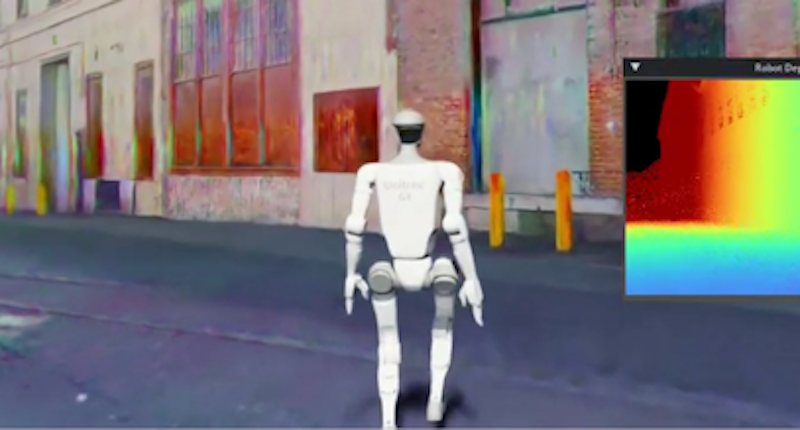
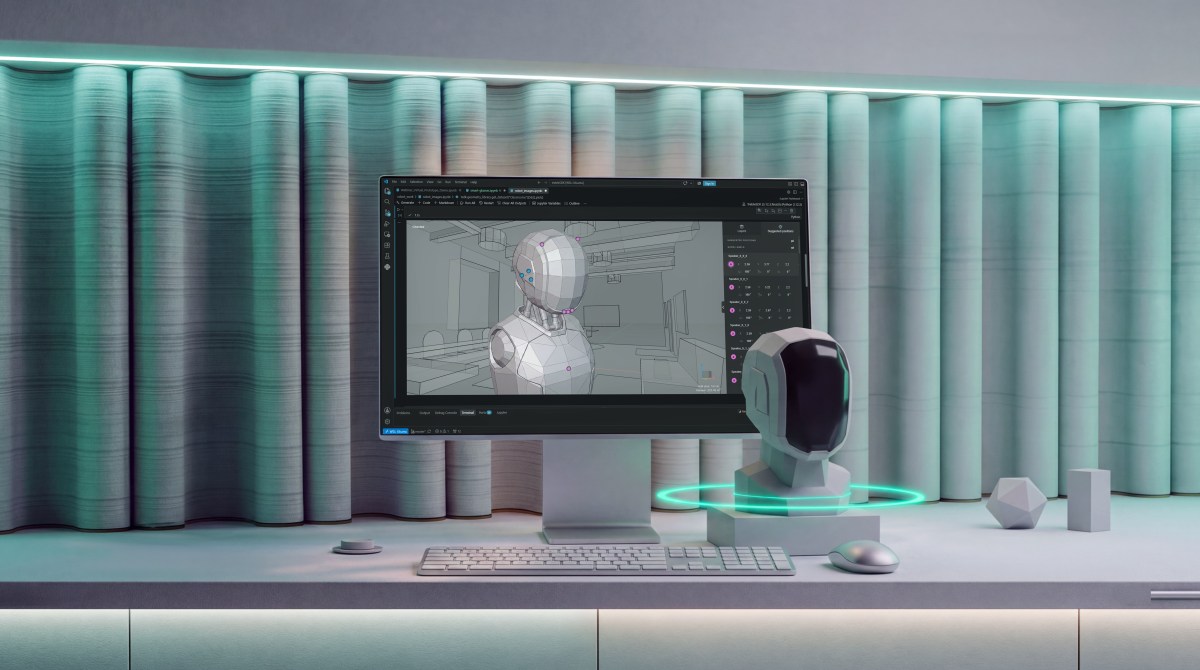
Niantic Spatial has launched USDZ export for its Scaniverse app, enabling robotics developers to convert real-world environments into simulation-ready digital twins for use with Nvidia Isaac Sim. The new capability is designed to help address the long-standing “sim-to-real” gap in robotics, where systems trained in synthetic environments often struggle when deployed in complex, real-world settings. […]
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.






Leave a comment