

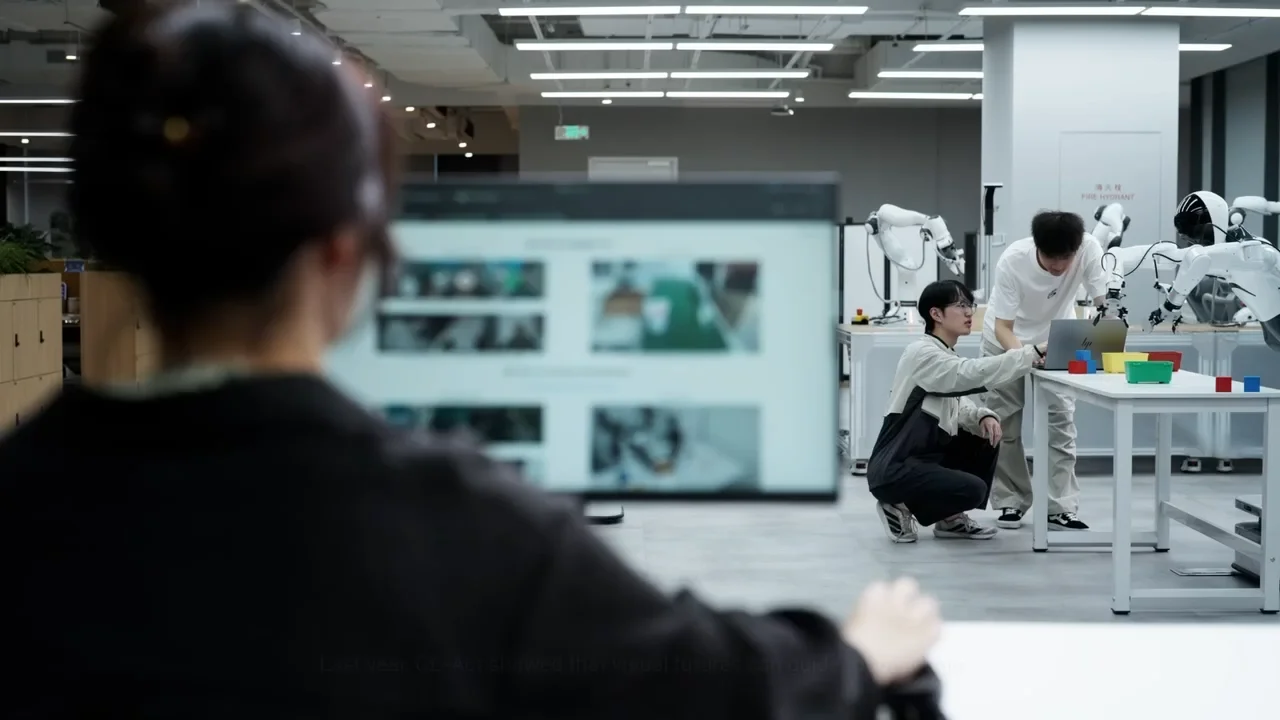
AGIBOT has officially released Genie Envisioner Act 2.0 (GE-Act 2.0), an open-source World-Action Model designed for training generalist manipulation policies. This release comes just after Unitree Robotics open-sourced its UnifoLM-WLA-1.0, marking a significant shift in the humanoid robotics landscape towards open-source models.
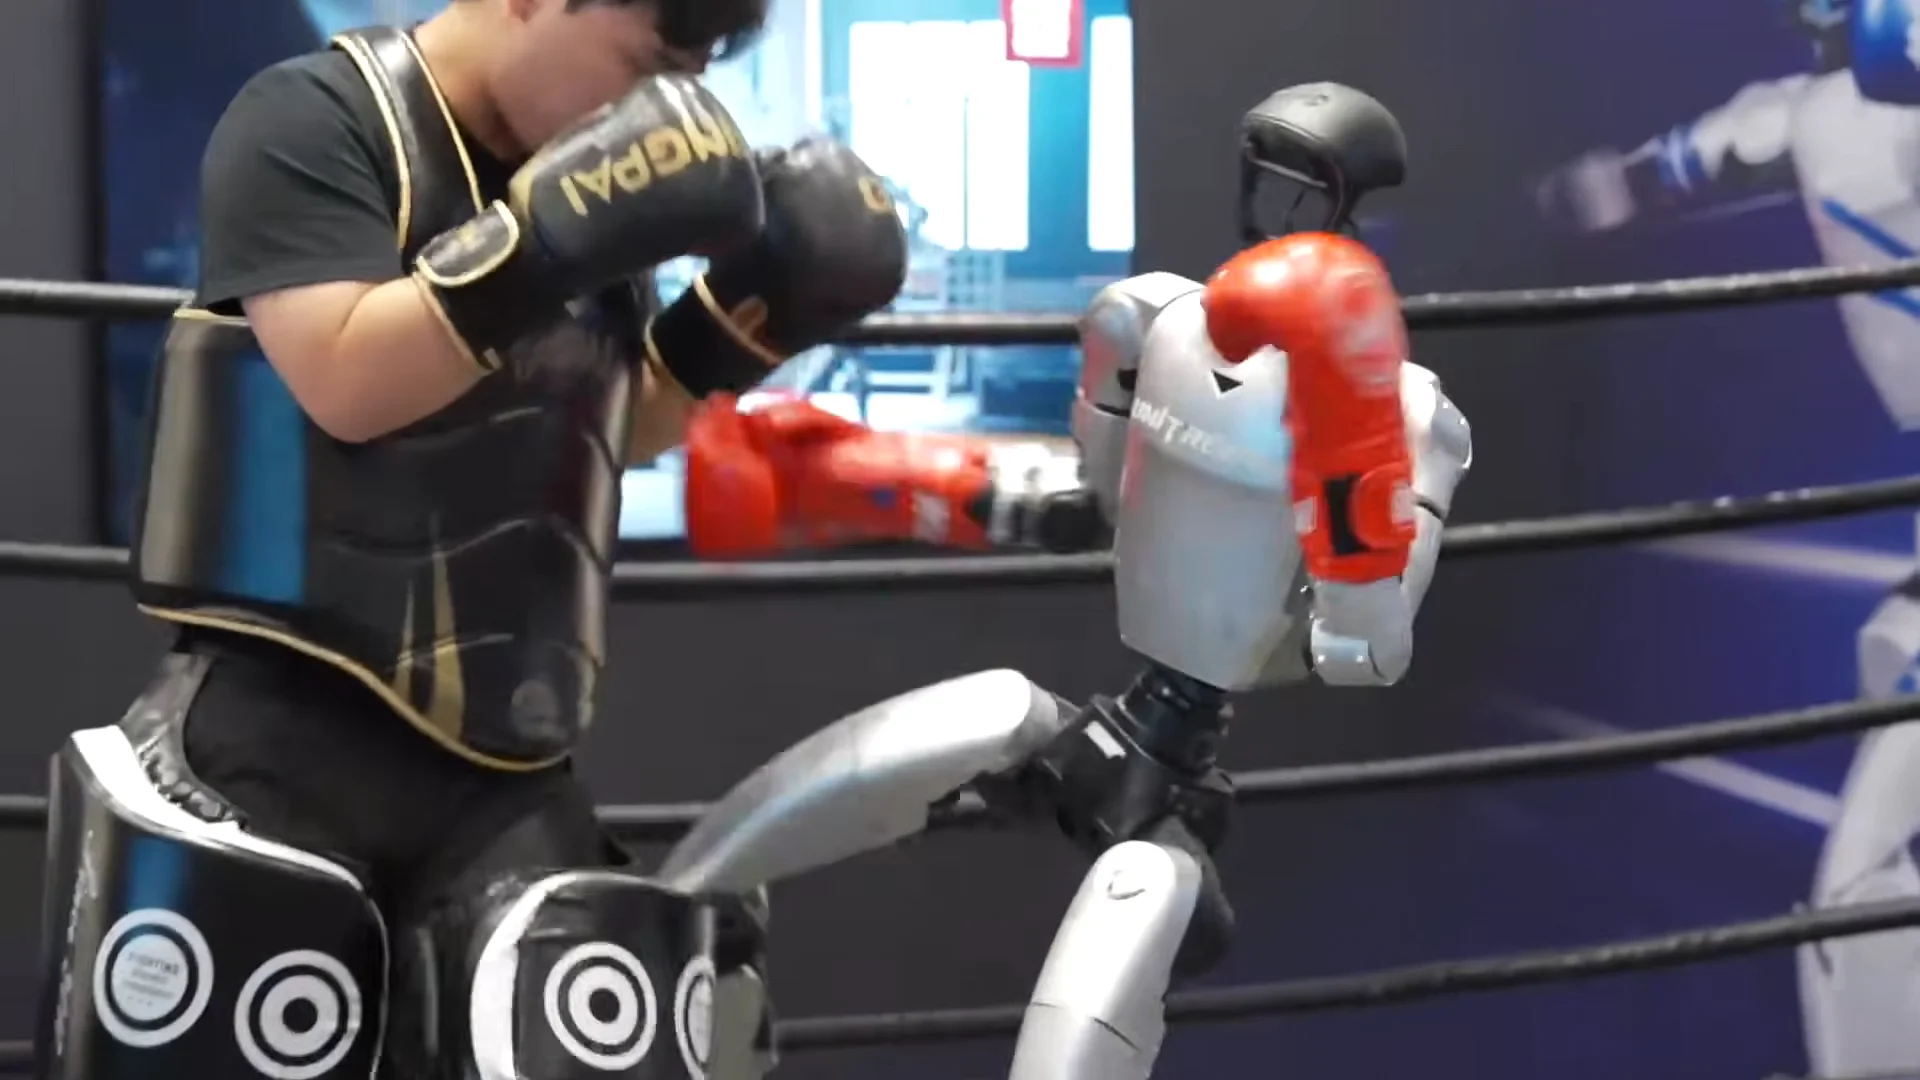
The introduction of GE-Act 2.0 highlights a competitive dynamic between AGIBOT and Unitree, particularly as AGIBOT recently achieved a manufacturing milestone of 15,000 units and leads in global shipments for the first half of 2026. Both companies are now focused on establishing a dominant open operating stack for robotic intelligence, moving away from traditional proprietary systems.
As AGIBOT's GE-Act 2.0 aims to enhance real-time robot control through modular stages, it addresses the limitations of existing Vision-Language-Action models. The methodology allows for faster processing and independent training of visual and action systems, which could redefine how robots learn from physical interactions. No further timeline was disclosed at the time of publication.
Editor's Note
The competition between AGIBOT and Unitree signifies a pivotal moment in the humanoid robotics sector, where open-source models are becoming increasingly important. This shift may influence investment strategies and technology adoption as companies seek to leverage collaborative advancements in AI and robotics. The focus on modular systems in AGIBOT's GE-Act 2.0 could also impact future developments in real-time robotic applications.













Leave a comment