

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.
Enhancing Urban Traffic Management Efficiency with IoT-Aided Robotics and Graph Neural Networks
Recent advancements in IoT-aided robotics have shown significant potential for improving urban traffic management. By utilizing a multi-component attention graph convolutional neural network, these systems can enhance real-time traffic monitoring capabilities, leading to more efficient traffic flow and reduced congestion. This development is crucial as urban areas continue to face increasing traffic challenges. The integration of advanced robotics and IoT technologies can provide city planners and traffic management authorities with the tools needed to optimize traffic patterns and improve overall urban mobility. Looking ahead, the focus will be on the implementation of these technologies in real-world scenarios. Continued research and development in this area will be essential to fully realize the benefits of IoT-aided robotics in urban traffic systems. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
Qianjue Technology and Tsinghua University Introduce New Neural Network Complexity Metric
Qianjue Technology, in collaboration with Tsinghua University, has proposed a new metric for assessing neural network complexity called Effective Degree (ED). This metric aims to quantify the complexity of learned models and enhance their ability to generalize in new environments, addressing a core challenge in robotics: the ability to make correct judgments in unfamiliar settings. The significance of this development lies in its potential to improve the selection of models for robotic brains, diagnose overfitting during training, and enhance generalization capabilities when facing new tasks and environments. The research has been validated across various tasks, including vision, language, and reinforcement learning, providing a new technical pathway for advancing robotics. Looking ahead, the research aligns with recent theories in world modeling, notably those discussed by Turing Award winner Yann LeCun. The methodologies employed by the Qianjue-Tsinghua team, which focus on the recovery of hidden variables in data generation, echo similar inquiries in the field. No further timeline was disclosed at the time of publication.
Neural Networks Machine Learning Robotics AI Research
Enhanced Outdoor Robot Localization and Landmark Detection Using Dual-Discriminator Conditional GANs
A recent study published in the Journal of Field Robotics introduces a novel approach for outdoor robot localization and landmark detection. This method employs a Dual-Discriminator Conditional Generative Adversarial Network (GAN) alongside optimized binarized spiking neural networks to improve accuracy in challenging outdoor environments. The significance of this research lies in its potential to enhance robotic navigation and perception in real-world settings. By integrating advanced machine learning techniques, the proposed system aims to overcome common challenges faced by outdoor robots, such as variable lighting and complex terrain, thereby improving operational efficiency and reliability. Looking ahead, the implementation of this technology could lead to significant advancements in autonomous navigation systems. Researchers and developers in the field should monitor the progress of this approach and its applications in various outdoor scenarios, as it may set a new standard for robotic localization and landmark detection. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
Study on Offshore Wind Turbine Blade Repair Using Particle Swarm Optimization and Advanced Control Techniques
A recent study published in the Journal of Field Robotics explores innovative methods for repairing offshore wind turbine blades. The research focuses on utilizing a Particle Swarm Optimization-Backpropagation Neural Network combined with Improved Active Disturbance Rejection Control to enhance repair efficiency. This research is significant as it addresses the growing need for effective maintenance strategies in offshore wind energy, which is crucial for maximizing energy output and minimizing downtime. The integration of advanced algorithms aims to improve the precision and reliability of repair processes, ultimately contributing to the sustainability of wind energy. Looking ahead, the implications of this study could influence future developments in wind turbine maintenance technologies. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
MIT and York University Study Visual Learning in the Brain Using Neural Networks
Researchers at MIT’s McGovern Institute for Brain Research and York University in Toronto have investigated how visual learning occurs in the brain. By analyzing neural activity and utilizing computational modeling, they compared the learning processes of animals and an artificial neural network designed to mimic brain architecture. Their findings, published on July 8 in Nature Communications, reveal that changes in visual processing are crucial for learning to discriminate new objects. This research is significant as it enhances our understanding of the brain's adaptability and the mechanisms behind visual learning. The study suggests that while the overall activity patterns in the inferior temporal cortex remain stable, subtle changes occur in response to learned object recognition. These insights could inform educational strategies and improve learning outcomes across various contexts. Looking ahead, the researchers aim to further explore how these modest changes in neural activity contribute to learning. They believe that artificial neural networks can provide valuable insights into biological learning processes, potentially leading to new experimental approaches and predictions that extend beyond current understanding. No further timeline was disclosed at the time of publication.
Research Neuroscience Learning Brain and cognitive sciences Computer modeling Vision
A Novel High‐Voltage‐Wire Stripping Robot and Adaptive Fuzzy RBF Neural Network PID Controller Optimized by PSO‐GA Algorithm
In a recent study published in the Journal of Field Robotics, researchers have unveiled significant advancements in robotic navigation systems. This groundbreaking research, conducted by a team of engineers and scientists, was published in the June 2026 issue and highlights innovative algorithms that enhance the ability of robots to navigate complex environments. The study focuses on improving the efficiency and accuracy of robotic systems, which are increasingly utilized in various sectors, including agriculture, manufacturing, and disaster response. By employing advanced machine learning techniques, the researchers demonstrated how robots can better interpret sensory data and make real-time decisions, ultimately leading to safer and more effective operations. The research was conducted in various simulated environments, allowing the team to rigorously test the new navigation algorithms under different conditions. This work is particularly timely as industries are seeking to automate processes and improve operational efficiency in response to growing demands for productivity and safety. The findings are expected to have a profound impact on the future development of autonomous systems, paving the way for more sophisticated robots capable of performing tasks in unpredictable settings. As the field of robotics continues to evolve, this study represents a significant step forward in the quest for smarter, more adaptable machines.
RESEARCH ARTICLE
Pose Estimation Accuracy Improvement Using Different Orientation Representations With Neural Networks: Case Study for the VIVE HTC Tracker
In a recent study published in the Journal of Field Robotics, researchers from a leading robotics institute have unveiled innovative advancements in autonomous navigation systems. This groundbreaking research, conducted in October 2023, aims to enhance the efficiency and safety of robotic applications in various fields, including agriculture and disaster response. The team focused on developing algorithms that enable robots to better interpret their surroundings and make real-time decisions. By integrating advanced sensor technology and machine learning techniques, the researchers demonstrated how these systems could significantly improve the robots' ability to navigate complex environments. The motivation behind this research stems from the increasing demand for autonomous solutions that can operate in unpredictable conditions. As industries seek to leverage robotics for tasks that are hazardous or labor-intensive, the need for reliable navigation systems becomes paramount. The study involved extensive field tests, where the robots were deployed in diverse scenarios to assess their performance. The results indicated a marked improvement in navigation accuracy and obstacle avoidance, showcasing the potential for these technologies to revolutionize how robots are utilized in real-world applications. This research not only contributes to the academic field but also has practical implications for industries looking to adopt autonomous systems. By addressing the challenges of navigation in dynamic environments, the findings pave the way for more effective and safer robotic operations in the future.
RESEARCH ARTICLE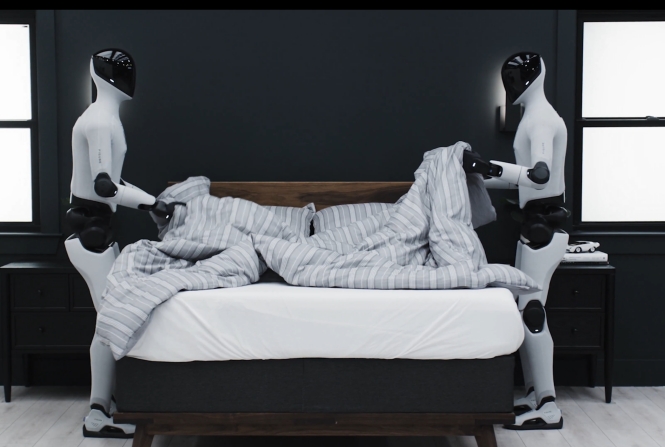
Two Robots Team Up for Life: The World's First Multi-Robot Collaboration Using a Single Neural Network
Figure AI has made a significant advancement in robotics by demonstrating the successful collaboration of two humanoid robots, equipped with the innovative Helix-02 system, to clean a bedroom in under two minutes. This event, which took place recently, represents a milestone in the field of robotics as it is the first instance of multi-robot cooperation utilizing a single neural network. The robots showcased remarkable autonomy and interaction, operating effectively without the need for central control. This breakthrough highlights the potential for enhanced efficiency in robotic tasks and paves the way for future developments in autonomous systems.
Humanoid Robots Robot Collaboration AI Automation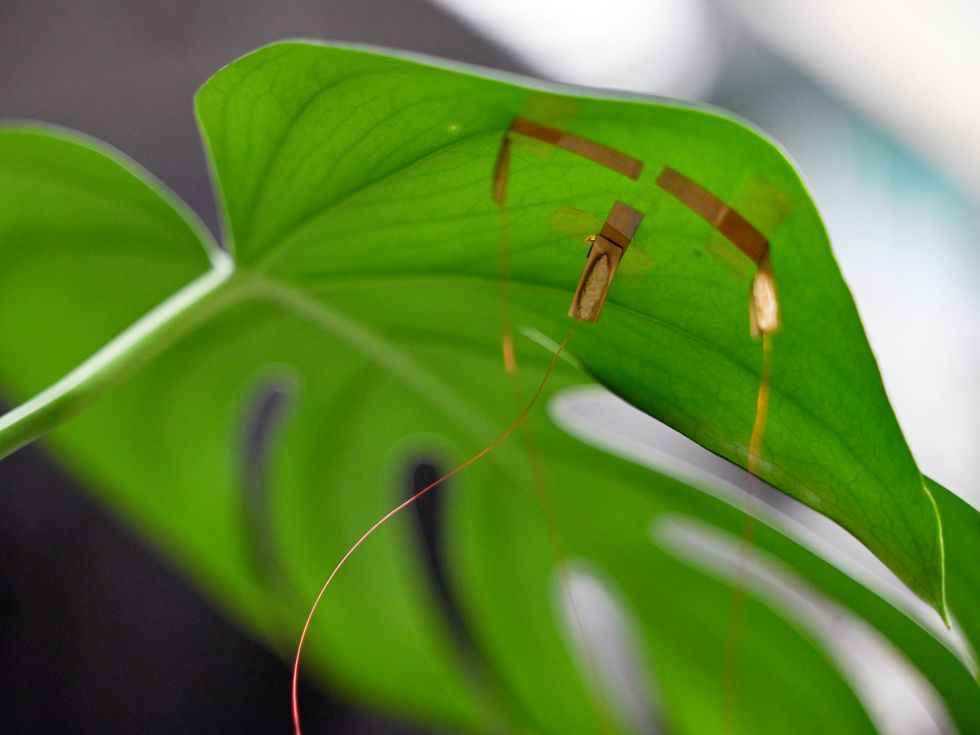
Graphene “Tattoos” for Plants Could Form Neural Networks
Researchers at the University of Texas at Austin have developed an innovative graphene "tattoo" that adheres directly to plant leaves, enabling real-time monitoring of leaf hydration. This breakthrough, published in the journal Nano Letters in February, addresses the limitations of traditional methods that require cutting leaves for moisture assessment. The sensor, which functions like a three-terminal transistor, sends electric pulses into the leaf, allowing it to measure moisture levels without disrupting photosynthesis. Led by associate professor Jean Anne Incorvia and graduate student Utkarsh Misra, the team envisions a future where these sensors could form a neural network across forests, providing critical data on drought and fire risks. The flexible and nearly transparent graphene material allows the tattoo to adapt to the leaf's movements, while its unique properties enable it to act as an artificial synapse, potentially enhancing plant-based computing. The concept emerged from a collaboration with geologist Ashley Matheny, highlighting the practical applications of the technology in agriculture and environmental monitoring. The researchers successfully trained a neural network to classify leaf hydration states, paving the way for more sophisticated plant monitoring systems that could help farmers and forest rangers respond to climate change challenges.
Graphene Agriculture Wildfires Neural-networks
Combining Neural Network and RRT*: A Novel Path Planning Method for Hyper‐Redundant Manipulators With 2N + 1 DOF
The Journal of Field Robotics has published an early view article highlighting recent advancements in robotic technology. This publication, released in October 2023, focuses on innovative applications of robotics in various fields, including agriculture, healthcare, and environmental monitoring. Researchers from multiple institutions collaborated to explore how these technologies can improve efficiency and accuracy in their respective sectors. The motivation behind this research stems from the increasing demand for automation and precision in tasks traditionally performed by humans. By utilizing advanced algorithms and machine learning techniques, the study demonstrates how robots can adapt to dynamic environments and perform complex tasks with minimal human intervention. This work is expected to contribute significantly to the ongoing discourse on the future of robotics and its potential to transform industries worldwide.
RESEARCH ARTICLE
A Boustrophedon‐Optimized Neural Network for Autonomous Path Planning in Large‐Scale Photovoltaic Farms
In May 2026, researchers published a significant study in the Journal of Field Robotics, focusing on advancements in robotic technology. The study explores innovative algorithms designed to enhance the navigation capabilities of autonomous robots in complex environments. Conducted by a team of engineers and computer scientists, the research aims to address the challenges faced by robots in real-world applications, such as search and rescue operations and environmental monitoring. The team conducted extensive field tests to validate the effectiveness of their algorithms, demonstrating improved accuracy and efficiency in navigation tasks. This research is particularly relevant as industries increasingly rely on autonomous systems for various applications, highlighting the need for reliable and adaptable robotic solutions. The findings are expected to contribute to the development of more sophisticated robots capable of operating in unpredictable settings, ultimately advancing the field of robotics and its practical applications.
RESEARCH NOTE
Real‐Time Detection of Undesired Human Interventions in Robotic Work Cells Using a Convolutional Neural Network‐Based Novel Architecture and Reliability Analysis With Explainable Artificial Intelligence
A recent study published in the Journal of Field Robotics highlights advancements in autonomous robotic systems designed for agricultural applications. Researchers from various institutions conducted the study to explore how these technologies can enhance efficiency and productivity in farming practices. The findings, released in early October 2023, indicate that the integration of robotics in agriculture not only streamlines operations but also addresses labor shortages faced by the industry. The research was carried out in diverse agricultural settings, showcasing the adaptability of robotic systems to different crops and farming techniques. By employing sensors and artificial intelligence, these robots can perform tasks such as planting, monitoring crop health, and harvesting with precision. The motivation behind this innovation stems from the need to increase food production while minimizing environmental impact and labor costs. As farmers face growing challenges from climate change and a declining workforce, the study emphasizes the potential of robotics to transform traditional farming methods. The researchers advocate for further investment in robotic technologies to ensure sustainable agricultural practices and improve overall food security. This study marks a significant step towards the future of farming, where automation plays a crucial role in meeting the demands of a growing global population.
RESEARCH ARTICLERobotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.






