

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.
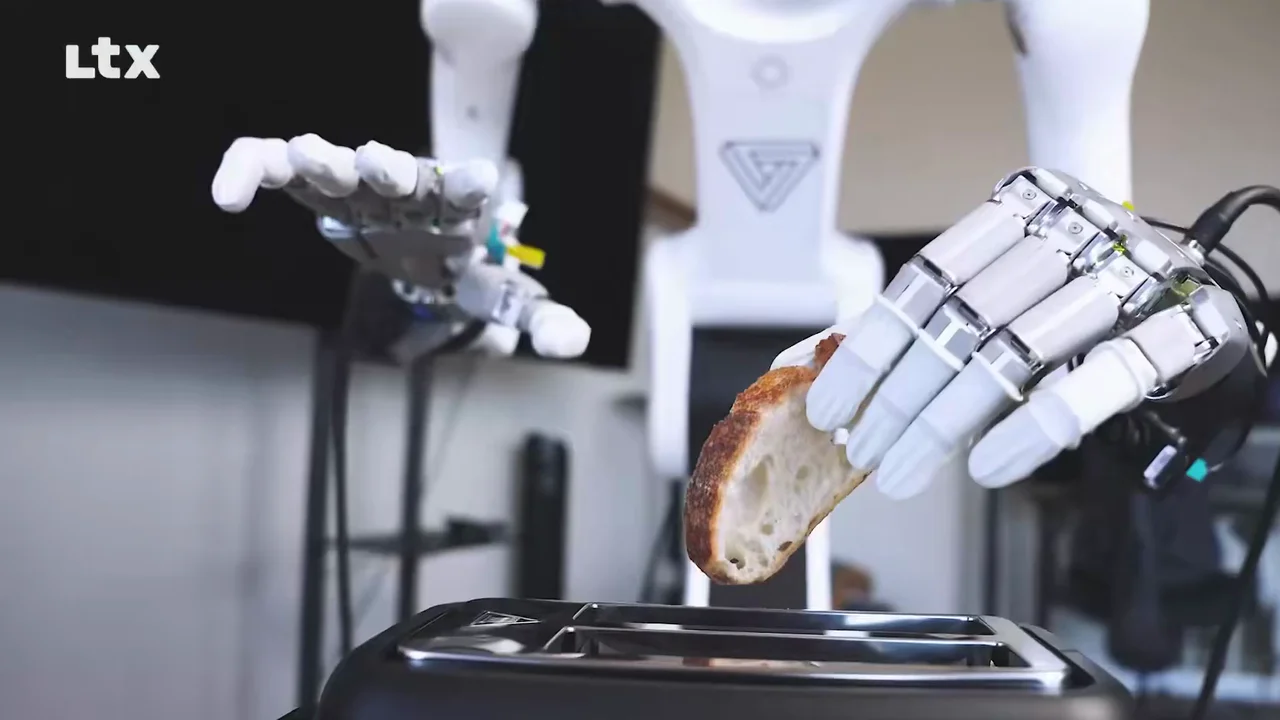
Markov Robotics Innovates Dexterous Manipulation with Video-Based Policy on LTX-2.5
Markov Robotics has introduced a novel approach to dexterous manipulation using a video model as the policy for its LTX-2.5 robot. This method allows the robot to understand object interactions in real-time, enhancing its ability to perform tasks in unfamiliar environments. By leveraging a world model that incorporates physical knowledge, the robot can adapt its grip based on the object's characteristics, such as applying gentle pressure for fragile items like glass and firmer grip for sturdier objects like rocks. This innovation addresses a significant challenge in robotics, where the development of effective software has not kept pace with advancements in hardware. Markov's approach emphasizes the importance of policies in robotic performance, suggesting that the future of dexterous manipulation lies in integrating high-fidelity sensory data with video-based expectations. The company's method of using a head cam to capture scenes and generate action videos represents a shift in how robots can learn and execute tasks. Looking ahead, the robotics community will be watching how Markov's techniques influence the broader field, particularly as more organizations explore world models for robotic applications. The effectiveness of this approach and its potential to streamline the training process for robots could set new standards in the industry. No further timeline was disclosed at the time of publication.
LTX Markov RoboticsRobotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.







