

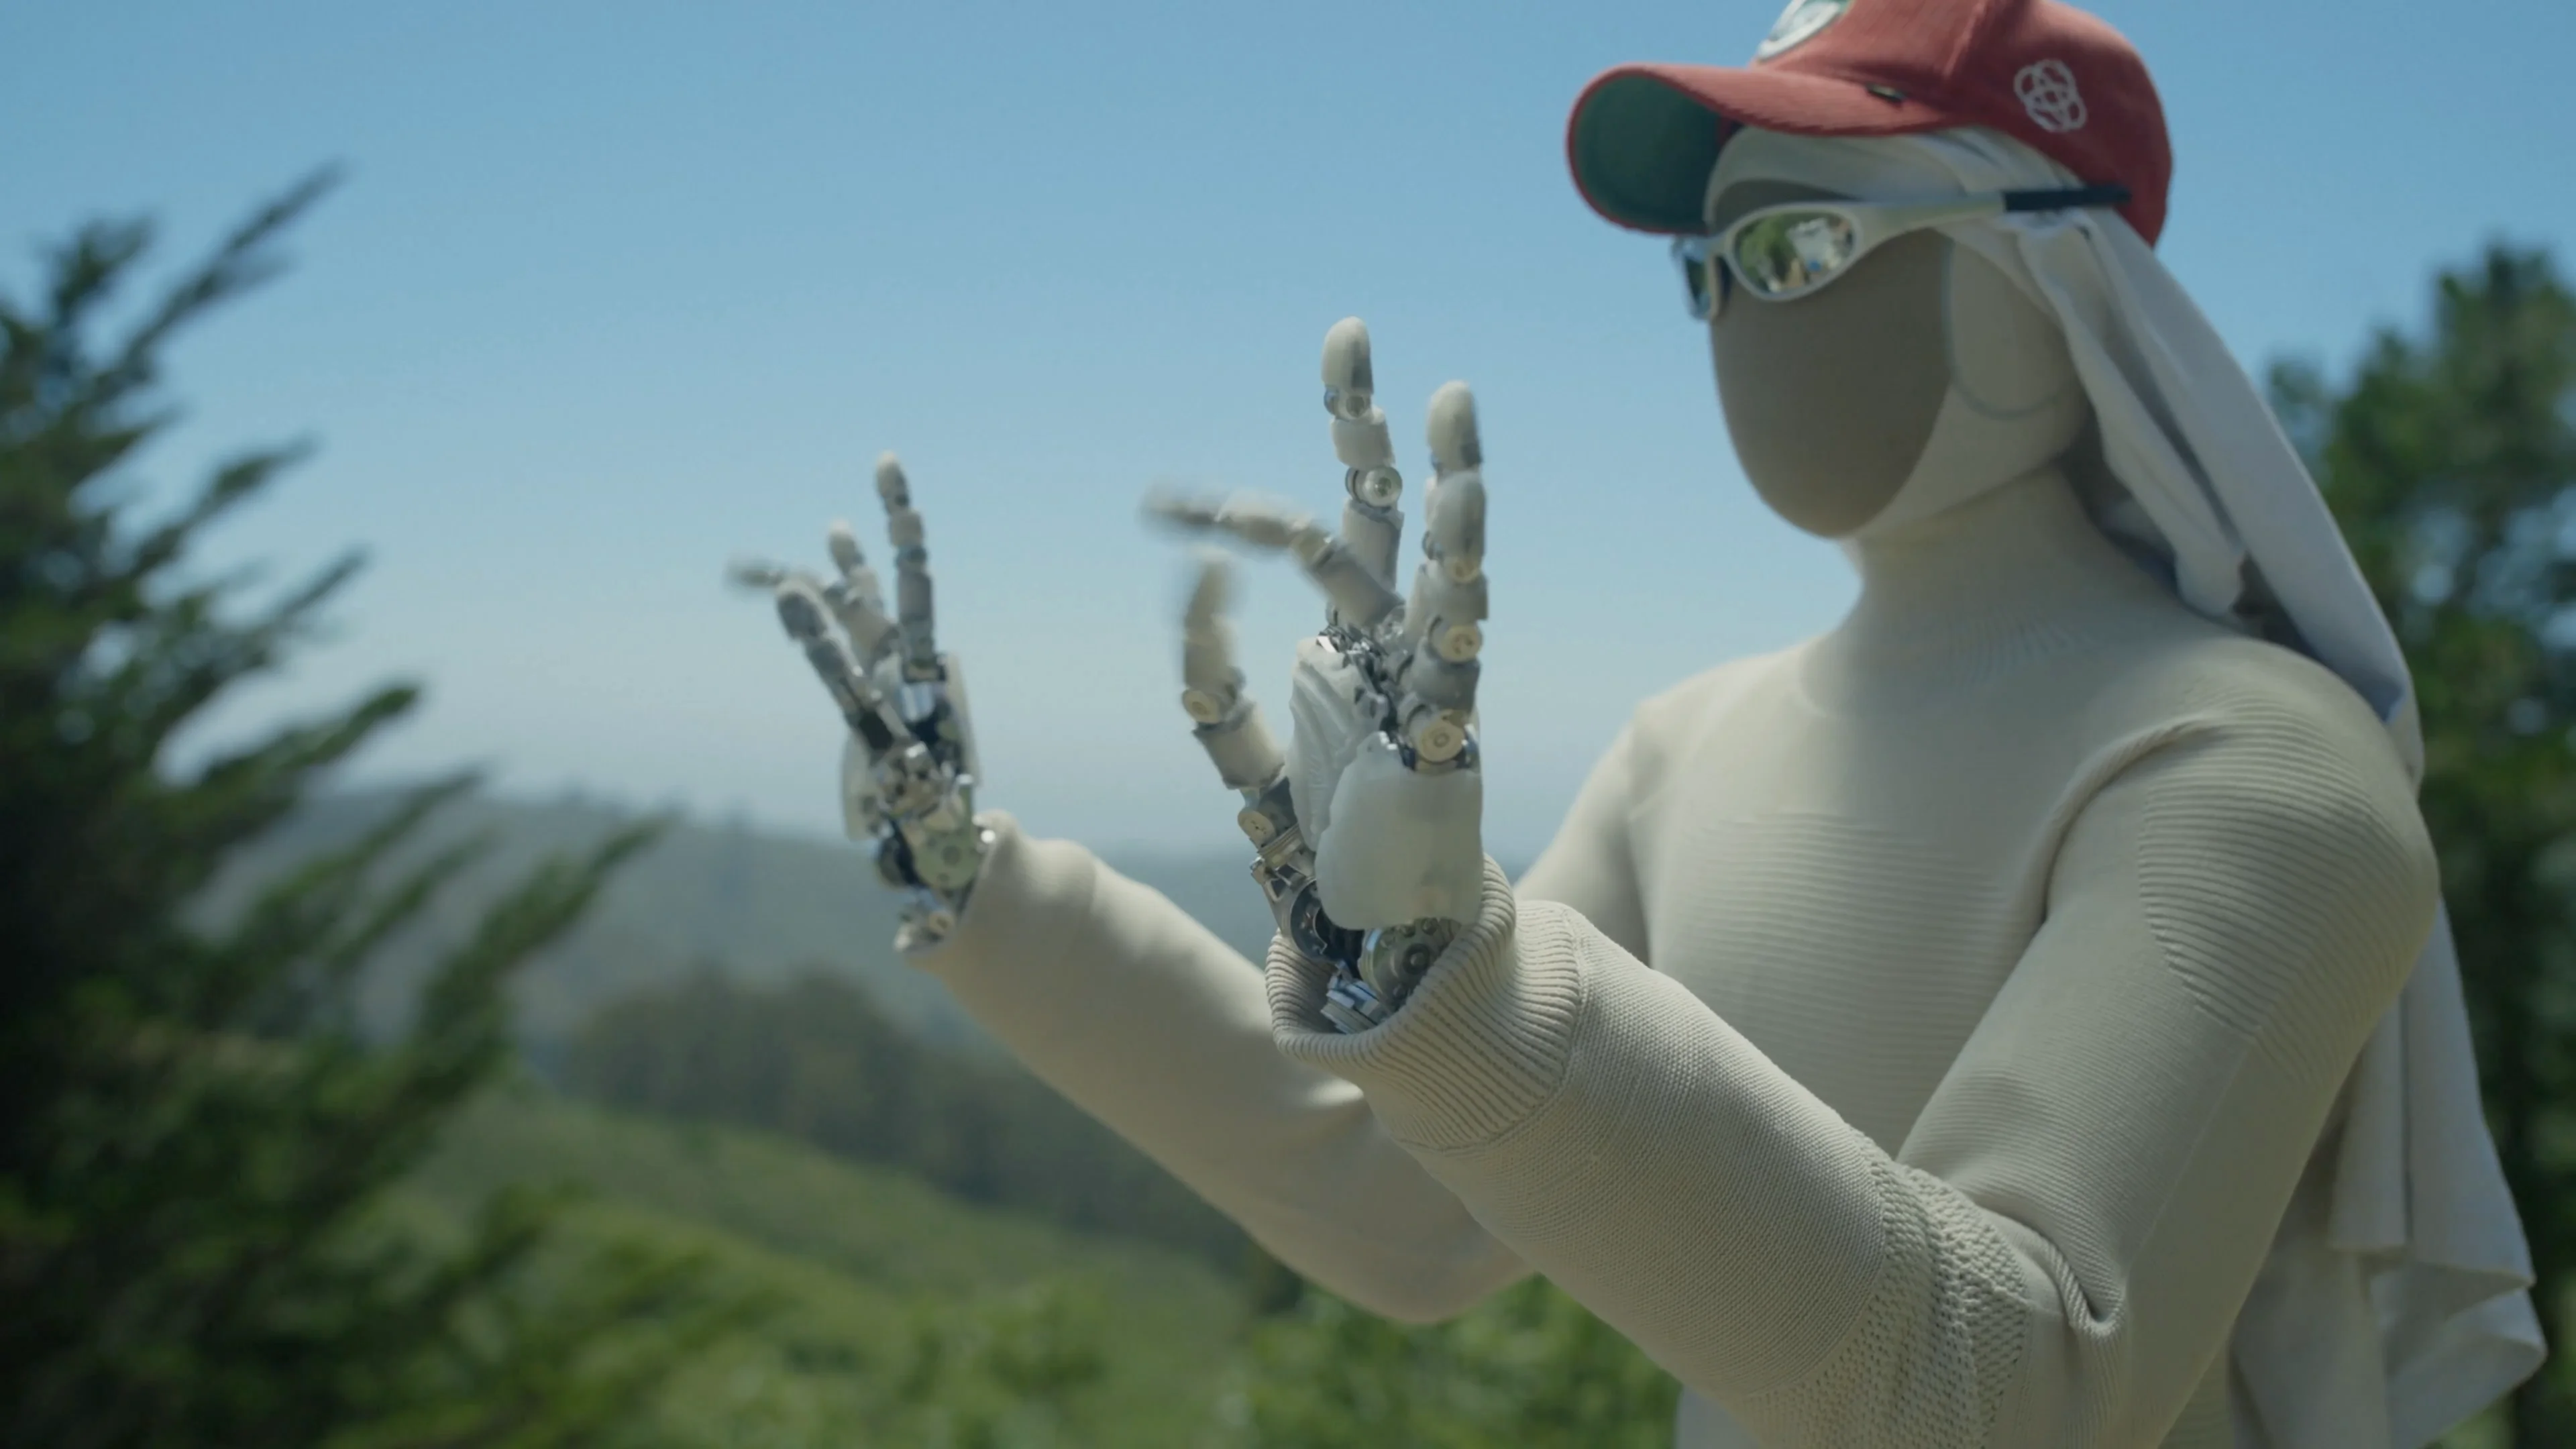
Origami Robotics co-founder Quanting Xie has raised concerns about the industry's dependence on high-ratio gearboxes, which he claims hinder the development of human-level manipulation. In a blog post titled 'The Dexterity Deadlock,' Xie argues that these gearboxes introduce significant failures in the 'sim-to-real' pipeline, necessitating excessive domain randomization in simulations.
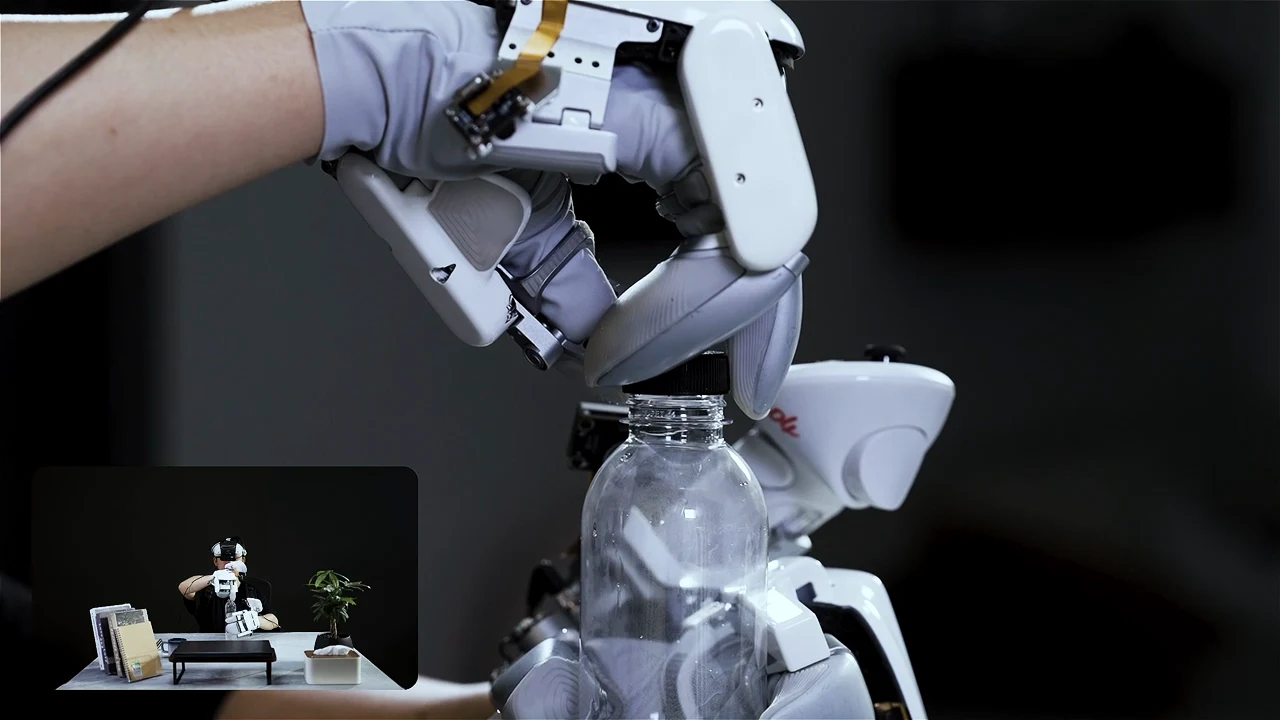
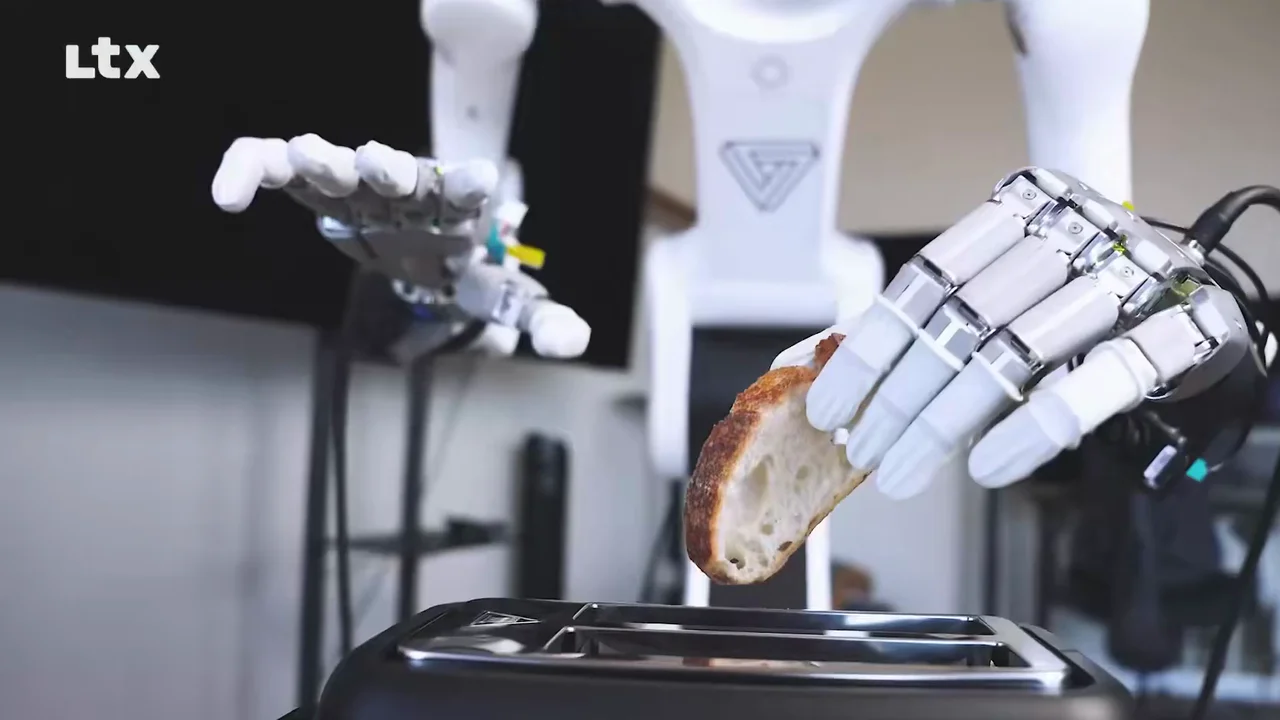
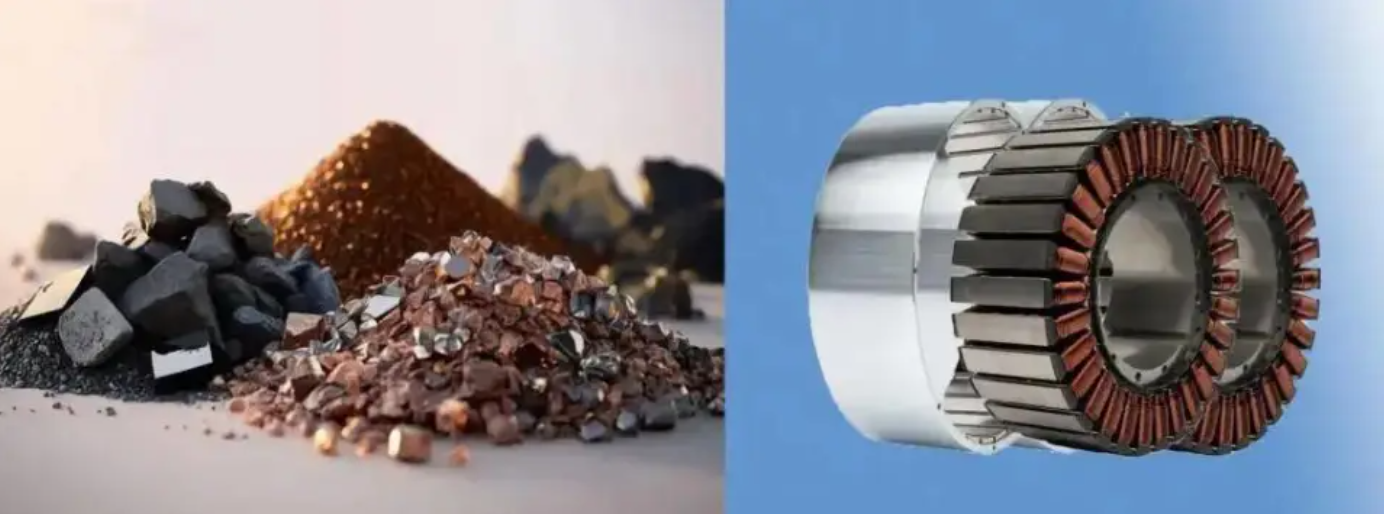
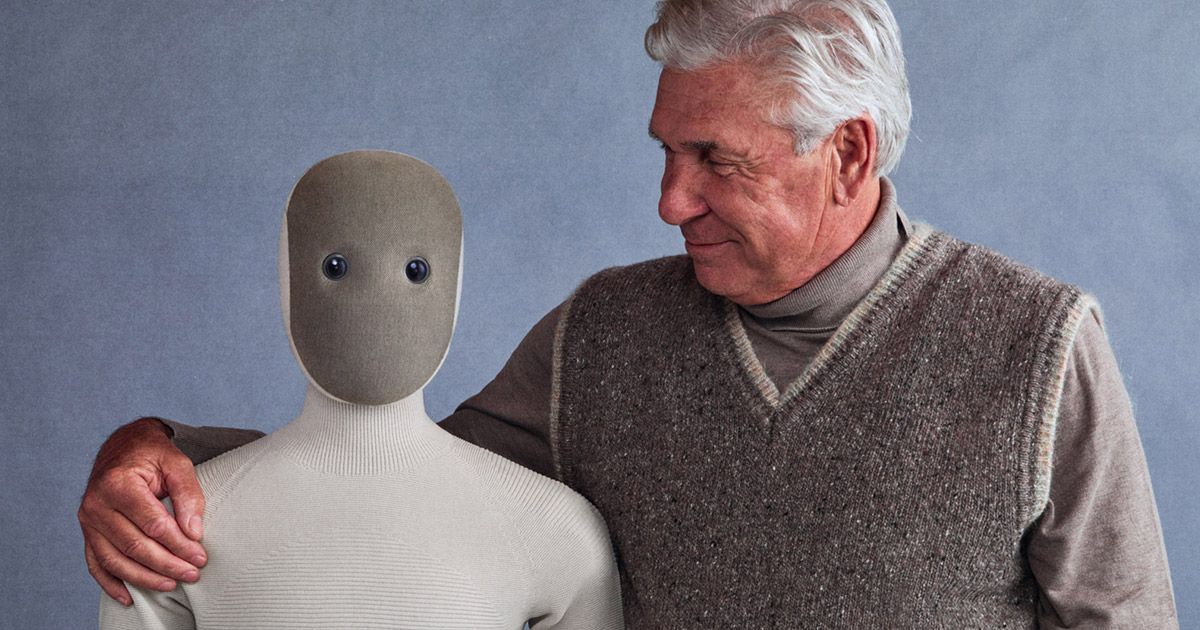
The debate has attracted attention from industry leaders, including 1X Technologies CEO Bernt Børnich, who defends the 'tendon-drive' system used in their upcoming NEO humanoid. Xie proposes an alternative axial flux motor design that reduces gear ratios significantly, enhancing torque generation and enabling a fully backdrivable hand capable of sensing forces through motor current.
As the discussion unfolds, the implications for robotic manipulation technology are profound. The contrasting approaches of Origami and 1X highlight a critical juncture in the field, with potential impacts on future humanoid designs. No further timeline was disclosed at the time of publication.
Editor's Note
The ongoing debate between Origami Robotics and 1X Technologies underscores a pivotal moment in robotic manipulation technology. As companies explore different mechanical architectures, the outcomes could reshape industry standards and influence future humanoid robot designs. Stakeholders should monitor these developments closely, as they may signal shifts in technology adoption and competitive strategies.















Leave a comment