

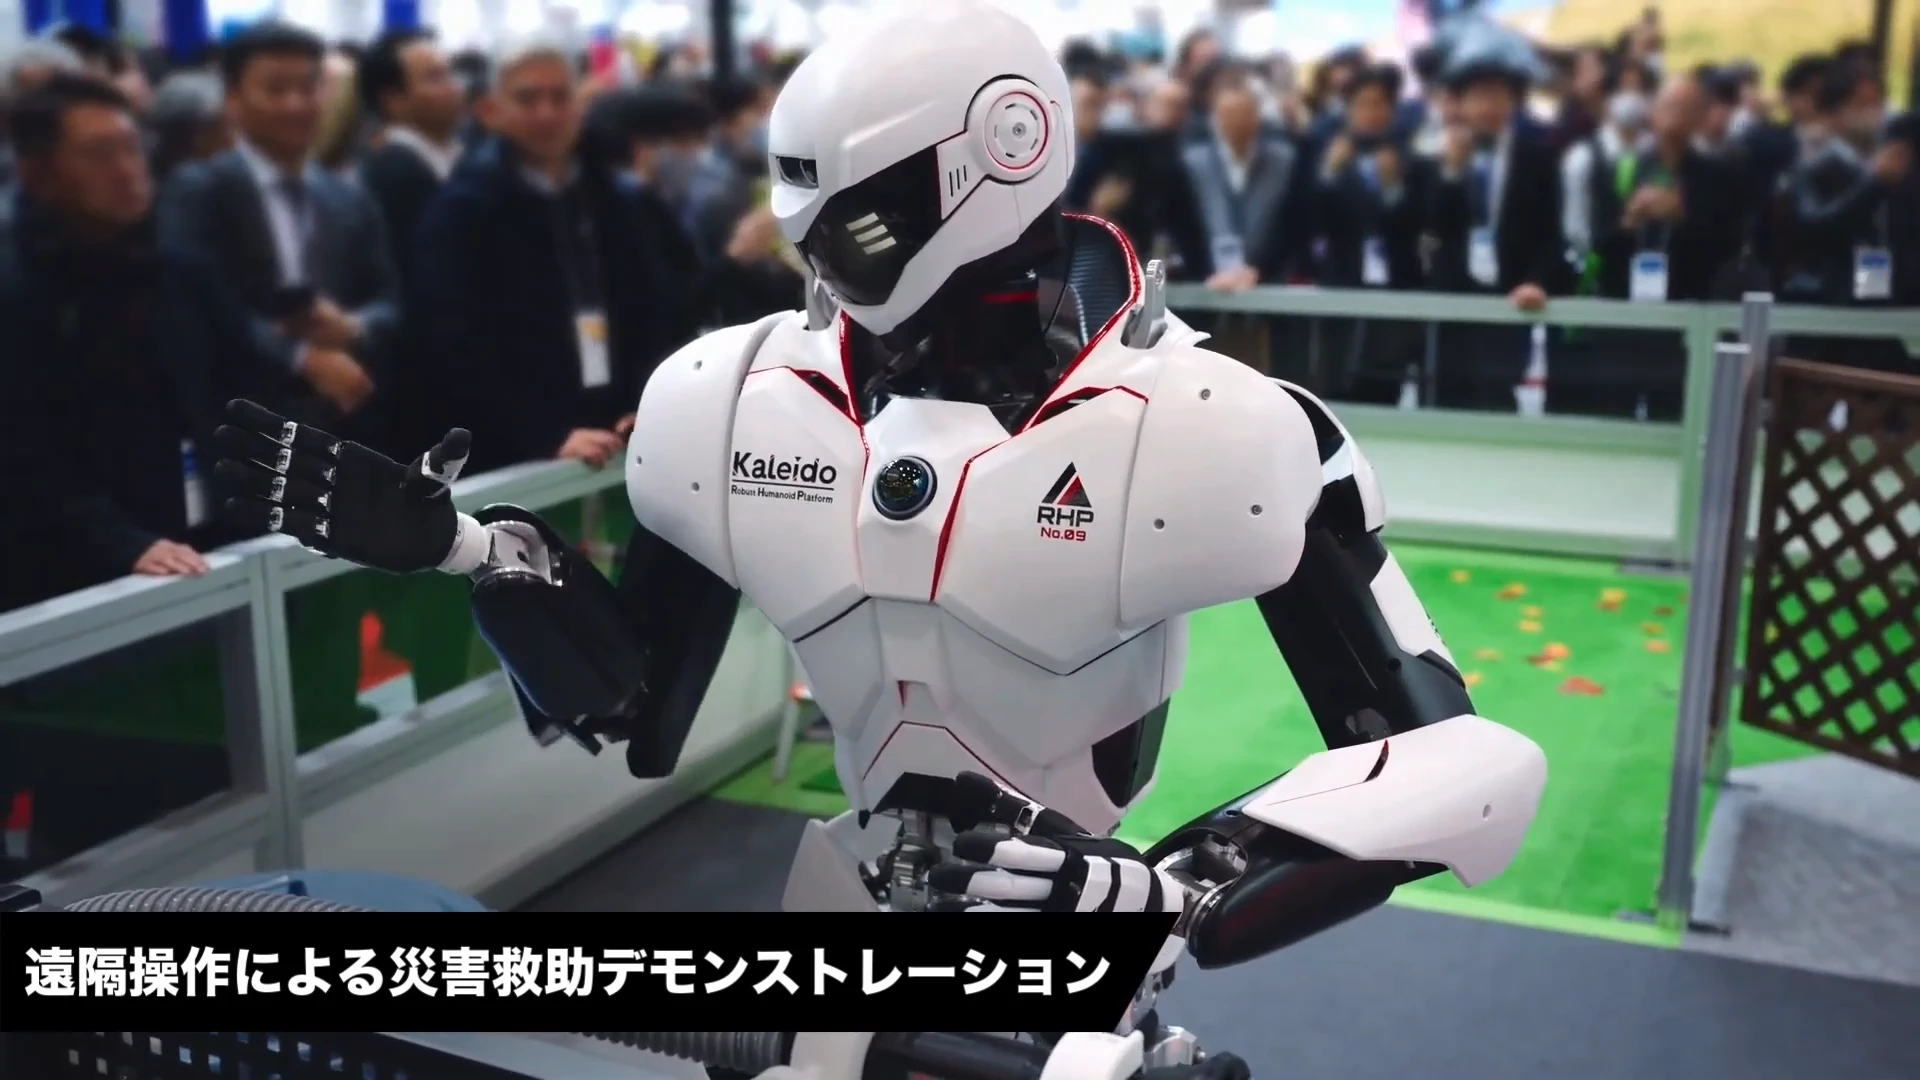
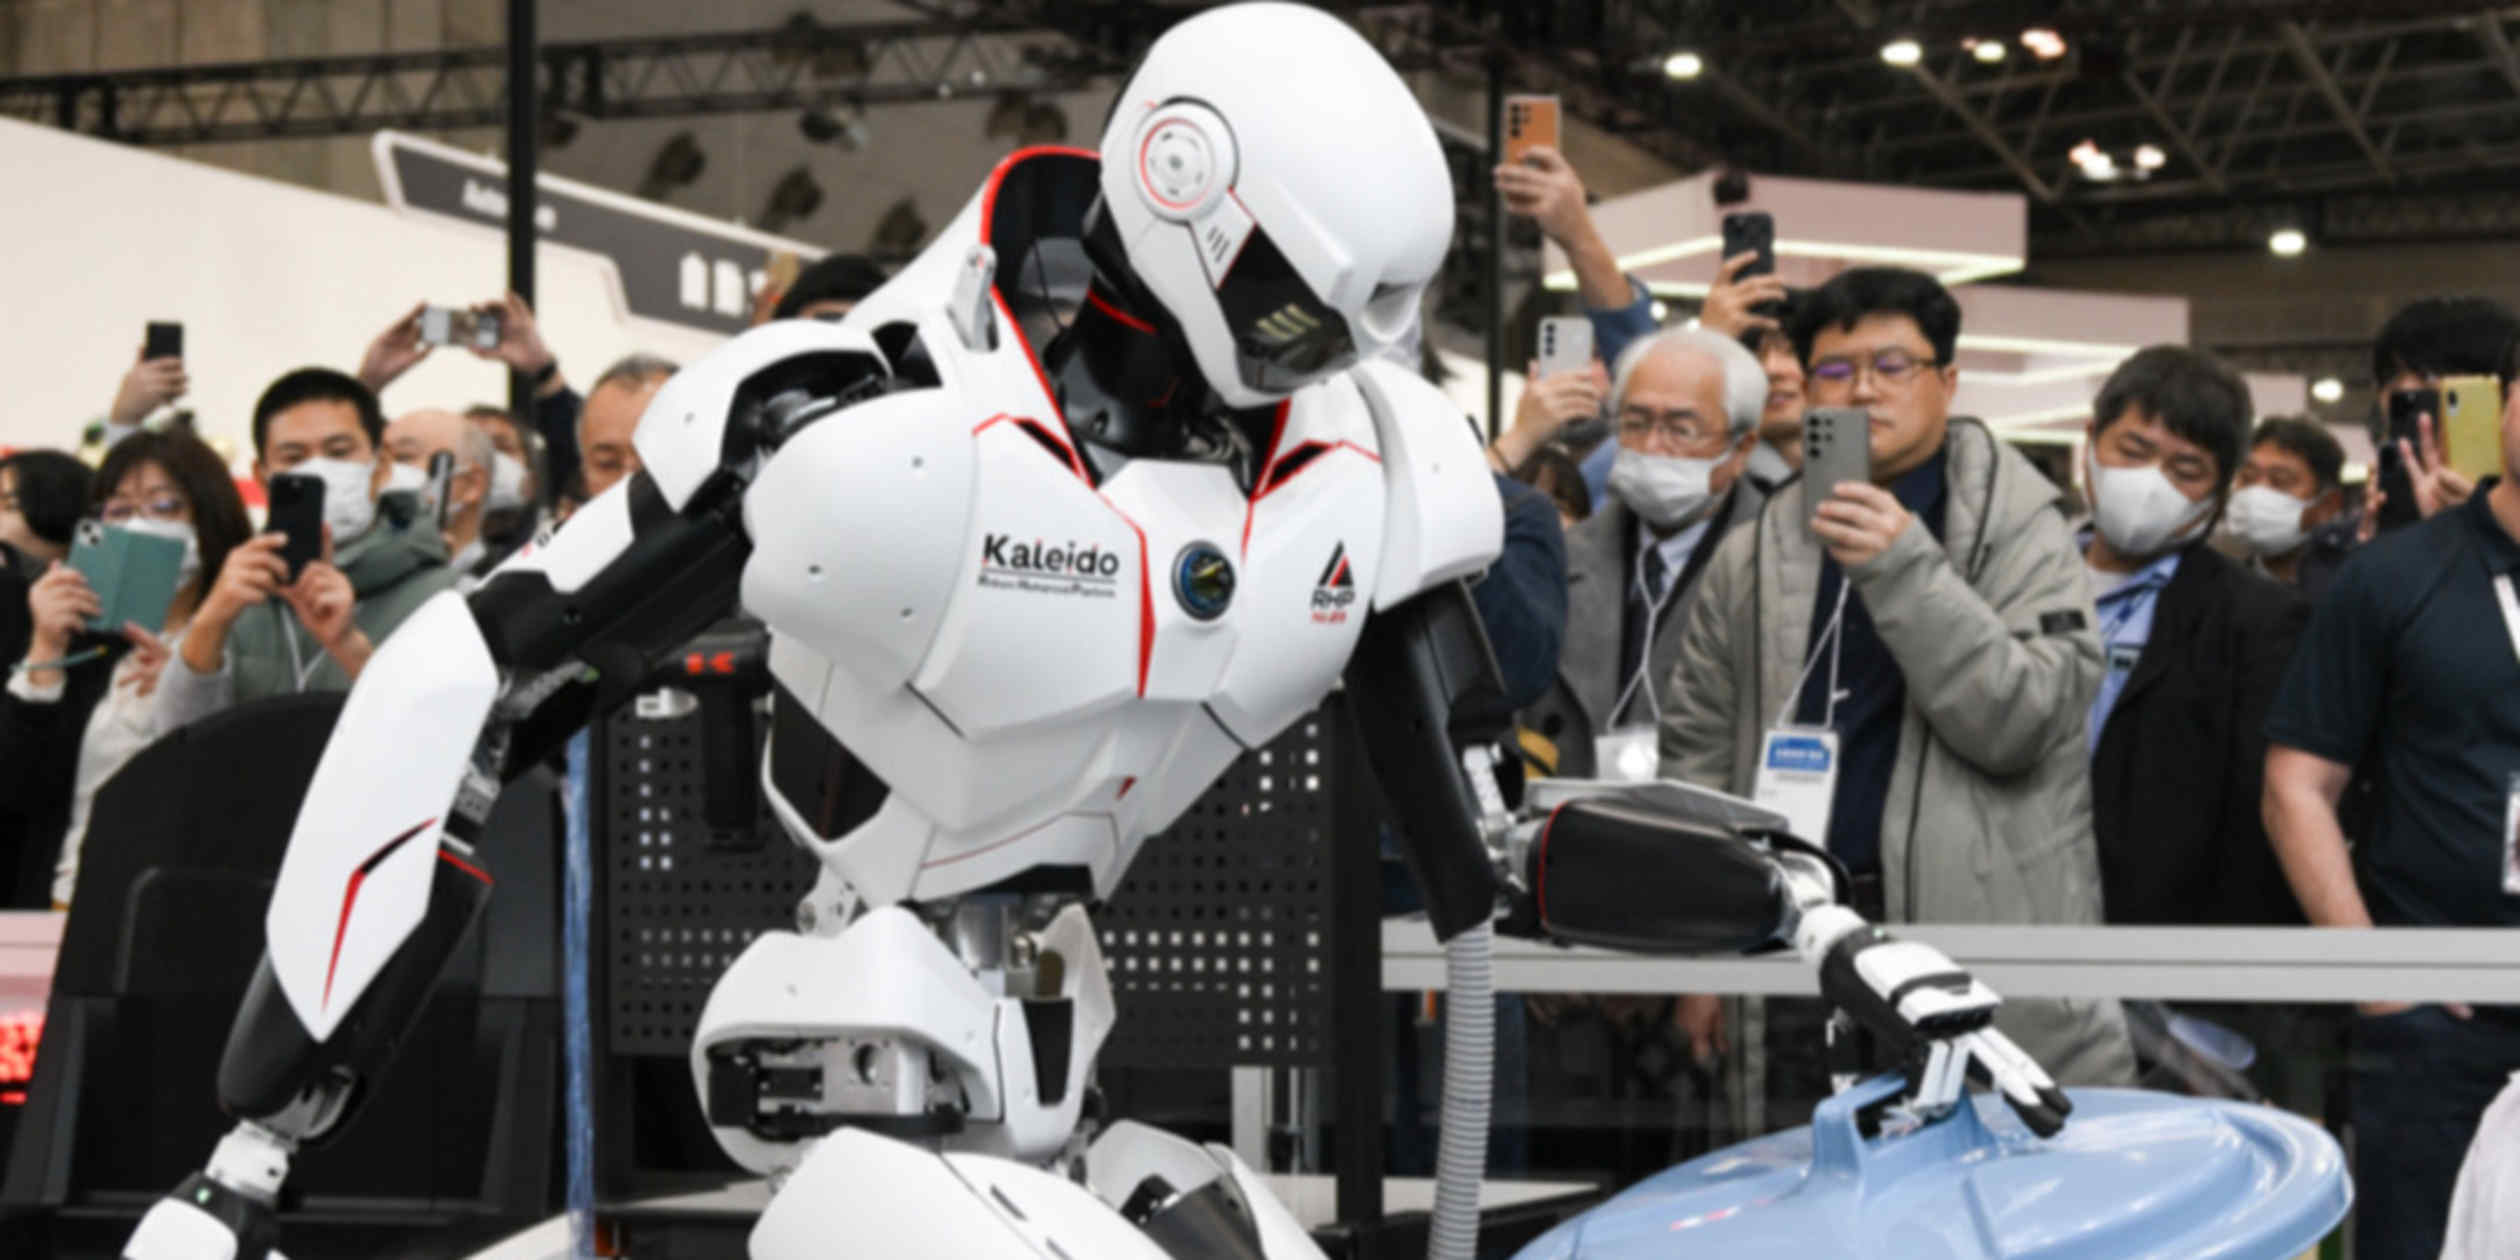
Kawasaki Heavy Industries plans to integrate Noetra’s Japanese physical AI platform into its Kaleido humanoid, aiming for a rollout as early as 2030. Kaleido will be the first to utilize Noetra’s technology, which will initially operate through a combination of remote human control and AI, gradually increasing its autonomous capabilities as Noetra’s platform evolves.
The significance of this development lies in the phased approach to autonomy, with initial tasks focused on simpler operations such as patrolling and moving parts. While the goal is full autonomy, the rollout will begin with a hybrid model. Kawasaki’s roadmap indicates that remote-assisted work is expected around 2030, with full autonomous operation targeted for 2040, although the Noetra report does not confirm that all tasks will be autonomous at launch.
Looking ahead, Kawasaki's collaboration with Noetra and NVIDIA aims to enhance the complexity and precision of autonomous movements. The company envisions deploying tens of thousands of robots across various applications by 2040, indicating a broader ambition beyond just humanoids, which will be crucial to watch in the coming years.
Editor's Note
Kawasaki's integration of Noetra's AI technology into the Kaleido humanoid reflects a strategic move to enhance automation capabilities within Japan's manufacturing sector. This partnership signifies a growing trend of combining physical AI with robotics to improve operational efficiency and adaptability in various environments. The phased approach to autonomy may influence how enterprises adopt and implement robotic solutions in the future.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.










Leave a comment