

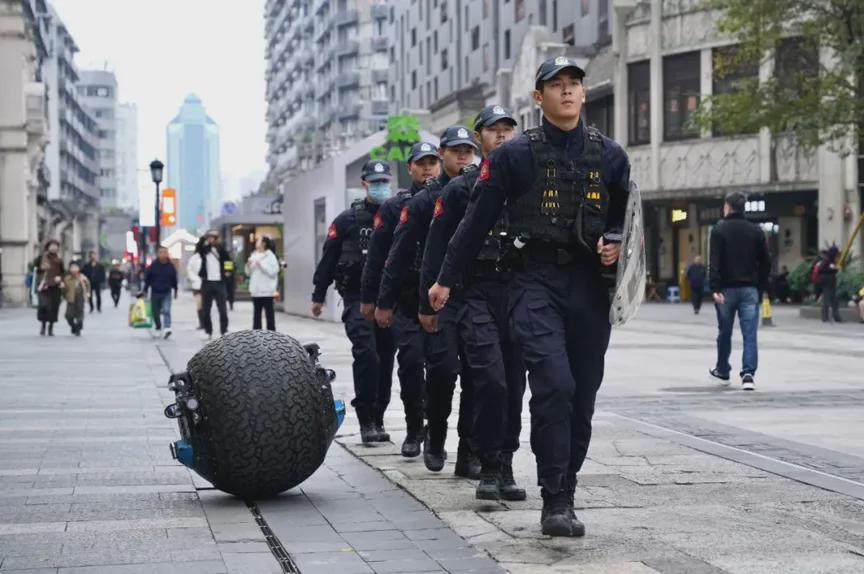
An amphibious ball robot, measuring approximately 80 cm in diameter and weighing around 190 kg, captivated attendees at the China International Defense Electronics Exhibition. This unique robot, which lacks legs or tracks, utilizes an internal motor and pendulum system to roll on land at speeds up to 35 km/h and navigate water with an added propeller.
The significance of this design lies in its departure from traditional robotic forms, as highlighted in PwC's report on the future of intelligent robotics. By 2030, a diverse coexistence of robotic forms is expected, with this ball robot exemplifying a new approach to mobility that combines simplicity and efficiency.
Looking ahead, researchers are exploring multi-modal propulsion systems that integrate pendulum and propeller mechanisms for optimized performance in transitional environments. The Duke University-developed MARBLE robot further exemplifies this trend by eliminating external moving parts, relying instead on internal mechanisms for movement in both land and water, marking a significant technological advancement in amphibious robotics.
Editor's Note
The emergence of amphibious robots like the ball robot reflects a shift in robotics towards more versatile and efficient designs. As industries increasingly seek adaptable solutions for diverse environments, the integration of innovative propulsion systems will likely play a crucial role in future robotic applications, enhancing operational capabilities across various sectors.













Leave a comment