

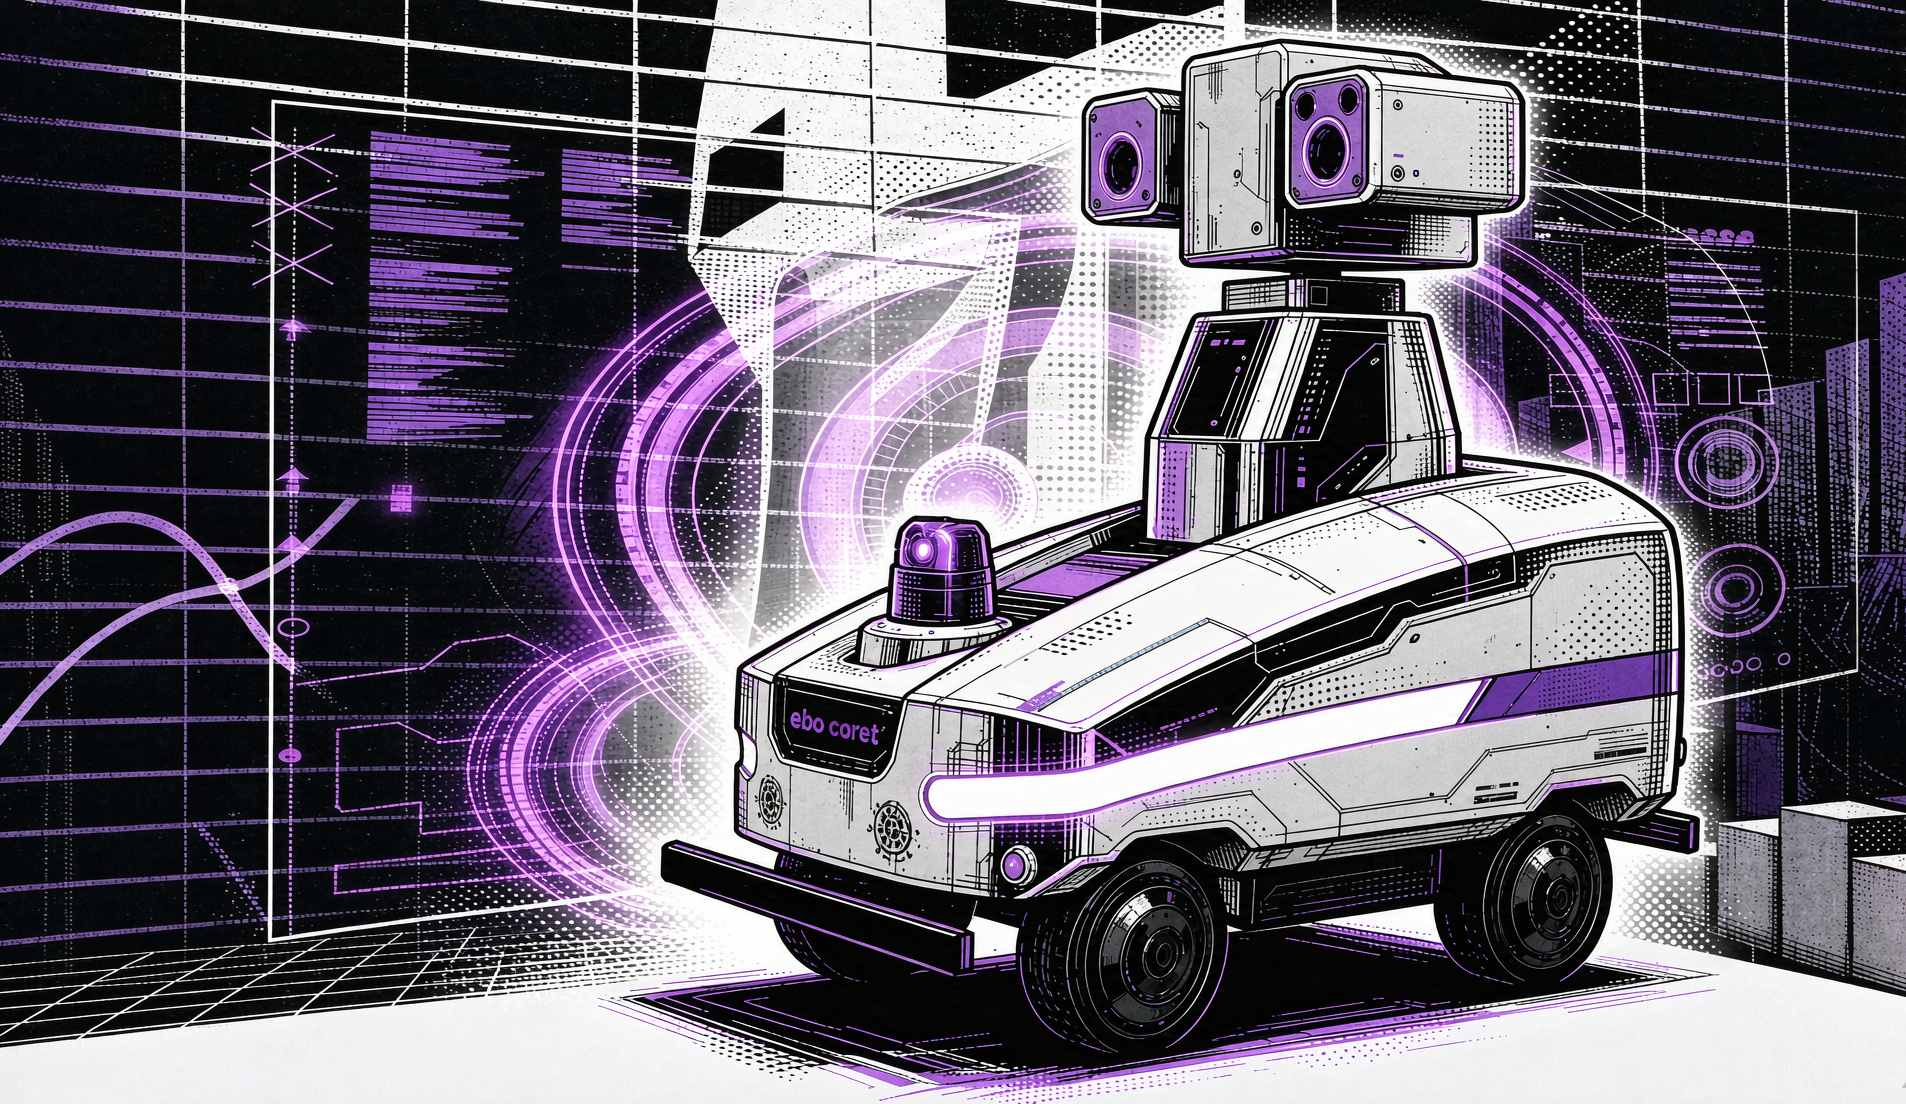
A team led by Cheng Ziyang has developed a forestry inspection robot designed to address the limitations of traditional fire detection methods. The robot integrates LiDAR and thermal imaging technologies, enabling it to operate effectively in low visibility conditions such as nighttime and smoke. This innovation aims to enhance the efficiency of forest fire monitoring by autonomously navigating complex terrains and detecting temperature anomalies that are often precursors to fires.
The significance of this development lies in its potential to improve forest fire prevention efforts. Traditional methods, including fixed sensors and manual patrols, have proven inadequate due to high costs, low efficiency, and limited coverage. The new robot has demonstrated a 27% increase in inspection coverage and significantly improved accuracy in identifying fire sources, thereby reducing the need for human intervention in hazardous areas.
Looking ahead, the team plans to further optimize the robot's performance and push for its industrialization. The challenges of cost, reliability, and mass delivery remain, but overcoming these hurdles could lead to a substantial enhancement in the intelligence of forest fire protection systems, ultimately reducing risks and improving response times in emergency situations.
Editor's Note
The development of intelligent forestry inspection robots represents a significant advancement in fire prevention technology. As traditional methods struggle with coverage and efficiency, this innovation could reshape how forest areas are monitored and protected. The integration of advanced sensors and autonomous capabilities addresses critical challenges in forestry management, particularly in remote and complex environments.












Leave a comment