

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.

Federal Lawsuit Filed by Michigan Journalist Challenges Drone Flight Restrictions Near Police Operations
A federal lawsuit has been filed by Michigan photojournalist Ray Rocha against Bay County Sheriff Troy Cunningham and Deputy Chris Berg, challenging restrictions on drone flights near police operations. The suit, initiated on August 9, 2024, stems from an incident in November 2024 where Rocha was operating his drone during a police search. Despite following federal regulations, Rocha was charged with a misdemeanor for allegedly interfering with police duties. The lawsuit argues that the state’s drone law, as enforced by local authorities, violates Rocha’s First Amendment rights to gather information on newsworthy events. It also claims the law is unconstitutionally vague under the 14th Amendment, lacking clear guidelines and allowing arbitrary enforcement by officers. Rocha seeks to prevent future charges unless his drone operations materially disrupt law enforcement activities. The outcome of this case could have significant implications for drone operation regulations in Michigan. Attorney Philip Ellison noted that if the court finds the law unconstitutional, it may prompt legislative changes. As Rocha is known for using drone footage to report on local law enforcement, the case highlights the ongoing tension between public information gathering and law enforcement operations.
Applications DL Exclusive Drone News Drone News Feeds Journalism Legal
Michigan Allocates $2 Million for Five Advanced Air Mobility Initiatives
Michigan has awarded $2 million to five companies for advanced air mobility projects aimed at addressing real-world challenges faced by state agencies. Announced on August 11 by the Michigan Department of Labor and Economic Opportunity’s Office of Future Mobility and Electrification, these projects will utilize the Michigan Mobility Funding Platform’s AAM Statewide Mobility Challenges. The selected projects will involve partnerships between technology firms and various Michigan state departments, focusing on areas such as environmental monitoring, wildfire response, and drone detection. Michigan Chief Mobility Officer Justine Johnson emphasized the importance of integrating new technologies into everyday operations to accelerate innovation and improve public services. Among the projects, Kohtari will collaborate with the Michigan Department of Environment, Great Lakes, and Energy for air and water quality monitoring, while Orb Aerospace will assist the Michigan Department of Natural Resources with wildfire monitoring. Westwood AI will partner with the Michigan Department of Transportation to enhance roadway assessments, and Motorola Solutions will work with Michigan State Police on drone detection technology. No further timeline was disclosed at the time of publication.
Advanced Air Mobility Drone News Drone News Feeds Drones in the News Dual Use News
Hyperscale Data Initiates Installation of OPR-R2 Robots at Michigan AI Facility
Hyperscale Data, Inc. has commenced the installation of OPR-R2 robots at its Michigan AI data center. This marks a significant step in the company's efforts to enhance its visual data collection and physical AI training capabilities. The installation of 143 OPR-R2 robots is crucial for Hyperscale Data as it aims to bolster its artificial intelligence initiatives. The first unit was assembled on July 16, 2026, indicating the start of a comprehensive program designed to improve AI training processes. Looking ahead, the deployment of these robots will be pivotal in advancing Hyperscale Data's operational efficiency and data processing capabilities. No further timeline was disclosed at the time of publication.

Common Vector Robotics Secures $425,000 in Michigan's PitchMI Startup Competition
Common Vector Robotics, a manufacturer based in Detroit, has secured $425,000 in funding after winning the defense and aerospace semifinal of Michigan University's PitchMI Startup Competition. The funding includes $375,000 from the main competition and an additional $50,000 from 20Fathoms. This funding is significant for Common Vector Robotics, as it aims to enhance its development of ground-based robotic systems for both civilian and defense applications. The company focuses on in-house manufacturing of critical components, which supports its innovative platforms like Ghostrunner and the GL-1, designed for rugged environments and autonomous operations. Looking ahead, Common Vector Robotics plans to leverage this funding to scale its operations and further develop its robotic technologies. No further timeline was disclosed at the time of publication.
Business News Robotics 20fathoms autonomous mobile robots Autonomous robots
UCLA and University of Michigan Create 11-Centimeter Jumping Robot Using Elastic Rods
Researchers from UCLA and the University of Michigan have developed a small robot measuring 11 centimeters that utilizes twisted elastic rods to jump. This innovative design allows the robot to store energy through the twisting of the rods and release it suddenly, propelling the robot forward. Weighing 98.2 grams, the robot achieves an average speed of 2.46 body lengths per second across various surfaces, with a peak speed of 3.21 body lengths per second on wood. The significance of this development lies in its potential applications in challenging terrains. Unlike traditional jumping robots that rely on rigid legs and complex mechanisms, this elastic rod design offers greater adaptability to soft or uneven surfaces. The research indicates that the shape of the elastic rods, rather than their size, determines whether they deform slowly or jump suddenly, suggesting scalability to millimeter-sized robots. This could revolutionize small robot mobility in scenarios such as disaster response and environmental monitoring. Looking ahead, the research team believes that this design approach could lead to the creation of small robots capable of navigating complex terrains effectively. No further timeline was disclosed at the time of publication.
Soft Robotics Jumping Robots Elastic Actuators Robotics Research
UCLA and Michigan Researchers Develop Frog-like Robot Using Elastic Rods for Versatile Movement
Researchers at the UCLA Samueli School of Engineering and the University of Michigan have demonstrated that elastic rods can be utilized in robotic designs to enhance mobility. These rods can bend and twist, allowing robots to snap between different shapes, which releases stored energy for dynamic movements such as hopping, flipping, and swimming. This innovation is significant as it enables small robots to traverse various terrains more effectively than traditional rigid-legged designs. The ability to harness elastic energy not only improves agility but also expands the potential applications of these robots in diverse environments, making them more versatile in real-world scenarios. Looking ahead, the implications of this research could lead to advancements in soft robotics and bio-inspired designs. As the technology matures, further developments may focus on optimizing the performance of these elastic systems in practical applications. No further timeline was disclosed at the time of publication.
Robotics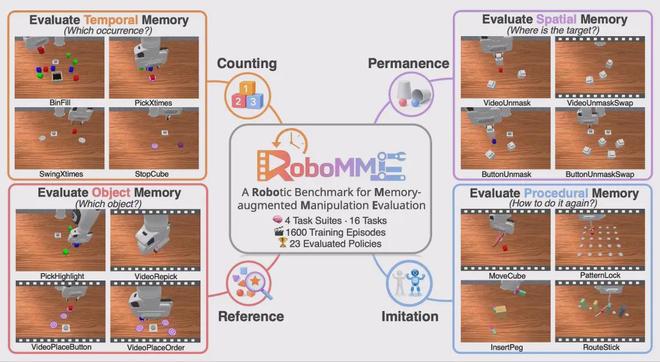
Michigan, Stanford, and Figure AI Collaborate to Launch the Groundbreaking RoboMME Robot Memory Benchmark!
A new standardized evaluation system for robot memory, known as the RoboMME benchmark, has been introduced by a collaborative effort involving Michigan University, Stanford University, and Figure AI. This innovative framework assesses robot memory across four key dimensions: temporal, spatial, object, and procedural. By addressing previous shortcomings in assessment methods, the RoboMME benchmark aims to improve robot performance in executing complex tasks. The initiative reflects ongoing advancements in robotics and artificial intelligence, highlighting the importance of effective memory evaluation in enhancing robotic capabilities.
Robot Memory Benchmarking Artificial Intelligence Robotics Machine Learning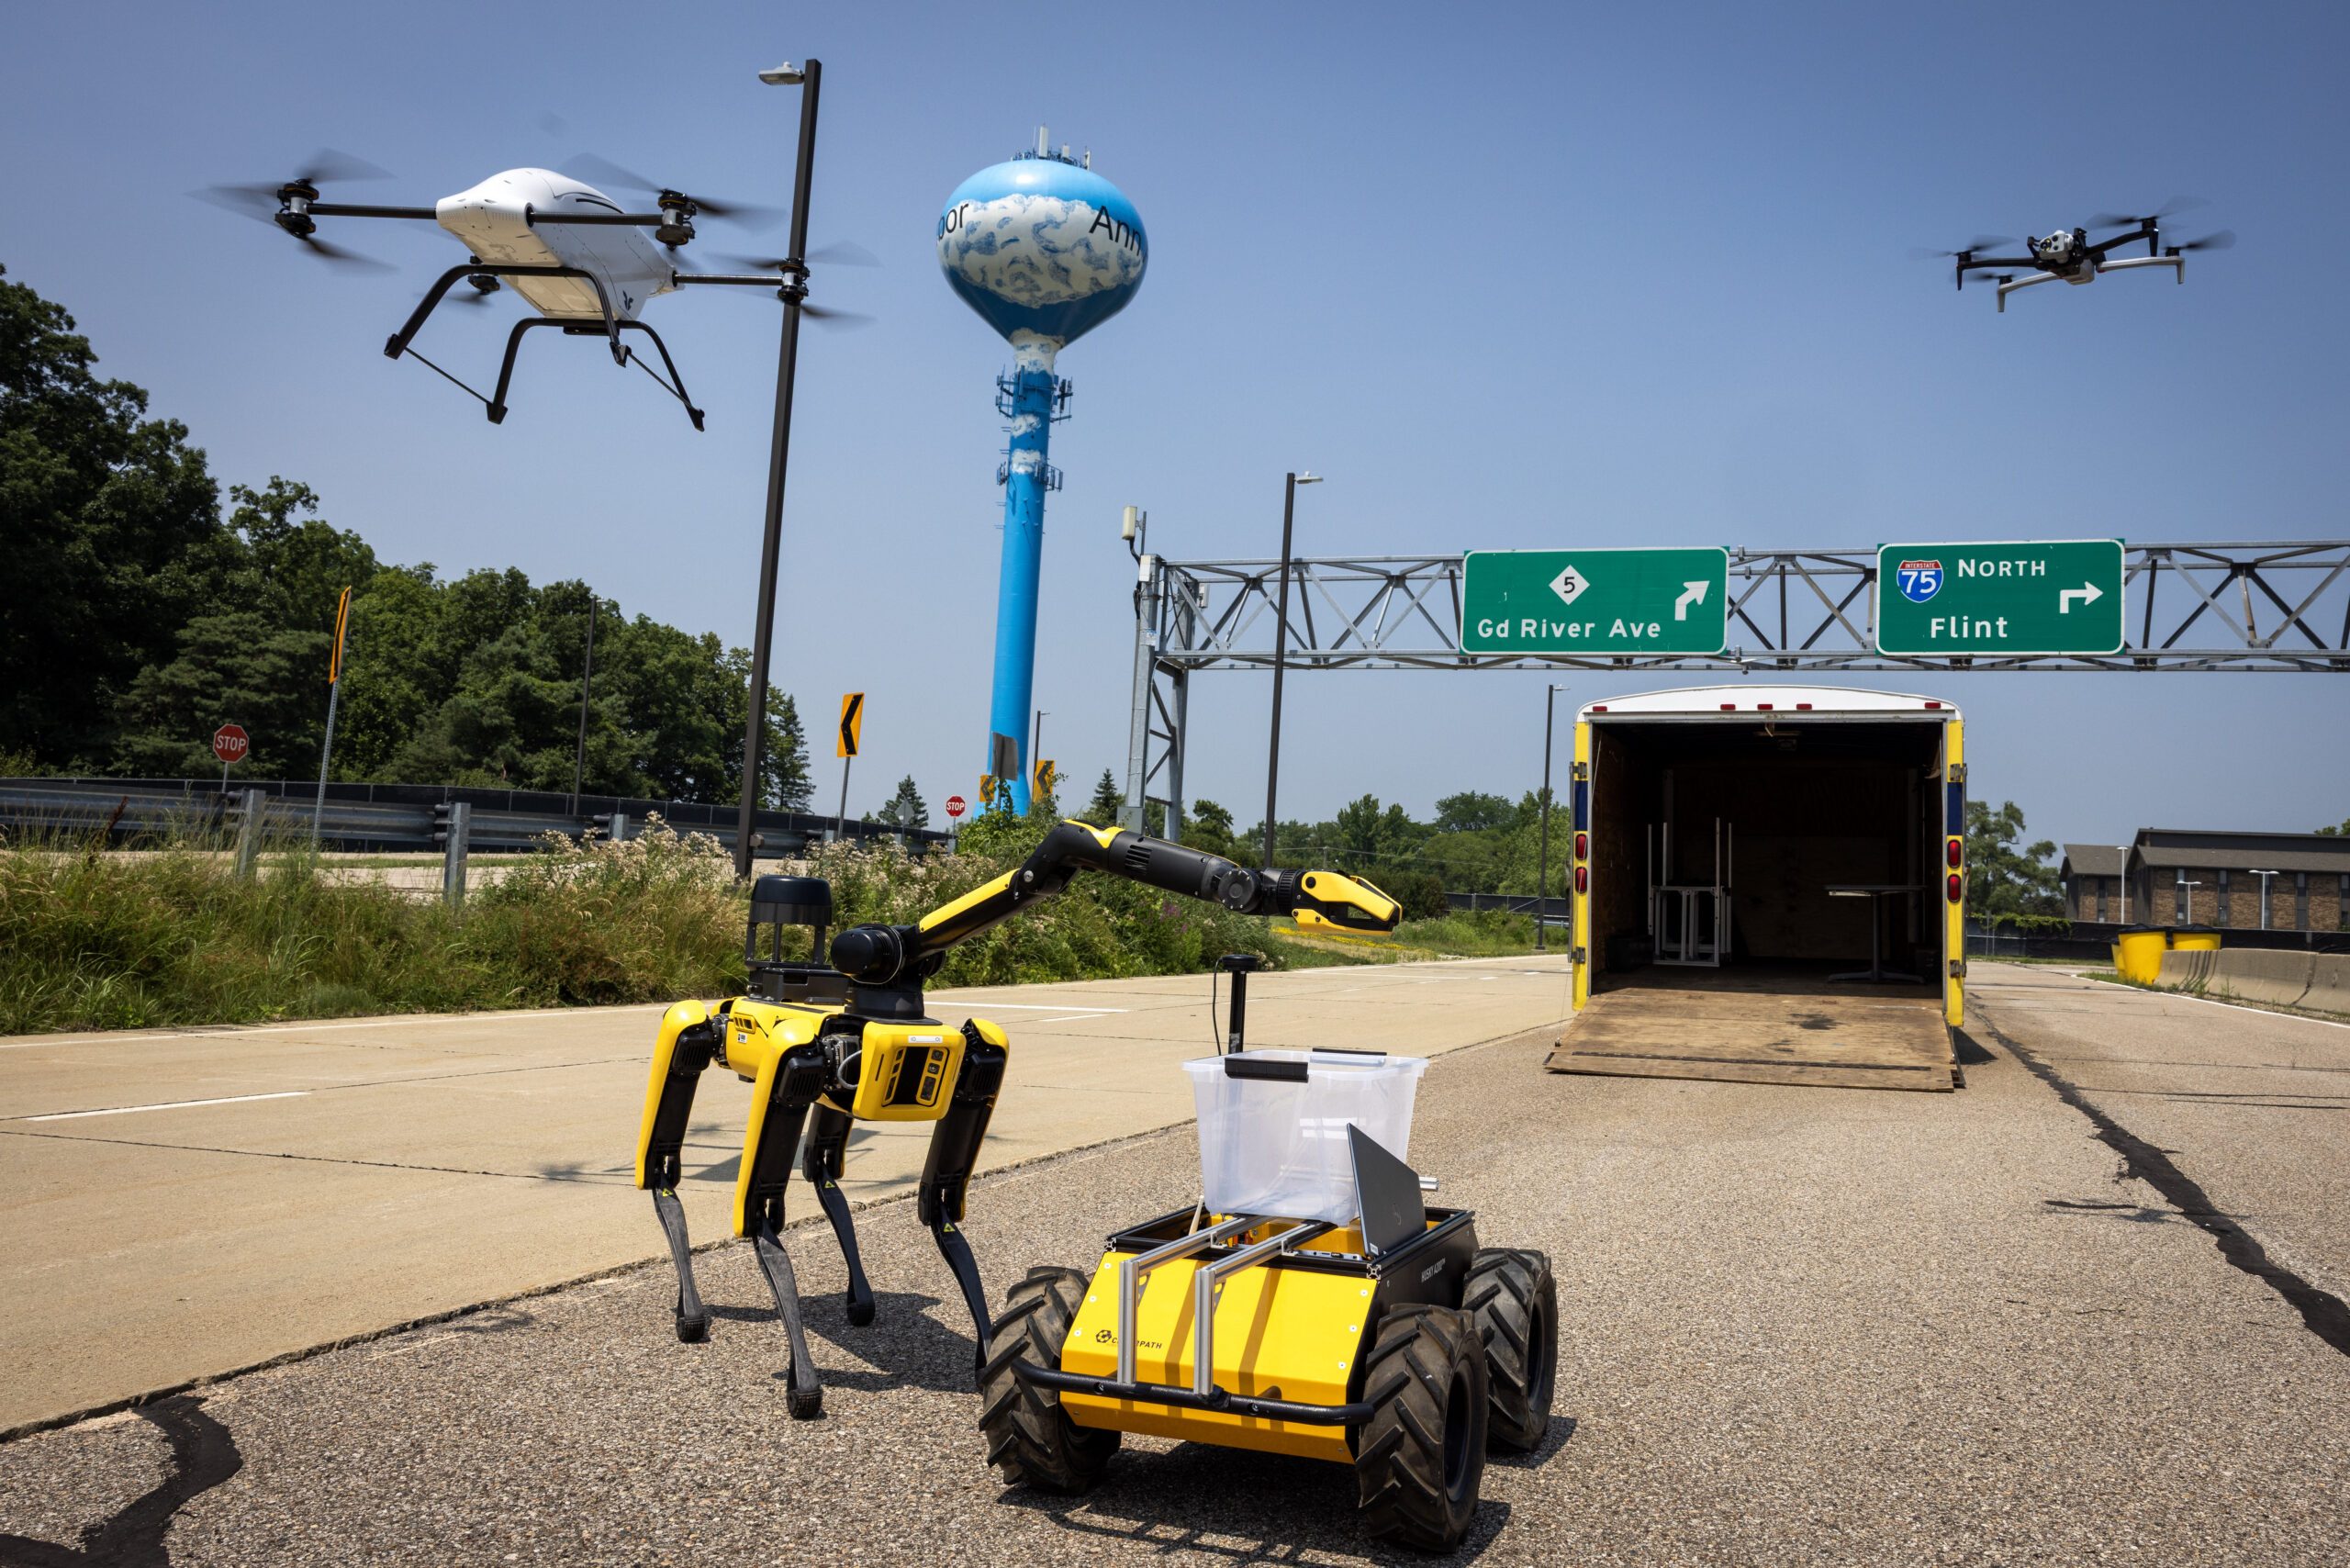
Michigan’s Bet on the Low Altitude Economy: How M Air Connects Aerospace Innovation and Detroit Manufacturing
At XPONENTIAL 2026, leaders from the University of Michigan presented a forward-looking vision aimed at establishing the state as a key player in the low altitude economy, particularly in the realms of drones and advanced air mobility (AAM). This initiative seeks to leverage Michigan's aerospace innovations alongside Detroit's robust industrial manufacturing capabilities. The discussion highlighted the potential for Michigan to become a central hub for these emerging technologies, emphasizing the synergy between cutting-edge aerospace developments and the region's manufacturing expertise.
Advanced Air Mobility Aerospace Applications Autonomous DL Exclusive Drone ManufacturingRobotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.







