

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.
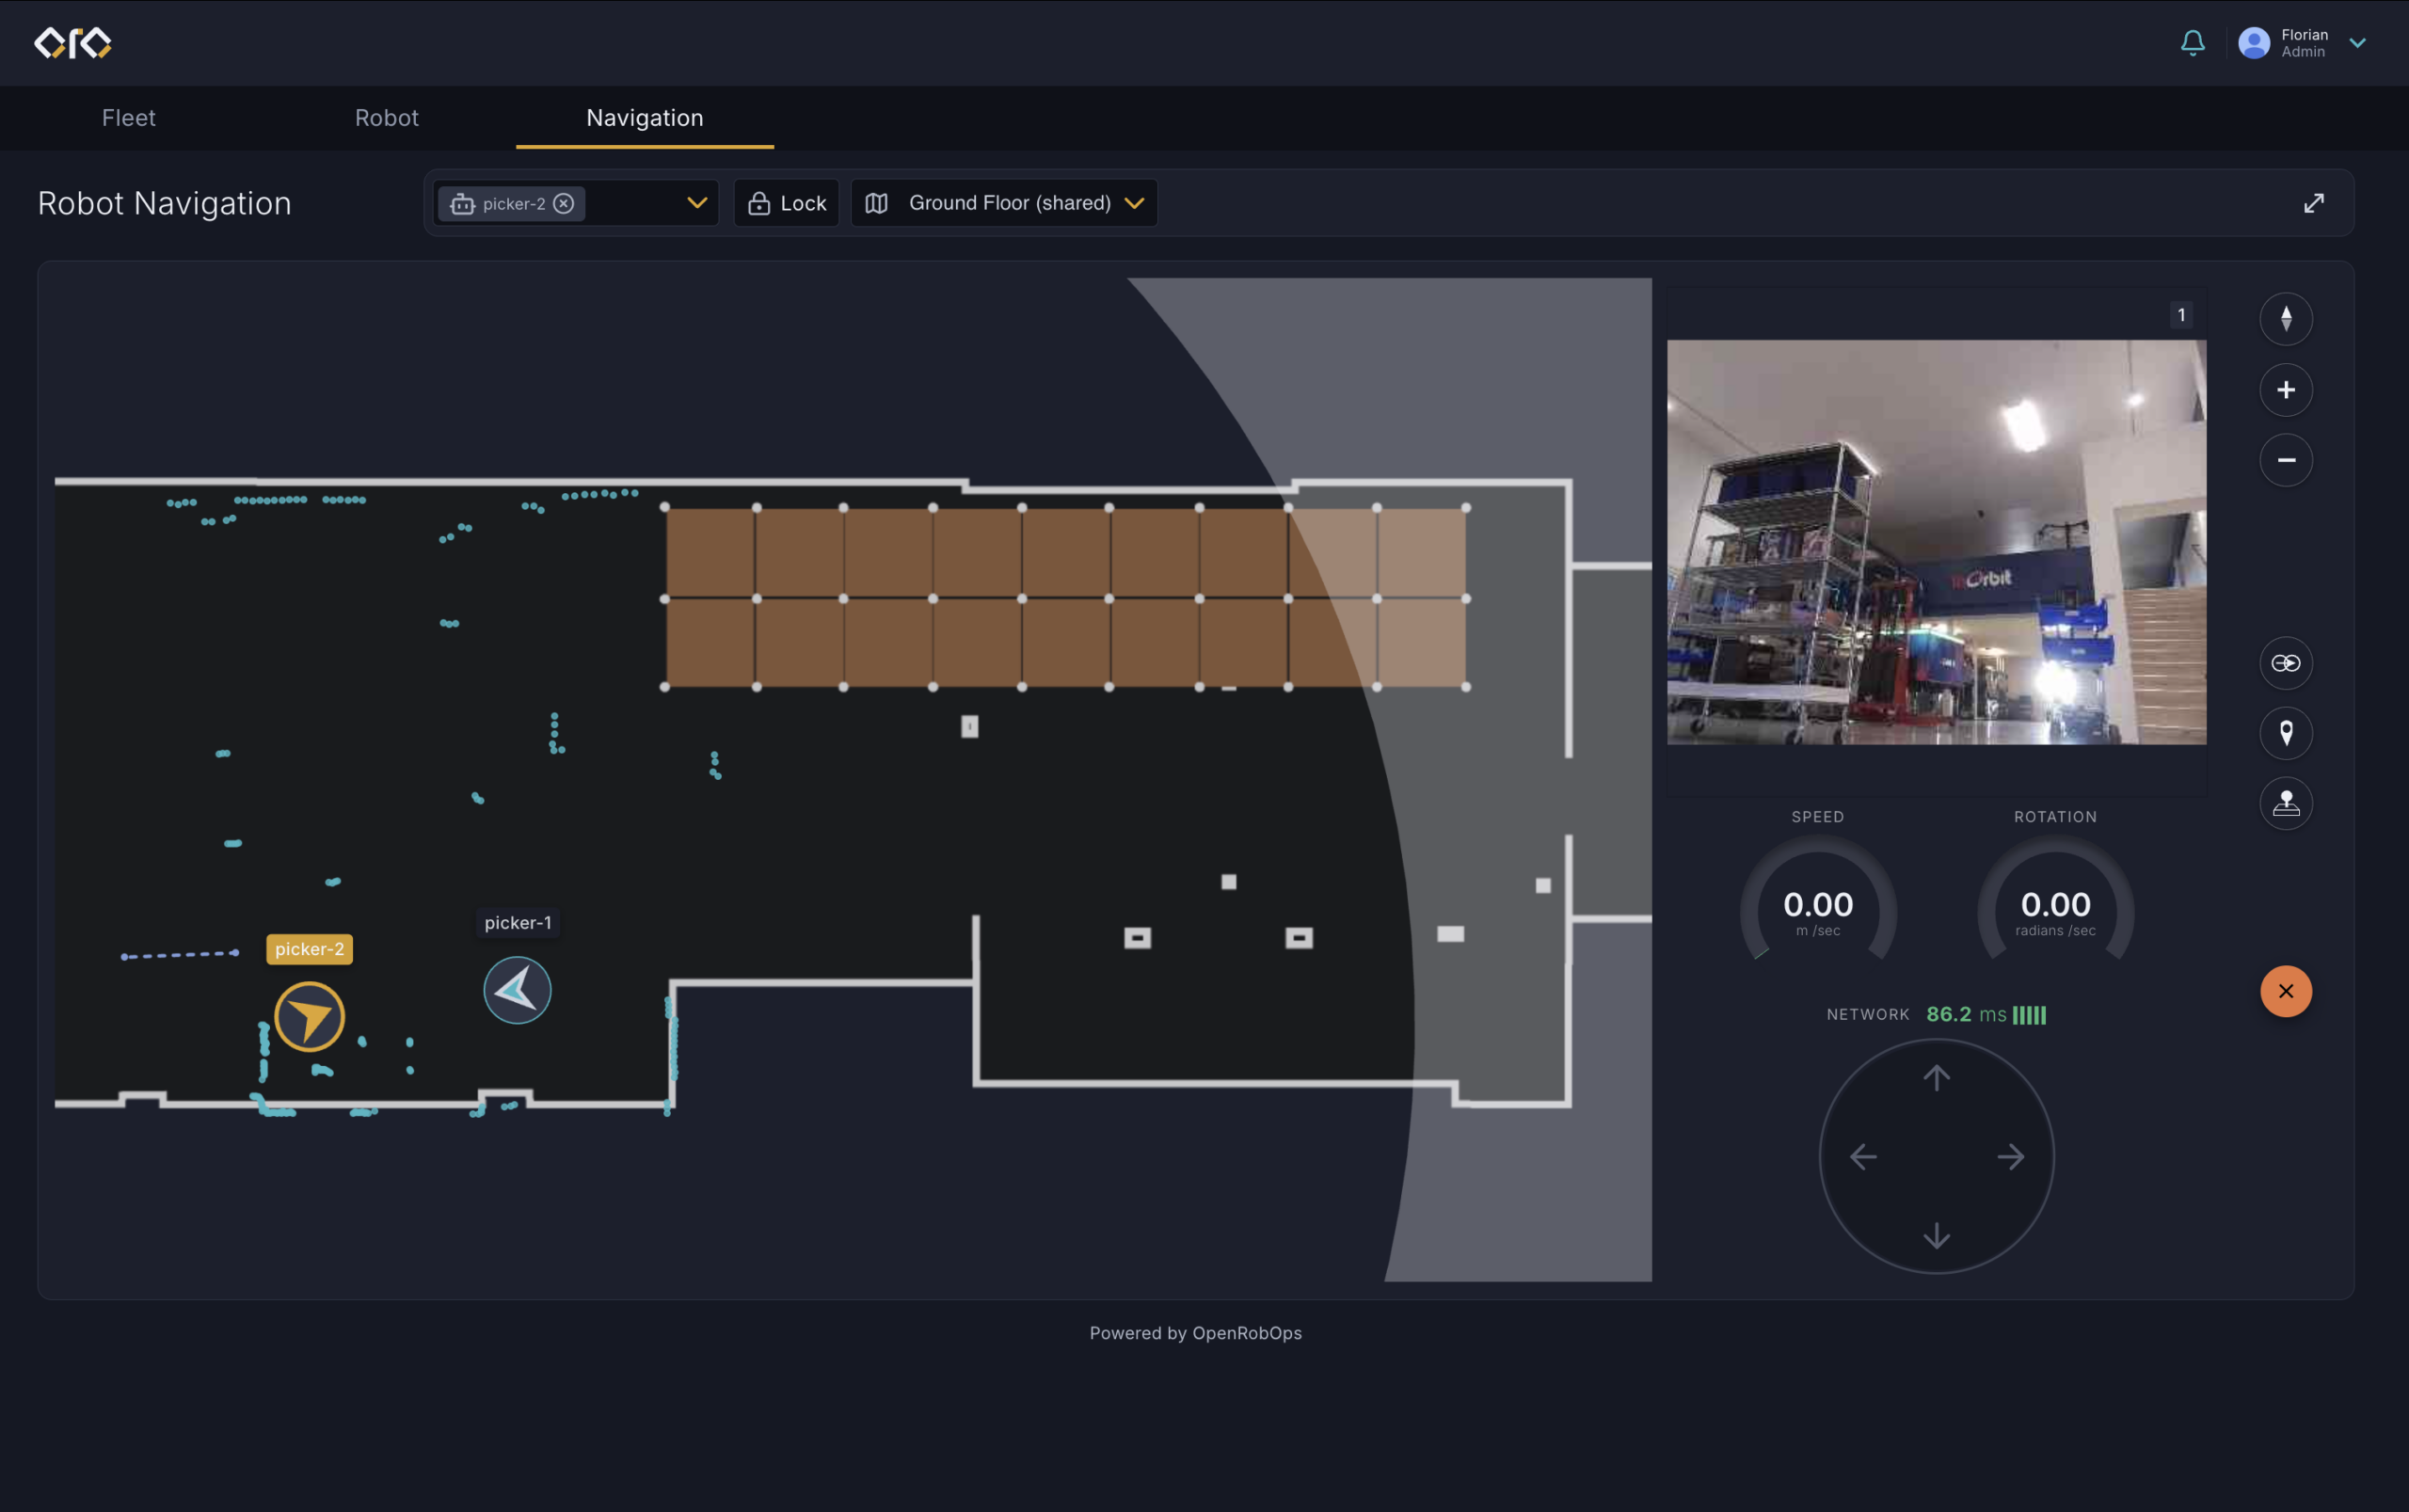
InOrbit.AI Launches OpenRobOps as ISO 21423 Reference Implementation for Fleet Management
InOrbit Inc. has introduced OpenRobOps, an open-source robot operations and fleet management software aimed at simplifying fleet orchestration for developers. This release marks the industry's first ISO 21423 reference implementation, which is designed to enhance interoperability among mobile robots and fleet managers. The significance of OpenRobOps lies in its potential to help robotics developers avoid the 'build trap' by providing a production-grade foundation that allows them to focus on innovation rather than backend development. According to Florian Pestoni, CEO of InOrbit, this initiative is a contribution to the global robotics community, enabling organizations to bridge the gap between business intent and physical execution. Looking ahead, OpenRobOps is expected to facilitate the adoption of the ISO 21423 standard, which governs communication and data exchange for industrial mobile robots. As the demand for autonomous mobile robots increases, the ability to provide standardized fleet management solutions will be crucial for OEMs and developers in the robotics sector. No further timeline was disclosed at the time of publication.
Autonomous Mobile Robots (AMRs) Development Tools / SDKs / Libraries Logistics Mobility / Navigation News Regulatory & Compliance
InOrbit.AI Launches OpenRobOps, First ISO 21423 Reference Implementation for Robotics
InOrbit.AI has announced the launch of OpenRobOps (ORO), an open-source robot operations software aimed at providing a production-grade foundation for robotics developers. This software facilitates the creation of a complete fleet manager and supports the forthcoming ISO interoperability standard for mobile robots. The introduction of OpenRobOps is significant as it addresses the robotics build trap, enabling developers to deploy robust fleet management solutions more efficiently. This release includes the first reference implementation of the ISO 21423 standard, marking a milestone in the standardization of mobile robot operations. Looking ahead, the industry will be watching how OpenRobOps influences the adoption of standardized practices in robotics and impacts the scalability of robotic deployments. No further timeline was disclosed at the time of publication.

InOrbit.AI Demonstrates the Future of Multi-Vendor Robot Orchestration and Physical AI at Automate 2026
InOrbit.AI is set to showcase a pioneering multi-vendor robotics demonstration at Automate 2026, highlighting the future of the sentient enterprise. This event will take place in 2026, where industry leaders and innovators will gather to explore advancements in automation technology. The demonstration aims to illustrate how seamless interoperability and Physical AI are revolutionizing disparate automation systems, creating a cohesive and resilient operational ecosystem. By integrating various robotic technologies, InOrbit.AI seeks to address the challenges of isolated automation, ultimately enhancing efficiency and productivity across industries. This initiative reflects a growing trend towards unified solutions in the robotics sector, emphasizing the importance of collaboration among vendors to drive innovation and improve operational capabilities.
Robotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.







