Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.
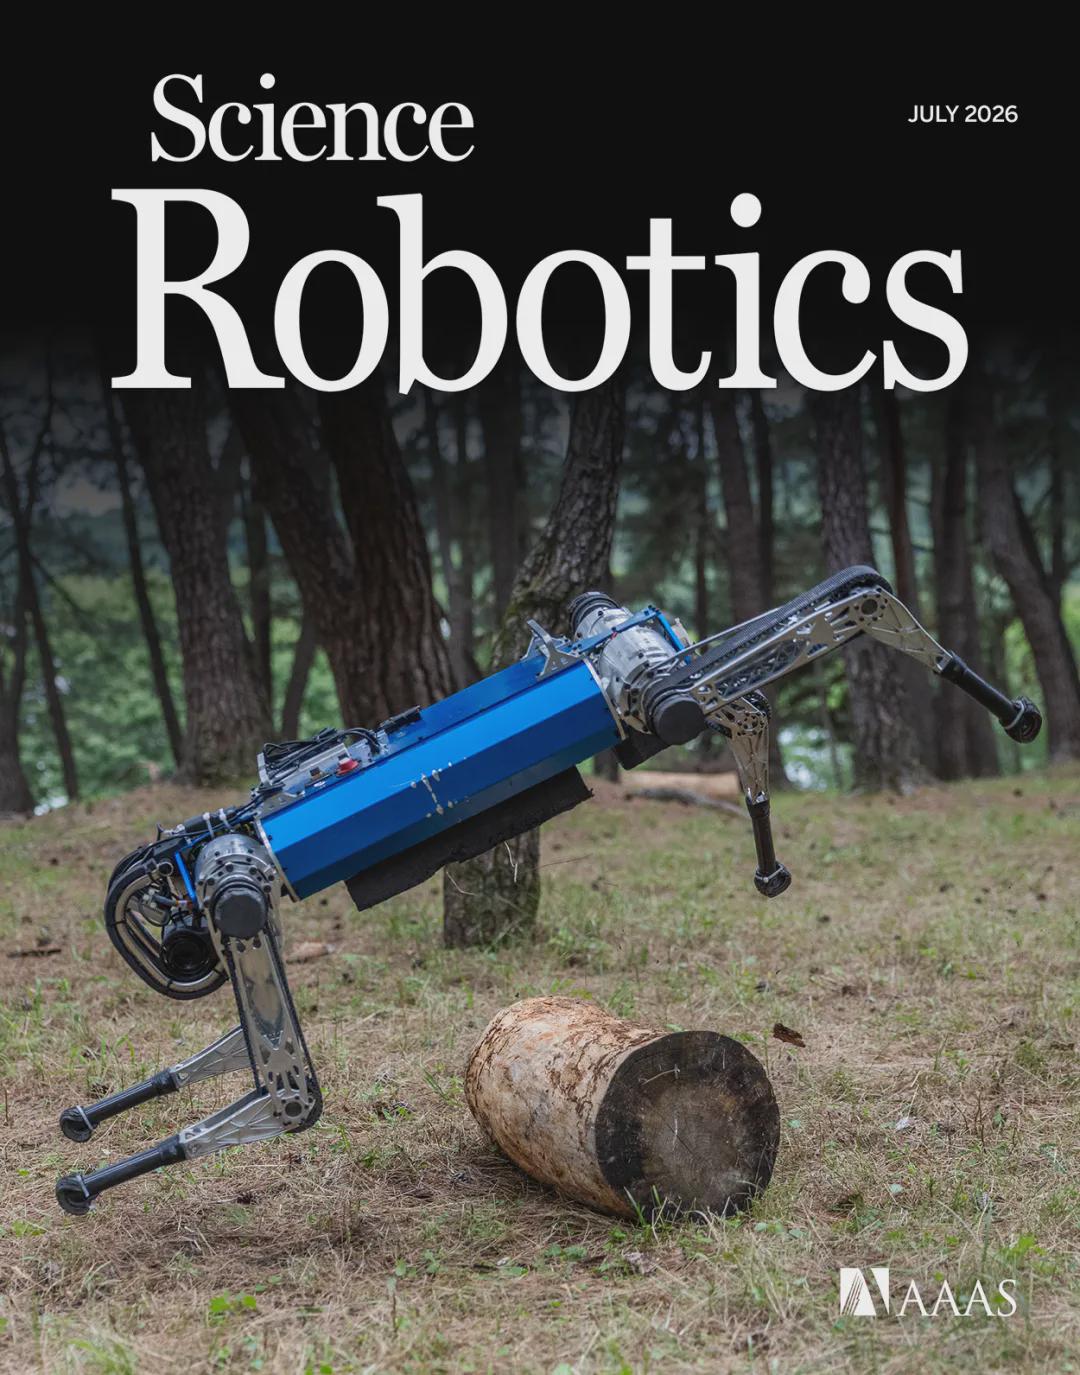
KAIST's HOUND Robot Reaches 6m/s Speed Using 2D Data for Advanced Parkour Skills
KAIST and Korea University researchers have developed the KAIST HOUND robot, achieving a peak speed of 6m/s while autonomously navigating complex terrains. This advancement showcases the robot's ability to seamlessly switch gaits, such as trotting and bounding, based on environmental conditions without external support. The significance of this achievement lies in the innovative APT-RL framework, which utilizes a simplified 2D dynamics model to generate extensive motion data. This approach allows the robot to learn and adapt its movements in real-world 3D environments, overcoming traditional limitations of motion capture and reinforcement learning strategies. Looking ahead, the research team has demonstrated the robot's capability to handle various scenarios, including jumping and maintaining balance under challenging conditions. Future developments may focus on enhancing the perception system to support high-speed operations, as the current sensing technology has limitations in effective range.
Quadrupedal Robots Robotics Research Reinforcement Learning AI Autonomous SystemsRobotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.