

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.
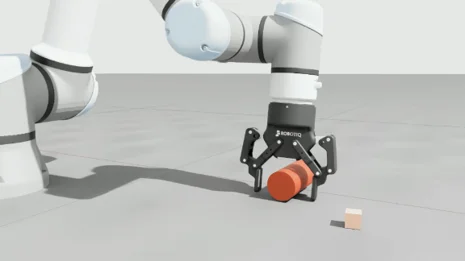
Robotiq Launches Open-Source Software Tools for Enhanced Adaptive Grippers
Robotiq has introduced three open-source software tools for its adaptive grippers, aimed at enhancing robotics development. These tools include a ROS 2 package, a standalone C++ SDK, and updated Isaac Sim assets, all available on Robotiq’s GitHub repository. This release marks the initial components of Robotiq’s Contact Core software layer for physical AI, with further advancements expected in the fourth quarter. The significance of this release lies in the growing demand for higher fidelity in simulation and tighter control loops for physical AI applications. According to Robotiq's CTO, Vincent Duchaine, conventional grippers do not meet the requirements of modern applications, which necessitate detailed reporting and continuous data collection across numerous cycles. The new tools are designed to support developers in creating more sophisticated robotics solutions. Looking ahead, Robotiq plans to introduce embedded intelligence at the point of contact, anticipated for release in the fourth quarter. The company will showcase this technology at the upcoming IEEE/RSJ International Conference on Intelligent Robots & Systems (IROS 2026) in Pittsburgh on September 28, 2026, at booth 427.
AI AI Funding & Investment AI Infrastructure & Compute Robotics C++ grippersRobotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.







