

Industry Briefing
A single destination for timely, editor-curated robotics news from around the world.
Human Pose Estimation Approach for Multi-Modal Perception in Dynamic Occlusion Scenarios
A recent study published in the Journal of Field Robotics explores a human pose estimation approach aimed at enhancing multi-modal perception in dynamic occlusion scenarios. This research is particularly relevant for improving human-robot collaboration, as it addresses the challenges posed by occlusions in real-time environments. The significance of this study lies in its potential to advance the capabilities of robots in collaborative settings, enabling them to better understand and interact with human counterparts. By focusing on dynamic occlusion scenarios, the research highlights the importance of robust perception systems that can adapt to changing environments, which is crucial for effective human-robot teamwork. Looking ahead, the implications of this research could lead to more sophisticated robotic systems capable of navigating complex environments while maintaining high levels of interaction with humans. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE
New Lightweight AI Framework Enhances Real-Time Robotic Grasping with 6D Pose Estimation
A new framework has been introduced for real-time 6D pose estimation in robotics, leveraging LightGlue for effective object detection and advanced geometric mapping techniques. This innovation aims to improve the efficiency and accuracy of robotic grasping tasks. The significance of this development lies in its potential to enhance robotic capabilities in various applications, making robots more adept at interacting with their environments. By utilizing a lightweight AI framework, the technology can operate in real-time, which is crucial for dynamic settings. Looking ahead, the industry will be watching how this framework is adopted in practical applications and its impact on the efficiency of robotic systems. No further timeline was disclosed at the time of publication.

BF-GNet: A Network for RGB-D Fusion in Grasp Pose Estimation
The article discusses BF-GNet, a novel RGB-D fusion network designed for grasp pose estimation in complex background environments. This technology aims to enhance robotic manipulation capabilities by accurately determining grasp poses despite challenging visual conditions. The significance of BF-GNet lies in its potential to improve the efficiency and reliability of robotic systems in real-world applications. By effectively integrating RGB and depth data, the network addresses common challenges faced in environments with clutter and varying textures, making it a valuable tool for advancing robotic perception. Looking ahead, the adoption of BF-GNet could lead to more sophisticated robotic applications in various sectors, including logistics and manufacturing. As the technology matures, further developments and potential collaborations may emerge to enhance its capabilities and deployment in practical scenarios. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE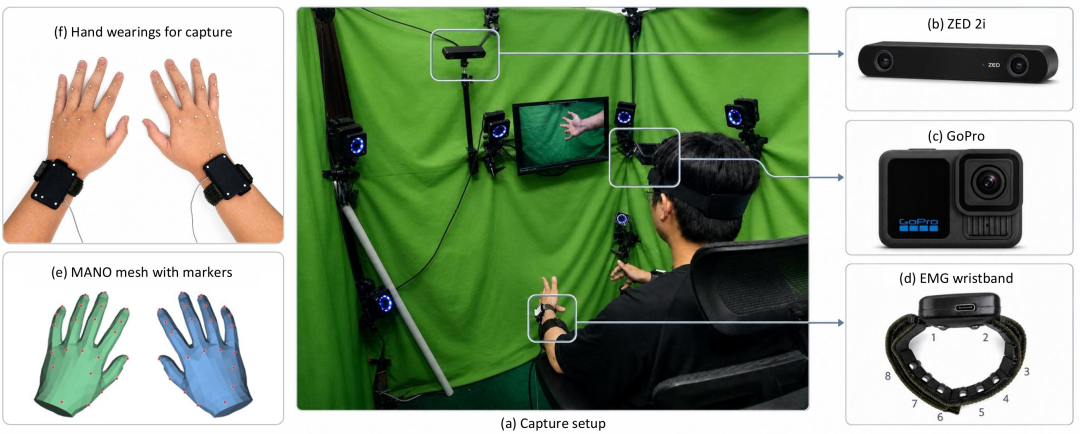
Tsinghua University and Shouyi Technology Launch EgoEMG Dataset for Hand Pose Estimation
Researchers from Tsinghua University and Shouyi Technology have unveiled the EgoEMG dataset, marking a significant advancement in the field of hand pose estimation. This innovative dataset is the first of its kind to publicly integrate electromyography (EMG), visual, depth, and motion data, providing a comprehensive resource for studying hand movements. Released in October 2023, the dataset aims to enhance embodied intelligence by offering precise data on hand operations. Its development is expected to facilitate progress in robotic dexterity through multimodal learning techniques, ultimately bridging existing gaps in the understanding of human-like manipulation in robotics.
Hand Pose Estimation EMG Technology Multimodal Data Robotics Artificial Intelligence
Tsinghua University and Shouyi Technology Launch EgoEMG Dataset for Hand Pose Estimation
A groundbreaking dataset, known as EgoEMG, has been launched through a collaboration between Tsinghua University and Shouyi Technology. This dataset is notable for being the first public resource to offer synchronized multimodal data specifically designed for hand pose estimation, incorporating both electromyography (EMG) and visual signals. Released in October 2023, EgoEMG aims to address existing challenges in hand perception for robotics. By providing comprehensive data that reflects human hand movements, the dataset seeks to enhance the capability of machines to learn and perform dexterous tasks through human demonstration. This initiative represents a significant step forward in the field of robotics, potentially improving the interaction between humans and machines in various applications.
Hand Pose Estimation Multimodal Data Robotics EMG Technology
Pose Estimation Accuracy Improvement Using Different Orientation Representations With Neural Networks: Case Study for the VIVE HTC Tracker
In a recent study published in the Journal of Field Robotics, researchers from a leading robotics institute have unveiled innovative advancements in autonomous navigation systems. This groundbreaking research, conducted in October 2023, aims to enhance the efficiency and safety of robotic applications in various fields, including agriculture and disaster response. The team focused on developing algorithms that enable robots to better interpret their surroundings and make real-time decisions. By integrating advanced sensor technology and machine learning techniques, the researchers demonstrated how these systems could significantly improve the robots' ability to navigate complex environments. The motivation behind this research stems from the increasing demand for autonomous solutions that can operate in unpredictable conditions. As industries seek to leverage robotics for tasks that are hazardous or labor-intensive, the need for reliable navigation systems becomes paramount. The study involved extensive field tests, where the robots were deployed in diverse scenarios to assess their performance. The results indicated a marked improvement in navigation accuracy and obstacle avoidance, showcasing the potential for these technologies to revolutionize how robots are utilized in real-world applications. This research not only contributes to the academic field but also has practical implications for industries looking to adopt autonomous systems. By addressing the challenges of navigation in dynamic environments, the findings pave the way for more effective and safer robotic operations in the future.
RESEARCH ARTICLERobotics needs a service framework.
RSF defines a common language for robot service capability, lifecycle operations, certification pathways, and service-provider networks.
Join the RobotToday community on LinkedIn
Daily robotics news, in-depth analysis, conference highlights, and discussions with professionals worldwide.







