

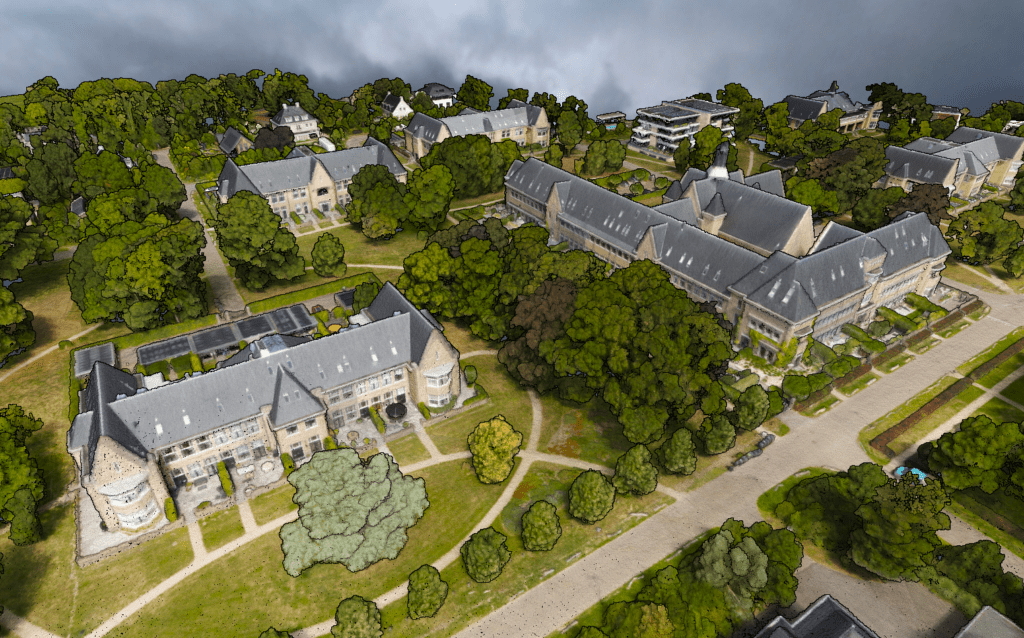
SimActive has launched a new feature in Correlator3D that allows users to publish Gaussian splat models directly to a connected Cesium account. Announced on October 6, 2026, this capability simplifies the distribution of photorealistic 3D results, enabling users to share models without the need for file exports or format conversions.
This development is significant as it enhances the accessibility of photorealistic 3D data for clients and stakeholders outside the processing environment. By integrating with Cesium, users can seamlessly share their Gaussian splat models, which represent scenes with overlapping 3D points, color, and transparency, making them ideal for non-technical audiences.
Looking ahead, the focus will be on how this new sharing capability impacts the workflow of mapping firms and government organizations that utilize Correlator3D. No further timeline was disclosed at the time of publication.
Editor's Note
The introduction of online sharing capabilities in photogrammetry software like Correlator3D reflects a growing trend towards enhancing collaboration and accessibility in geospatial data processing. As organizations increasingly seek efficient ways to present complex data to diverse audiences, features that simplify sharing and visualization will be critical in driving technology adoption across various sectors.
Copyright Notice
This briefing is an independently written summary based on publicly available reporting and is provided for industry information and news discovery. The original report and source publication are credited and linked where applicable. RobotToday does not claim ownership of third-party source material.
Rights concerns? If you believe any material in this briefing infringes your copyright or other rights, please contact [email protected] with the relevant URL and details. We will review the matter and take appropriate action where warranted.




Leave a comment