Nikon Metrology NV
Belgian subsidiary of Nikon Corporation providing industrial metrology solutions including CMMs, laser scanners, laser radar, and X-ray CT systems.
Contact Nikon Metrology NV
WEBSITE
https://industry.nikon.comPHONE
+32 16 74 01 00HEADQUARTERS
Belgium
Company Facts
Founded
1995
Primary Role
Manufacturer
Company Size
-
Primary Region
Europe
Annual Sales
-
Funding Stage
-
Funding Total
-
MIT Researchers Develop New AI Technique for Safety-Critical Applications
MIT researchers have introduced a novel method that enhances generative artificial intelligence models for high-stakes problem-solving. This technique allows models to generate outputs that not only provide plausible solutions but also adhere to strict safety and task-specific requirements, known as hard constraints. By allowing more freedom during the generation process and enforcing constraints only on the final output, the method consistently delivers better solutions across various applications, including robotics and computer vision. The significance of this development lies in its potential to improve the reliability of AI in safety-critical environments. Traditional methods often struggle to balance the generative capabilities of AI with the necessity of meeting stringent safety standards. The new approach enables pretrained generative models to be adapted for use in scenarios where compliance with safety rules and physical laws is essential, thus expanding their applicability in real-world situations. Looking ahead, the adaptability of this technique suggests a promising future for generative AI in complex environments. As industries increasingly rely on AI for tasks like robot path planning, the ability to enforce hard constraints without compromising output quality will be crucial. No further timeline was disclosed at the time of publication.
Research Computer science and technology Artificial intelligence Machine learning Algorithms Mechanical engineering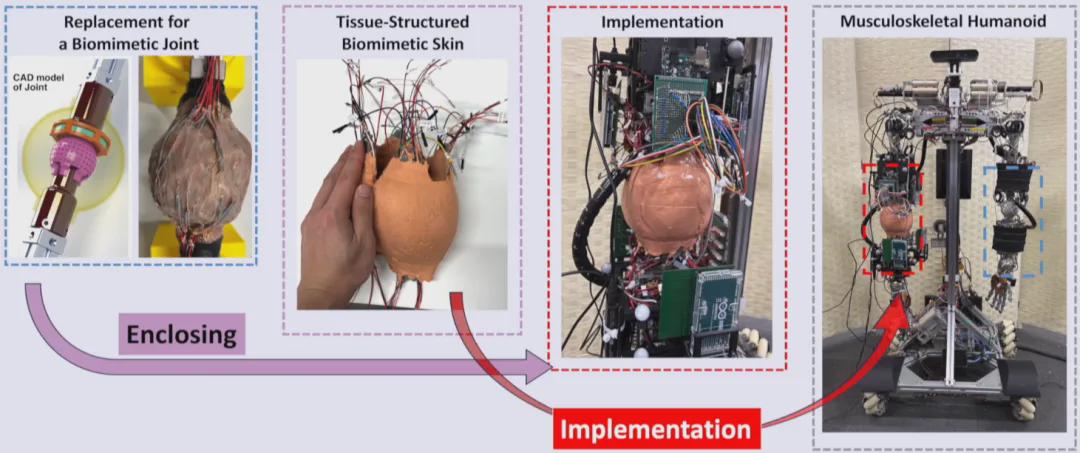
Tokyo University Innovates Artificial Skin for Enhanced Joint Angle Sensing in Robots
Tokyo University's research team has developed an artificial skin that enables robots to accurately sense joint angles through its deformation. This bionic skin, designed with a tissue-like layered structure, was tested on the Musashi-W humanoid robot. The results indicated that the average estimation error for joint angles could be maintained within approximately 3 degrees, and further accuracy was achievable by integrating skin and muscle information. This advancement is significant as traditional muscle-driven humanoid robots face challenges in measuring joint angles directly, unlike conventional robotic joints that utilize encoders. Current methods rely on limited sensors, such as muscle length and tension sensors, to infer joint angles. The research team's approach mimics biological structures by embedding numerous small sensors within soft tissues, enhancing the robot's ability to discern between external disturbances and internal state changes. Moving forward, the integration of these sensors into robotic systems could revolutionize how robots perceive their own movements and interactions with the environment. No further timeline was disclosed at the time of publication.
Humanoid Robots Proprioception Biomimetic Technology Robotic Sensors
Alien Control Systems Opens 191,000-Square-Foot Facility for Bullfrog Counter-Drone Production
Alien Control Systems (ACS) is launching a new 191,000-square-foot manufacturing facility in Austin, Texas, to enhance production of its Bullfrog counter-drone system. This expansion is a direct response to increased demand from the U.S. and allied nations for effective countermeasures against weaponized drones. The new facility will allow ACS to rapidly scale production of Bullfrog, which integrates computer vision, autonomous control, and precision robotics. The system has already been deployed by the U.S. Army and Navy, and it has contracts with Joint Interagency Task Force 401 and several allied militaries, underscoring its significance in safeguarding critical infrastructure. Looking ahead, ACS aims to further expand Bullfrog's deployment across U.S. military services, following its recent selection by the U.S. Marine Corps for the Ground Based Air Defense program. No further timeline was disclosed at the time of publication.
Military
UltraSense Proposes Ultrasound as a Solution for Tactile Intelligence in Robotics
UltraSense has introduced ultrasound technology as a solution to enhance tactile sensing in robotics, addressing the wear and tear associated with traditional electronic skin. As robots evolve to interact more effectively with their environments, reliable touch sensing becomes crucial for various applications, including humanoid hands and industrial systems. The challenge lies in developing a scalable tactile architecture that can withstand harsh mechanical conditions while maintaining signal integrity over time. The significance of this development is underscored by the limitations of current tactile sensing technologies, which often struggle with durability and accuracy due to environmental factors. Traditional methods, such as capacitive and piezoelectric sensors, face challenges like wear, hysteresis, and recalibration burdens, particularly in high-duty-cycle applications. UltraSense's approach aims to provide a more robust solution that can sustain performance across millions of contact cycles, making it a potential game-changer in the field of physical AI. Looking ahead, the industry will need to monitor advancements in ultrasound technology and its integration into robotic systems. As physical AI continues to gain traction, the ability to maintain accurate and reliable tactile sensing will be critical for the success of various robotic applications. No further timeline was disclosed at the time of publication.
Artificial Intelligence / Cognition Grippers Human Robot Interaction / Haptics Humanoids Microprocessors / SoCs News
New Images of China's WZ-X Stealth Drone Reveal Key Features and Flight Capabilities
Recent images have surfaced showing China's WZ-X stealth drone, resembling the American B-2 Spirit. These photos, taken at an undisclosed location, highlight the drone's unique serrated trailing edge, suggesting advanced stealth capabilities. This design feature is intended to deflect radar signals, enhancing its operational effectiveness in contested airspace. The significance of the WZ-X lies in its potential role for reconnaissance missions, akin to the US RQ-170/RQ-180 drones. Analysts speculate that it could gather crucial intelligence while maintaining a low radar profile, thanks to its flying-wing design. The drone's daylight test flights indicate a shift towards a more advanced flight-test phase, suggesting increased confidence in its capabilities. Future developments to watch include the potential integration of advanced sensor systems such as synthetic-aperture radar and electronic-intelligence equipment. However, the exact specifications and operational capabilities of the WZ-X remain largely unverified, as the designation is unofficial and the images have not been independently authenticated.
Innovation Military
Humanoid Robot Demonstrates Agility on Monkey Bars in Latest Video Showcase
In the latest edition of Video Friday, a humanoid robot showcases its ability to traverse monkey bars, demonstrating advanced agility and perception of complex 3D structures. This task requires the robot to jump onto the structure, navigate through sparse bar interactions, and land safely, highlighting its whole-body motion capabilities. The significance of this demonstration lies in its implications for humanoid robotics, particularly in environments where navigating thin and overhanging geometries is essential. As humanoid robots become more adept at traversing challenging obstacles, the potential applications in search and rescue, disaster response, and other critical fields continue to expand. Looking ahead, the upcoming Humanoids Summit in Seoul and other robotics events scheduled for late 2026 will likely feature further advancements in humanoid robotics. No further timeline was disclosed at the time of publication.
Humanoid-robots Video-friday Drones Robot-videos Center-for-robot-assisted-search Quadruped-robots
ACE Robotics and NTU S-Lab Release Open-Source Puffin-World Multimodal Model
ACE Robotics and NTU S-Lab have announced the open-source release of Puffin-World, a multimodal world model that integrates physics, geometry, and appearance. This model utilizes the Puffin-16M dataset and achieves state-of-the-art camera absolute pose errors, reporting sub-degree accuracy across four public benchmarks. The significance of this release lies in its potential to enhance various applications in robotics and computer vision by providing a unified framework for understanding complex environments. By achieving such high accuracy in pose estimation, Puffin-World could facilitate advancements in autonomous navigation and scene understanding. Looking ahead, the impact of Puffin-World on the robotics community will be closely monitored, particularly in how it influences future research and development in multimodal models. No further timeline was disclosed at the time of publication.
Northrop Grumman's Lumberjack Drone Successfully Tests Quantum Navigation Technology
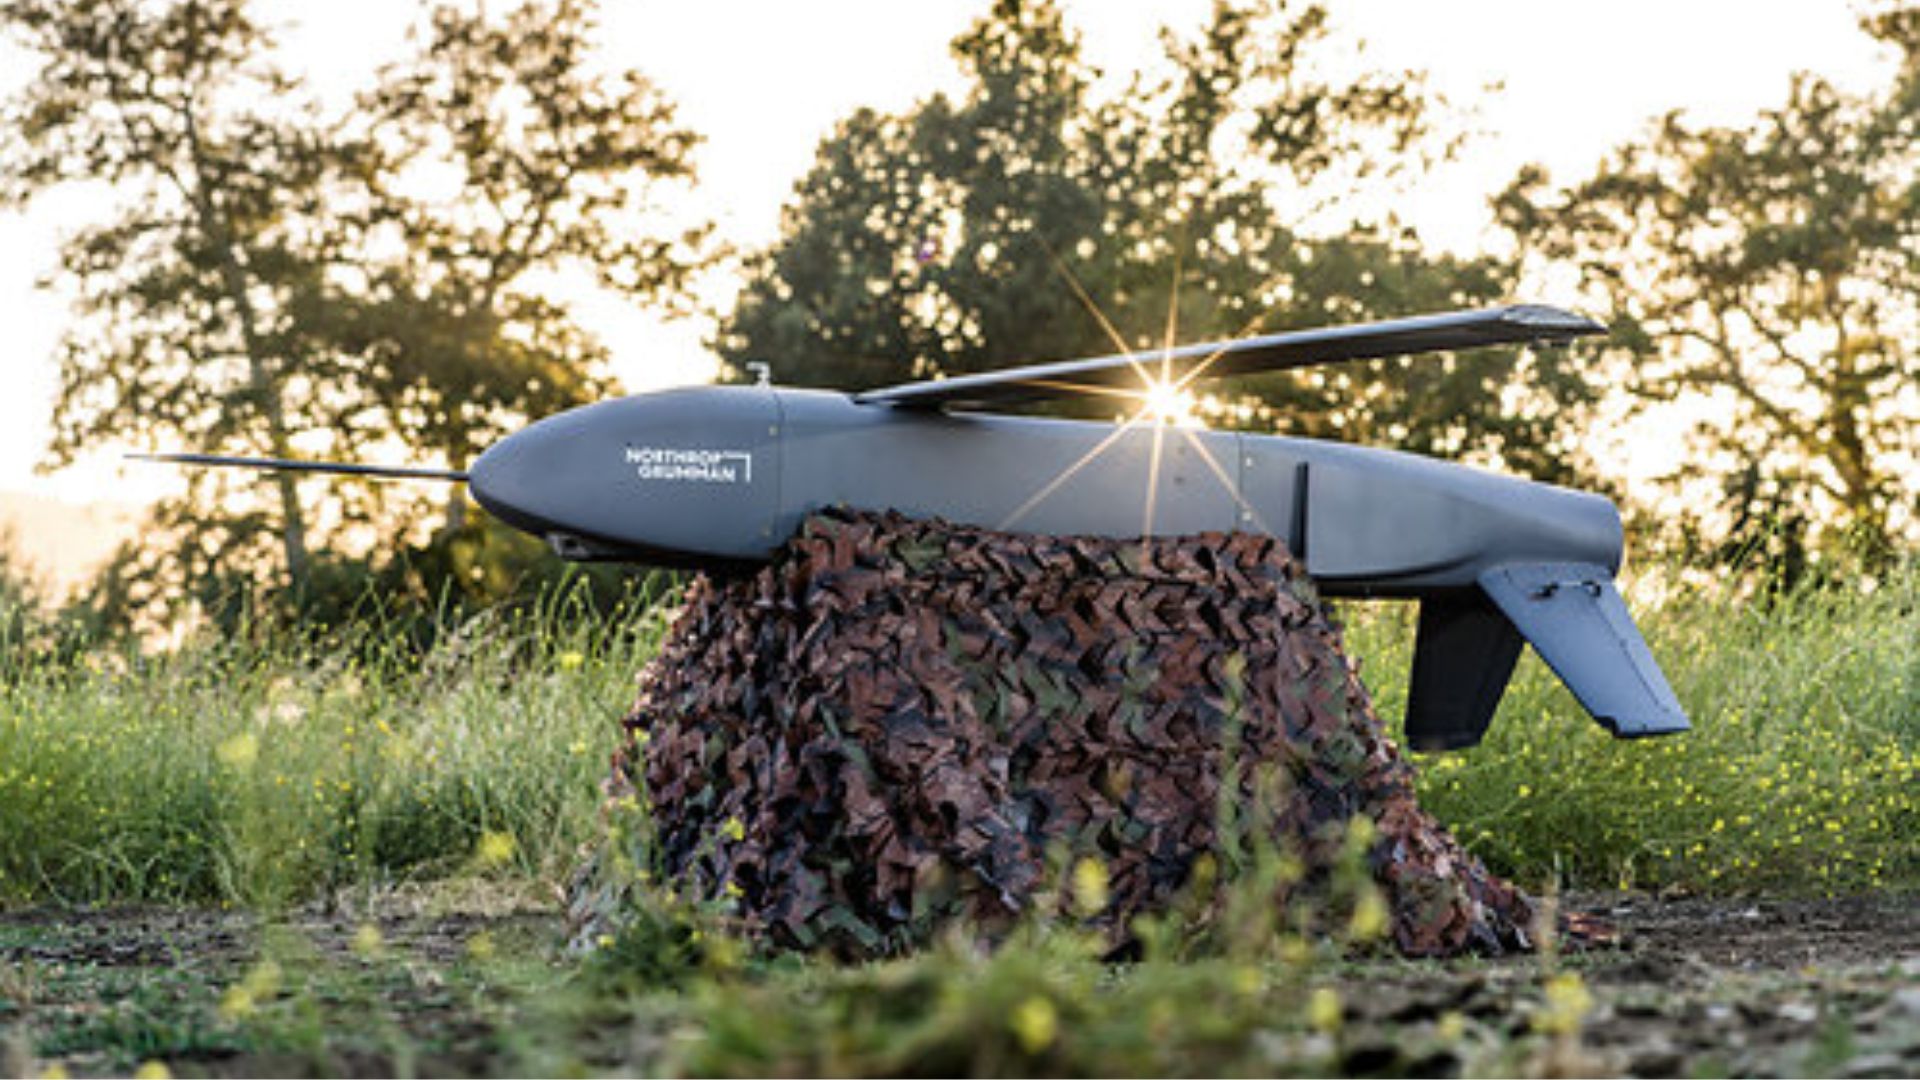
Sandbox AQ has successfully tested its quantum sensor-based Magnetic Navigation (MagNav) on Northrop Grumman’s Lumberjack drone, marking a significant milestone in unmanned aircraft systems. This test is the first of its kind for an attritable drone, showcasing the potential of quantum navigation in GPS-denied environments, which is increasingly relevant given current military operations. The successful integration of MagNav with Lumberjack's visual navigation system is crucial as the U.S. military seeks alternatives to GPS for navigation and targeting. The ongoing conflicts in Ukraine and West Asia highlight the need for resilient navigation systems that can operate effectively even when GPS signals are jammed or spoofed. This advancement could enhance operational capabilities in contested domains. Looking ahead, the deployment of Sandbox AQ’s AQNav technology in various aircraft platforms could revolutionize military navigation. The ease of integration into existing systems, as demonstrated by the rapid installation on Lumberjack, suggests a promising future for quantum navigation solutions in defense applications. No further timeline was disclosed at the time of publication.
Military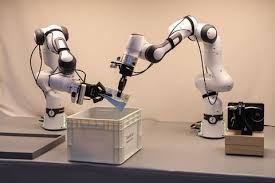
Tactile Sensing Technology Sees Significant Growth in Robotics Sector
Tactile sensing technology is gaining prominence in the robotics industry as humanoid robots transition from exhibition spaces to factory floors. Since 2026, funding in the tactile sensing sector has exceeded 7 billion yuan, with the penetration rate of tactile sensors in commercial humanoid dexterous hands rising from 20% to over 60% this year. This rapid growth is notable within the robotics components sector, highlighting a shift in robotic applications. While visual-language-action models have enhanced robots' environmental understanding and task planning, precision assembly and flexible grasping require tactile feedback for effective force control and slip detection. According to Qianjue Robotics founder Ma Daolin, tactile sensing is essential for high-precision industrial operations. The evolution of technology supports this need, as Qianjue Robotics' VTLA model integrates tactile modalities into traditional frameworks, enabling real-time perception of deformation, texture, and force distribution during contact. Their comprehensive tactile solution expands sensing from fingertips to palms, achieving a sensor density of 125 points per square centimeter and a force accuracy of 0.03 Newtons. As hardware costs decrease and data accumulation accelerates, tactile sensing is becoming a necessary capability in real-world operational scenarios.
Tactile Sensors Humanoid Robots Robotics Technology Industrial Automation
Vention Showcases Unified Platform Integrating Physical AI and Agentic AI at IMTS 2026
Vention is set to demonstrate its unified industrial automation platform at IMTS 2026, featuring both Physical AI and Agentic AI. The platform combines these two layers of intelligence to enhance robotics and machine operations, showcasing innovations such as the MachineAgent agentic cell. The significance of this development lies in its potential to streamline manufacturing processes through an interactive, end-to-end automated workflow. Attendees can witness live demonstrations of Physical AI capabilities, including Rapid Operator AI for deep bin picking and goal-driven collision-free path planning, which utilize advanced autonomous perception and robotic motion. Looking ahead, industry professionals should monitor how Vention's integration of these AI technologies influences manufacturing efficiency and automation trends. No further timeline was disclosed at the time of publication.
China’s Dexterous Hand Industry, 2026 Part 1 — The Demand Picture
MIR Databank puts China dexterous hand shipments above 30,000 units in 2026, yet only 3.5% of 2025 demand came from factory production. Part 1 of 3.
China’s Dexterous Hand Industry, 2026 Part 2 — The Technology
Linkage, tendon, direct drive or hybrid — and why hardware is converging while the DL1–DL5 manipulation scale decides who wins. Part 2 of 3.
ROBOTTODAY WEEKLY BRIEFING August 24 – 28, 2026
This week in robotics: XPeng's Dogotix raises over $900 million at a $6.3 billion valuation, Unitree's post-IPO slump revives bubble talk, Beijing's World Humanoid Robot Games close with a shift to real-world tasks, and Teradyne sues JAKA at Europe's Unified Patent Court. August 24–28, 2026.
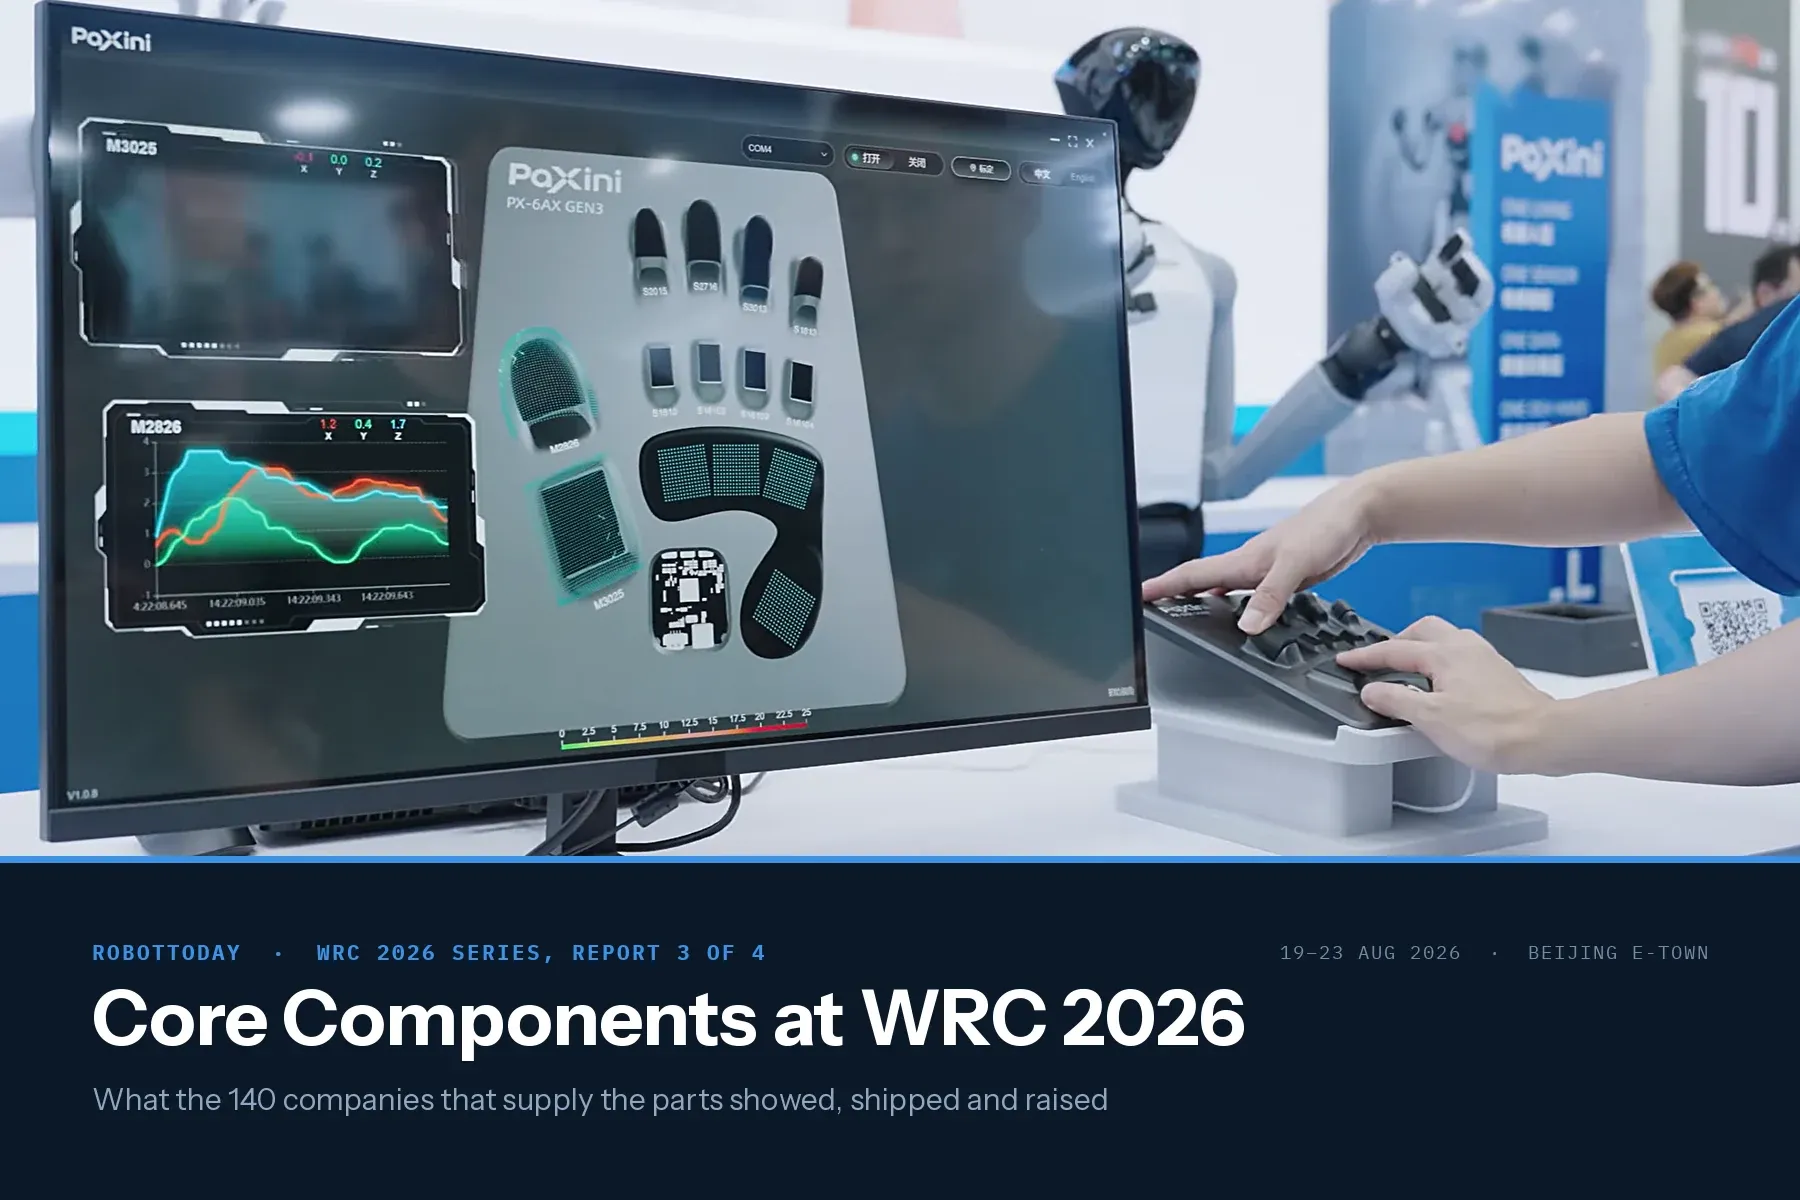
WRC 2026 Core Components: 137 Robot Parts Suppliers
The third report in the WRC 2026 series. Report 1 mapped all 248 exhibitors by category and Report 2 covered the 139 that build finished robots. This one covers the 137 that build what goes inside them.
WRC 2026 Exhibitor Map: 248 Robotics Companies Mapped
We classified 248 WRC 2026 exhibitors with the RobotToday taxonomy. Motion & Actuation leads at 75 companies, Humanoid at 72, and compute stays thin at 12. (Modified 2026-08-27)
Handbook of Marine Craft Hydrodynamics and Motion Control Thor I. Fossen — RSF Specialist Shelf · Book S1 of 6
Added mass, wave loading, DVL navigation: the marine GNC reference for USV, ROV and AUV service engineers. The hardest book on the RSF list, 5/5.
Small Unmanned Aircraft: Theory and Practice Beard & McLain — RSF Specialist Shelf · Book S2 of 6
Beard & McLain derive the fixed-wing autopilot the RSF Top 10 never does: successive loop closure on roll, pitch, altitude and airspeed. 4/5.
Reinforcement Learning: An Introduction Richard S. Sutton & Andrew G. Barto — RSF Specialist Shelf · Book S5 of 6
“It's the AI” will not satisfy an OEM support call. Sutton & Barto turn that into something a service engineer can investigate. Free PDF, Part I 4/5.
Planning Algorithms Steven M. LaValle — RSF Specialist Shelf · Book S4 of 6
The reference that treats planning as a subject in its own right: configuration space, sampling-based methods, RRT. Free online, dual difficulty 4/5-2/5.
Underactuated Robotics Russ Tedrake — RSF Specialist Shelf · Book S3 of 6
Legged robots fall over for control reasons, not mechanical ones. Tedrake's free MIT 6.832 notes explain why, and what a controller must do about it.