

Renovate Robotics
"Rethinking Roofing with Robotics"
Brooklyn-based startup developing autonomous roof shingle installation robots for residential and multifamily roofing contractors.
Contact Renovate Robotics
WEBSITE
https://www.renovaterobotics.com/HEADQUARTERS
United States

Company Facts
Founded
2021
Primary Role
Manufacturer
Company Size
-
Primary Region
North America
Annual Sales
-
Funding Stage
-
Funding Total
-
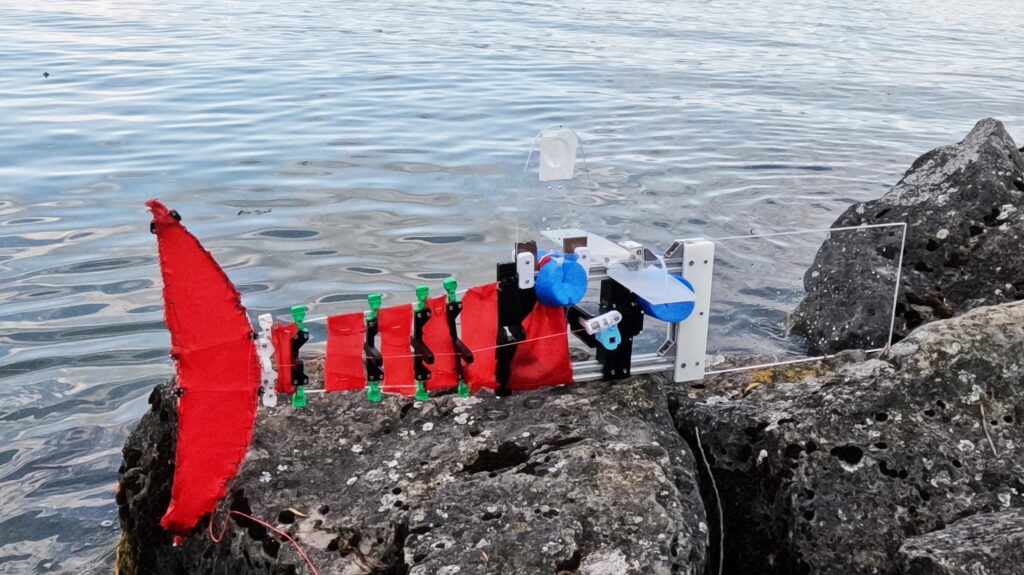
EPFL and NYU Develop Scalable Robotic Fish for Diverse Aquatic Environments
A team from EPFL and NYU has introduced ScaFi, a scalable robotic fish designed to adapt to various aquatic environments. Unlike traditional propeller-driven vehicles, ScaFi mimics the swimming motion of fish, allowing it to navigate shallow waters and dense vegetation without disturbing wildlife. The significance of ScaFi lies in its ability to maintain swimming efficiency across different sizes, which could reduce the engineering effort required for aquatic robots. The research highlights the importance of adaptable tools for environmental monitoring, as ecosystems vary greatly in size and complexity. Future developments will focus on understanding the energy efficiency of ScaFi as it scales, as initial tests revealed challenges with larger models. The team aims to explore whether the energy performance can be improved alongside the swimming capabilities of the robotic fish.
Chen Pu of Yuan Ke Vision Discusses Transitioning Robot Training Data from 2D to 4D with High Precision
On September 23, Chen Pu, Vice President of Product Development at Yuan Ke Vision, highlighted the importance of high-quality real data for robot training during a seminar in Beijing. He emphasized the need to elevate data from 2D to 4D and improve precision from centimeter to sub-millimeter levels to build a robust 4D data foundation for robotics. This transition is crucial as the industry faces challenges such as weak model generalization and inadequate scene adaptability. Chen noted that current training methods often rely on limited 2D video data, which fails to capture the complexities of three-dimensional space and temporal changes, hindering robots' ability to understand and interact with their environments effectively. Looking ahead, Yuan Ke Vision aims to address these challenges by developing new data collection and training paradigms that enhance dimensionality, enrich modalities, and improve precision. Chen pointed out that while video data serves as a foundation, it is often too simplistic, and the lack of tactile data remains a significant gap in the industry. No further timeline was disclosed at the time of publication.
Robot Training Data 4D Data Collection Industrial Robotics Embodied Intelligence Precision Robotics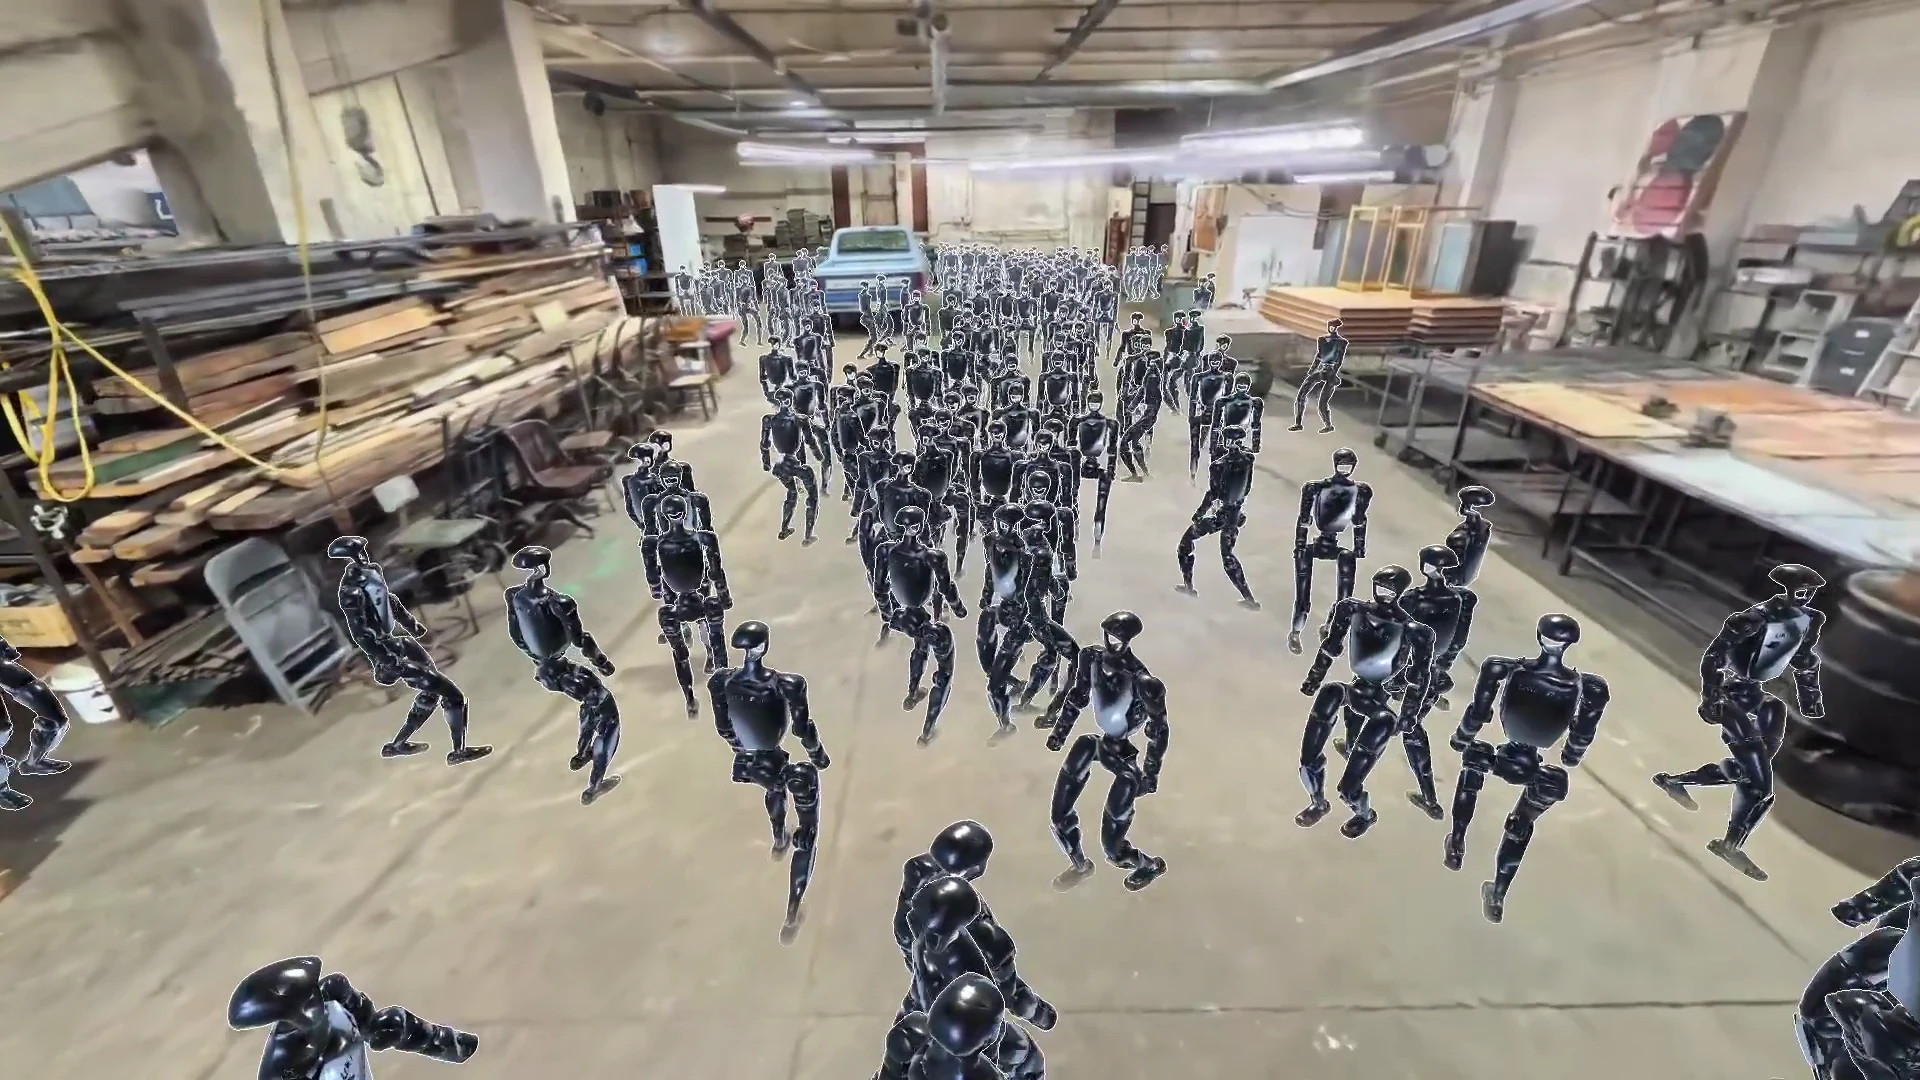
Niantic Spatial Introduces Places Library Featuring 100 Real Environments for Robot Training
Niantic Spatial has launched its Places Library, providing robotics developers with a catalog of 100 real environments for training and evaluation. The assets, available as USDZ files, include two representations for each environment: a Gaussian splat for visual appearance and a mesh for collision detection. This initiative aims to enhance embodied AI training by offering realistic settings that align with gravity and support various simulators, including NVIDIA Isaac Sim. The significance of this launch lies in its potential to improve robot training efficiency. By utilizing real-world environments captured with a standard 360-degree camera, Niantic ensures that robots receive accurate visual and collision data, which is crucial for effective navigation and interaction. The library includes diverse settings, such as medical warehouses and urban streets, allowing developers to test their robots in varied scenarios without the need for extensive in-house data collection. Looking ahead, the Places Library could facilitate more advanced evaluations of robotic behavior in different environments. While the library's impact on performance across the 100 environments remains to be seen, it offers a valuable resource for robotics teams aiming to refine navigation tasks and adapt to changing surroundings. No further timeline was disclosed at the time of publication.
Niantic Spatial Flexion
Memo Unveils Physical-WAM to Enhance Embodied Intelligence at Global Digital Trade Expo
At the Global Digital Trade Expo on September 24, Memo introduced the Physical-WAM, the world's first physical-world action model equipped with physical perception capabilities. This innovation aims to address the challenges faced by robots in understanding and interacting with the physical world, which has hindered the widespread adoption of embodied intelligence. The significance of this development lies in its potential to bridge the data gap that currently limits robots' physical interactions. Memo's CEO, Li Minghao, highlighted that the lack of foundational physical understanding in robots stems from insufficient real-world interaction data and inadequate evaluation metrics. The Physical-WAM model is designed to enhance robots' predictive capabilities and real-time adjustments in physical tasks. Looking ahead, the demand for embodied intelligence is surging, with significant investments in the sector. However, challenges remain in aligning order fulfillment with funding growth. As the industry evolves, the effectiveness of solutions like Physical-WAM will be crucial in overcoming existing barriers to practical implementation.
Embodied Intelligence Physical AI Robotics Machine Learning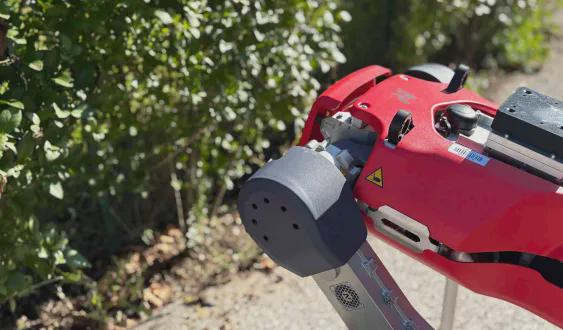
Robot Dogs Use Insect-Inspired Movements to See Through Obstructions in 17 Milliseconds
A collaborative team from Johannes Kepler University Linz, Free University of Bozen-Bolzano, University of Trento, and University of Sussex has developed a method for robot dogs to mimic insect movements to enhance their visual perception. By performing rhythmic lateral movements, akin to the 'peering' behavior observed in insects like locusts, these robots can effectively see through obstructions such as foliage and debris. This innovation is significant as it addresses a common challenge faced by exploration robots in environments cluttered with obstacles that hinder visual sensors. The research establishes a connection between the peering motion and synthetic aperture sensing, allowing the robots to create a virtual aperture that enhances background signals while blurring out obstructions. Future developments to watch include the potential applications of this technology in various environments, including forests and disaster sites. The research indicates that the synthetic aperture technique is most effective at around 50% obstruction density, suggesting a promising avenue for improving robotic vision in complex terrains. No further timeline was disclosed at the time of publication.
Robotics Computer Vision AI Obstacle Detection
Mondo Robotics' Beni: A Tumbling Robot Camera with Significant Obstacle Avoidance Issues
Mondo Robotics has introduced Beni, a small bipedal robot designed to capture and record video while following users. Equipped with a built-in camera and sensors, Beni can perform tricks like flips and roll while tracking specified objects via an app. However, after several weeks of testing, reviewers found Beni's obstacle avoidance capabilities severely lacking. The importance of Beni lies in its potential as a fun companion for personal activities like sports and pet video recording. Despite its interesting features, the robot struggles significantly with obstacle avoidance, often losing track of its target in cluttered environments. Reviewers noted that even in open spaces, Beni failed to navigate around obstacles effectively, which detracts from its overall usability. Moving forward, it will be crucial to monitor Mondo Robotics' efforts to improve Beni's obstacle avoidance technology. Currently priced at $599, the robot's value is questionable given its primary flaw. If Mondo can address these issues, Beni could become a more appealing option for users engaged in various activities, but until then, recommendations are limited.
Robot Cameras Obstacle Avoidance Consumer Robotics Video Technology
Noin Introduces GLOW Architecture for Instant Learning in Robotics
Noin has unveiled the GLOW architecture, a generative learning framework aimed at enhancing robot learning capabilities. This new technology allows robots to learn tasks instantly without the need for extensive data collection or predefined processes, addressing the challenges posed by dynamic real-world environments. GLOW's core innovation lies in its ability to enable robots to learn tasks through a single demonstration, transforming visual input and feedback into actionable tasks. The significance of GLOW is underscored by its potential to revolutionize how robots acquire skills, moving away from traditional methods that require separate strategies for each task. Instead, GLOW aims to equip robots with generalized capabilities that can be applied across various objects, environments, and tasks. This shift could lead to more efficient and adaptable robotic systems, as users will no longer need to break down their requirements into machine instructions. Future developments to watch include Noin's ongoing commitment to advancing the GLOW technology, which integrates visual understanding, spatial reasoning, task planning, and action generation within a unified model. The architecture has already shown promising results in various evaluations, indicating its effectiveness in physical scene understanding and task execution, paving the way for enhanced robotic intelligence and adaptability.
Robotics Generative Learning AI Embodied Intelligence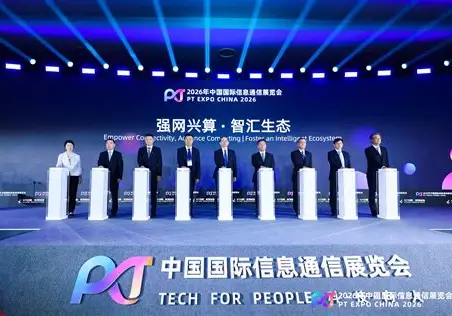
The Importance of a Comprehensive Network for Robotics: Insights from the 2026 Information Communication Expo
The 2026 China International Information Communication Expo highlighted the necessity of a comprehensive network for robotics, showcasing advancements in embodied intelligence. The expo featured technologies essential for robotic tasks, including perception, decision-making, motion control, and human-robot interaction, emphasizing the integration of these elements for effective operation. This focus on connectivity is crucial as robots must adapt to various environments, ensuring safety and efficiency in tasks ranging from industrial applications to healthcare. The expo demonstrated how robots can be integrated into smart factories and homes, where they must understand human needs and operate safely in shared spaces. The success of robotic systems relies not only on their ability to perform complex actions but also on their operational stability and cost-effectiveness. Looking ahead, the 2026 initiative for humanoid robots and embodied intelligence aims to enhance real-world training and application validation. The emphasis on reliable real-time control, stable connectivity, and effective data utilization will be key to advancing robotic capabilities and ensuring their successful deployment in diverse environments. No further timeline was disclosed at the time of publication.
Embodied Intelligence Robotics Technology Smart Factories Healthcare Robotics
Academician Zheng Nanning Discusses Embodied Intelligence Beyond Humanoid Robots
Academician Zheng Nanning, Director of the Artificial Intelligence and Robotics Institute at Xi'an Jiaotong University, published an article discussing the growth of embodied intelligence in the physical world. He emphasized that a key direction for artificial intelligence is enabling machines to not only process information but also to flexibly perform various tasks in dynamic environments. This includes precise operations on industrial production lines, autonomous navigation in complex terrains, and dynamic movements in exhibition settings. Zheng clarified that embodied intelligence is not synonymous with humanoid robots; rather, it focuses on whether intelligent systems can truly engage with real-world environments, forming a closed loop of perception, cognition, decision-making, action, and feedback. The evaluation of embodied intelligence should be based on its ability to solve real-world problems, not merely its physical form. He likened understanding embodied intelligence to an infant's process of learning about the world through interaction with their environment. To enable machines to act in the world, embodied intelligence requires various capabilities, including the formation of world models, multimodal representation, causal reasoning, and the integration of generation and action. The development of embodied intelligence relies on high-quality multimodal data and realistic simulation environments. Current limitations include the black box problem, computational constraints, and an immature industrial ecosystem. In sectors like industrial manufacturing, healthcare, and urban governance, intelligent systems are evolving from mere tools to proactive systems capable of continuous learning and adaptation.
Embodied Intelligence Artificial Intelligence Robotics Machine Learning
University of Washington Unveils 1-Gram Jumping Robot with Accurate Height Control
Engineers at the University of Washington have developed DirectHop, a 1-gram jumping robot capable of precise height control, enabling it to jump over standard stair steps. This innovation leverages a miniature motor and three folding legs, allowing the robot to perform multiple jumps with centimeter-level accuracy. The significance of DirectHop lies in its potential applications, which include detecting gas leaks in refineries, monitoring water and fertilizer usage on farms, and even exploring other planets. Unlike traditional jumping robots that rely on springs, DirectHop's design eliminates the need for complex mechanical components, making it easier to control jump distances and perform multiple jumps. Looking ahead, the team is exploring enhancements such as onboard solar cells, battery power, and navigation capabilities through cameras and sensors. Their ultimate goal is to achieve full autonomy, allowing DirectHop to navigate stairs independently by calculating jump heights and adjusting its position accordingly. No further timeline was disclosed at the time of publication.
Jumping Robots Micro Robotics Robotics Engineering Automation Technology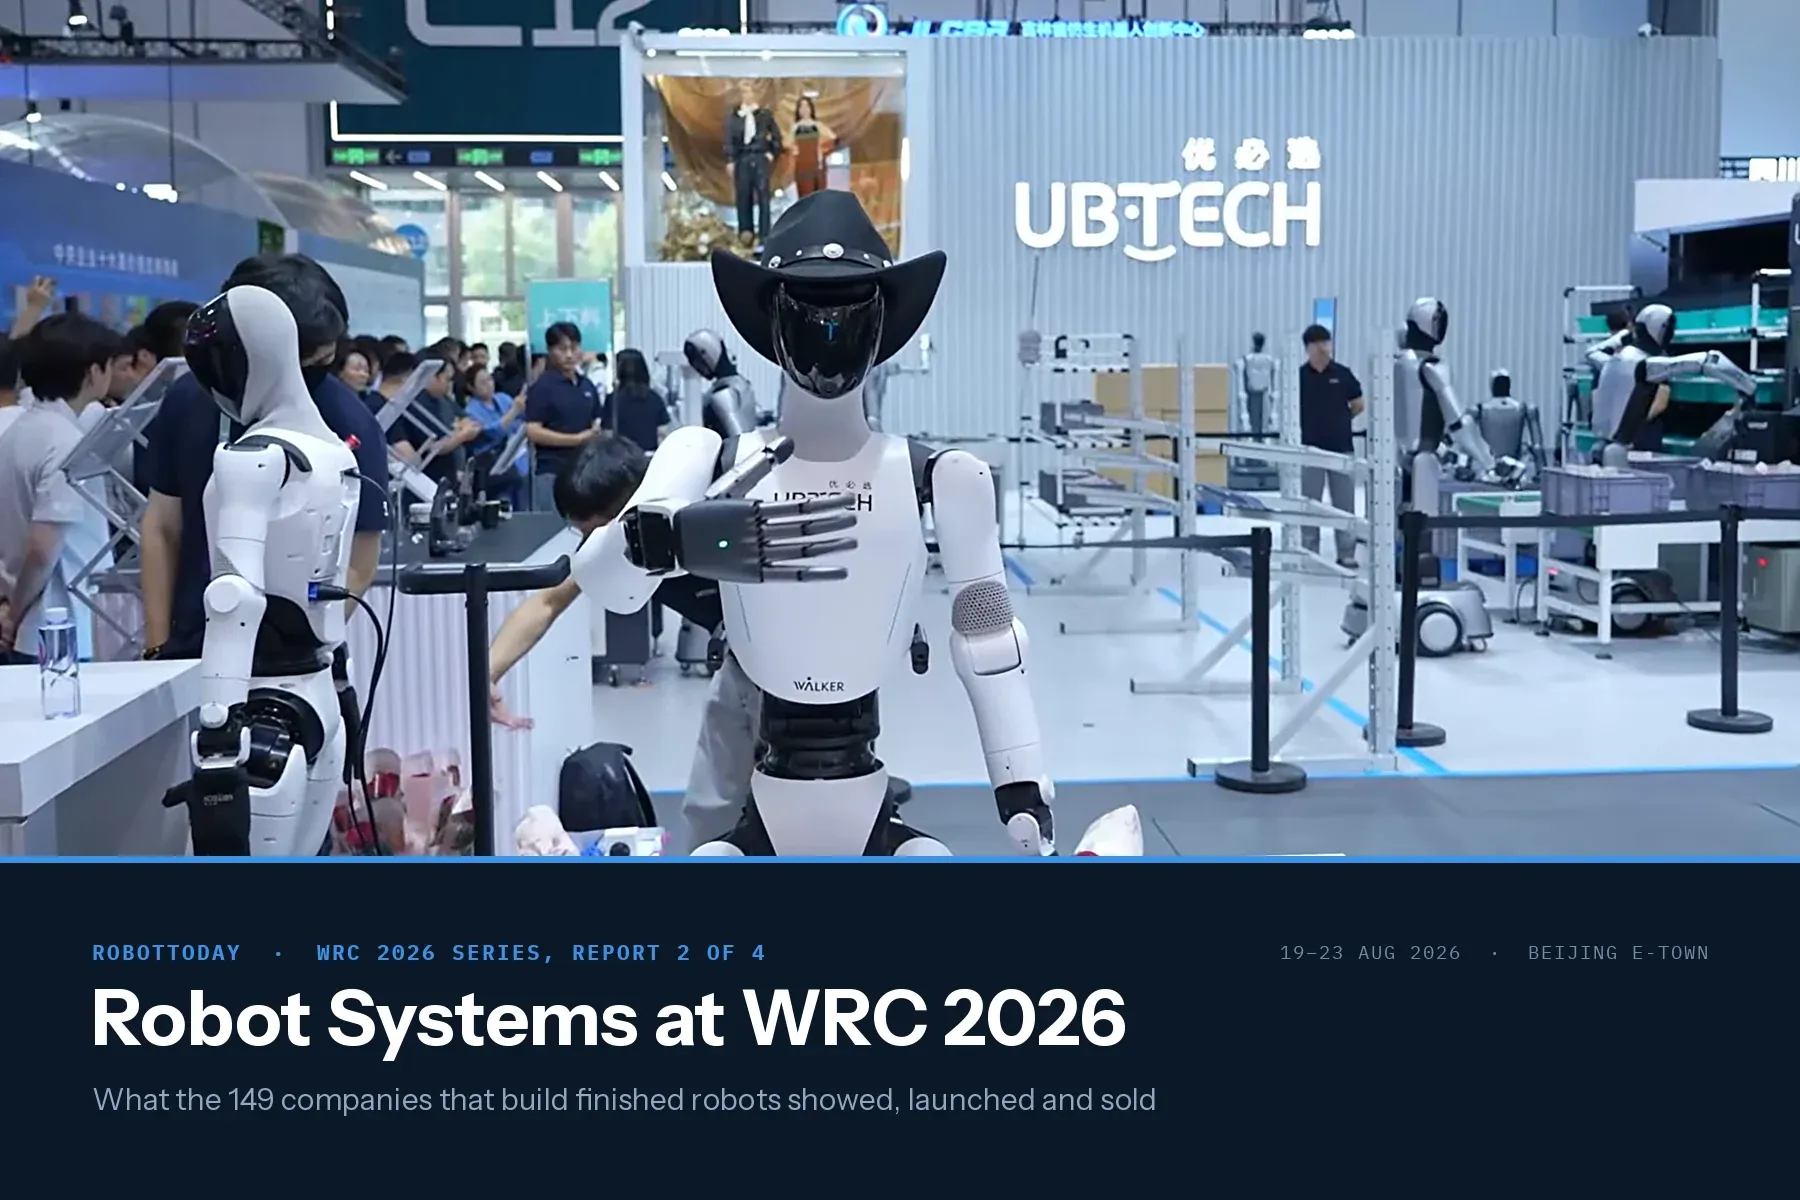
WRC 2026 Robot Systems: 149 Companies That Build Robots
149 of the 248 classified WRC 2026 exhibitors build finished robots. 93 build humanoid or legged machines. The audited humanoid sales number is one unit.
Springer Handbook of Robotics B. Siciliano & O. Khatib (eds.) — RSF Top 10 Robot Education Textbooks · No. 10
Eighty-plus chapters, 2,300 pages, nobody reads it cover to cover. It ranks for one reason: when a fault crosses domains, this is the reference of record.
Autonomous Mobile Robots Siegwart, Nourbakhsh & Scaramuzza — RSF Top 10 Robot Education Textbooks · No. 3
AMR and AGV fleets are the biggest robot service market. Siegwart decodes the vendor manual: odometry, localization, cost maps.
Robotics, Vision and Control Peter Corke — RSF Top 10 Robot Education Textbooks · No. 5
Most books you read; Corke's you run. Every concept ships as executable Python via the open Robotics Toolbox. The code softens the maths.
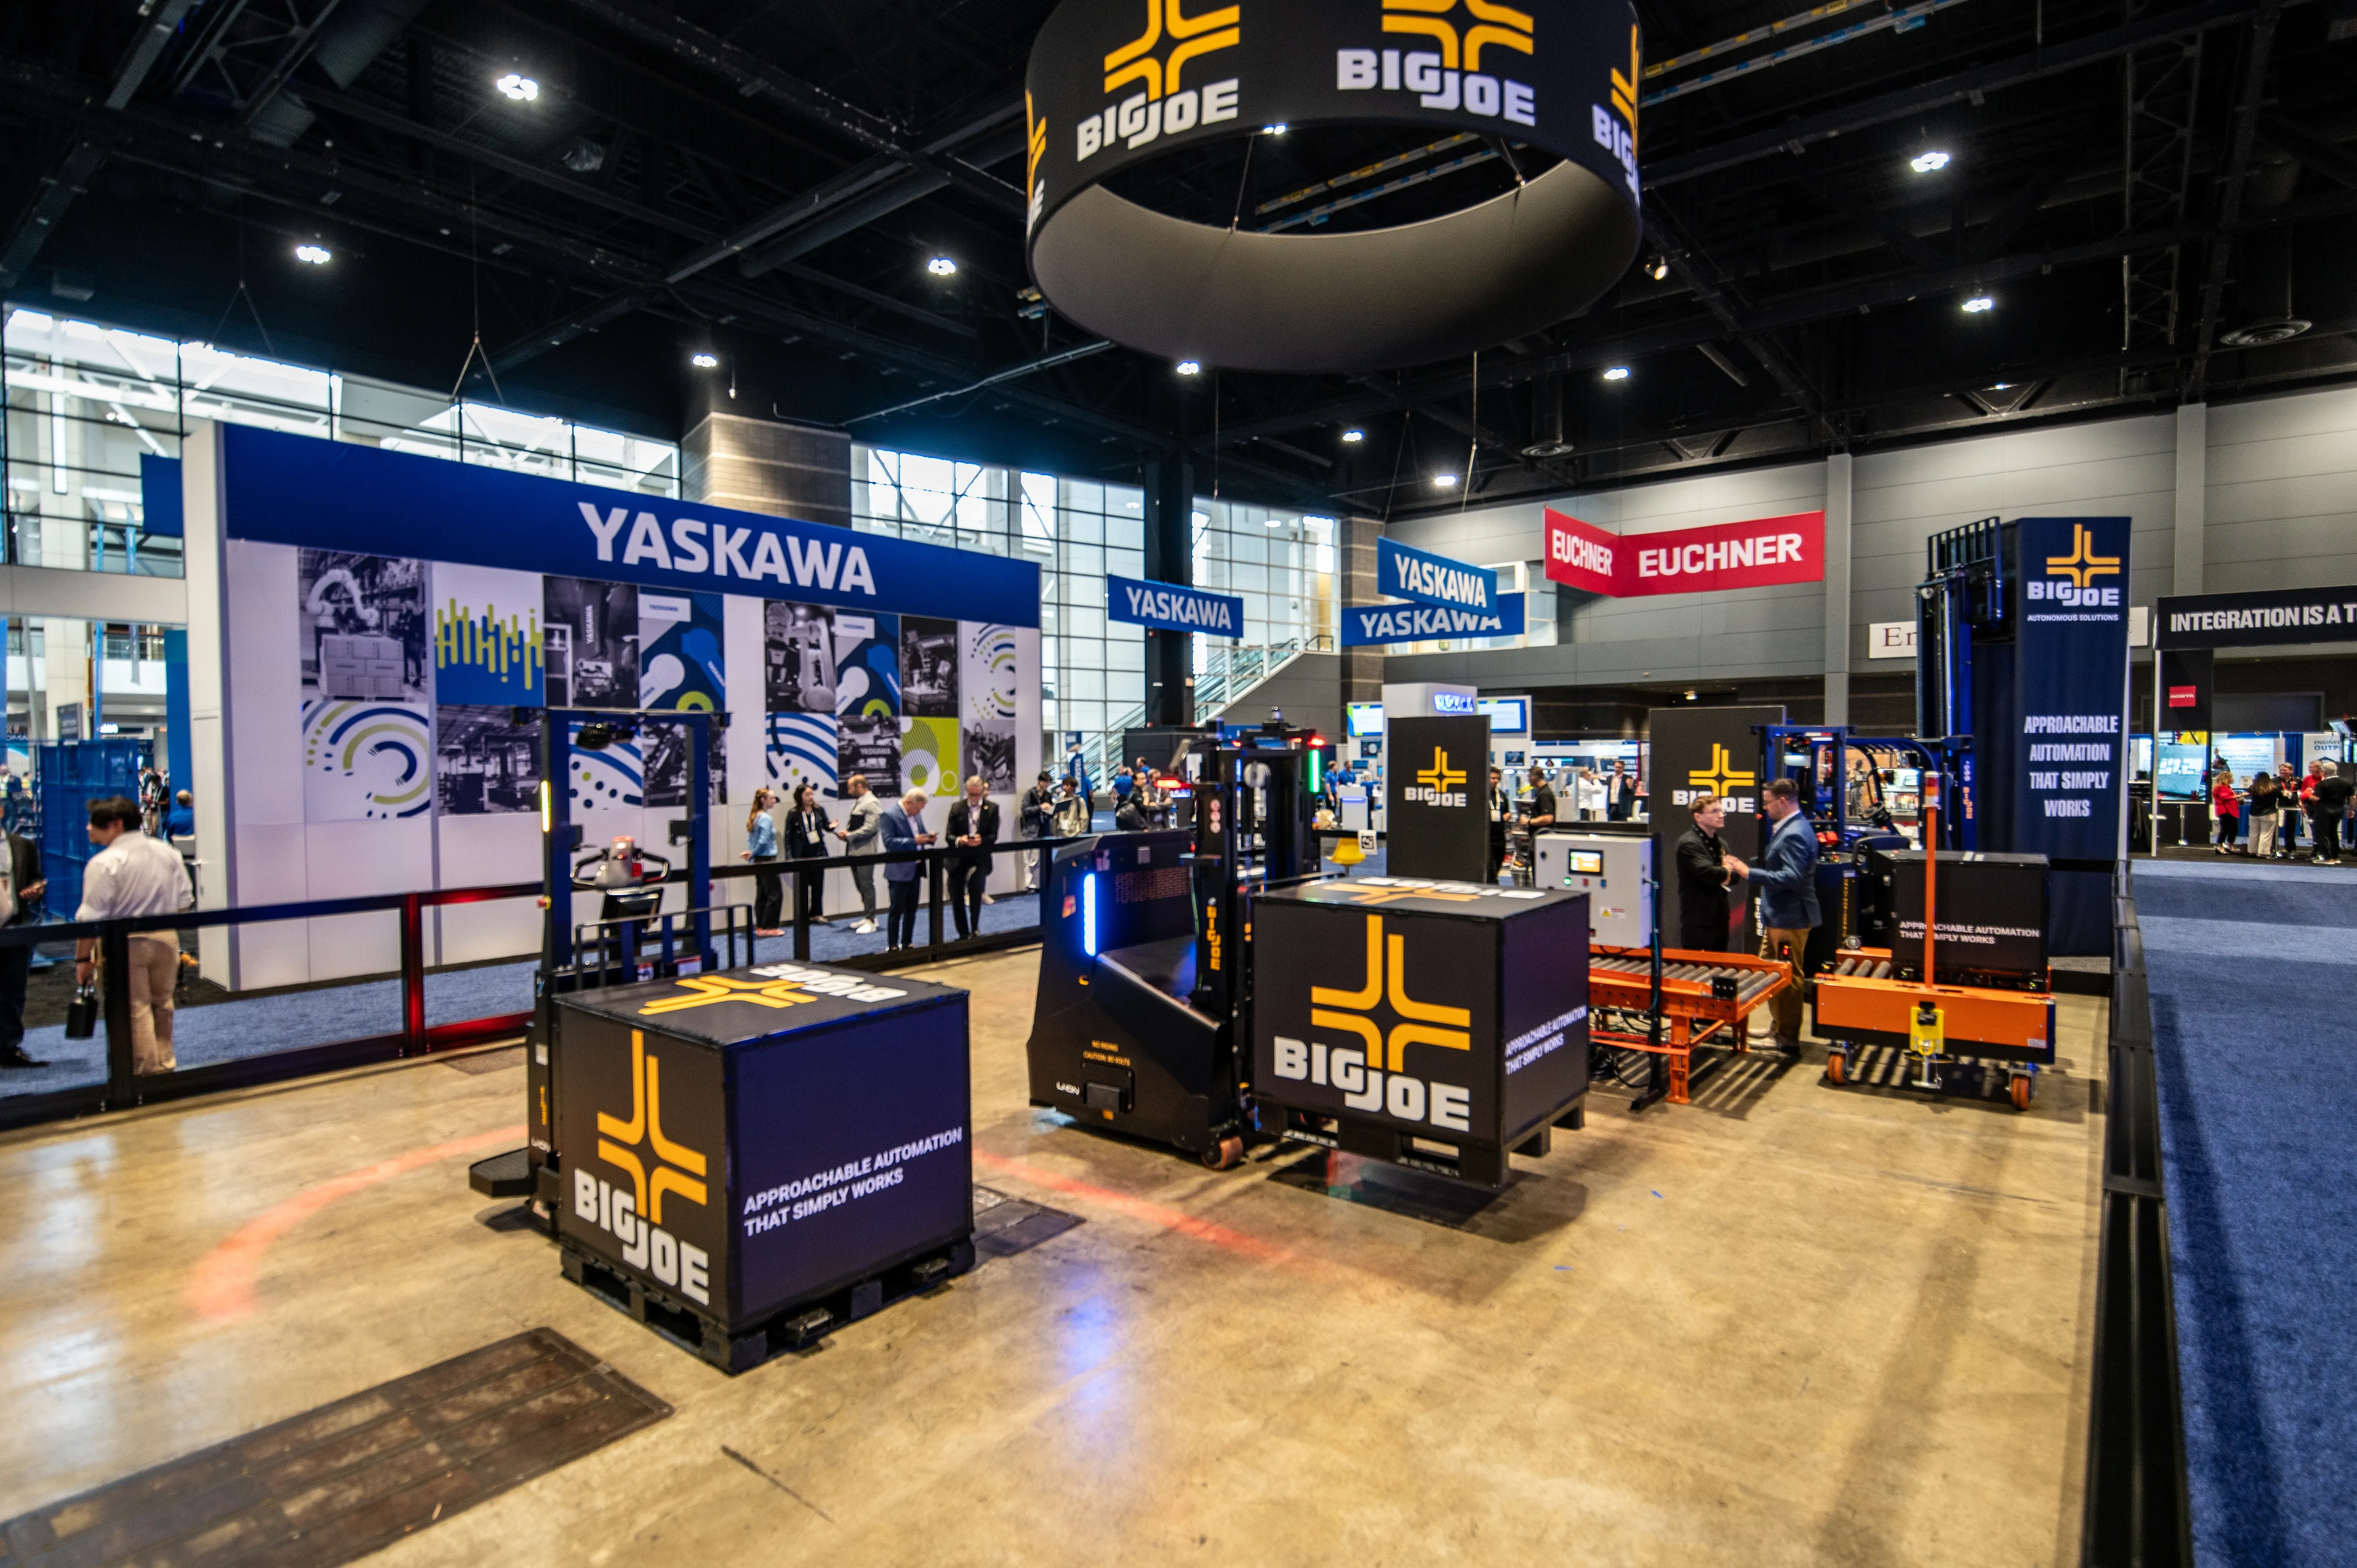
Big Joe's Four-Product AMR Push at Automate 2026: What It Reveals About the North American Warehouse Automation Market
RobotToday analyzes Big Joe's four new autonomous vehicles launched at Automate 2026 — AP44, ASC40, ATC100, ACV40 — in the context of North America's warehouse labor shortage and AMR market growth.
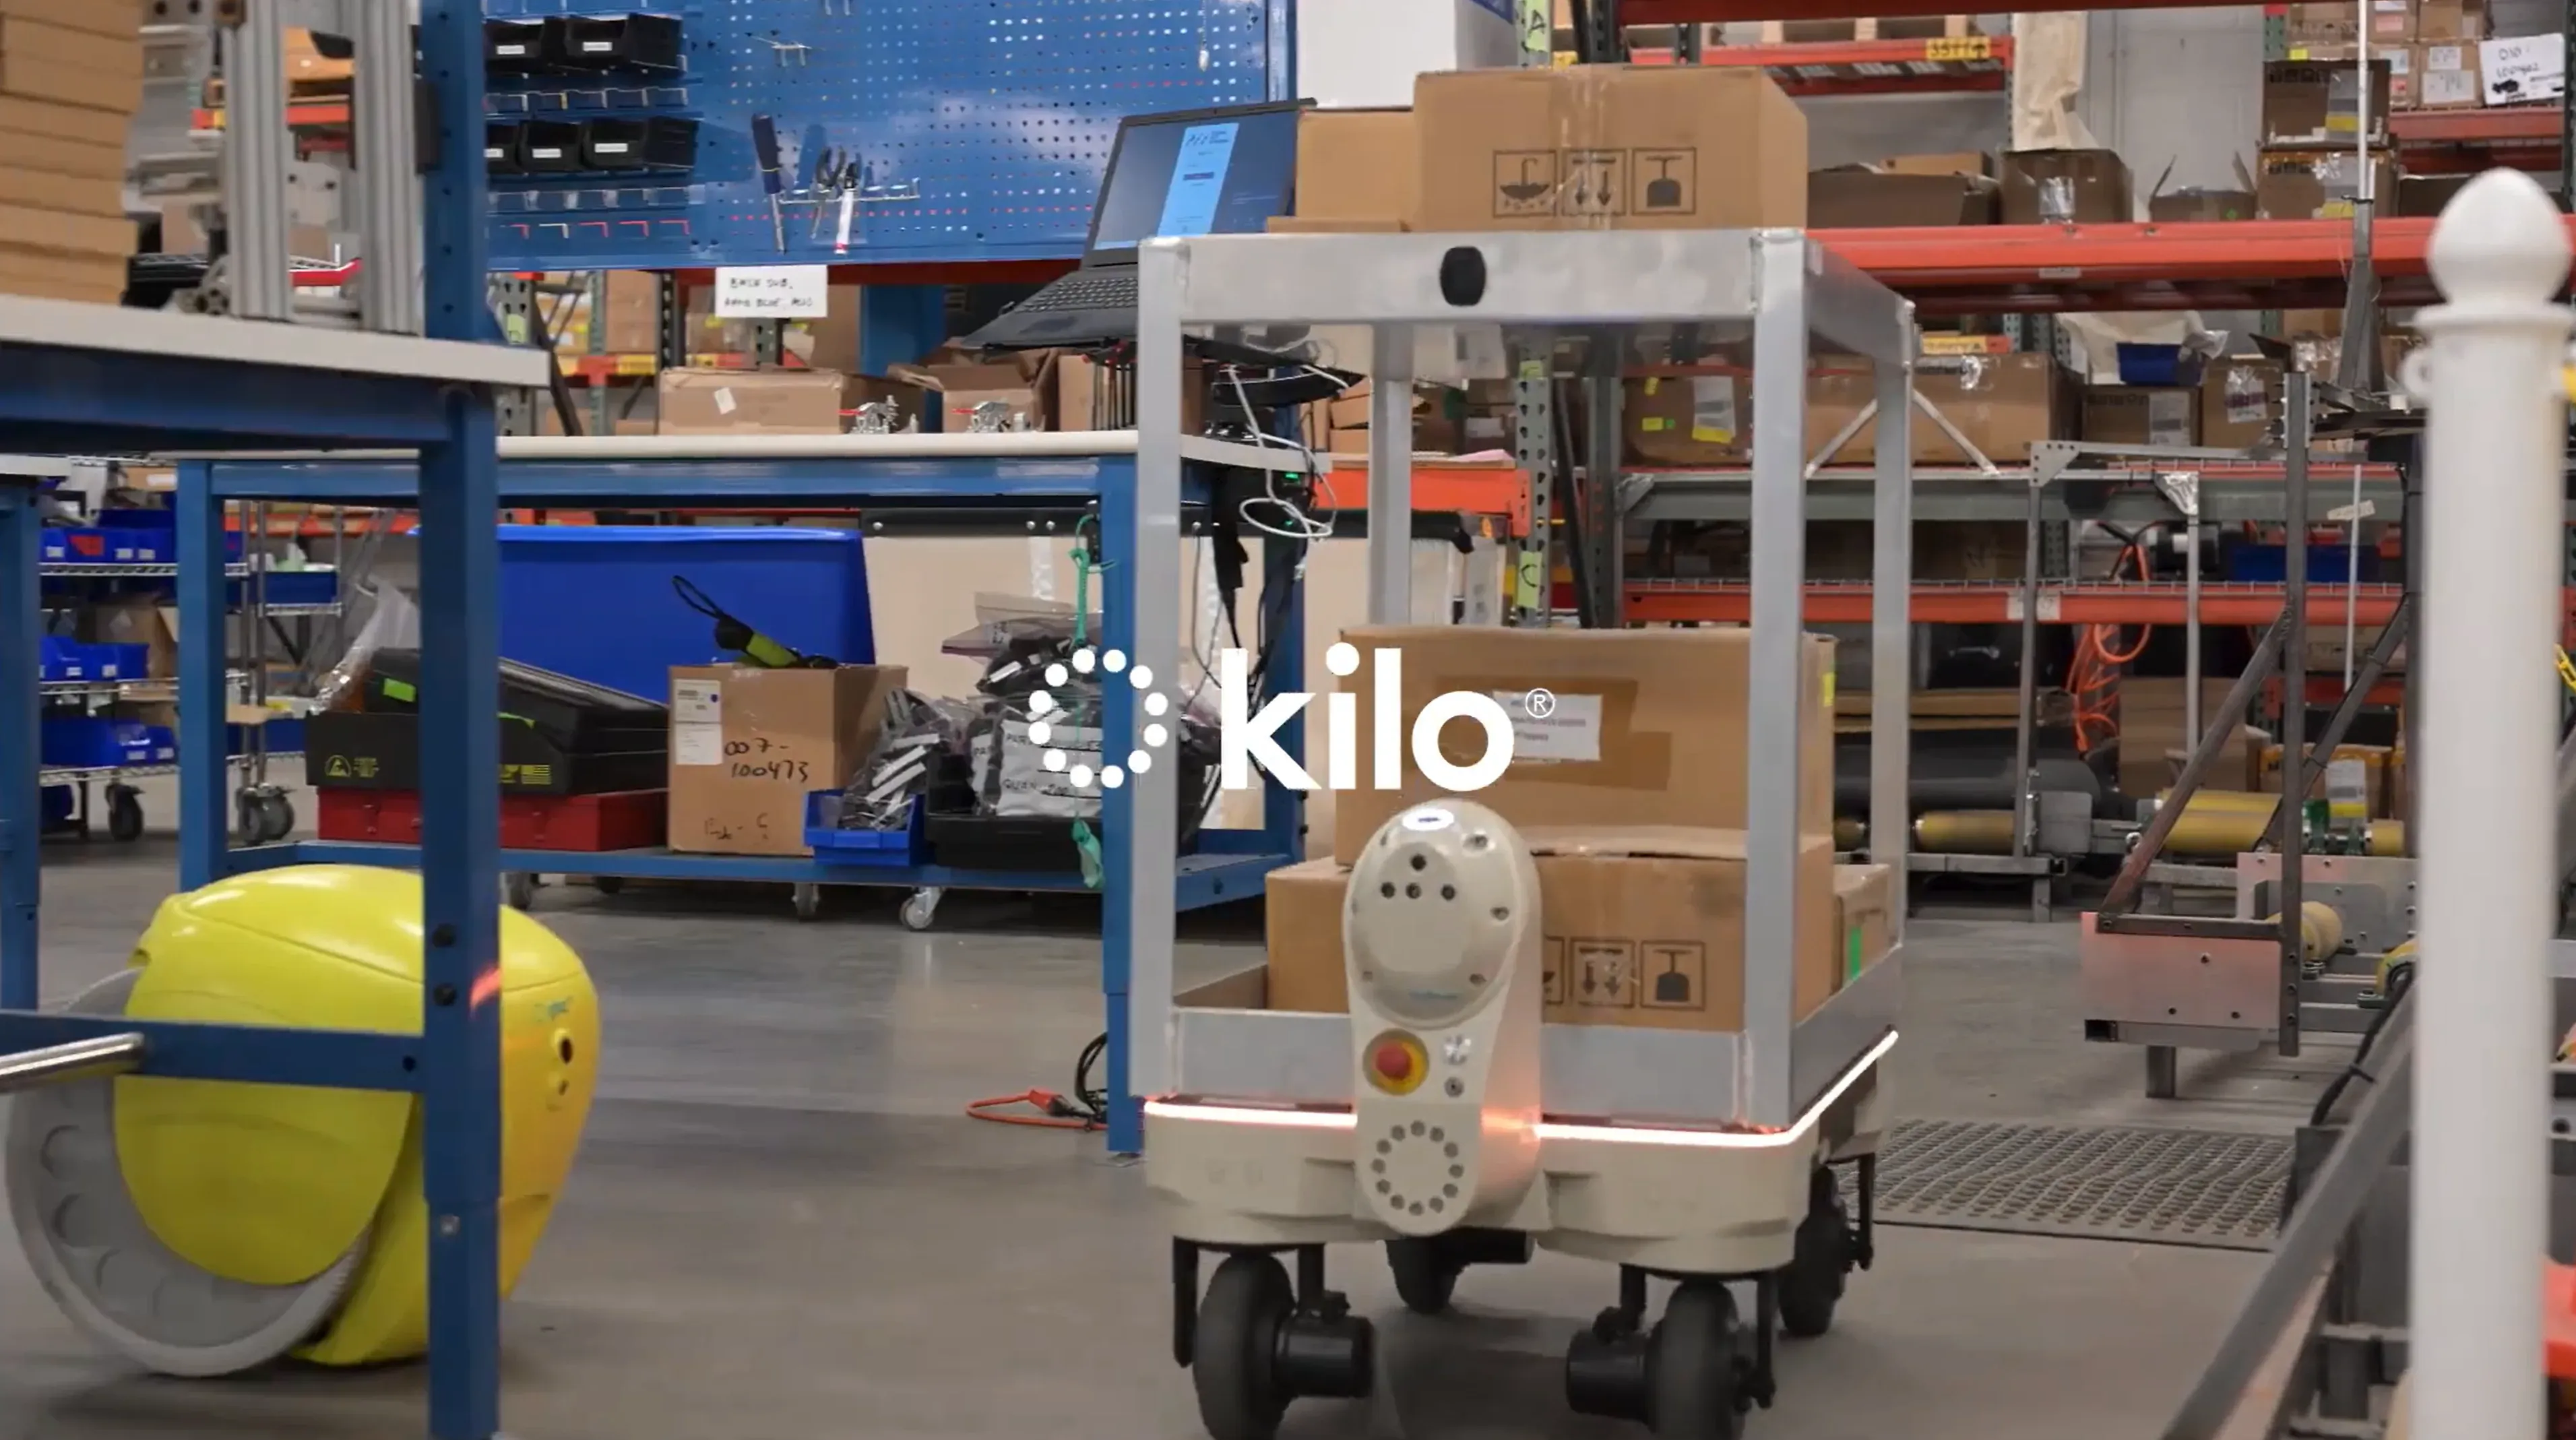
Piaggio Fast Forward Brings kilo® Autonomous Mobile Robot to Automate 2026
Piaggio Fast Forward showcases kilo®, an infrastructure-free collaborative AMR (300 lb payload, 360° LiDAR), at Automate 2026 booth #17054.
When a Materials Giant Meets Robotics: Covestro at Automate 2026
At Automate 2026, Covestro brought Makrolon, Bayblend, Baysafe BEF and Vulkollan to robotics — tackling weight, heat, sensing and sustainability for humanoids and AGV/AMRs.
Vietnam Robotics Industry Report 2026
Comprehensive analysis of Vietnam's robotics industry: market size, industrial policy, key companies (Vingroup, Apicoo, Phenikaa-X), geopolitical dynamics, and 2030 growth opportunities.
FABTECH 2026 | Oct 21–23, Las Vegas | Welding, Fabrication & Manufacturing Robotics
FABTECH 2026 returns to Las Vegas, October 21–23, for North America's largest metal forming, fabricating, welding, and finishing event. 31,000+ attendees, 1,500+ exhibitors. Key showcase for industrial robot welding and automation applications.
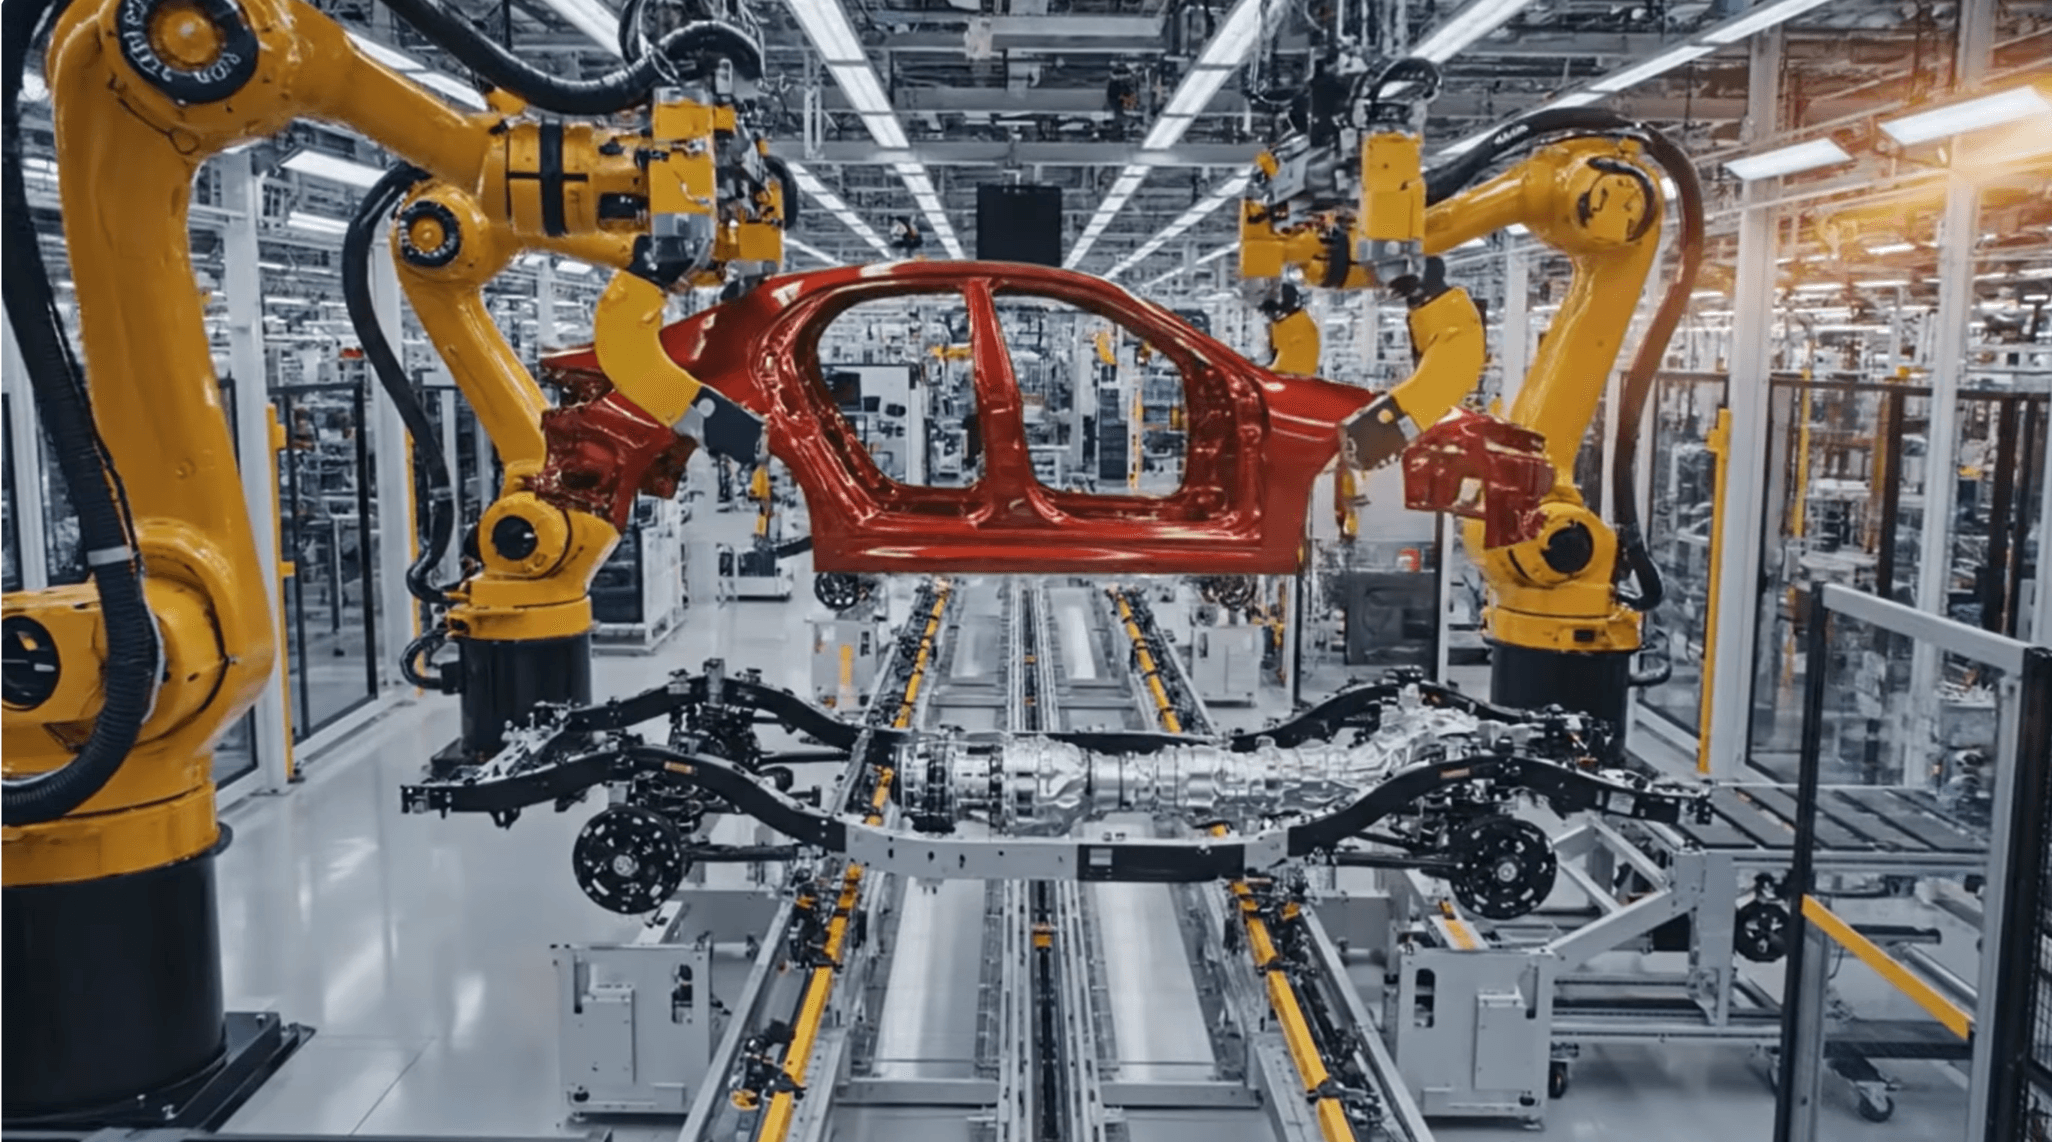
Global Industrial Robots Market 2025: Market Sizing, Geographic Trends & Case Studies (Chapter 1)
An in-depth analysis of the global industrial robotics market for 2025 — Chapter 1 of a 9-chapter bilingual research series. Covers market sizing consensus ($17.5–22 B USD), geographic deployment landscape, four real-world case studies (Ford, Volkswagen, BYD, Toyota), and 2025–2030 installation forecasts, with bilingual English-Chinese analysis for executives and investors.


