

Butlr
"Leading AI Platform for Intelligent Spaces"
Privacy-first AI people-sensing platform using thermal sensors to deliver anonymous occupancy and activity data for smart buildings.
Contact Butlr
WEBSITE
https://butlr.ioHEADQUARTERS
United States

Company Facts
Founded
2019
Primary Role
Manufacturer
Company Size
-
Primary Region
North America
Annual Sales
-
Funding Stage
-
Funding Total
-
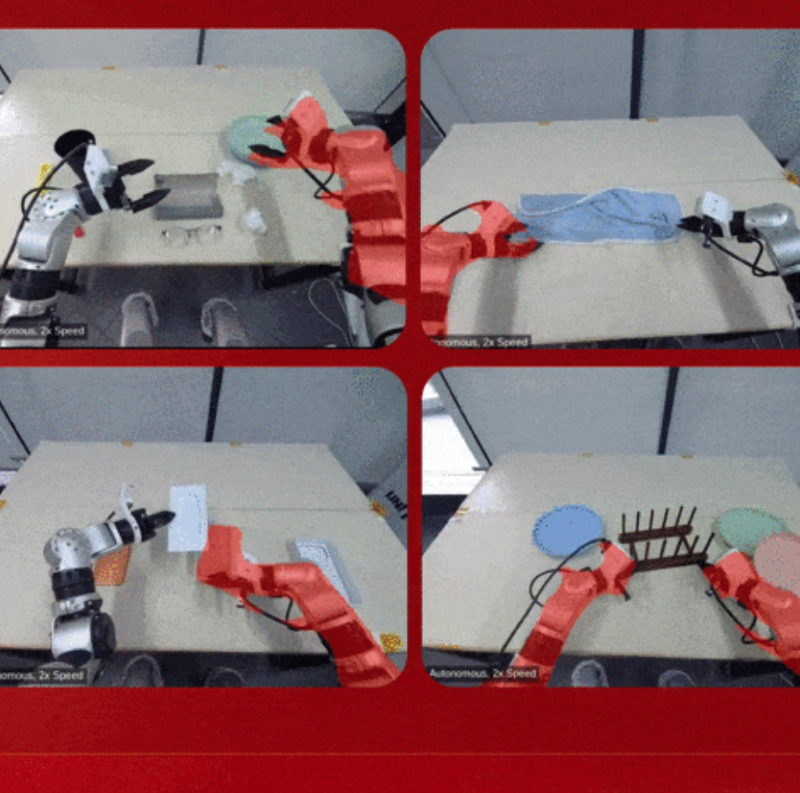
Yushu Launches G1+ Robot Featuring Advanced Perception and Motion Enhancements
Yushu has unveiled the G1+ robot, which includes significant hardware upgrades such as increased neck degrees of freedom, an enhanced vision system with dual cameras and 3D LiDAR, and improved motor torque. The robot's far-field audio system has also been upgraded to support sound source localization and noise reduction, with a total price of 95,000 yuan. This launch is crucial as it showcases Yushu's commitment to advancing humanoid robotics technology. The G1+ robot is part of a series of announcements, including the introduction of the UnifoLM-WLA-1.0 model, which integrates world modeling, language understanding, and action generation. These developments highlight the company's focus on real-time decision-making capabilities in robotics. Looking ahead, Yushu plans to open-source the UnifoLM-WMA-0 model in September 2025, which will predict changes in the environment following robotic actions. Additionally, the UnifoLM-VLA-0 model is set for release in January 2026, further enhancing the robot's operational capabilities. No further timeline was disclosed at the time of publication.
Humanoid Robots AI Robotics Machine Learning
Nvidia Launches Jetson Orin Nano 2 for Robotics and Edge AI Applications
Nvidia has introduced the Jetson Orin Nano 2, a new robotics computer designed for entry-level edge AI applications. This innovative computer aims to empower millions of developers globally to create robots, drones for delivery and inspection, and vision AI systems tailored for advanced physical AI tasks. The significance of the Jetson Orin Nano 2 lies in its enhanced performance and energy efficiency. It offers double the inference performance of its predecessor while consuming 40% less power, making it an attractive option for developers seeking compact and efficient robotics solutions. With over 3 million developers utilizing the Nvidia robotics stack, early adopters like Cognex, Doosan Bobcat, and Matic are already exploring its capabilities. Looking ahead, Nvidia's Jetson Orin Nano 2 is set to redefine entry-level edge AI by providing frontier-class generative AI performance to a broader audience. As AI models become more efficient, the potential for autonomous edge devices to perform real-time tasks will expand significantly. No further timeline was disclosed at the time of publication.
Computing News Robotics ai computing Autonomous robots drones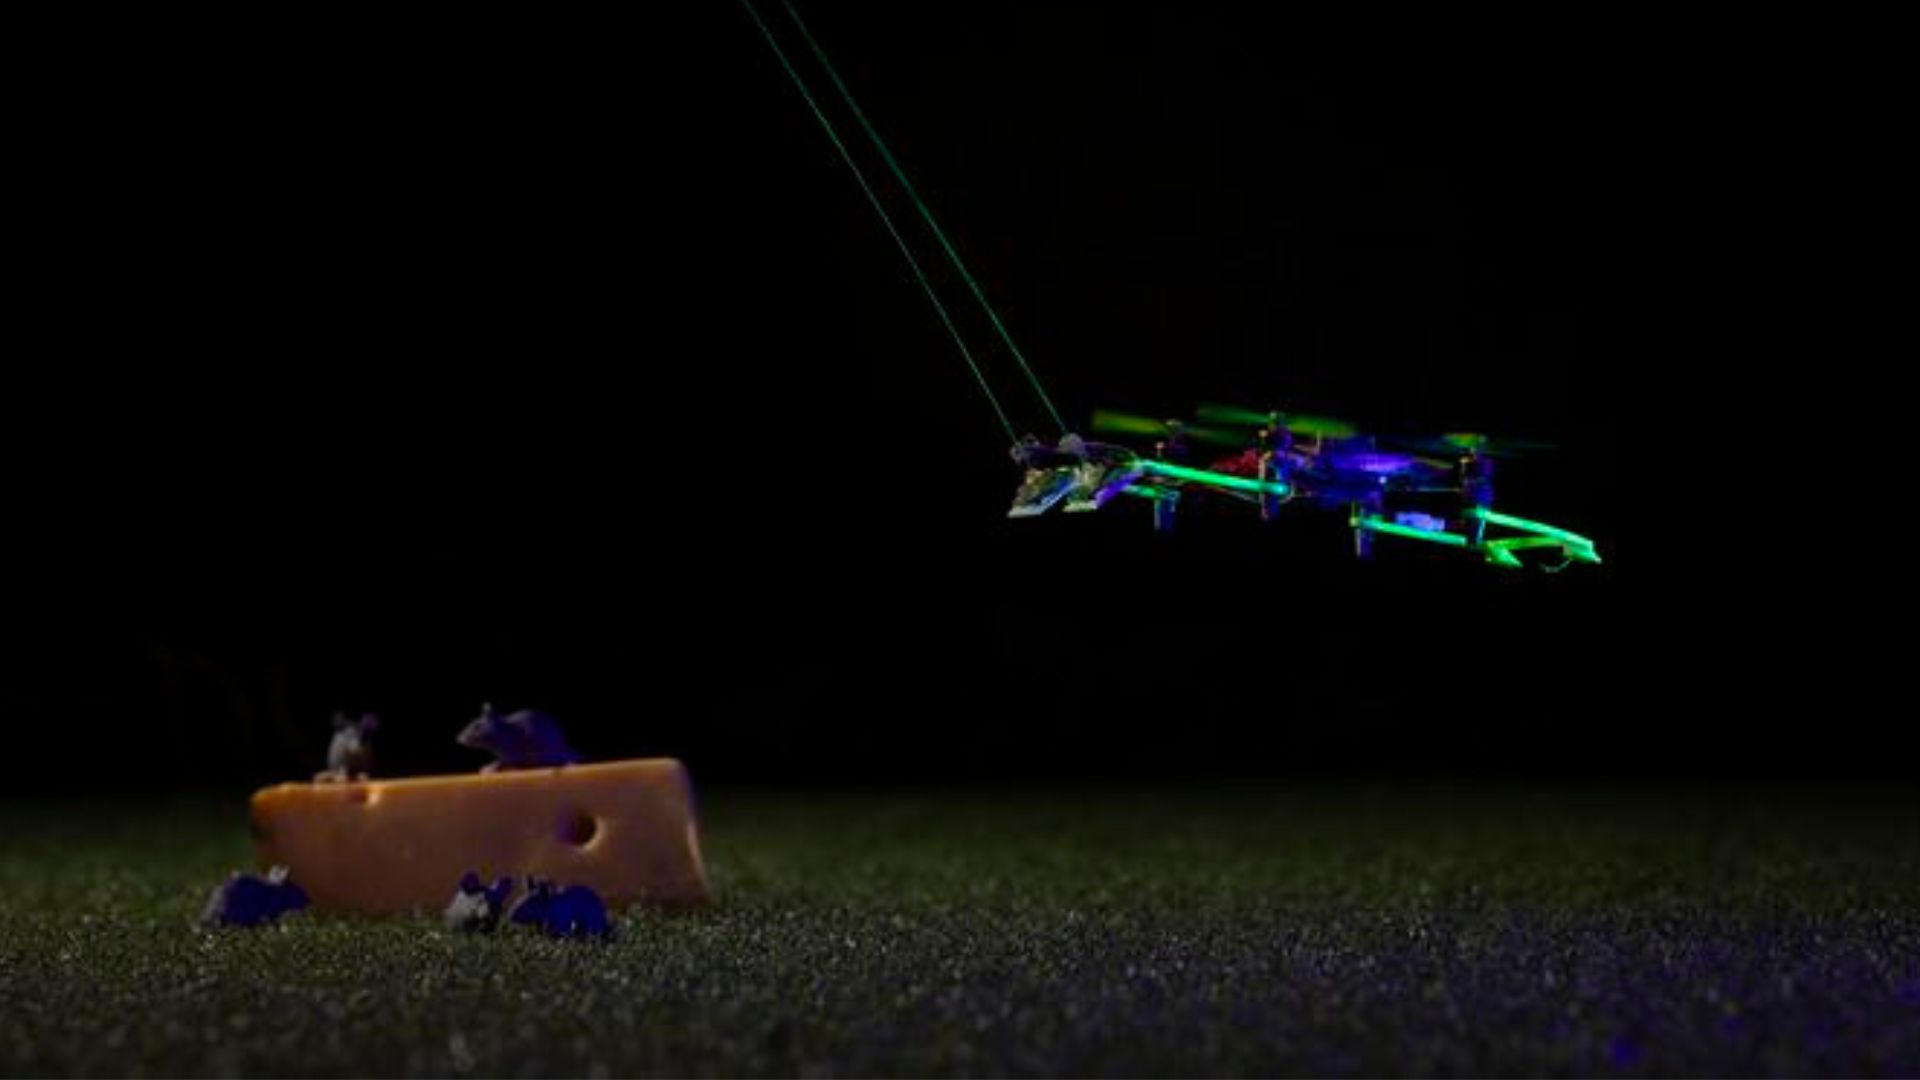
New Whisker-Based Technology Enables Tiny Drones to Navigate Without Vision
Researchers at Delft University of Technology have developed a whisker-based tactile framework that allows tiny drones to navigate complex environments without relying on visual input. Inspired by the natural whiskers of rodents, this technology equips drones with artificial whiskers that provide real-time feedback as they interact with their surroundings. This innovation addresses a significant challenge in aerial robotics, particularly for micro-drones weighing under 100 grams, which cannot support heavy LiDAR systems. The whisker system enables these drones to operate effectively in low-visibility conditions, such as dust or darkness, where traditional cameras fail. Moving forward, the focus will be on refining this tactile navigation system and exploring its applications in various environments. No further timeline was disclosed at the time of publication.
AI and Robotics
Delft University Develops Whisker-Based Sensors for Drones to Navigate in Darkness
Researchers at Delft University of Technology have created a lightweight tactile sensor inspired by animal whiskers, enabling tiny autonomous drones to navigate in low-visibility environments. This innovation allows drones to explore areas filled with darkness, dust, or smoke without relying on heavy sensors. The ability for drones to navigate through challenging environments is significant for various applications, including search and rescue operations, environmental monitoring, and industrial inspections. By mimicking the sensory capabilities of rats and mice, these drones can effectively maneuver in tight spaces and complex terrains. Future developments in this technology could enhance the operational capabilities of drones in various sectors. As research progresses, it will be important to monitor advancements in sensor technology and potential applications in real-world scenarios. No further timeline was disclosed at the time of publication.
Robotics
CT-Unite Team Secures ACM MM 2026 Championship with Innovative Brain-Inspired Model
The CT-Unite team has won the ACM MM 2026 championship, marking their second consecutive victory in international AI competitions. This time, they achieved success with a brain-inspired, cross-modal cognitive neural network designed for robotics, which compresses a 100 TFLOPS model to operate at 38.8 TFLOPS using distributed computing technology. This achievement is significant as it addresses the critical challenge of enabling embodied intelligent robots to transition from perception to cognition. The EgoLink challenge, part of the ACM MM conference, focuses on understanding social relationships and event logic from a first-person perspective, showcasing the highest level of AI capabilities in video social interaction and environmental reasoning. Looking ahead, the integration of the CT-2001A IDPU architecture and the CT-HS01 4D spectral sensor represents a major advancement in robotic cognition. The team's approach aligns multi-source information at the feature and neuron levels, allowing robots to infer social dynamics and emotional causality, thus achieving human-like cognitive abilities. No further timeline was disclosed at the time of publication.
Cognitive Robotics Neural Networks Multimodal Integration AI Technology
Treble Technologies Raises $18 Million to Advance Robots' Sound Perception Capabilities
Treble Technologies has secured $18 million in Series A-2 funding, led by Paladin Capital Group, to enhance auditory capabilities in robots. Founded in 2020 in Reykjavik, Iceland, Treble focuses on transforming sound propagation into simulative data, addressing limitations faced by AI models in complex acoustic environments. The significance of Treble's technology lies in its ability to model sound acoustics based on physical principles, allowing developers to evaluate product performance before creating physical prototypes. This approach differs from traditional audio processing methods, which primarily focus on signal-level enhancements. Treble's simulations can replicate real-world acoustic conditions, providing valuable insights for companies like Amazon and Logitech, who are already testing audio products on Treble's platform. Looking ahead, Treble aims to expand its presence in the U.S. market while increasing investments in physical AI. As sound becomes a critical interface for intelligent machines, the company’s acoustic simulation capabilities could bridge the gap in robotic perception, enabling robots to interpret auditory information alongside visual data. No further timeline was disclosed at the time of publication.
Acoustic Modeling Robotics AI Sound Simulation
Aetina Launches AIE-KT78 and AIE-KT68 for Advanced AI in Robotics Control
Aetina Corporation has announced the general availability of its DeviceEdge AIE-KT78 and AIE-KT68 edge AI systems. These systems support local multimodal generative AI, LLM, VLM, and VLA model execution, enabling seamless integration with high-resolution sensors, motors, joints, and actuators through high-bandwidth interfaces and EtherCAT control. The introduction of these systems is significant as they are powered by NVIDIA Jetson Thor and utilize the NVIDIA Blackwell architecture, providing high-performance AI compute and deterministic industrial control. This makes them ideal for Collaborative Robots (Cobots), humanoid robots, and next-generation autonomous machines, enhancing their ability to perceive, reason, decide, and act in real-world environments. Looking ahead, the focus will be on how developers leverage the capabilities of the AIE-KT78 and AIE-KT68 systems to create more sophisticated robotic applications. No further timeline was disclosed at the time of publication.
Arm Launches Total Design for Physical AI, Uniting Over 80 Developers in Robotics
Arm Holdings PLC has introduced Arm Total Design for Physical AI, a program that unites over 80 companies involved in the physical AI technology stack. This initiative aims to foster collaboration among participants in the physical AI space, addressing challenges in perception, AI, real-time control, and safety. The significance of this program lies in its potential to streamline the fragmented robotics industry, which often sees companies struggling to collaborate effectively. Dermot O’Driscoll, vice president at Arm, emphasized the need for a cohesive ecosystem where technology and ideas can be shared, enhancing the development of interoperable systems. Looking ahead, Arm's Robotics Capability Framework will categorize robotic systems into six levels of sophistication, from basic reactive robots to advanced systems that learn and self-optimize. Arm is seeking industry feedback to refine these levels, indicating a commitment to evolving the understanding and capabilities of robotics in the market.
Artificial Intelligence Artificial Intelligence / Cognition Automotive Design / Development Development Tools / SDKs / Libraries Markets / Industries
Enhancing the Navy's Kill Chain with Remote Mine Hunting Using AI and Sonar
The Navy is advancing its find, fix, and finish kill chain through the implementation of remote mine hunting technologies. This innovative approach leverages autonomy, artificial intelligence, and advanced sonar systems to effectively locate and neutralize underwater mines, significantly improving operational efficiency. The integration of these technologies is crucial for enhancing maritime safety and operational readiness. By utilizing remote mine hunting, the Navy can clear waterways more quickly and with reduced risk to personnel, addressing the growing need for effective mine countermeasures in complex environments. Looking ahead, the continued development and deployment of remote mine hunting capabilities will be essential for maintaining naval superiority. No further timeline was disclosed at the time of publication.
Naval Warfare Sponsored Post Navy networks Presented by Thales SAS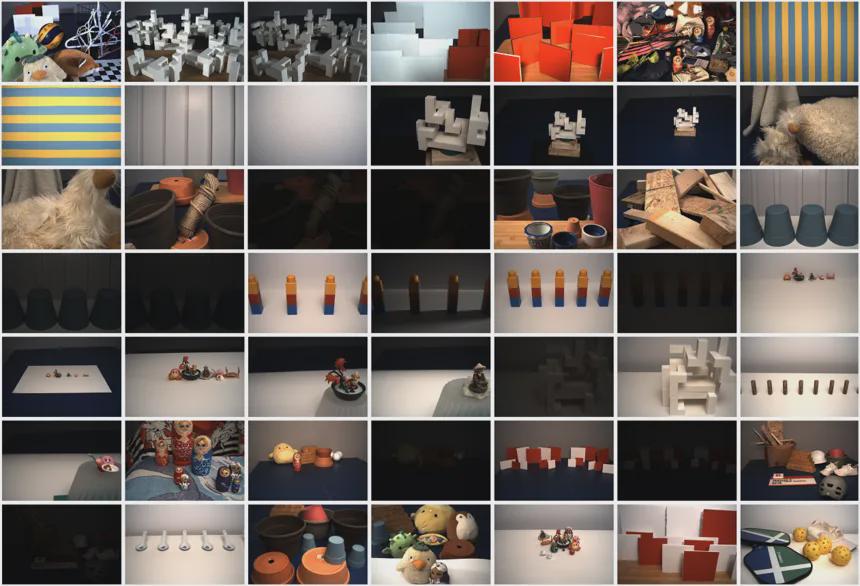
York University Develops CBS Algorithm to Enhance Humanoid Robot Depth Perception
Researchers from York University have introduced the Convergent Binocular Stereo (CBS) algorithm to improve depth perception in humanoid robots. This innovative approach utilizes the movement of the robot's eyes, allowing them to converge on a target while calculating depth based on camera orientation and disparities in the images. This method significantly outperforms traditional depth learning techniques, especially in complex visual scenarios. The advancement is crucial as humanoid robots increasingly rely on sophisticated vision systems to navigate and interact with their environments. By integrating eye movement into depth calculations, the CBS algorithm addresses a long-standing challenge in robotic vision, enhancing the robots' ability to perceive three-dimensional spaces accurately. Looking ahead, the implementation of the CBS algorithm could lead to more advanced humanoid robots capable of better depth perception and spatial awareness. No further timeline was disclosed at the time of publication.
Humanoid Robots Vision Systems Depth Perception Robotics Research
China’s Dexterous Hand Industry, 2026 Part 1 — The Demand Picture
MIR Databank puts China dexterous hand shipments above 30,000 units in 2026, yet only 3.5% of 2025 demand came from factory production. Part 1 of 3.
China’s Dexterous Hand Industry, 2026 Part 2 — The Technology
Linkage, tendon, direct drive or hybrid — and why hardware is converging while the DL1–DL5 manipulation scale decides who wins. Part 2 of 3.
ROBOTTODAY WEEKLY BRIEFING August 24 – 28, 2026
This week in robotics: XPeng's Dogotix raises over $900 million at a $6.3 billion valuation, Unitree's post-IPO slump revives bubble talk, Beijing's World Humanoid Robot Games close with a shift to real-world tasks, and Teradyne sues JAKA at Europe's Unified Patent Court. August 24–28, 2026.
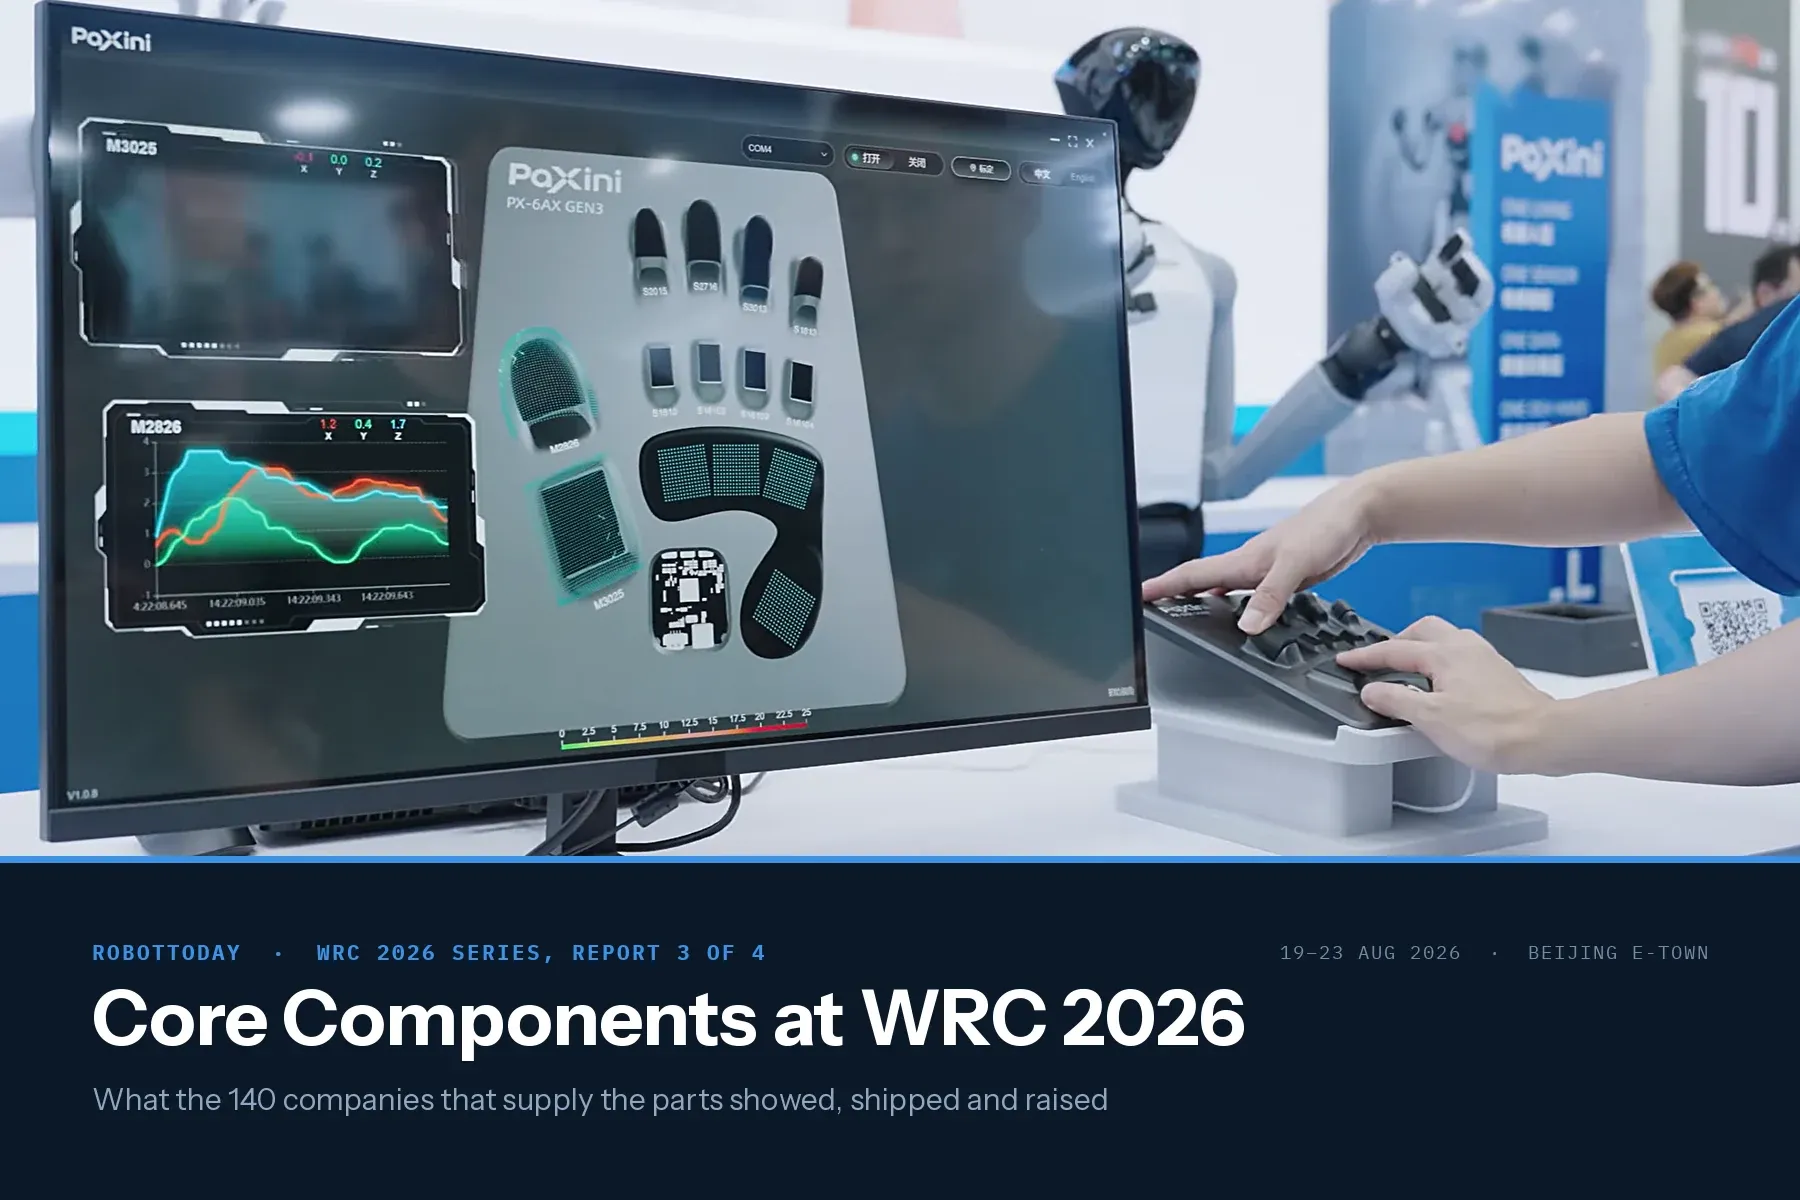
WRC 2026 Core Components: 137 Robot Parts Suppliers
The third report in the WRC 2026 series. Report 1 mapped all 248 exhibitors by category and Report 2 covered the 139 that build finished robots. This one covers the 137 that build what goes inside them.
WRC 2026 Exhibitor Map: 248 Robotics Companies Mapped
We classified 248 WRC 2026 exhibitors with the RobotToday taxonomy. Motion & Actuation leads at 75 companies, Humanoid at 72, and compute stays thin at 12. (Modified 2026-08-27)
Handbook of Marine Craft Hydrodynamics and Motion Control Thor I. Fossen — RSF Specialist Shelf · Book S1 of 6
Added mass, wave loading, DVL navigation: the marine GNC reference for USV, ROV and AUV service engineers. The hardest book on the RSF list, 5/5.
Small Unmanned Aircraft: Theory and Practice Beard & McLain — RSF Specialist Shelf · Book S2 of 6
Beard & McLain derive the fixed-wing autopilot the RSF Top 10 never does: successive loop closure on roll, pitch, altitude and airspeed. 4/5.
Reinforcement Learning: An Introduction Richard S. Sutton & Andrew G. Barto — RSF Specialist Shelf · Book S5 of 6
“It's the AI” will not satisfy an OEM support call. Sutton & Barto turn that into something a service engineer can investigate. Free PDF, Part I 4/5.
Planning Algorithms Steven M. LaValle — RSF Specialist Shelf · Book S4 of 6
The reference that treats planning as a subject in its own right: configuration space, sampling-based methods, RRT. Free online, dual difficulty 4/5-2/5.
Underactuated Robotics Russ Tedrake — RSF Specialist Shelf · Book S3 of 6
Legged robots fall over for control reasons, not mechanical ones. Tedrake's free MIT 6.832 notes explain why, and what a controller must do about it.


