

EZ Automation Systems LLC
Jacksonville, FL automation integrator founded 2005 specialising in machine vision, AI inspection, 3D vision, and robotics for manufacturing and logistics.
Contact EZ Automation Systems LLC
WEBSITE
https://www.ezsystemsllc.com/PHONE
+1 844-397-9783HEADQUARTERS
United States

Company Facts
Founded
2005
Primary Role
System Integrator
Company Size
-
Primary Region
North America
Annual Sales
-
Funding Stage
-
Funding Total
-
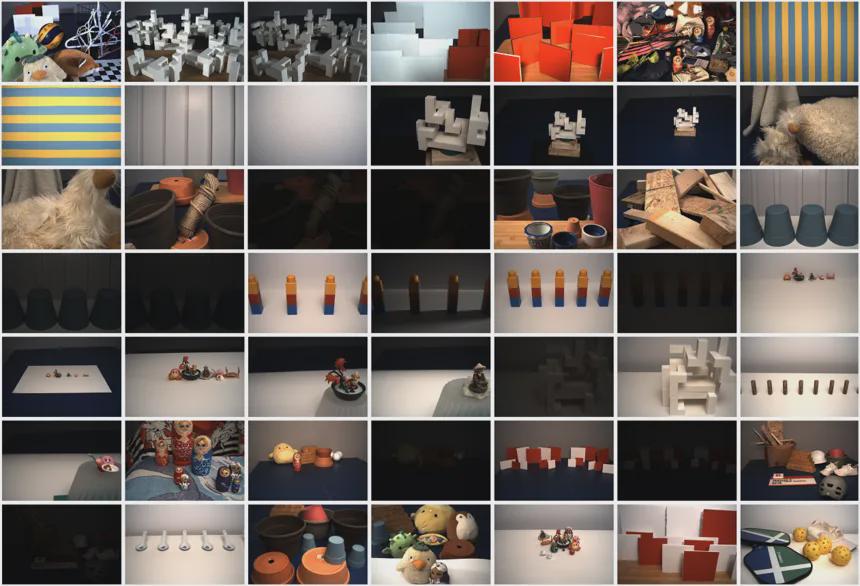
York University Develops CBS Algorithm to Enhance Humanoid Robot Depth Perception
Researchers from York University have introduced the Convergent Binocular Stereo (CBS) algorithm to improve depth perception in humanoid robots. This innovative approach utilizes the movement of the robot's eyes, allowing them to converge on a target while calculating depth based on camera orientation and disparities in the images. This method significantly outperforms traditional depth learning techniques, especially in complex visual scenarios. The advancement is crucial as humanoid robots increasingly rely on sophisticated vision systems to navigate and interact with their environments. By integrating eye movement into depth calculations, the CBS algorithm addresses a long-standing challenge in robotic vision, enhancing the robots' ability to perceive three-dimensional spaces accurately. Looking ahead, the implementation of the CBS algorithm could lead to more advanced humanoid robots capable of better depth perception and spatial awareness. No further timeline was disclosed at the time of publication.
Humanoid Robots Vision Systems Depth Perception Robotics Research
KAIST's Urban Robotics Lab Achieves Top Honors in International Navigation Challenges
KAIST's Urban Robotics Lab secured first and second place in two prestigious international robot navigation challenges. The team developed an AI system that enables robots to self-verify their decisions, ensuring they reach the correct destination. This innovative self-checking technology was instrumental in their success at the competitions held in Malmo, Sweden, and Sydney. The significance of this achievement lies in the advancement of embodied artificial intelligence, which allows robots to better understand human instructions and navigate complex environments. By addressing common navigation errors, such as misidentifying destinations, KAIST's technology enhances the reliability of robotic systems in real-world applications. The competitions were part of the European Conference on Computer Vision 2026 and Robotics: Science and Systems 2026, highlighting the importance of AI in robotics. Looking ahead, the focus will be on further refining the CoRe-VLN system, which utilizes AI to analyze visual and textual data for improved navigation accuracy. No further timeline was disclosed at the time of publication.
All News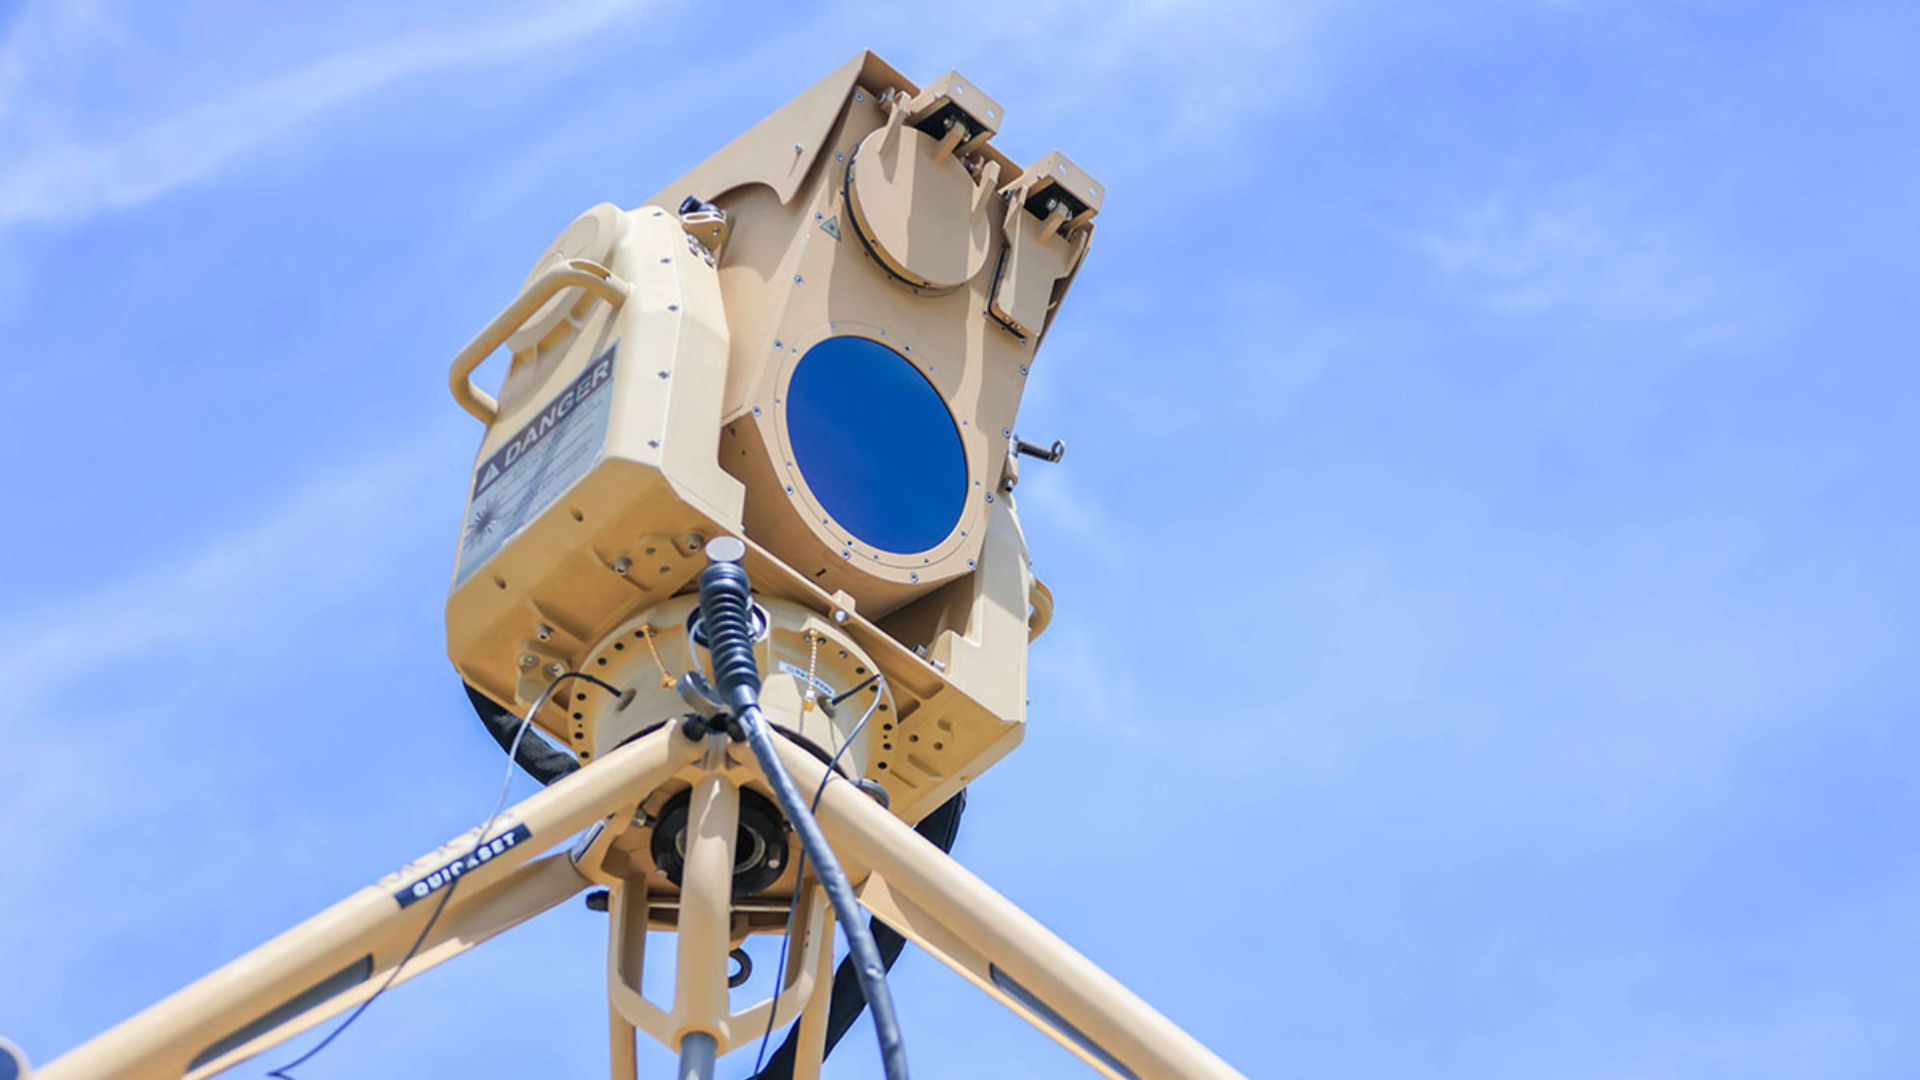
AEye and AB Swiftstrike AI Collaborate on Long-Range Lidar for Drone Detection
AEye and AB Swiftstrike AI are partnering to integrate AEye's STRATOS lidar into Swiftstrike's autonomous counter-drone systems. This collaboration aims to enhance the detection of small aerial threats that operate without conventional radio signals, extending the detection range to nearly one mile. The integration of STRATOS, which boasts more than double the resolution of AEye's Apollo lidar, is significant for identifying small drones. Higher resolution allows for better differentiation between actual aerial targets and surrounding objects, providing precise information on their position and movement. As drone technology evolves, electronic detection becomes increasingly challenging. The STRATOS sensor's ability to actively measure objects using laser pulses offers a viable solution, even when drones do not emit electronic signatures. No further timeline was disclosed at the time of publication.
Military
Durham University Develops Advanced Drone Navigation System for Safer Flight in Crowded Spaces
Researchers at Durham University have created an innovative drone navigation system that allows autonomous aircraft to navigate through cluttered environments more efficiently. This advancement enhances the speed, smoothness, and safety of drone operations in areas filled with obstacles. The significance of this development lies in its potential applications, including search and rescue missions, infrastructure inspections, and environmental monitoring. By improving drone navigation, this system opens up new opportunities for various industries that rely on aerial technology. Looking ahead, the impact of this navigation system could transform how drones are utilized in complex environments. No further timeline was disclosed at the time of publication.
Robotics
Enhancing Visual Interpretability in Exploratory Robots Using Peering Techniques
A recent study published in Science Robotics explores how robot dogs can enhance their visual interpretability through innovative peering techniques. This advancement allows these exploratory robots to better understand and navigate their environments, which is crucial for their operational effectiveness. The significance of this research lies in its potential to improve the interaction between robots and their surroundings, making them more adept at performing tasks that require visual comprehension. By employing peering methods, these robots can interpret complex visual data more effectively, which is essential for applications in various fields, including search and rescue operations. Looking ahead, the implications of this research could lead to further developments in robotic vision systems. As the technology evolves, it will be important to monitor how these advancements are integrated into real-world applications and the impact they have on the capabilities of exploratory robots. No further timeline was disclosed at the time of publication.
Research Resource
Hefei Team Develops All-Weather Forestry Inspection Robot for Enhanced Fire Detection
A team led by Cheng Ziyang has developed a forestry inspection robot designed to address the limitations of traditional fire detection methods. The robot integrates LiDAR and thermal imaging technologies, enabling it to operate effectively in low visibility conditions such as nighttime and smoke. This innovation aims to enhance the efficiency of forest fire monitoring by autonomously navigating complex terrains and detecting temperature anomalies that are often precursors to fires. The significance of this development lies in its potential to improve forest fire prevention efforts. Traditional methods, including fixed sensors and manual patrols, have proven inadequate due to high costs, low efficiency, and limited coverage. The new robot has demonstrated a 27% increase in inspection coverage and significantly improved accuracy in identifying fire sources, thereby reducing the need for human intervention in hazardous areas. Looking ahead, the team plans to further optimize the robot's performance and push for its industrialization. The challenges of cost, reliability, and mass delivery remain, but overcoming these hurdles could lead to a substantial enhancement in the intelligence of forest fire protection systems, ultimately reducing risks and improving response times in emergency situations.
Forestry Robotics Fire Detection Technology Autonomous Systems Environmental Monitoring
Boston Dynamics Introduces Industrial-Style Head for Atlas Robot Design
Boston Dynamics has redesigned its Atlas robot, incorporating an industrial-style head instead of human-like features. Mechanical engineer Taylor Frey-Baker emphasized that Atlas is intended for industrial environments, thus its appearance should reflect that purpose. The head lacks facial features and includes light rings that communicate the robot's operational status and intentions to nearby workers. This design choice is significant as it prioritizes safety and efficiency in shared workspaces. The head's lighting interface provides immediate visual cues about Atlas's actions, reducing ambiguity in industrial settings. The robot is equipped with HDR stereo cameras that enhance environmental perception, allowing operators to navigate challenging lighting conditions effectively. Looking ahead, the integration of the head as a sensor carrier and status indicator positions Atlas to work safely and predictably alongside human workers in factories and warehouses. No further timeline was disclosed at the time of publication.
Industrial Robots Robot Design Automation Technology Safety Systems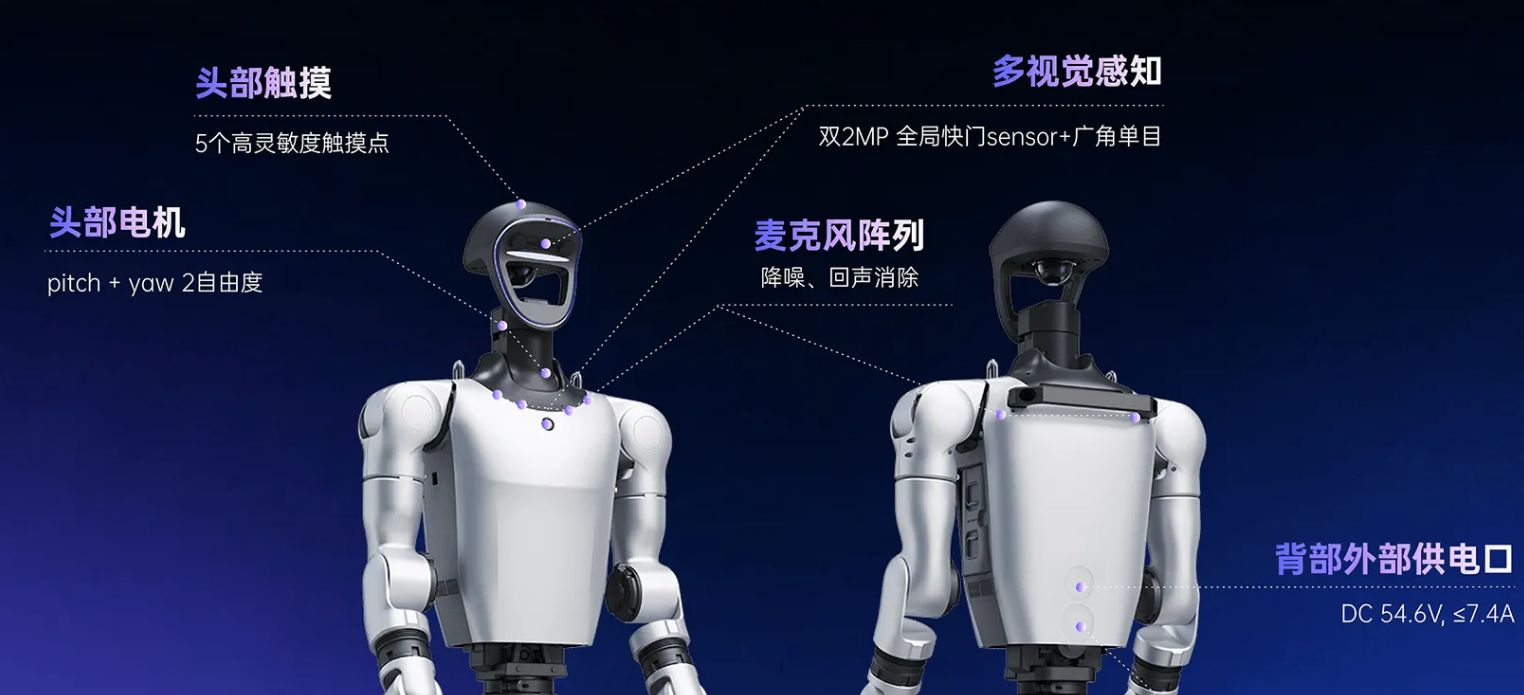
Unitree Introduces Enhanced G1+ Humanoid Robot Featuring Six Key Upgrades
Unitree has unveiled the G1+, an upgraded version of its G1 humanoid robot, featuring six significant enhancements in motion performance, perception, interaction, and endurance. The standard model is priced at RMB 95,000 in China, while the G1+ EDU version is available upon request through sales channels. The G1+ introduces two additional neck degrees of freedom, increases peak shoulder and waist motor torque by 110%, and boosts maximum arm torque by 43%, all while reducing heat generation at the same torque levels. These upgrades enhance the robot's operational capabilities, making it more versatile for various applications. Looking ahead, the G1+ is expected to attract interest in educational and research settings due to its advanced features, including a binocular-plus-wide-angle vision system, head touch sensing, external power support, a six-microphone array, and dual 10-watt speakers. No further timeline was disclosed at the time of publication.
News Feed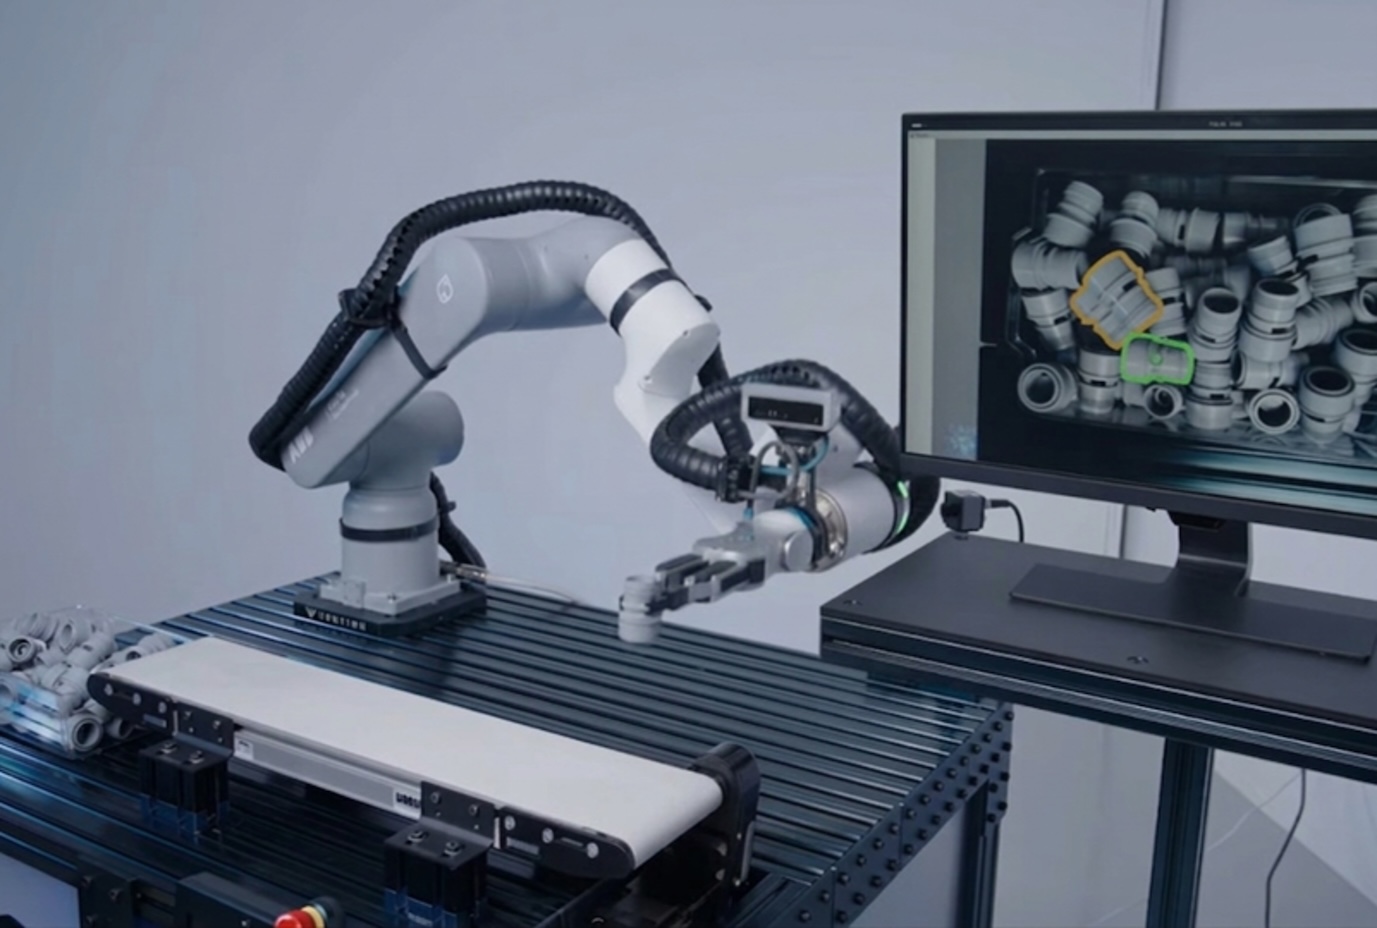
CSGE Enhances Multi-View 3D Detection in Robotic Systems with Modular Cross-Spatial Representation
The Journal of Field Robotics has published an early view article detailing the development of CSGE, a modular cross-spatial guided space representation designed to improve multi-view 3D detection in robotic systems. This innovative approach aims to enhance the accuracy and efficiency of 3D perception in various robotic applications. The significance of CSGE lies in its potential to address challenges in multi-view 3D detection, which is crucial for the effective operation of robotic systems in complex environments. By utilizing a modular design, CSGE allows for flexible integration into existing robotic frameworks, potentially leading to advancements in automation and intelligent manufacturing. Looking ahead, the industry will be monitoring the implementation of CSGE in real-world robotic applications and its impact on performance metrics. Further developments and research findings related to this technology may provide insights into its broader applicability and effectiveness in enhancing robotic perception capabilities. No further timeline was disclosed at the time of publication.
RESEARCH ARTICLE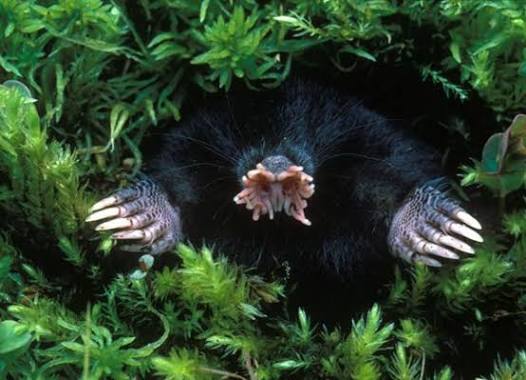
University of Southern Denmark Develops Touch-Based Robot Inspired by Star-Nosed Moles
The University of Southern Denmark's robotics team has proposed a concept robot that relies on touch rather than vision, inspired by the star-nosed mole. This mammal is known for its exceptional tactile sensitivity, using its unique nose structure to detect food with remarkable precision. The team's design mimics the functionality of the mole's Eimer organs, which are sensitive structures that allow the mole to perceive its environment through touch. This innovative approach is significant as it addresses the limitations of visual-based robotics, which struggle with transparent, obscured, or hidden objects. By utilizing a flexible liquid-filled tube equipped with pressure sensors, the robot can generate tactile signals in response to external pressure, offering a different sensory pathway compared to traditional visual systems. This could be particularly valuable for robots operating in dark or confined spaces where vision is inadequate. Currently, the prototype remains in the conceptual stage and has not been officially released. However, it signifies a shift towards multimodal perception in robotics, complementing visual information with tactile feedback. As robots are expected to navigate various unstructured environments, the integration of touch could enhance their operational capabilities, similar to the evolutionary adaptations seen in star-nosed moles.
Robotics Tactile Sensors Artificial Intelligence Sensor Technology
IMTS 2026 Preview: Record Orders and the Automation Story
IMTS 2026 opens in Chicago with 1,788 exhibitors and record H1 machine tool orders. What the USMTO data says about automation, and the booths to see.
China’s Dexterous Hand Industry, 2026 Part 1 — The Demand Picture
MIR Databank puts China dexterous hand shipments above 30,000 units in 2026, yet only 3.5% of 2025 demand came from factory production. Part 1 of 3.
China’s Dexterous Hand Industry, 2026 Part 2 — The Technology
Linkage, tendon, direct drive or hybrid — and why hardware is converging while the DL1–DL5 manipulation scale decides who wins. Part 2 of 3.
ROBOTTODAY WEEKLY BRIEFING August 24 – 28, 2026
This week in robotics: XPeng's Dogotix raises over $900 million at a $6.3 billion valuation, Unitree's post-IPO slump revives bubble talk, Beijing's World Humanoid Robot Games close with a shift to real-world tasks, and Teradyne sues JAKA at Europe's Unified Patent Court. August 24–28, 2026.
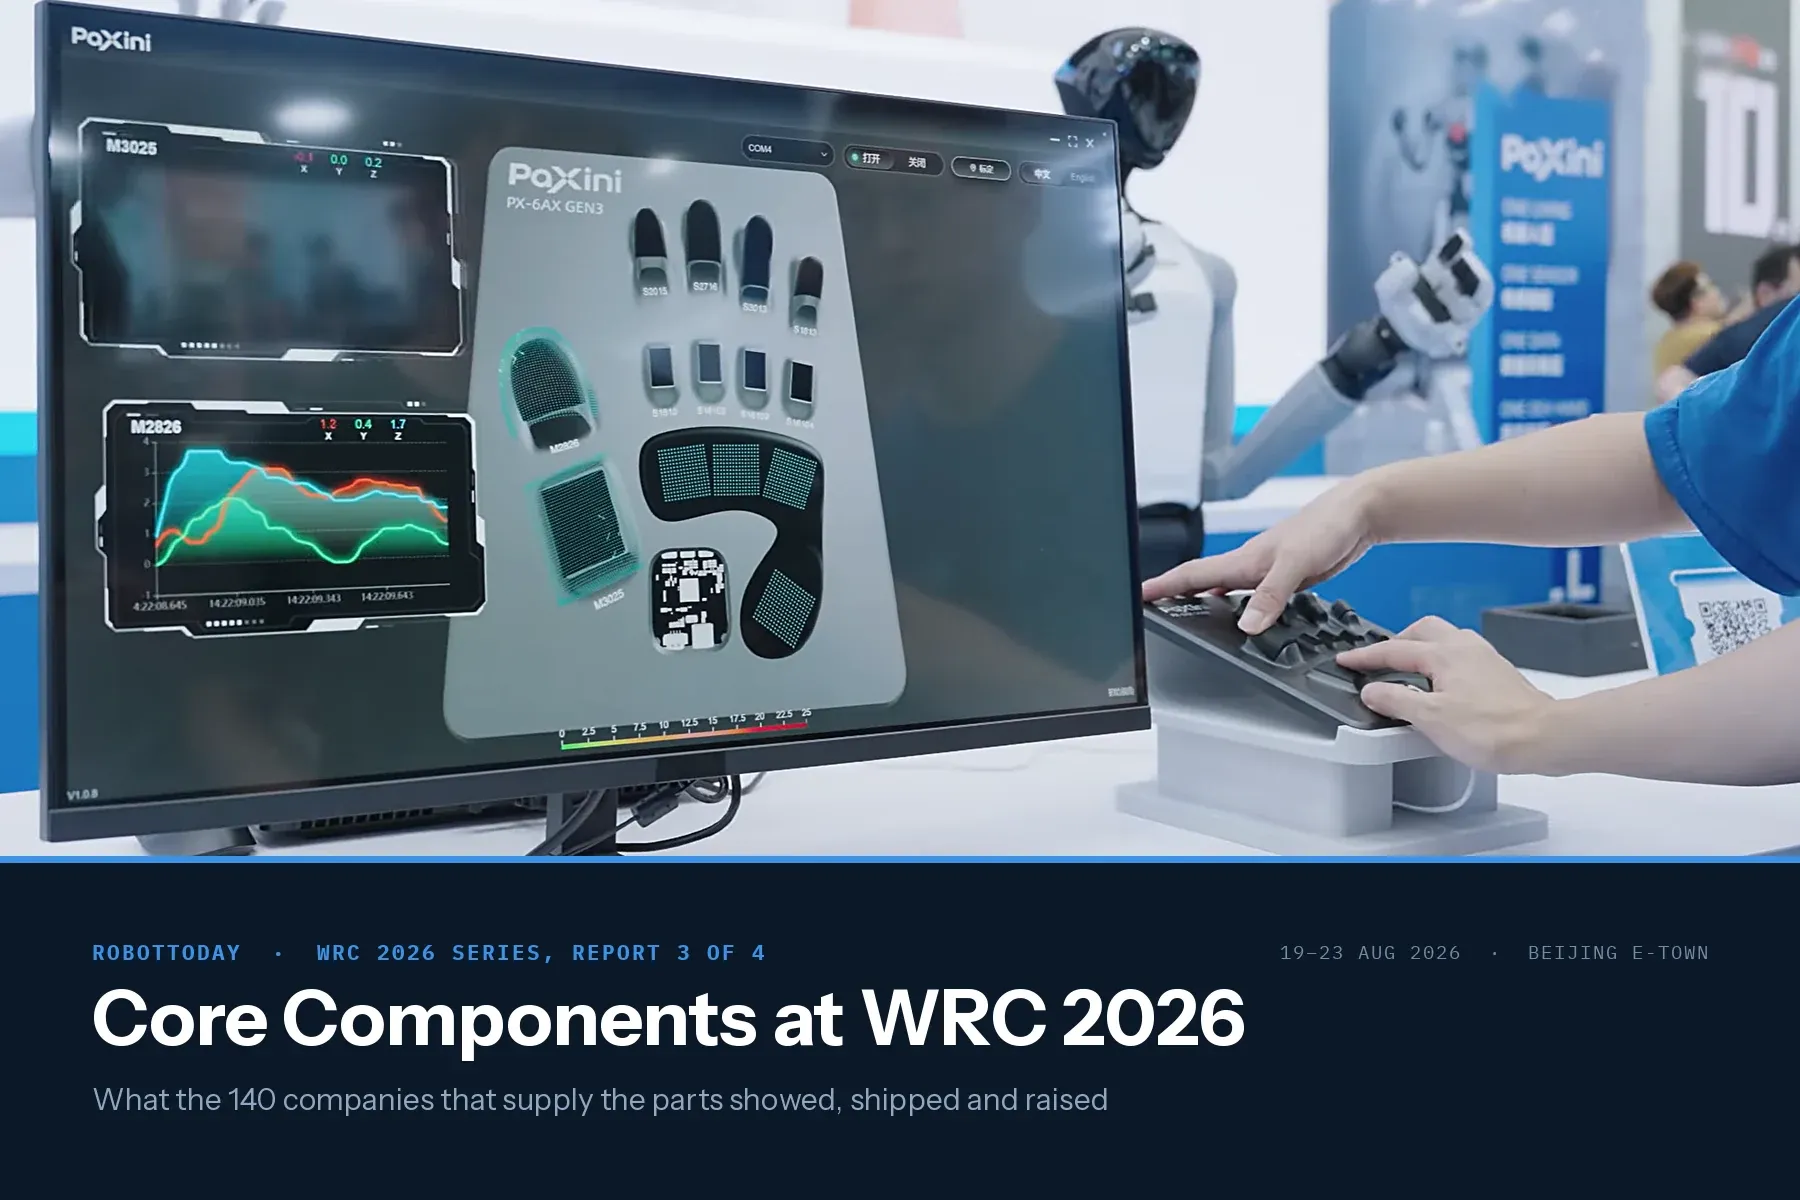
WRC 2026 Core Components: 137 Robot Parts Suppliers
The third report in the WRC 2026 series. Report 1 mapped all 248 exhibitors by category and Report 2 covered the 139 that build finished robots. This one covers the 137 that build what goes inside them.
WRC 2026 Exhibitor Map: 248 Robotics Companies Mapped
We classified 248 WRC 2026 exhibitors with the RobotToday taxonomy. Motion & Actuation leads at 75 companies, Humanoid at 72, and compute stays thin at 12. (Modified 2026-08-27)
Handbook of Marine Craft Hydrodynamics and Motion Control Thor I. Fossen — RSF Specialist Shelf · Book S1 of 6
Added mass, wave loading, DVL navigation: the marine GNC reference for USV, ROV and AUV service engineers. The hardest book on the RSF list, 5/5.
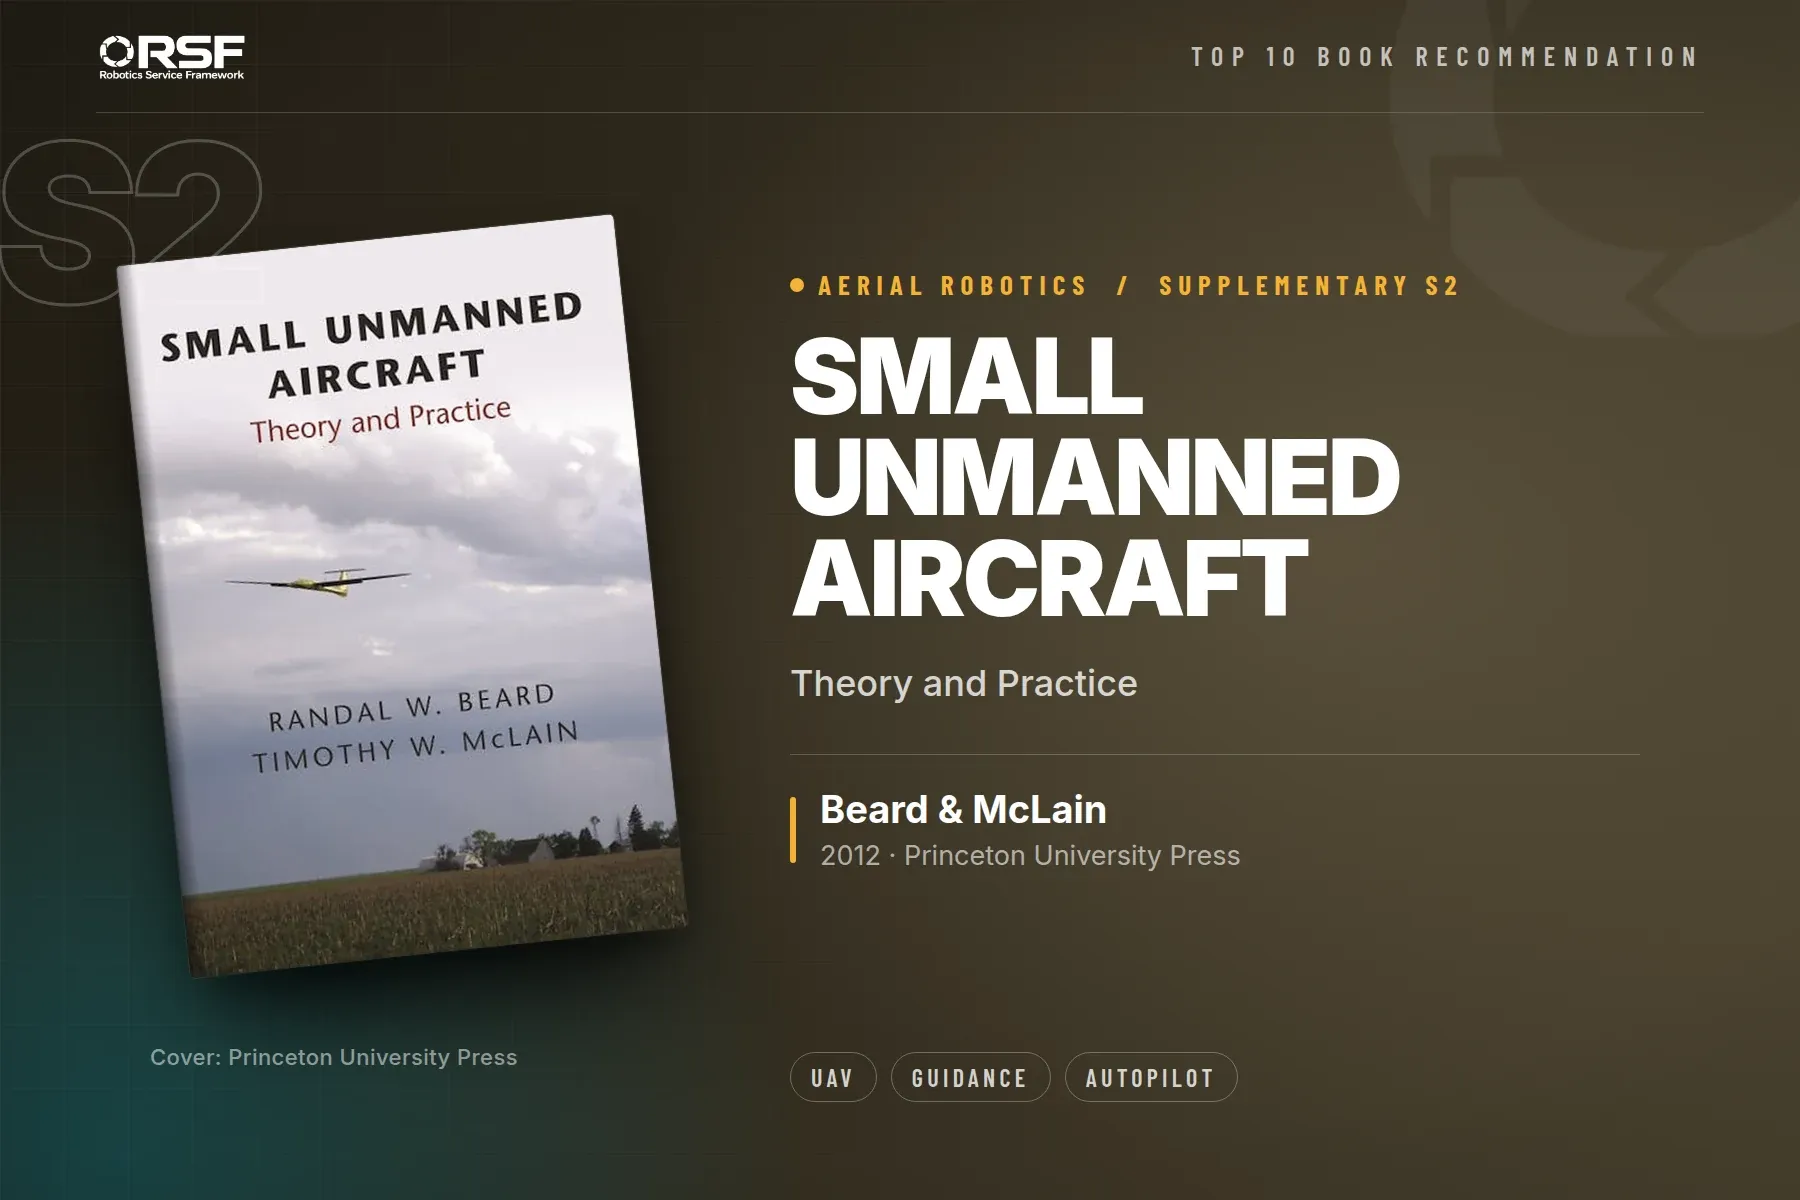
Small Unmanned Aircraft: Theory and Practice Beard & McLain — RSF Specialist Shelf · Book S2 of 6
Beard & McLain derive the fixed-wing autopilot the RSF Top 10 never does: successive loop closure on roll, pitch, altitude and airspeed. 4/5.
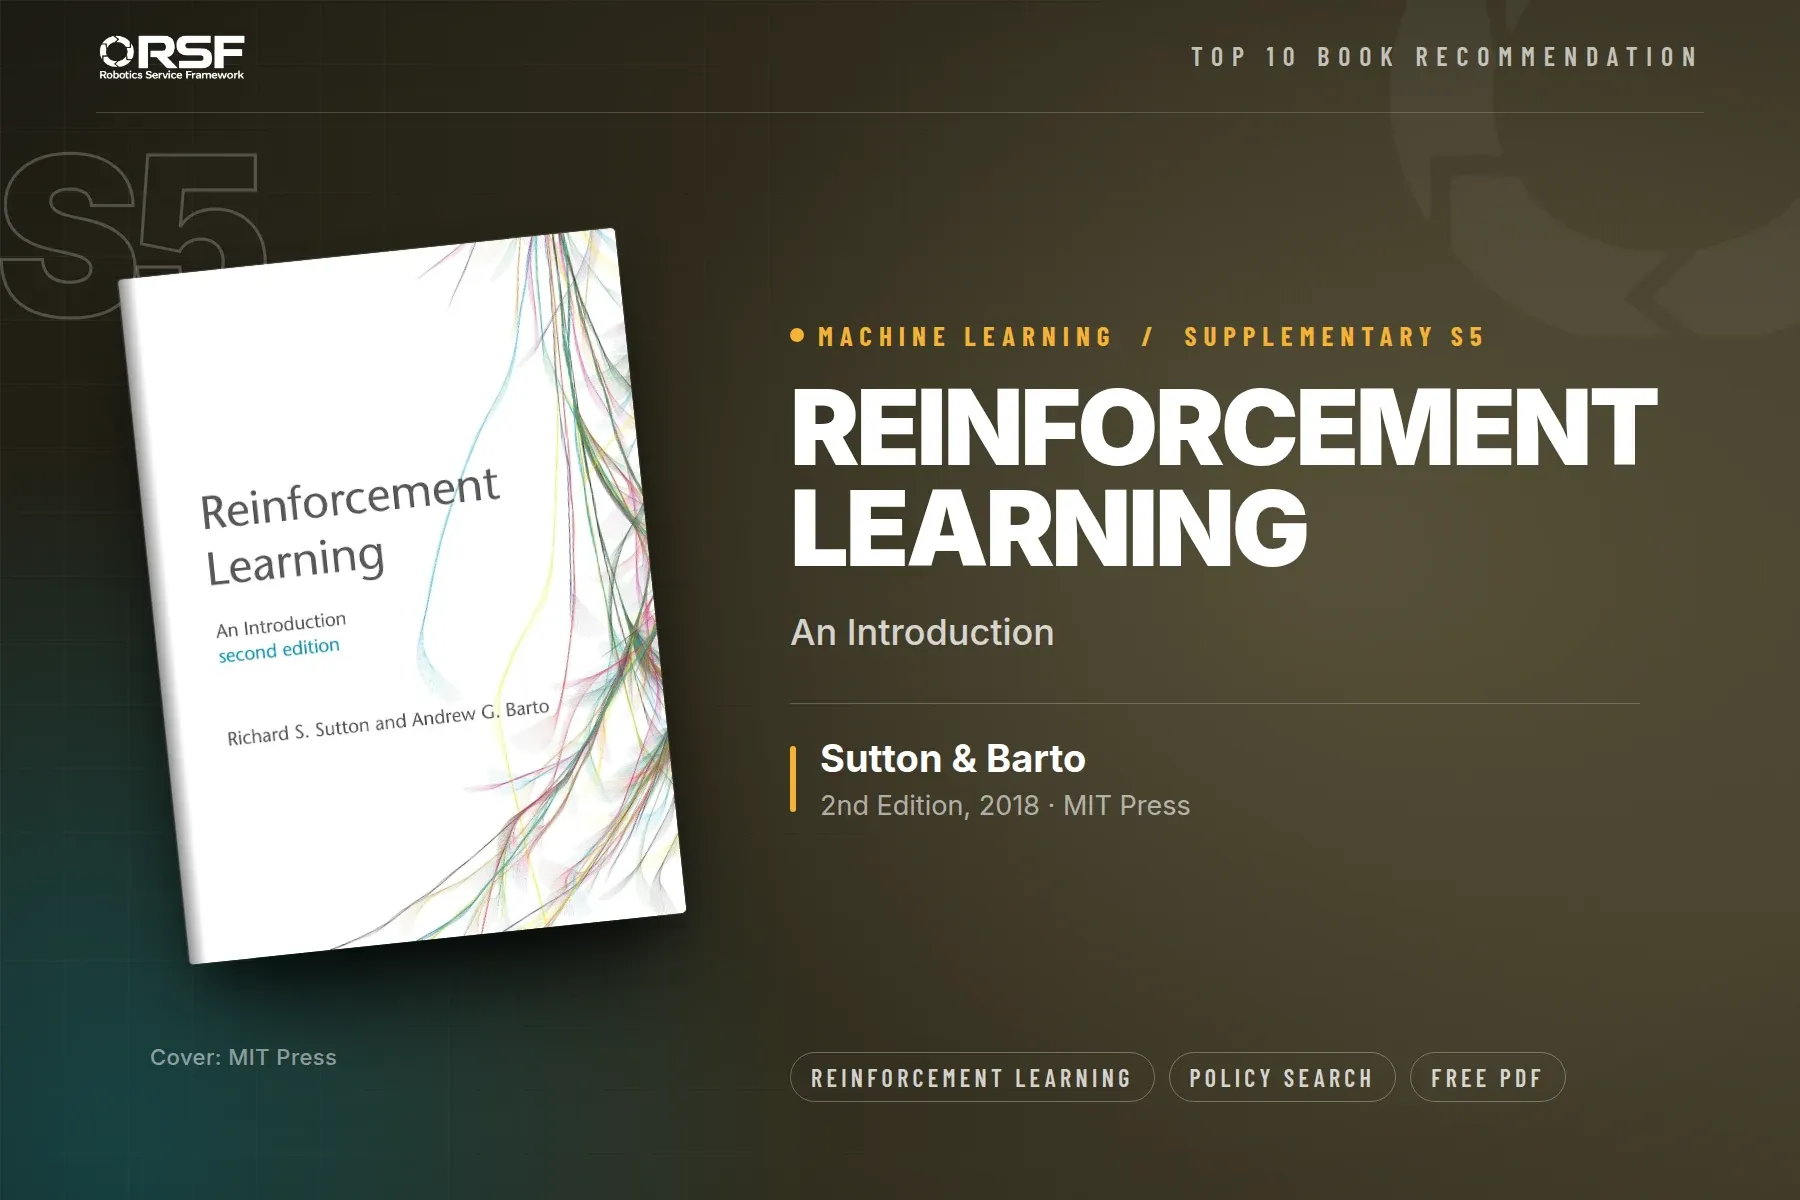
Reinforcement Learning: An Introduction Richard S. Sutton & Andrew G. Barto — RSF Specialist Shelf · Book S5 of 6
“It's the AI” will not satisfy an OEM support call. Sutton & Barto turn that into something a service engineer can investigate. Free PDF, Part I 4/5.
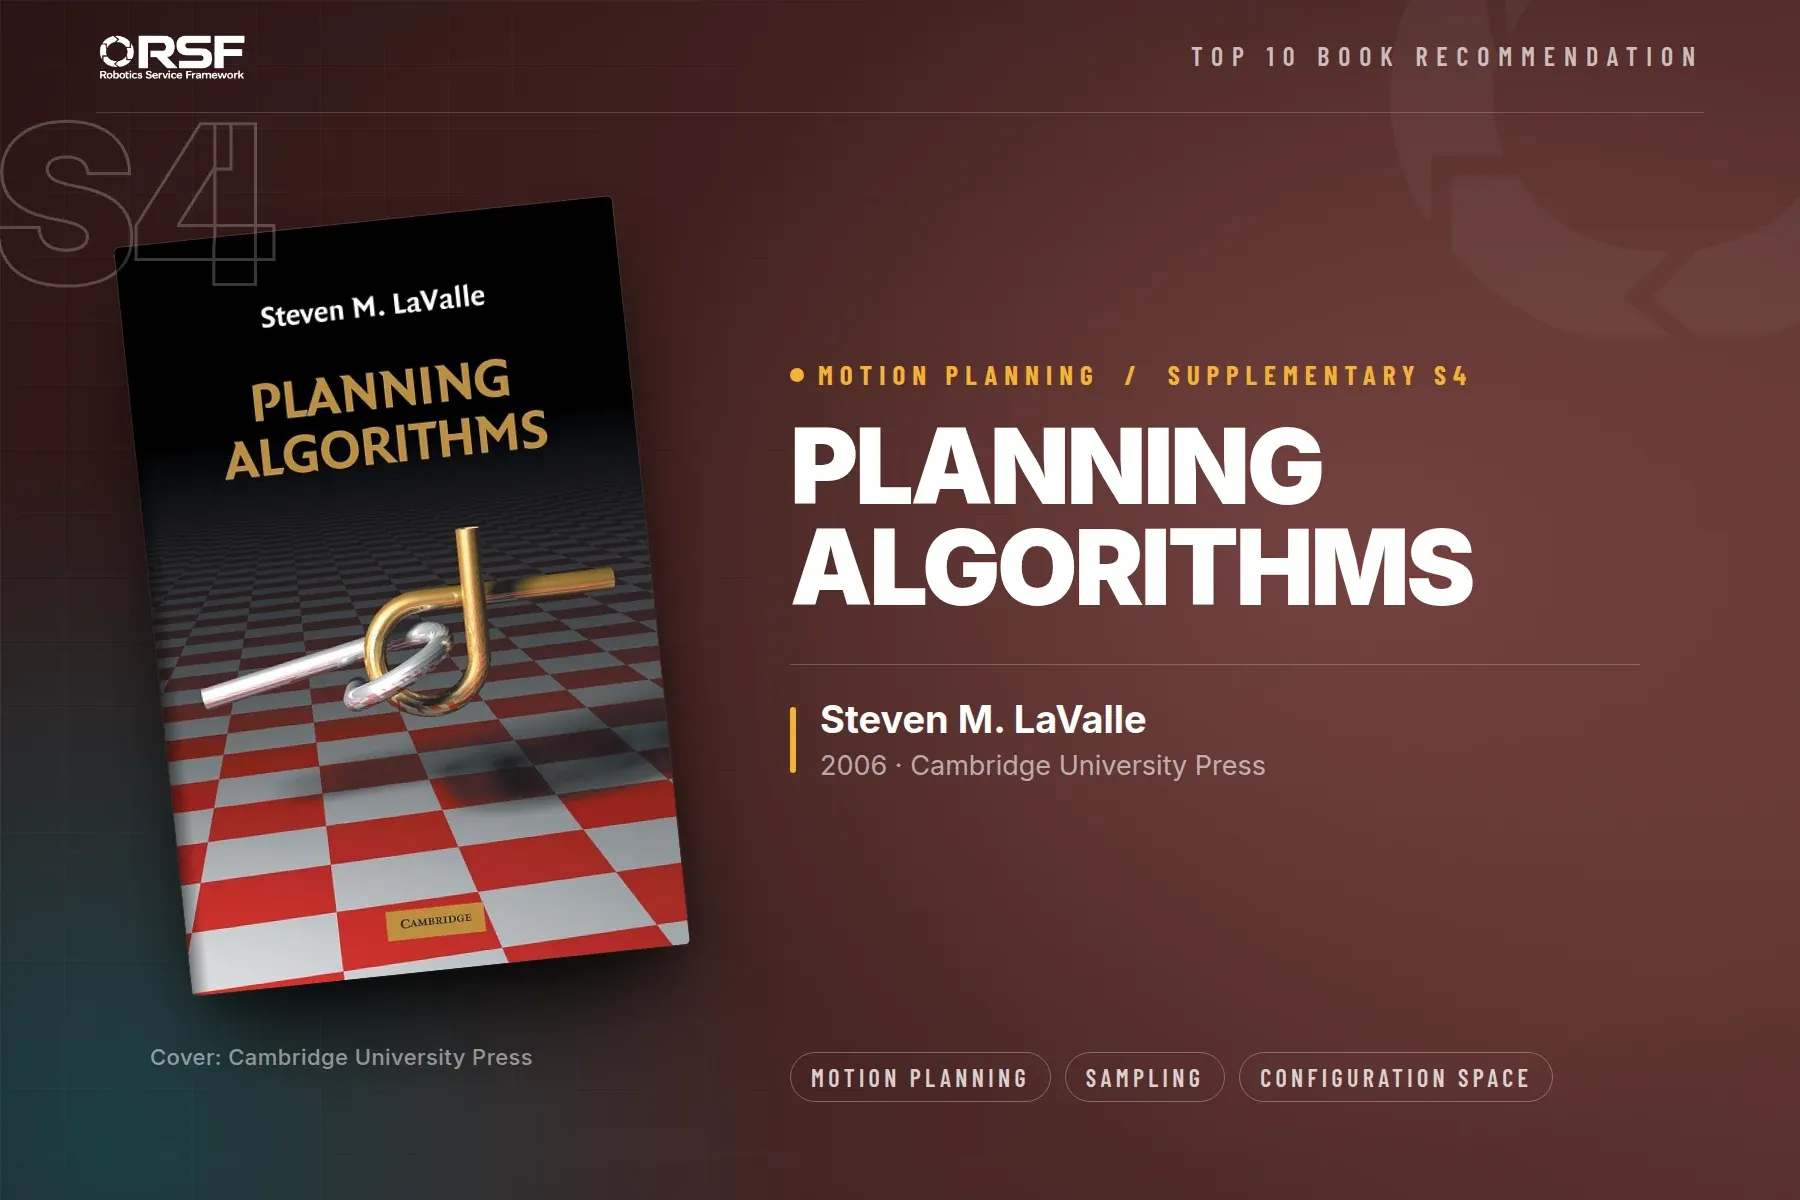
Planning Algorithms Steven M. LaValle — RSF Specialist Shelf · Book S4 of 6
The reference that treats planning as a subject in its own right: configuration space, sampling-based methods, RRT. Free online, dual difficulty 4/5-2/5.


